Week 4.1 - Genetic Algorithm
*Report of Genetic Algorithm
*challenge_skill lync-ganesh katkar
AIM : To write matlab code to optimize the stalagmite function and find the global maxima of the function.
OBJECTIVE : Explaining the concept of genetic algorithm and also explain the syntax for ga in MATLAB. Plot graphs for all 3 studies and for F maximum vs no. of iteration.
Theory :
In computer science and operations research, a genetic algorithm (GA) is a metaheuristic inspired by the process of natural selection that belongs to the larger class of evolutionary algorithms (EA). Genetic algorithms are commonly used to generate high-quality solutions to optimization and search problems by relying on biologically inspired operators such as mutation, crossover and selection.
The genetic algorithm is a technique for solving both constrained and unconstrained optimization problems that are based on natural selection, the process that drives biological evolution. The genetic algorithm constantly modifies the population size of individual solutions.
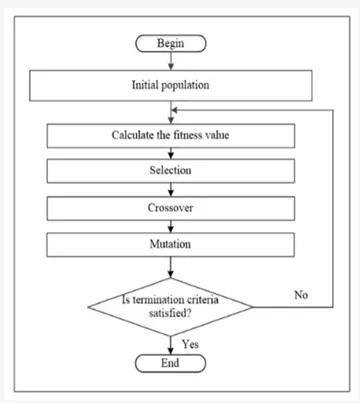
Phases in Genetic Algoritham-
1 .Initialization of Population (Coding)
The code generates its random population of defined size and from that population the code evaluates the fitness of the members of the population according to which it forms new population based on no. of iterations performed.
1.Fitness Function
It is that function which we have to optimize and its optimization is done with the help of number of generations which have been formed by the code accordance with the fitness value of each member generated, these fitness values are used for the reproduction of the children.
1.Selection
The idea of the selection phase is to select the fittest individuals and let them pass their genes to the next generation. The main goal of this phase is to find the region where the chances of getting the best solution are more.
Inspiration for this is from the survival of the fittest.
It should be a balance between exploration and exploitation of search space.
GA tries to move the genotype to higher fitness in the search space.
Too strong fitness selection bias can lead to sub-optimal solutions.
Too little fitness bias selection results in unfocused search.
1.Reproduction
Generation of offspring happen in 2 way:
Crossover
Mutation
A) Crossover
Crossover is the most significant stage in the genetic algorithm. During crossover, a random point is selected while mating a pair of parents to generate offspring.
There are 3 major types of crossover.
Single Point Crossover:A point on both parents’ chromosomes is picked randomly, and designated a ‘crossover point’.
Two-Point Crossover: Two crossover points are picked randomly from the parent chromosomes.
Unifofm Crossover: In a uniform crossover, typically, each bit is chosen from either parent with equal probability.
B) Mutation
In a few new offspring formed, some of their genes can be subjected to a mutation with a low random probability. This indicates that some of the bits in the bit chromosome can be flipped. Mutation happens to take care of diversity among the population and stop premature convergence.
Syntax Genetic Algorithm:
x = ga(fun,nvars,A,b,Aeq,beq,lb,ub)
x = ga(fun,nvars,A,b,Aeq,beq,lb,ub,nonlcon)
x = ga(fun,nvars,A,b,Aeq,beq,lb,ub,nonlcon,options)
x = ga(fun,nvars,A,b,[],[],lb,ub,nonlcon,IntCon)
x = ga(fun,nvars,A,b,[],[],lb,ub,nonlcon,IntCon,options)
[x,fval,exitflag,output] = ga(___)
[x,fval,exitflag,output,population,scores] = ga(___)
Description:
x = ga(fun,nvars) finds a local unconstrained minimum, x, to the objective function, fun. nvars is the dimension (number of design variables) of fun.
x = ga(fun,nvars,A,b) finds a local minimum x to fun, subject to the linear inequalities A*x ≤ b. ga evaluates the matrix product A*x as if x is transposed (A*x').
x = ga(fun,nvars,A,b,Aeq,beq) finds a local minimum x to fun, subject to the linear equalities Aeq*x = beq and A*x ≤ b. (Set A=[] and b=[] if no linear inequalities exist.) ga evaluates the matrix product Aeq*x as if x is transposed (Aeq*x').
x = ga(fun,nvars,A,b,Aeq,beq,lb,ub) defines a set of lower and upper bounds on the design variables, x, so that a solution is found in the range lb ≤ x ≤ ub. (Set Aeq=[] and beq=[] if no linear equalities exist.)
x = ga(fun,nvars,A,b,Aeq,beq,lb,ub,nonlcon) subjects the minimization to the constraints defined in nonlcon. The function nonlcon accepts x and returns vectors C and Ceq, representing the nonlinear inequalities and equalities respectively. ga minimizes the fun such that C(x) ≤ 0 and Ceq(x) = 0. (Set lb=[] and ub=[] if no bounds exist.)
x = ga(fun,nvars,A,b,Aeq,beq,lb,ub,nonlcon,options) minimizes with the default optimization parameters replaced by values in options. (Set nonlcon=[] if no nonlinear constraints exist.) Create options using optimoptions.
x = ga(fun,nvars,A,b,Aeq,beq,lb,ub,nonlcon,intcon) or x = ga(fun,nvars,A,b,Aeq,beq,lb,ub,nonlcon,intcon,options) requires that the variables listed in intcon take integer values.
x = ga(problem) finds the minimum for problem, a structure described in problem.
[x,fval] = ga(___), for any previous input arguments, also returns fval, the value of the fitness function at x.
[x,fval,exitflag,output] = ga(___) also returns exitflag, an integer identifying the reason the algorithm terminated, and output, a structure that contains output from each generation and other information about the performance of the algorithm.
[x,fval,exitflag,output,population,scores] = ga(___) also returns a matrix population, whose rows are the final population, and a vector scores, the scores of the final population.
Body of the content :
f(x,y) = f1,xf2,x,f1,y,f2,y
f1.x = [sin(5.1pi.x + 0.5)]^6
f1.y = [sin(5.1pi.y + 0.5)]^6
f2,x = exp[-4In(2)((x-0.0667)^2/0.64)]
f2,y = exp[-4In(2)((y-0.0667)^2/0.64)]
The above equations are used in the stalagmite function to plot the graph in the main functions.
function f = stalagmite_fun(input)
x = input(1);
y = input(2);
f1x = (sin(((5.1*pi).*x)+0.5)).^6;
f1y = (sin(((5.1*pi).*y)+0.5)).^6;
f2x = exp((((x-0.0667).^2).*(-4*log(2)))./0.64);
f2y = exp((((y-0.0667).^2).*(-4*log(2)))./0.64);
f = -f1x*f1y*f2x*f2y;
While using the function at the end as we are using the -ve sign so that the plot will be reversed as we have to find the maxima of the given function using ga.
clear all
close all
clc
% Defining search space
x = linspace(0,0.6,150);
y = linspace(0,0.6,150);
num_cases = 50;
%Number of itreation for which the function will evaluate the fitness
% creating 2D mesh
[xx,yy] = meshgrid(x,y);
for i = 1:length(xx)
for j = 1:length(yy)
input(1) = xx(i,j);
input(2) = yy(i,j);
f(i,j) = stalagmite_fun(input);
end
end
Firstly, creating the mesh from the two vectors which will be acting as a search space to find the maxima of the function.
Creating the mesh of these two vectors using the ‘mesh’ command and defining the no. of iterations as num_cases to iterate the values of the optimum values of the function.
Now calculating the values of fitness function at each point of the mesh grid formed.
Now creating its surface through ‘surfc’ command which will also provide the contour of the generated surface.
While using surfc applying the -ve sign to the function will generate the surface upside down which will be quite good to get the maxima of the function, as it will provide positive value for the maxima using the -ve sign.
Study 1: unbounded input
clear all
close all
clc
% Defining search space
x = linspace(0,0.6,150);
y = linspace(0,0.6,150);
num_cases = 50;
%Number of itreation for which the function will evaluate the fitness
% creating 2D mesh
[xx,yy] = meshgrid(x,y);
for i = 1:length(xx)
for j = 1:length(yy)
input(1) = xx(i,j);
input(2) = yy(i,j);
f(i,j) = stalagmite_fun(input);
end
end
% study 1 - Statistical behavior of genetic algorithm
tic
for i = 1:num_cases
[inputs,fopt(i)] = ga(@stalagmite_fun,2);
xopt(i) = inputs(1);
yopt(i) = inputs(2);
end
fopt = -fopt
f = -f
study1_time = toc
figure(1)
subplot(2,1,1)
hold on
surfc(x,y,f)
shading interp
plot3(xopt,yopt,fopt,'marker','o','MarkerSize',5,'MarkerFaceColor','r')
title('Unbounded inputs')
subplot(2,1,2)
plot(fopt)
xlabel('Interations')
ylabel('Functions maxima')
when execute,the plot is shown
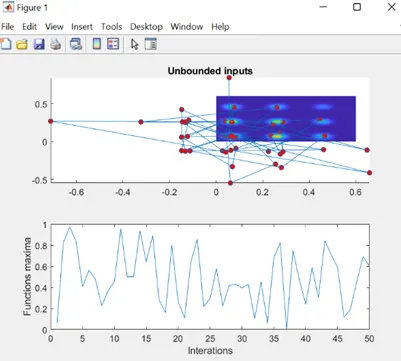
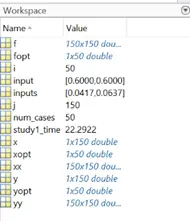
study1_time =
22.2922
Study 2 : bounded input
clear all
close all
clc
% Defining search space
x = linspace(0,0.6,150);
y = linspace(0,0.6,150);
num_cases = 50;
%Number of itreation for which the function will evaluate the fitness
% creating 2D mesh
[xx,yy] = meshgrid(x,y);
for i = 1:length(xx)
for j = 1:length(yy)
input(1) = xx(i,j);
input(2) = yy(i,j);
f(i,j) = stalagmite_fun(input);
end
end
% study 2 - statistical behaviour - with upper and lower bounds
tic
for i = 1:num_cases
[inputs,fopt(i)] = ga(@stalagmite_fun,2,[],[],[],[],[0;0],[1;1]);
xopt(i) = inputs(1);
yopt(i) = inputs(2);
end
fopt = -fopt
f = -f
study2_time = toc
figure(2)
subplot(2,1,1)
hold on
surfc(x,y,f)
shading interp
plot3(xopt,yopt,fopt,'marker','o','MarkerSize',5,'MarkerFaceColor','r')
title('bounded inputs')
subplot(2,1,2)
plot(fopt)
xlabel('Interations')
ylabel('Functions maxima')
when execute,the plot is shown
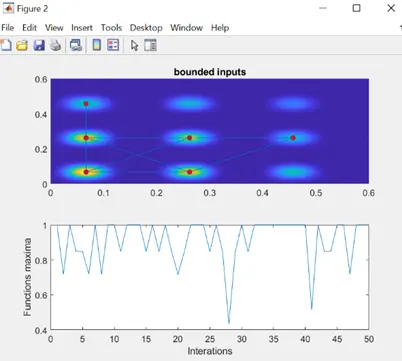
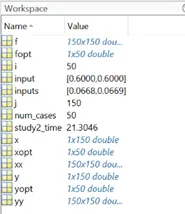
study2_time =
21.3046
Study 3: bounded input with modified population size (250)
clear all
close all
clc
% Defining search space
x = linspace(0,0.6,150);
y = linspace(0,0.6,150);
num_cases = 50;
%Number of itreation for which the function will evaluate the fitness
% creating 2D mesh
[xx,yy] = meshgrid(x,y);
for i = 1:length(xx)
for j = 1:length(yy)
input(1) = xx(i,j);
input(2) = yy(i,j);
f(i,j) = stalagmite_fun(input);
end
end
% study 3 - increasing GA iteration
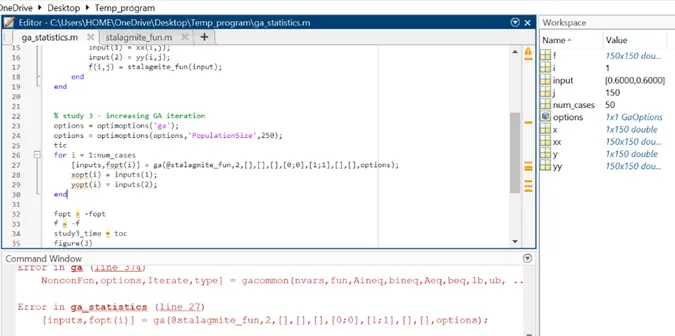
options = optimoptions('ga');
options = optimoptions(options,'PopulationSize',250);
tic
for i = 1:num_cases
[inputs,fopt(i)] = ga(@stalagmite_fun,2,[],[],[],[],[0;0],[1;1],[],[],options);
xopt(i) = inputs(1);
yopt(i) = inputs(2);
end
fopt = -fopt
f = -f
study3_time = toc
figure(3)
subplot(2,1,1)
hold on
surfc(x,y,f)
shading interp
plot3(xopt,yopt,fopt,'marker','o','MarkerSize',5,'MarkerFaceColor','r')
title('Bounded inputs with modified population size')
subplot(2,1,2)
plot(fopt)
xlabel('Interations')
ylabel('Functions maxima')
when execute,the plot is shown
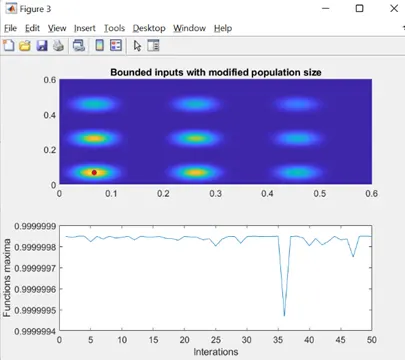
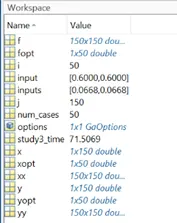
study3_time =
71.506
references:
https://en.wikipedia.org/wiki/Genetic_algorithm
https://in.mathworks.com/discovery/genetic-algorithm.html
conclusion:
finally we found the global maxima by optimizing stalagmite function using genetic algorithm in matlab.
clear all
close all
clc

% Defining search space
x = linspace(0,0.6,150);
y = linspace(0,0.6,150);
num_cases = 50;

% creating 2D mesh
[xx,yy] = meshgrid(x,y);

for i = 1:length(xx)
    for j = 1:length(yy)
        input(1) = xx(i,j);
        input(2) = yy(i,j);
        f(i,j) = stalagmite_fun(input);
    end
end

% study 1 - Statistical behavior of genetic algorithm
tic
for i = 1:num_cases
    [inputs,fopt(i)] = ga(@stalagmite_fun,2);
    xopt(i) = inputs(1);
    yopt(i) = inputs(2);
end

fopt = -fopt
f = -f
study1_time = toc
figure(1)
subplot(2,1,1)
hold on
surfc(x,y,f)
shading interp
plot3(xopt,yopt,fopt,'marker','o','MarkerSize',5,'MarkerFaceColor','r')
title('Unbounded inputs')
subplot(2,1,2)
plot(fopt)
xlabel('Interations')
ylabel('Functions maxima')

% study 2 - statistical behaviour - with upper and lower bounds
tic
for i = 1:num_cases
    [inputs,fopt(i)] = ga(@stalagmite_fun,2,[],[],[],[],[0;0],[1;1]);
    xopt(i) = inputs(1);
    yopt(i) = inputs(2);
end

fopt = -fopt
f = -f
study2_time = toc
figure(2)
subplot(2,1,1)
hold on
surfc(x,y,f)
shading interp
plot3(xopt,yopt,fopt,'marker','o','MarkerSize',5,'MarkerFaceColor','r')
title('bounded inputs')
subplot(2,1,2)
plot(fopt)
xlabel('Interations')
ylabel('Functions maxima')

% study 3 - increasing GA iteration
options = optimoptions('ga');
options = optimoptions(options,'PopulationSize',250);
tic
for i = 1:num_cases
    [inputs,fopt(i)] = ga(@stalagmite_fun,2,[],[],[],[],[0;0],[1;1],[],[],options);
    xopt(i) = inputs(1);
    yopt(i) = inputs(2);
end

fopt = -fopt
f = -f
study3_time = toc
figure(3)
subplot(2,1,1)
hold on
surfc(x,y,f)
shading interp
plot3(xopt,yopt,fopt,'marker','o','MarkerSize',5,'MarkerFaceColor','r')
title('Bounded inputs with modified population size')
subplot(2,1,2)
plot(fopt)
xlabel('Interations')
ylabel('Functions maxima')

function f = stalagmite_fun(input)
x = input(1);
y = input(2);

f1x = (sin(((5.1*pi).*x)+0.5)).^6;
f1y = (sin(((5.1*pi).*y)+0.5)).^6;

f2x = exp((((x-0.0667).^2).*(-4*log(2)))./0.64);
f2y = exp((((y-0.0667).^2).*(-4*log(2)))./0.64);

f = -f1x*f1y*f2x*f2y
end