Week 3 - Solving second order ODEs
In this project we attempt to write a program to solve a Second order differential Equation using MATLAB. We, also write a program to represent the pendulum for the given ODE.
The parameters are already given in the question so, we use the same parameters to solve the ode.
The following program is written as follows :
clear all
close all
clc

b = 0.05;
g = 9.81;
l = 1;
m = 1;

% initial conditions
theta_a = [0;3];

% time points
t_span = linspace(0,20,100);

% solve ODE
[t,results] = ode45(@(t,theta) ode_func(t, theta, b,g,l,m), t_span, theta_a);

output = results(:,1);

%contour_command
ct = 1;
for i = 1:length(output)
    disp = output(i);

    % start position
    x0 = 0;
    y0 = 0;

    % final position

    x1 = l * sin(disp);
    y1 = -l * cos(disp);

    % plot

    plot([x0 x1], [y0 y1], x1,y1, '.','markersize',20,'linewidth',4)
    axis([-1.3 1.3 -1.3 1.3])
    hold off
    grid on
    M(ct) = getframe(gcf);
    ct = ct+1;
end

% animation
movie(M)
videofile = VideoWriter('ode_pendulum');
open(videofile)
writeVideo(videofile,M)
close(videofile)
Now we write a code to produce the damping graph as follows :
plot(t,results(:,1))
hold on
plot(t,results(:,2))
ylabel('plot')
xlabel('time')
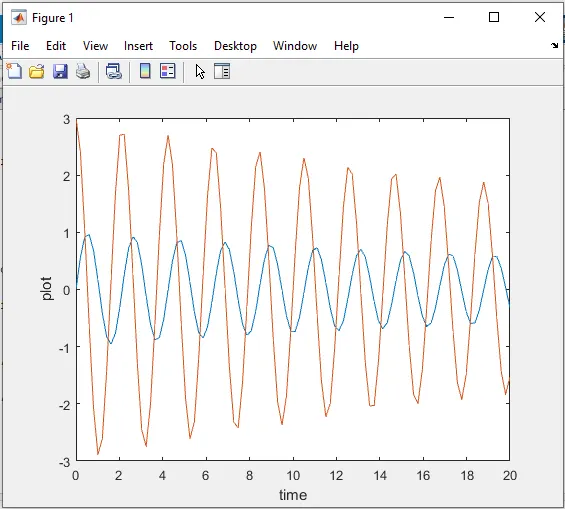
The given link is the YouTube video https://youtu.be/W4bQE_I1YBk
Ode_func is a command written to solve various differential equations :
function [dtheta_dt] = ode_func(t,theta,b,g,l,m)

theta1 = theta(1)
theta2 = theta(2)
dtheta1_dt = theta2;
dtheta2_dt = -(b/m)*theta2 - (g/l)*sin(theta1);
dtheta_dt = [dtheta1_dt ; dtheta2_dt];

end
As shown above we have successfully solved the Second Order Diffrential Equation by the given parameters.