Week 3 - Solving second order ODEs
Week 3 - Solving second order ODEs
OBJECTIVE :-
- To write a program in python to simulate the transient behavior of a Simple pendulum.
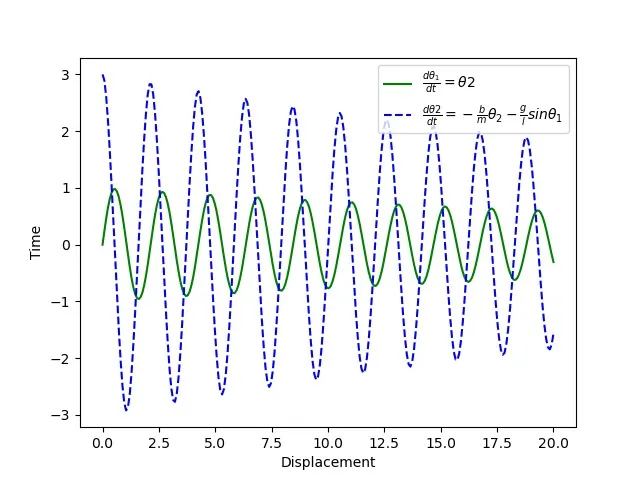
- To plot graph Time vs Displacement.
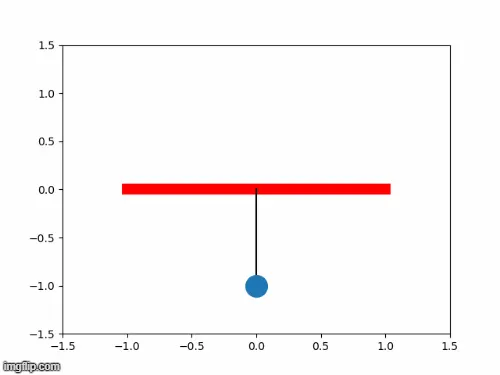
- To create an animation of its motion.
THEORY :-
The pendulum could be a simple system that follows a equation. The pendulum is initially at rest in a very vertical position. When the pendulum is displaced by an angle 0 and released, the force of gravity pulls it back towards its resting position.
A pendulum could be a weight suspended from a pivot so it can swing freely. When a pendulum is displaced sideways from its resting, equilibrium position, it's subject to a restoring force thanks to gravity that may accelerate it back toward the equilibrium position. When released, the restoring force functioning on the pendulum's mass causes it to oscillate about the equilibrium position, swinging back and forth. The time for one complete cycle, a left swing and a right swing, is termed the amount. the amount depends on the length of the pendulum and also to a small degree on the amplitude, the width of the pendulum's swing.
GOVERNING EQUATION
Second order differential equation for simple pendulum is
Where,
g=gravity (
l=Length of the pendulum (m)
m=mass of the ball (kg)
b=damping coefficient
INPUT VALUES
g=9.81
l=1 m
b=0.05 m
m=1 kg
PROCEDURE
- Initially we are going to import the “matplotlib.pyplot” , “math” , “scipy” and “numpy” library for the calculations.
- Scipy library provides us a equation of the second order ODE to solve the theta value.
- Then just input the given parameters are g, b, l and m to calculate the other parameters.
- Using the calling function command we are going to call theta values.
- And then using “numpy” command we provide the steps in the time.
- Then plot the Time against Displacement graph.
- For the motion of simple pendulum, first mention the co-ordinates of the pendulum at the start(x0, y0) and end(x1, y1).
- Using the string and counter command we’ll give different png names and save all the png files.
- For the Animation we use some other software to create the animation.
PROGRAM
#second order ODE

import matplotlib.pyplot as plt
import math
from scipy.integrate import odeint
import numpy as np

# calling function
def model(theta,t,b,g,l,m):
	theta1=theta[0]
	theta2=theta[1]
	dtheta1_dt=theta2
	dtheta2_dt=-(b/m)*theta2-(g/l)*math.sin(theta1)
	dtheta_dt=[dtheta1_dt,dtheta2_dt]
	return dtheta_dt

#input parameters
b=0.05
g=9.81
l=1
m=1

#intial condition
theta_0=[0,3]  #angular displacement abd angular velcity

#time point
t=np.linspace(0,20,250)   #0 to 20 sec motion

#Solve ODE
theta=odeint(model,theta_0,t,args=(b,g,l,m))

#point results
plt.plot(t,theta[:,0],'g-', label=r'$\frac{d\theta_1}{dt}=\theta2$')
plt.plot(t,theta[:,1],'b--', label=r'$\frac{d\theta2}{dt}=-\frac{b}{m}\theta_2-\frac{g}{l}sin\theta_1$')
plt.xlabel('Displacement')
plt.ylabel('Time')
plt.legend(loc='best')
plt.show()

#Animation of Simple pendulum


x0=0    #this is fixed point at the wall
y0=0

ct=1
for ang in theta[:,0]:  #angle

	x1=l*math.sin(ang)
	y1=-l*math.cos(ang)

	filename=str(ct)+'.png'
	ct=ct+1

	plt.figure()
	plt.plot([-1,1],[0,0],'red',linewidth=10)
	plt.plot([x0,x1],[y0,y1],'black')
	plt.plot(x1,y1,'o',markersize=20)
	plt.xlim(-1.5,1.5)
	plt.ylim(-1.5,1.5)
	plt.savefig(filename)
RESULTS
Plot
Animation Video
Simulate the motion between 0-20 sec, for angular displacement=0,angular velocity=3 rad/sec at time t=0.
CONCLUSION
- Simulation of transient behavior of a Simple pendulum motion by solving second order differential equation.
- Animation of the Simple pendulum is simulated.