Week 3 - Solving second order ODEs
AIM;
To solve the 2nd order ode equation, with the help of matlab program. To find out the a simple pendulam motion.
OBJECTS;
ODE45, which is inbuilt matlab solver. A simple pendulam motion move forward and reversee.
It contains,
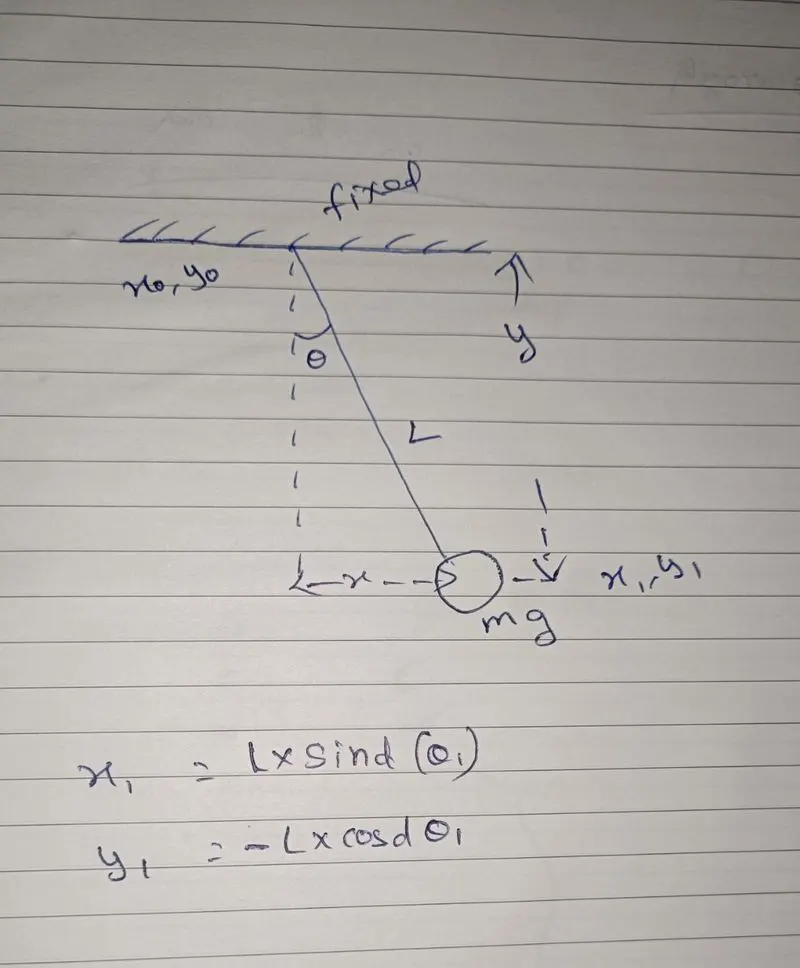
L = length of spring, m
G = gravity,
M = mass, kg
B = damping coefficient,
d^2θ/dt^2 + b/m*dθ/dt +g/lsinθ=0
θ=θ1.
transfering to, dθ/dt = dθ1/dt = θ2. -------------------- 1
d^2θ/dt^2 = d^2θ1/dt^2 = d/dt(dθ1/dt) = θ2--2
Now we go to orginal equation,
d^2θ/dt^2 + b/m*dθ/dt +g/l*sinθ=0
d^2θ1/dt^2 + b/m*dθ1/dt +g/l*sinθ1=0
dθ2/dt + b/m*dθ2 +g/l*sinθ=0
dθ2/dt = + b/m*θ2 + g/l*sinθ
Then, we create 2 ode
1------------- dθ1/dt = θ2
2---------------dθ2/dt = - b/m*θ2 - g/l*sinθ
we will brak the equation for matric formation,
d/dt(θ1 θ2), = (θ2 - b/m*θ2 - g/l*sinθ)
we will go to program,
clear all
close all
clc

% inputs
b=0.05
g=9.81 m/s^2
l=1 m
m=0.1 kg

% intial time for pendulam position
theta = [0;5] angular displacement, velocity

% time
t_span = linspace(0,20,500) time for intial condition 0 to 20 sec for 500 value.

we enter the ode equ
[t,results] = ode45(@(t,theta) ode_func(t,theta,b,g,l,m),t_span,theta)
ode45 inbuilt solver.
 we find the ode_func

function code

function [dtheta_dt] = ode_func(t,theta,b,g,l,m)
theta1=theta(1)
theta2=theta(2)
dtheta1-dt=theta2
dtheta2_dt=-(b/m)*theta2-(g/l)*sin(theta1)

then we make the plot for 2 outputs
figure(1)
plot(t,results(:,1),'linewidth',3,'color','r')
hold on
plot(t,results(:,2),'linewidth',3,'color','b')
grid on
xlabel('time')
ylabel('plot')
titile('angular displacement vs velocity')
lengend('displacement', 'velocity')
we got output for this function.
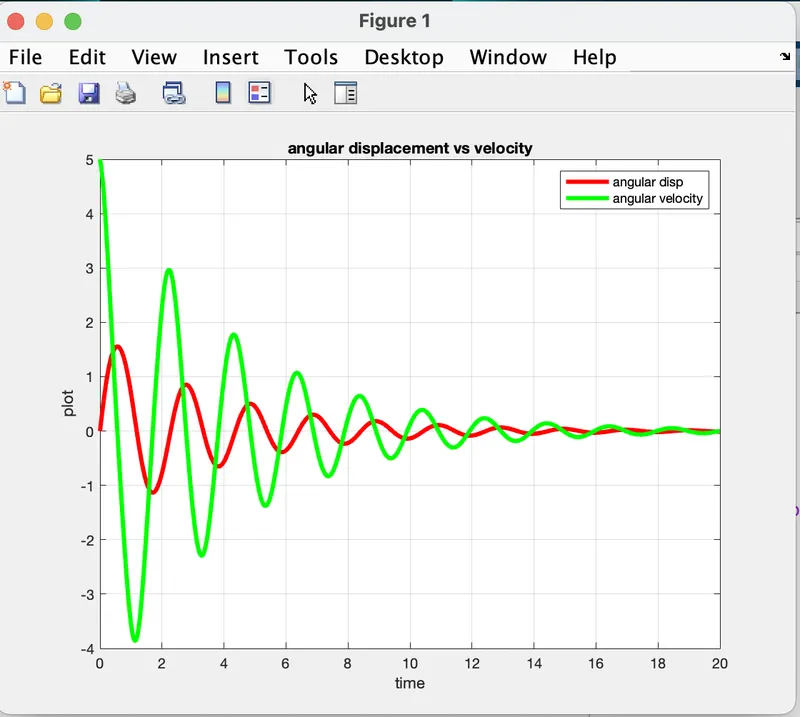
now, we define the pendulam movement,
x=results(:,2)
ct=1
use for loop for find the theta value.
for i=1:length(x)
theta1=results(i)
% coordinates intial stage of pendulam x0=0, y0=0
x1=lsind(theta1)
y1=-lcosd(theta1) we use nagative value this direction,
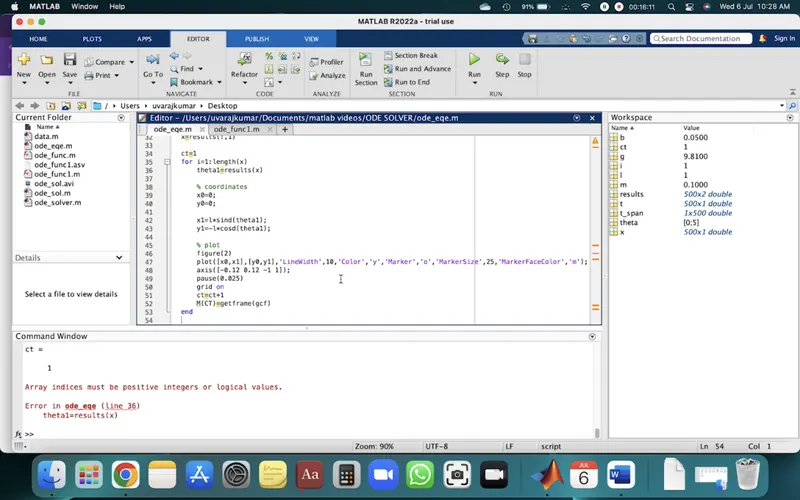
this error theta1=results(x) wroung inputs enter,
theta1=results(i) correct value
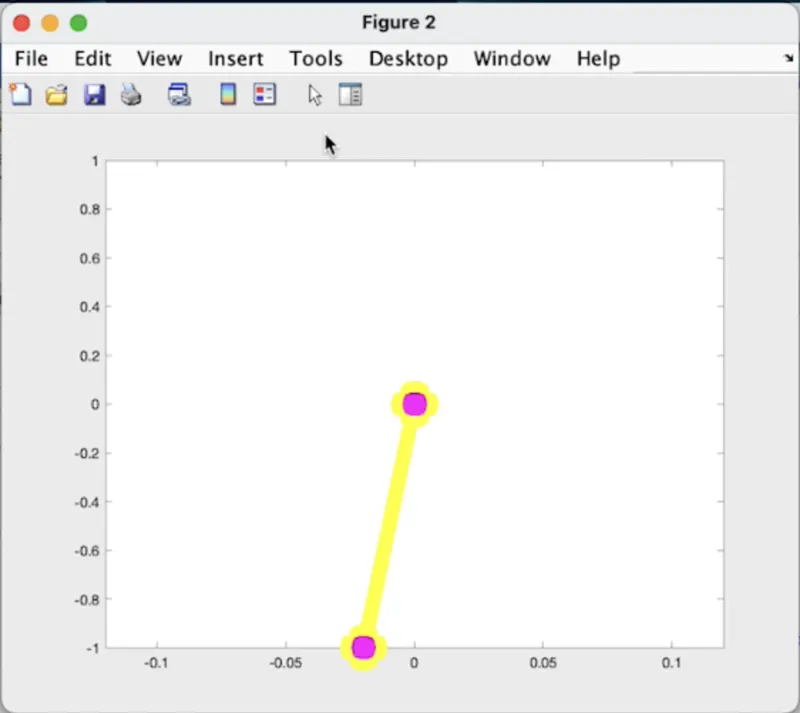
we make the plot and animation for pendulam
plot([x0,x1],[y0,y1],'linewidth',10,'color','b','marker','o',markersize',25,'markerfacecolor','m')
we correct the axis value axis([-.12 .12 -1 1[)
pause(0.025)
ct=ct+1
M(ct)=getframe(gcf)
end
% create animation and save the movie
movie(M)
videofile=writevideo('ode_equ', 'uncompressed.avi')
open(videofile)
writevideo(videofile,M)
close(videofile)
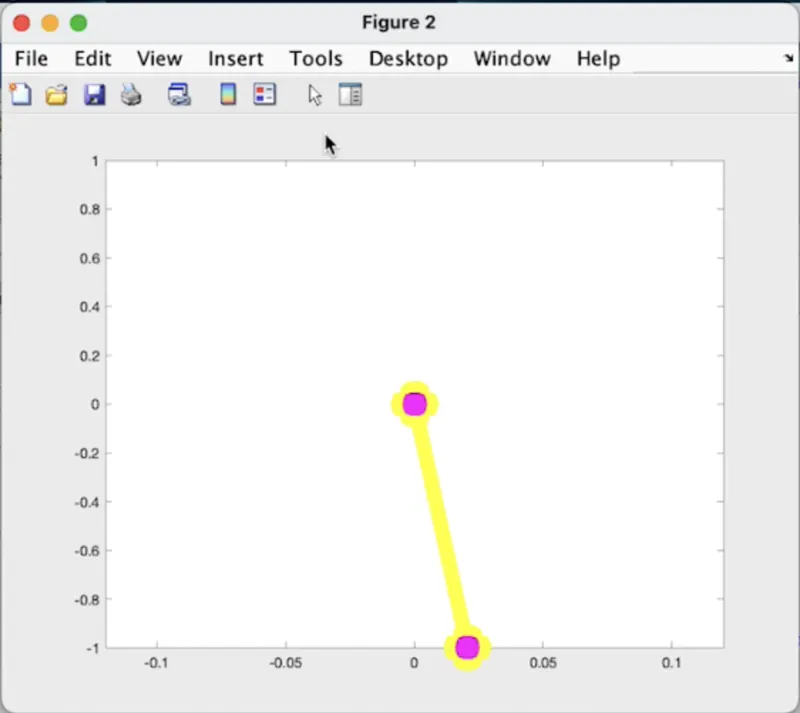
https://drive.google.com/file/d/122KQmpZl8eSRRmdkP-JUl5D7XGA9zAKA/view?usp=sharing
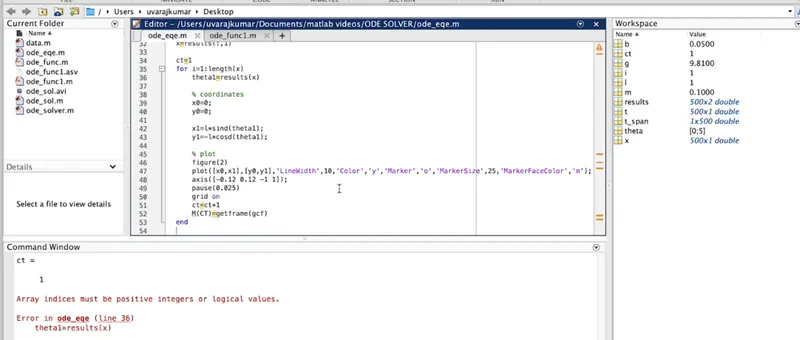
error line no 51 and 52 interchaged.
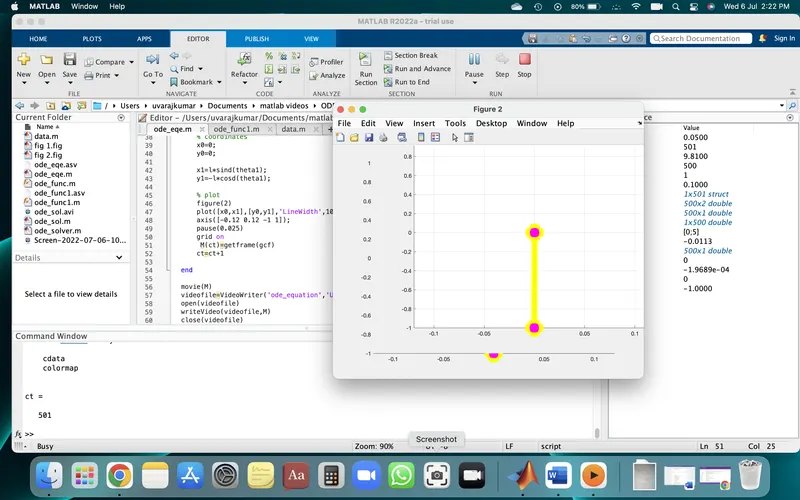
this is correct.
animation video