Week 3 - Solving second order ODEs
-Code to solve the ODE, the ODE to represent the motion of simple Pendulum.
clear all
close all
clc

%inputs

b=0.05;
g=9.81;
l=1;
m=1;

%initial condition
theta_0=[0;3];

%time point
t_span= linspace (0,20,400);
%solve ODE
[t,results]= ode45(@(t,theta) ode_func(t,theta,b,g,l,m), t_span, theta_0);

plot(results(:,1),results(:,2))
hold on
xlabel('plot')
ylabel('time')

ct=1
for i=1:length(results(:,1))

x0= 0
y0= 0

x1= l*sind(results(i,1));
y1= -1*cosd(results(i,1));


%plotting

plot([1 1],[0 0])
hold on
line([x0 x1],[y0 y1],'LineWidth',3)
hold on
%marker is imported to create shape
plot(x1,y1,'o','markers',25,'MarkerFaceColor','r');

axis([-0.2 0.2 -1.5 0.5])


pause(0.003)
hold off
M(ct)=getframe(gcf);
ct=ct+1;

end

movie(M)
videofile = VideoWriter("second_order_ode.m","Uncompressed AVI");
open(videofile)
writeVideo(videofile,M)
close(videofile)
-Function def (dtheta_dt call up):
function[dtheta_dt]=ode_func(t,theta,b,g,l,m)

theta1=theta(1)
theta2=theta(2)

dtheta1_dt=theta2;
dtheta2_dt= -(b/m)*theta2-(g/l)*sin(theta1);

dtheta_dt=[dtheta1_dt; dtheta2_dt];

end
-Explanation of code
%input
-inputs are Damping coeff, mass, gravity and length
%initial condition
-considering theta1 and theta2 as(0 and 5)
%time
-considering time span of 0-20 (with 500 splitup)
%ODE equ
-general ODE equation end up with (t and results)
-this has the function call array
-in the function it has the values if theta 1 and theta 2
-were the dtheta1_dt which represents the equation
d/dt [theta1 ; theta2]
-where the dtheta2_dt which represent the equation
[theta2 ; -(b/m)theta2 - g/l sintheta]
-then t_span and theta_0 are the time points and initial condition in ODE equation
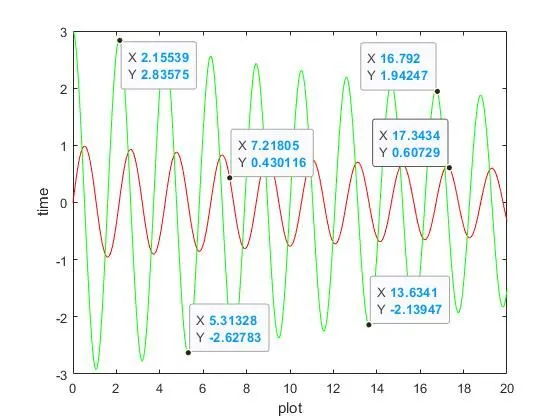
now the displacement velocity graph is plotted with respective to time.
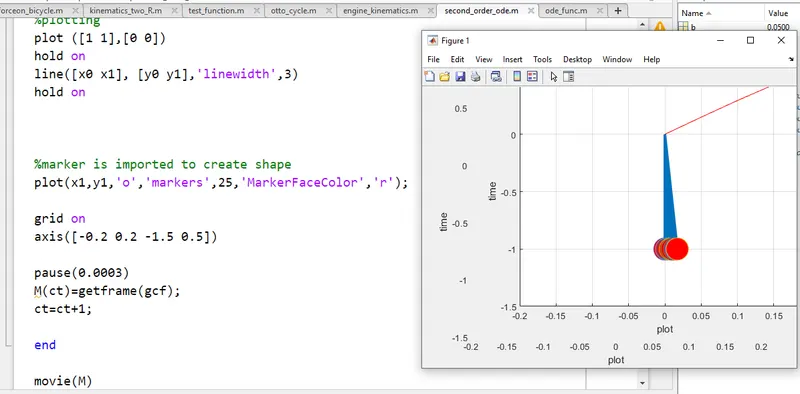
-then the for loop condition is started for increament with new x1 and y1 values with respective to arm length and angle.
-For plotting the axis with range are choosen
-and the maker command is used to create the pendulum ball with string.
- finally the movie is saved as avi file.
Errors faced
-Forget to use Hold on command
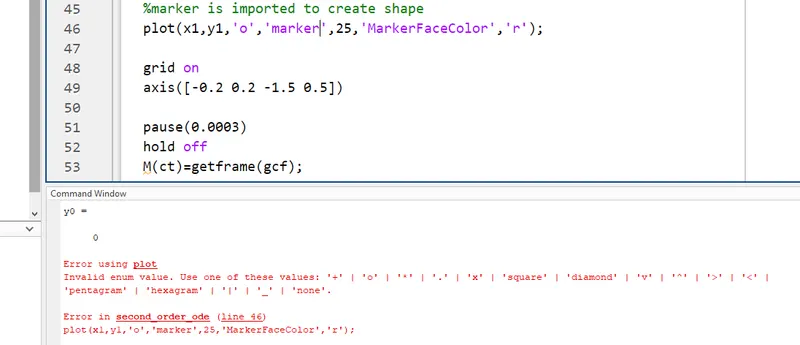
-i have mentioned marker command wrong
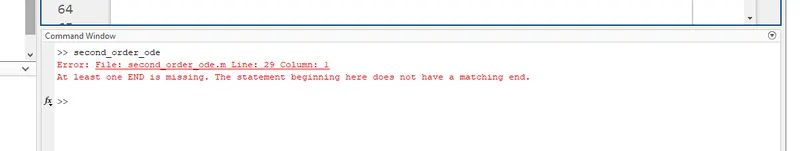
-Forget to close the for loop