Week 3 - Solving second order ODEs
AIM - To solve second order ODE to simulate the transient motion of a simple pendullum and create animation file.
MATLAB CODE-
clear all
close all
clc

b = 0.05;  % damping coefficient
g = 9.81;  % gravity in m/s^2
l = 1;     % length of the pendullum in 'm'
m = 1;     % mass of the ball in kg's

%inputs
theta_a = [0;5];

%% TIME SPAN
t_span = linspace(0,20,500);

[t,results] = ode45(@(t,theta)ode_fun(t,theta,b,g,l,m),t_span, theta_a);

%plot
figure(1)
plot(t,results(:,1))
hold on ;
plot(t,results(:,2))
legend('time vs Displacement','time vs velocity')
xlabel('Plot')
ylabel('Time')


%% CODE FOR ANIMATION AND VIDEO FILE

ct=1;
for i = 1: length(t)
x0 = 0;
y0 = 0;
THETA = results(i,1);
x1 = l*sind(THETA);
y1 = -(l*cosd(THETA));
figure(2)

plot([x0 x1],[y0 y1]);
hold on
plot(x1,y1,'marker','.','markersize',40)
line([-0.1 0.1],[0,0],'linewidth',2,'color','k')
hold off
axis([-0.2 0.2 -1.5 0.2 ])
 pause(0.03)
 M(ct)= getframe(gcf);
  ct = ct+1;

end

movie(M)
videofile = VideoWriter('simple_pendullum')
open(videofile)
writeVideo(videofile,M)
close(videofile)
STEP BY STEP PROCEDURE-
- To solve the second order ode we have to break it to first order ode.
- The first order ODE's are dtheta1_dt and dtheta2_dt
- Assign them to the solution vector.
- Here we are using ODE45 solver to solve the ode function.
- [t,results] = ode45(@(t,theta)ode_fun(t,theta,b,g,l,m),t_span, theta_a)
here t_span = [t0 tf] integrates the system of differential equations y' = f(t,y) from t0 to tf
- ode_func is a fuction created damping coefficient , length of pendullum, gravity and mass of the ball and also breaking second order function to first order code also carried out in this function.
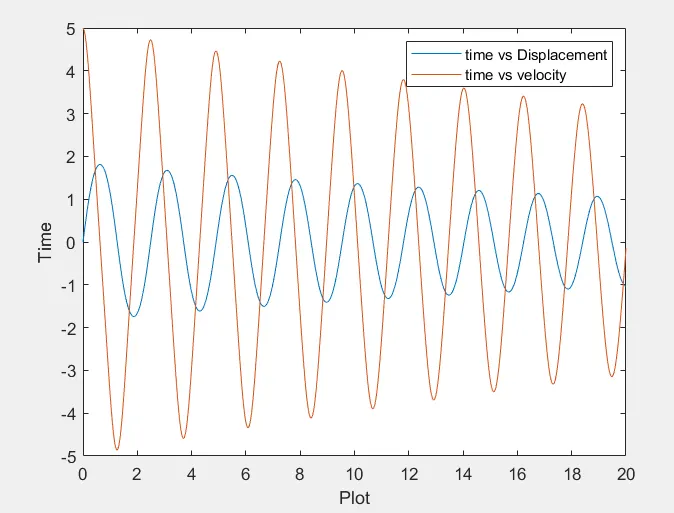
- Then plot the results theta1 and theta2 against t the we will get the plot of displacement vs time and velocity vs time.
- fix x0 and y0 as (0,0).
- From basic trignometric formulae we get x1 and y1 values.
- Vary x1 and y1 values with respect to theta
- Use marker command to create the ball.
- finally create the movie accordingly.
FUNCTION-
function [dtheta_dt] = ode_fun(t,theta,b,g,l,m)
theta1 = theta(1);
theta2 = theta(2);
dtheta1_dt = theta2;
dtheta2_dt = -(b/m)*theta2 - (g/l)*sin(theta1);
dtheta_dt = [dtheta1_dt ; dtheta2_dt ];
end
PLOT -
Plot for time vs displacement and time vs velocity
YOUTUBE LINK- (Animation video file)
ERRORS FACED -
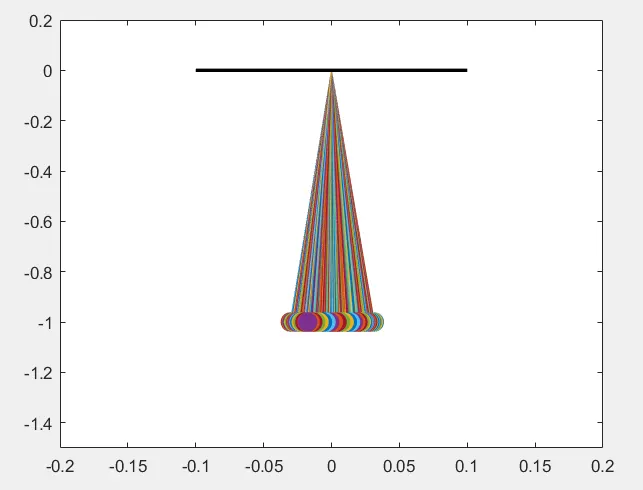
- fixed this error using hold off command.
RESULT -
By excecuting above code we can able to solve second order ODE.