Week - 2 - Explicit and Implicit Analysis
AIM
To study about implicit and explicit method to solve engineering problems.
OBJECTIVES
To demonstrated in the PDF, F(u) = u3+9u2+4u use this equation and solve using both Explicit and Implicit Methods with tolerance of 10-2.
Explicit: As opposed to Implicit methods, explicit method is a function of time. Being a function of time, the velocity and acceleration as well as the mass and damping need to be considered in this scheme. In an explicit method, Central Difference time integration (CDTI) is used to calculate field variables at respective nodal points. Since only a numerical solution is possible for a non linear ordinary differential equation, this method is particularly suited for non linear problems. It requires the inversion of the lumped mass matrix as opposed to that of the global stiffness matrix in the implicit methods. In the CDTI, the equation of motion is evaluated at the previous time step (tn-1, where tn is the current timestep).
The explicit method or algorithm works in timestep increments i.e. the displacements are calculated as the time proceeds. Consider the simulation of a crash analysis. At timestep 1 (t=0 ms), there is no deformation since the impact is yet to occur. Gradually as time would progresses the deformation also would change. Assume that at timestep 2, t is 5 ms, now the explicit algorithm will calculate the values of field variables at time when t=5 ms. This is the way in which the solution proceeds.
LS Dyna is one software which is based on explicit dynamics and is especially used for solving problems such as Crash, Impact, Penetration etc. Pam crash and Abaqus explicit are also based on the same.
Implicit: In an implicit scheme, the displacement is not a function of time (i.e. x = constant). Hence the velocities and accelerations which are time derivatives of displacement turn out to be zero and the mass and damping factors can be neglected. The implicit method can be based based on Newark’s method, Newton Raphson Method etc. In order to solve an FEM problem using implicit method, inversion of stiffness matrix (k) is required. Very Large deformation problems such as crash analysis can result in millions of degrees of freedom effectively increasing the size of stiffness matrix. Larger the stiffness matrix longer is the computational time required for its inversion. Hence there is a need for an explicit method which would prevent the inversion of stiffness matrix. Implicit methods are mainly used in softwares such as Ansys, Nastran, Abaqus etc.
IMPLICIT METHOD VS EXPLICIT METHOD
|
|
IMPLICIT METHOD |
EXPLICIT METHOD |
|
Deformation |
small |
Large |
|
What cause large deformation |
Force and dynamic |
Velocity, acceleration with mass and inertia |
|
K matrix inversion |
yes |
No |
|
Time step size |
Large |
Small |
|
What limits the time step |
Accuracy |
Stability |
|
Cost per time step |
large |
Small |
|
What dominate the cost |
Matrix inversion |
Element process |
|
Parallel process |
Possible |
Not possible |
PROBLEM
The variables used are u for displacement, f for internal force in the bar, F for external force applied to the bar and k for stiffness. Incremental displacements or incremental externally applied forces are represented as ∆u or ∆F, respectively. Use is made of the relationship ∆F = k∆u.
Explicit method
F(u) = u3+9u2+4u (1)
K(u) = dF/du = 3u2 +18u + 4 (2)
Step1
Take u = 0 in (2)
(2) => k(u0) = 3 x 02 + 18 x 0 + 4 = 4
= /k(u0) = ¼ = 0.25
u1= u0+ = 0.25
Fint = (0.25)3 + 9 x (0.25)2 +4 x 0.25 = 1.578
Step2
Take u1 = 0.25 in (2)
(2) => k(u1) = 3 x 0.252 + 18 x 0.25 + 4 = 8.6875
= /k(u1) = 1/8.6875 = 0.1151
U2= u1+ = 0.3651
Fint = (0.3651)3 + 9 x (0.3651)2 +4 x 0.3651 = 2.708
Step3
Take u2 = 0.3651 in (2)
(2) => k(u2) = 3 x 0.36512 + 18 x 0.3651 + 4 = 10.9716
= /k(u2) = 1/10.9716 = 0.09114
U3= u2+ = 0.46
To determine whether the analysis is equilibrium
Fext = = 3
Fint = (0.46)3 + 9 x (0.46)2 +4 x 0.46 = 3.841
Hence Fext fint the analysis is not equilibrium
Table 1: Summary of explicit analysis results
|
Step i |
∆Fi |
∆ui |
ui |
(Fext)i |
(fint)i |
fint − Fext = R |
|
1 |
1 |
0.25 |
0.25 |
1 |
1.578 |
0.578 |
|
2 |
1 |
0.1151 |
0.3654 |
2 |
2.708 |
0.708 |
|
3 |
1 |
0.09114 |
0.46 |
3 |
3.841 |
0.841 |
Implicit method
F(u) = u3+9u2+4u (1)
K(u) = dF/du = 3u2 +18u + 4 (2)
Step1
Take u = 0 in (2)
(2) => k(u0) = 3 x 02 + 18 x 0 + 4 = 4
= /k(u0) = ¼ = 0.25
u1= u0+ = 0.25
Residual R
Fint = (0.25)3 + 9 x (0.25)2 +4 x 0.25 = 1.578
R0 = 1.578 – 1 = 0.578 > 102
So, Newton-Raphson iterations is necessary
The correction u1 = u1(0)
u(1) = -[k(u1(0)-1 x R0
= -[(3 x 0.252 ) + (18 x 0.250) +4]-1 x 0.578
=-0.0665
U1(1) = u1(0) + u(1)
= 0.25 – 0.0665 = 0.1835
Residual R1
Fint = (0.1835)3 + 9 x (0.1835)2 +4 x 0.1835 = 1.0432
R0 = 1.0432 – 1 = 0.432 > 102
So, Newton-Raphson iterations is necessary
The correction u1 = u1(1)
u(2) = u(2) -[k(u1(1)-1 x R1
=(-0.0665) -(8.6875 -1 )x 0.0432
=-0.0714
U1(2) = u1(1) + u(2)
= 0.25 – 0.0714 = 0.1786
Residual R1
Fint = (0.1786)3 + 9 x (0.1786)2 +4 x 0.1786 = 1.0071
R0 = 1.0071 – 1 = 0.0071 < 102
No residual needed
U1 = 0.1786
Similarly we drived u2 = 2966, u3 = 0.3911
Table 1: Summary of explicit analysis results
|
Step i |
∆Fi |
∆ui |
ui |
(Fext)i |
(fint)i |
fint − Fext = R |
|
1 |
1 |
0.25 |
0.1786 |
1 |
1.0071 |
0.0071 |
|
2 |
1 |
0.1374 |
0.2966 |
2 |
2.0042 |
0.0042 |
|
3 |
1 |
0.1041 |
0.3911 |
3 |
3.008 |
0.008 |
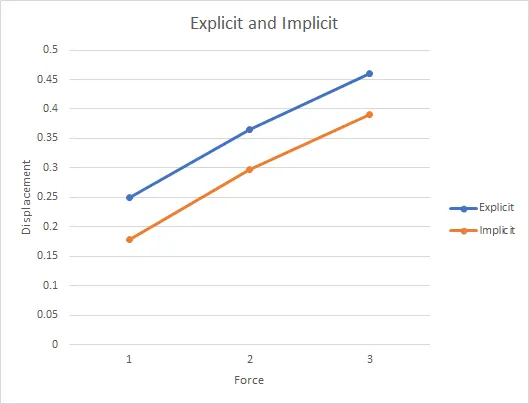
CONCLUSION
Explicit and implicit analysis is done for the given equation, implicit method is more accurate than the explicit but the time consumption is more in implicit method.