Challenge

Week 2- 2R Robotic Arm Challenge
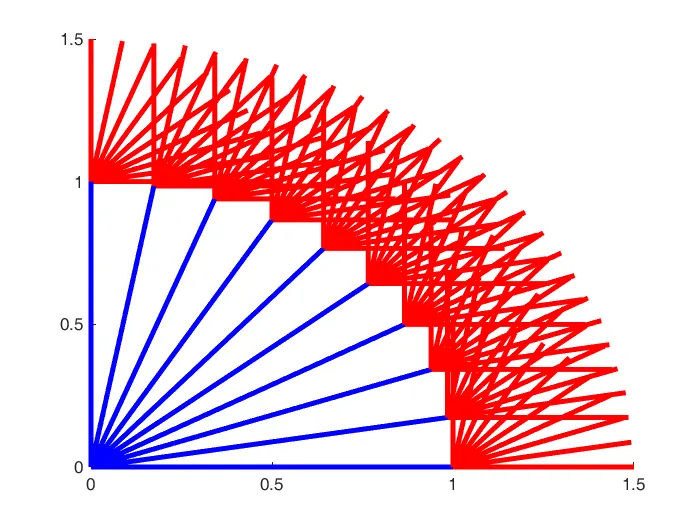
clear all close all clc %inputs theta1=linspace(0,90,10); theta2=linspace(0,90,10); l1=1; l2=0.5; ct=1; for i=1:length(theta1) THETA1=theta1(i); for j=1:length(theta2) THETA2=theta2(j); x0=0; y0=0; x1=l1*cosd(THETA1); y1=l1*sind(THETA1); x2=x1+l2*cosd(THETA2); y2=y1+l2*sind(THETA2); %plotting plot([x0 x1],[y0 y1],[x1 x2],[y1 y2],'linewidth',3) axis([-0.1 1.5 0 1.5]) pause(0.03) M(ct)=getframe(gcf); ct=ct+1; end end movie(M) videofile = VideoWriter('f_animation.avi','uncompressed AVI'); open(videofile) writeVideo(videofile,M) close(videofile)

#youtube video# A LINK OF MY YOUTUBE CHANNEL KINDLY SEE AND LIKE, SHEAR, SUBSCRIBE AND COMMENTS THANK YOU.

https://youtu.be/07EfpgWbGo4

clear all
close all
clc

%inputs
theta1=linspace(0,90,10);
theta2=linspace(0,90,10);
l1=1;
l2=0.5;

ct=1;
for i=1:length(theta1)
    THETA1=theta1(i);
    for j=1:length(theta2)
        THETA2=theta2(j);
        x0=0;
        y0=0;

        x1=l1*cosd(THETA1);
        y1=l1*sind(THETA1);
        x2=x1+l2*cosd(THETA2);
        y2=y1+l2*sind(THETA2);

        %plotting
        
        plot([x0 x1],[y0 y1],[x1 x2],[y1 y2],'linewidth',3)
        axis([-0.1 1.5 0 1.5])
        pause(0.03)
        M(ct)=getframe(gcf);
        ct=ct+1;
    end
end

movie(M)
videofile = VideoWriter('f_animation.avi','uncompressed AVI');
open(videofile)
writeVideo(videofile,M)
close(videofile)
Your portfolio, next

Ship work like this
in your own course.

Talk to a career counsellor

Free 20-minute call. We'll map the right course to where you want to work.

By submitting you agree to our Terms and Privacy Policy.

Talk to a career counsellor

Free 20-minute call. We'll map the right course to where you want to work.

By submitting you agree to our Terms and Privacy Policy.