Week 2- 2R Robotic Arm Challenge
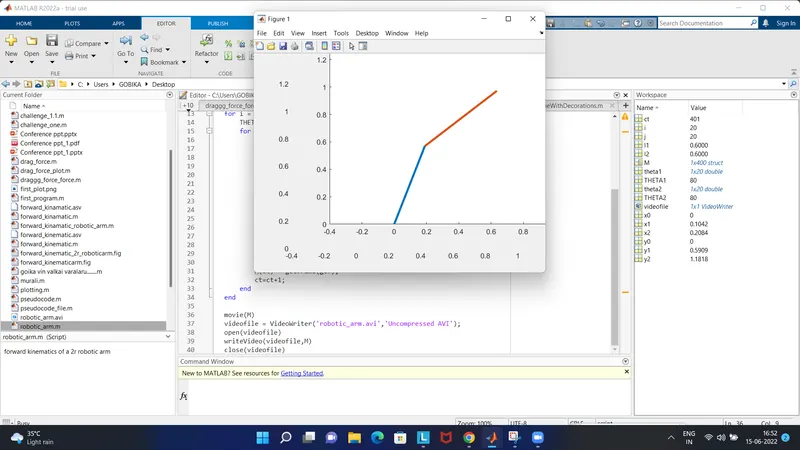
% Forward kinematics Of 2R Robotic Arm Manipulator
clear all
close all
clc

% Inputs
l1 = 0.6;
l2 = 0.6;
theta1 = linspace(0,80,20);
theta2 = linspace(0,80,20);

ct=1;
for i = 1:length(theta1)
    THETA1 = theta1(i);
    for j = 1:length(theta2)
        THETA2 = theta2(j);
        x0 = 0;
        y0 = 0;

        x1 = l1*cosd(THETA1);
        y1 = l1*sind(THETA1);

        x2 = x1 + l2*cosd(THETA2);
        y2 = y1 + l2*sind(THETA2);

        %plotting

        plot([x0 x1],[y0 y1],[x1 x2],[y1 y2],'linewidth',3)
        axis([-0.4 1 0 1.3])
        pause(0.03)
        M(ct) = getframe(gcf);
        ct=ct+1;
    end
end

movie(M)
videofile = VideoWriter('robotic_arm.avi','Uncompressed AVI');
open(videofile)
writeVideo(videofile,M)
close(videofile)
Google drive link:
https://drive.google.com/file/d/1LI5WOb1pcGNxWZ59oKVCDkty-XP8dUWu/view?usp=sharing