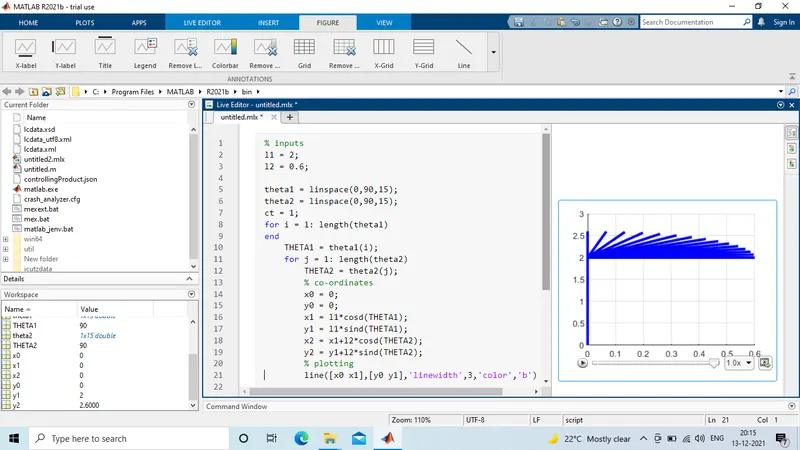
Week 2- 2R Robotic Arm Challenge
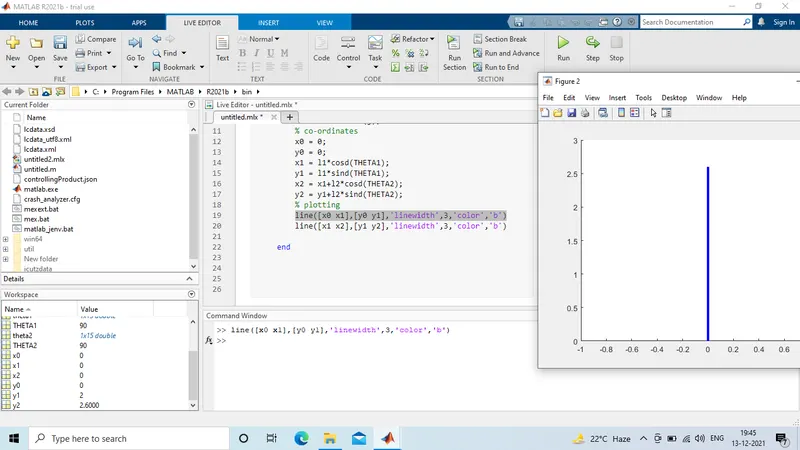
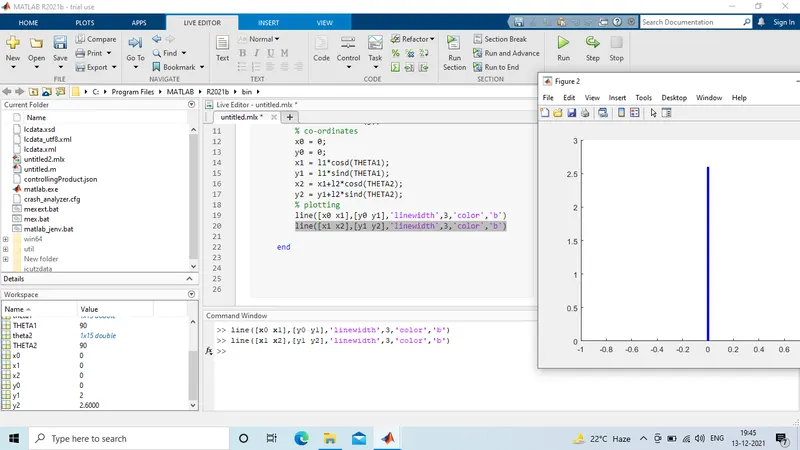
theta1 and theta2 are the final position
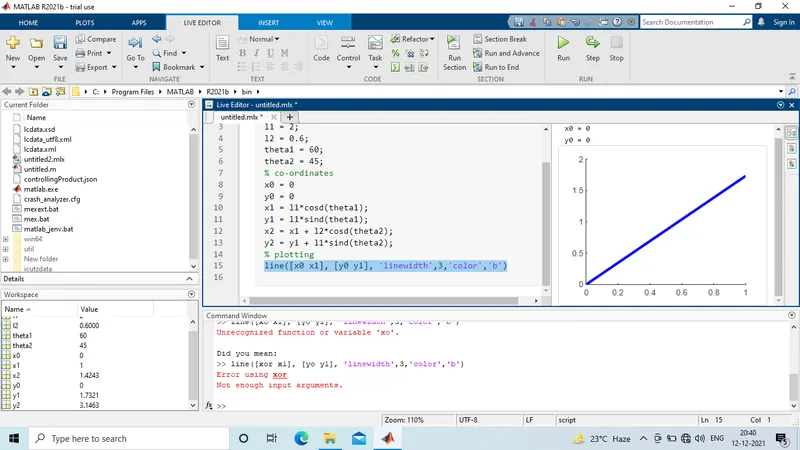
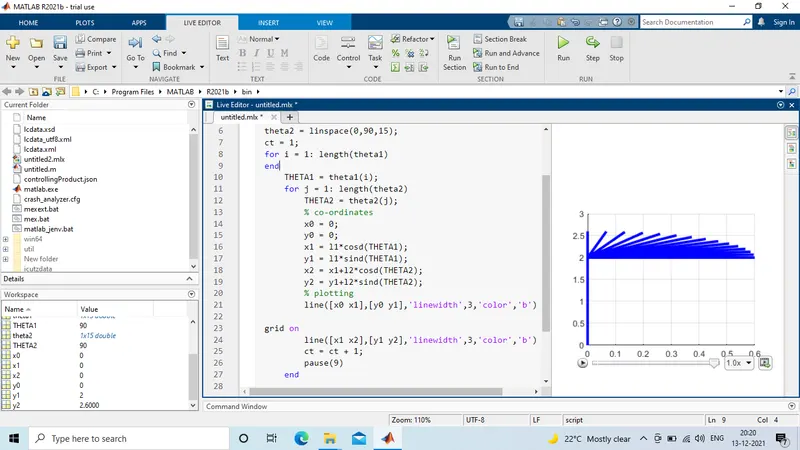
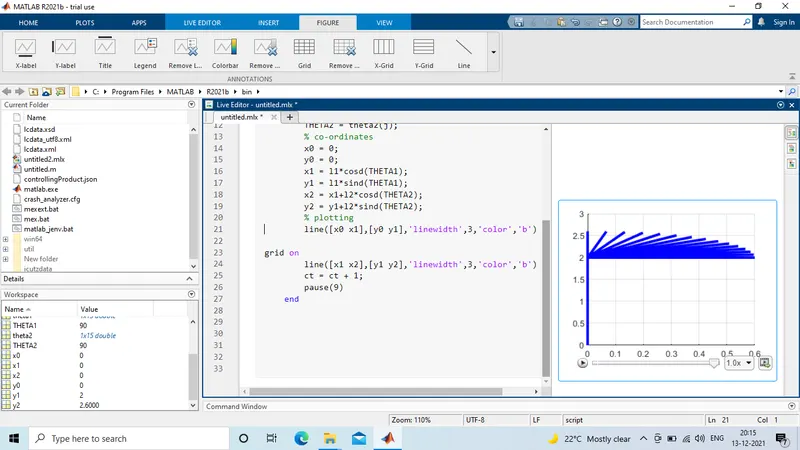
step:1 calculate the position of link1
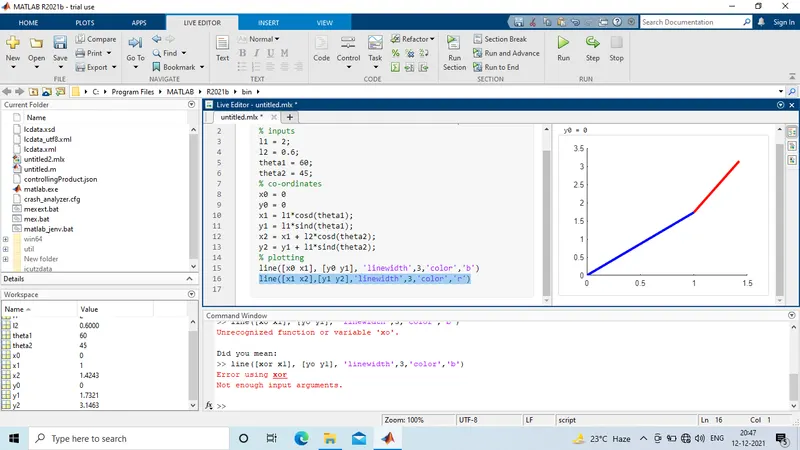
step2: calculate the position of link 2
x2 = x1 + l2cos (theta2)
y2 = y1 + l2sin(theta2)
solution at: [x0 y0],[x1,y1], [x2,y2]
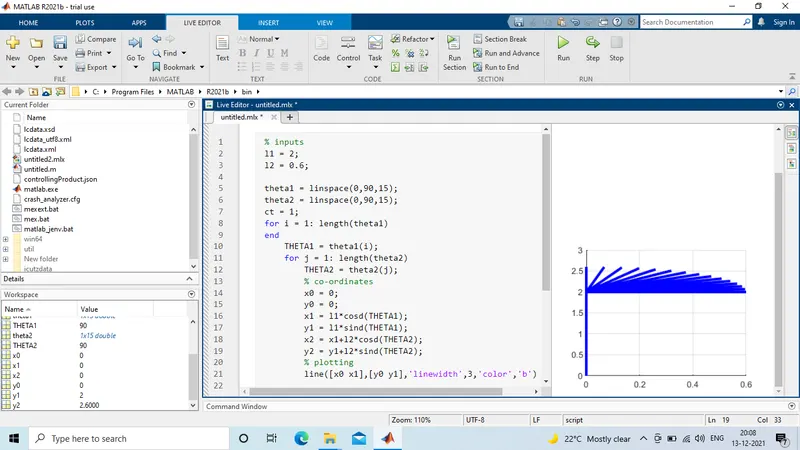
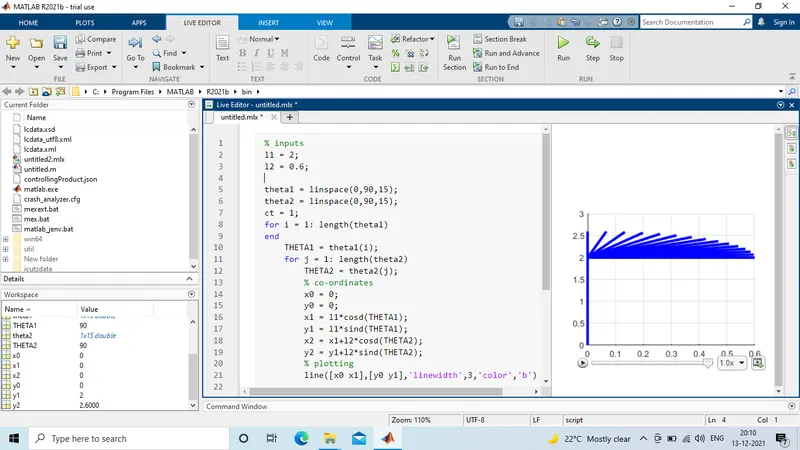
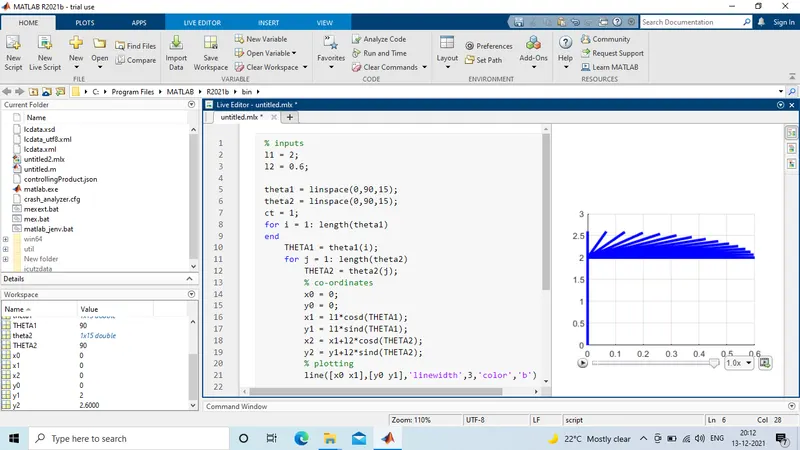
forward kinematic of a 2r robotic arm manipulator
% inputs
l1 = 2;
l2 = 0.6;