Week 2- 2R Robotic Arm Challenge
FORWARD KINEMATICS 2 ARM ROBOT.
Kinematicsis the relationships between the positions, velocities and accelerations of the links of a manipulator. the forward kinematics is when the kinematical data are known for the joint coordinates.the forward kinematics problem invoves finding the end tip position of a manipulator in a coordinate space given its joint parameters.A robot's kinematic structure is described by a set of links,which for most purpose are considered to be rigid bodies and joints connecting them and constraining their relative movement.
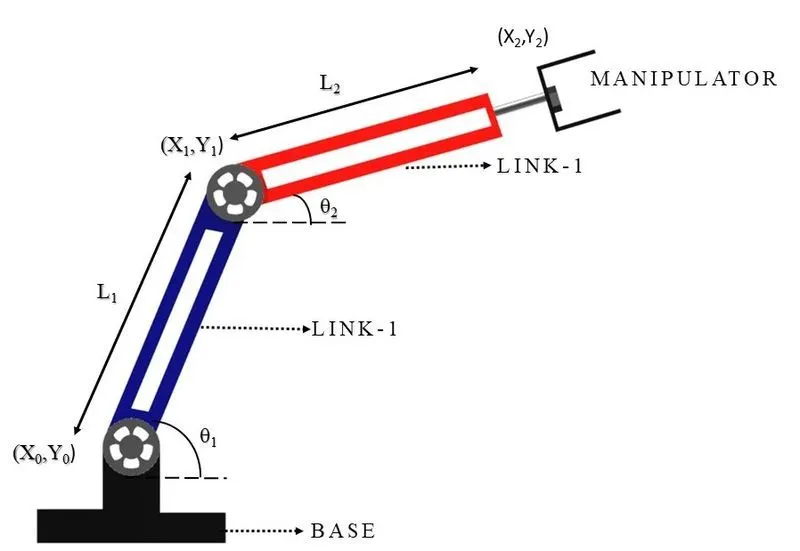
The above structure describres the Two arm roobot, with base coordinate (x0,y0) and length of link1.End point of link1 has coordinate (x1,y1) which also acts as starting point coordinate for link2 of length l2. Assume link1 makes angle theta1 wtr to base X axis & link2 makes an angle theta2 wtr to base X axis.
%input
l1=1;
l2=0.5;
theta1=linspace(0,90,10);
theta2=linspace(0,90,10);
ct=1;
for i=1:length(theta1)
    THETA1=theta1(i);

    for j=1:length(theta2)
        THETA2=theta2(j);

        x0=0;
        y0=0;

        x1=l1*cosd(THETA1);
        y1=l1*sind(THETA1);

        x2=x1+l2*cosd(THETA2);
        y2=y1+l2*sind(THETA2);


        %plotting
        plot([x0 x1],[y0 y1],[x1 x2],[y1 y2],'linewidth',3,'color','r');
        axis([-0.1 1.5 0 1.5])
        pause(0.11)
        M(ct)=getframe(gcf);
        ct=ct+1;
    end
end
movie(M)
videofile=VideoWriter('kinematics.avi')
open(videofile)
writeVideo(videofile,M)
close(videofile)
Error faced while coding
1. unrecognized property linwidth for class line
error in
plot([x0,x1],y0,y1],[x1,x2],[y1,y2],'linwidth',3,'color','b');
=error removed by