Week 2- 2R Robotic Arm Challenge
% to simulate the forward kinematics of a 2R Robotic Arm
% to create an animation file of the plot (.avi)

% initiating the length and angle for the robotic arm

l1 = 1;
l2 = 0.5;
theta_1 = linspace(0,90,10);
theta_2 = linspace(0,90,10);
ct = 1; % frame counter
% to cover the whole workspace, we need 2 'for loops'

for i = 1:length(theta_1)
    th1 = theta_1(i);
    for j = 1:length(theta_2)
        th2 = theta_2(j);
        x0 = 0;
        y0 = 0;
        x1 = l1*cosd(th1);
        y1 = l1*sind(th1);
        x2 = x1 + l2*cosd(th2);
        y2 = y1 + l2*sind(th2);

        %plot graphs
        plot([x0 x1],[y0 y1],[x1 x2],[y1 y2],'linewidth',3);
        axis([-0.1 1.5 0 1.5]); % fix the axis
        pause(0.03); % pause time to help in generating video
        M(ct) = getframe(gcf); % an array is made. each figure is saved here
        ct = ct + 1; % frame counter updated after each saving of frame
    end
end

% now we have all the respective images ready saved in the M(ct) array. The
% array was pre-defined for speedy operation of code.
movie(M) % we want to make a movie of M array elements or frames
videofile = VideoWriter('roboticarmmovie.avi', 'Uncompressed AVI'); % name and type is specified
open(videofile) % fiel is opened
writeVideo(videofile, M) % all the frames are written
close(videofile) % file is closed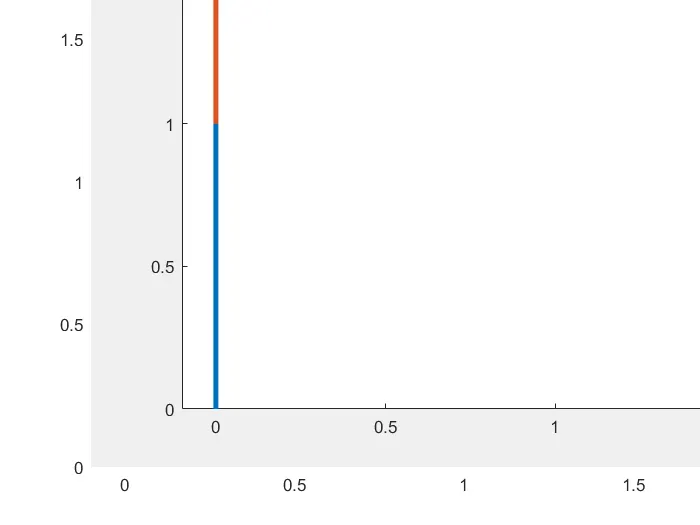
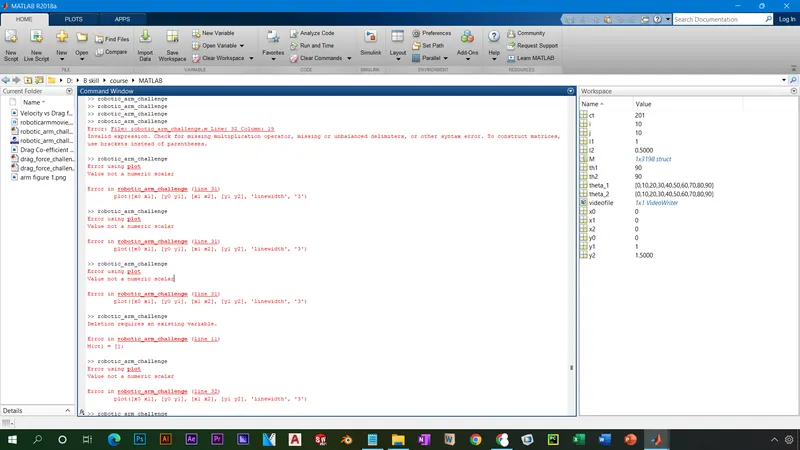
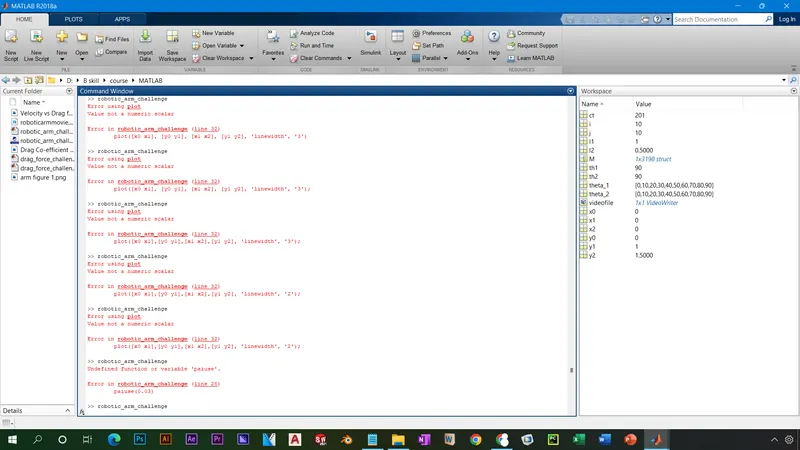
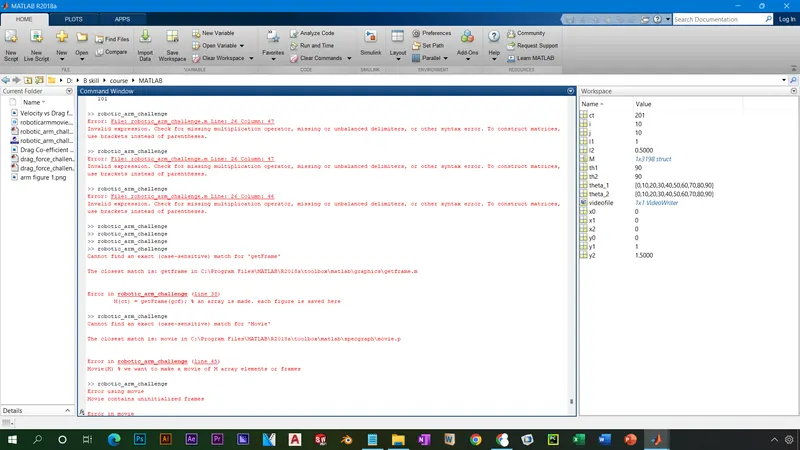
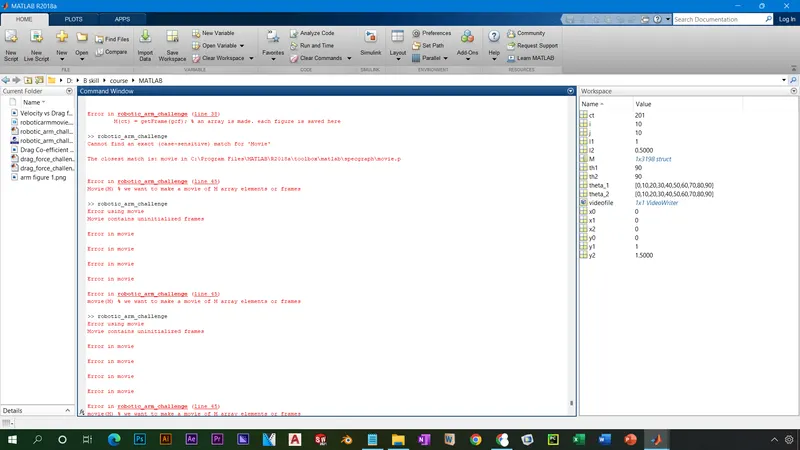
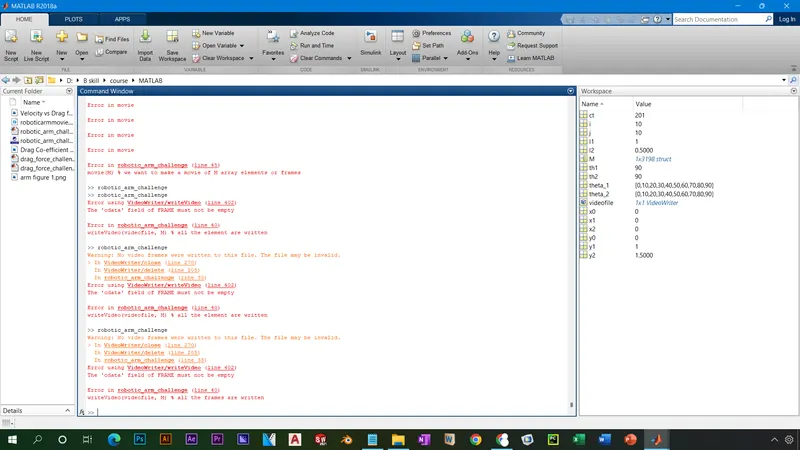
errors:
struct to double error - solved after restart
using plot command (value not a numeric scalar)- typo error
typo error - movie(m), getframe(gcf)
animation stuck for theta values more than 20, so 10 values considered.
uninitialised frames - restart matlab to solve the problem