Week 2- 2R Robotic Arm Challenge
2-R Robotic Arm Challenge :
Aim : Write a program in Matlab to simulate the forward kinematics of a 2R Robotic Arm.
Theory :
Kinematics :
Kinematics of machines deals with the study of the relative motion of machine parts. It involves the study of position, displacement, velocity and acceleration of machine parts. Dynamics of machines involves the study of forces acting on the machine parts and the motions resulting from these forces.
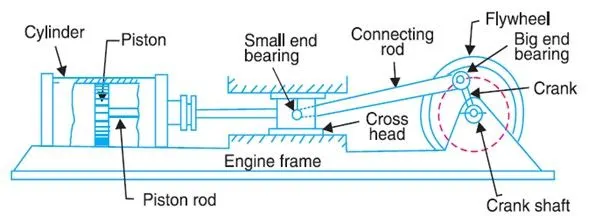
above Fig shows the better example of kinematic relative motion.
close all
clear all
clc

%inputs

l1=1;
l2=0.5;

theta1=linspace(0,90,10);
theta2=linspace(0,90,10);
ct=1;
for i = 1:length(theta1)
    THETA1=theta1(i);
    for j = 1:length(theta2)
        THETA2=theta2(j);
    x0=0;
    y0=0;

    x1=l1*cosd(THETA1);
    y1=l1*sind(THETA1);

    x2=x1+ l2*cosd(THETA2);
    y2=y1+l2*sind(THETA2);

    %plotting

    plot([x0,x1],[y0,y1],[x1,x2],[y1,y2],'linewidth',3)
    axis([-0.2 1.7 -0.2 1.7])

    pause(0.03)
    M(ct)=getframe(gcf)
    ct=ct+1;

    end
end
movie(M)
file=VideoWriter('robot.avi')
open(file)
writeVideo(file,M)
close(file)
Code Explaination:
define the link lengths as l1 and l2.
create array for different angles.
use for loop
You Tube link : https://youtu.be/y0yUV2AYMdI