Week 2- 2R Robotic Arm Challenge
% program for forward kinematics of robotic arm
clear all
close all
clc

% input

% length of first link l1
l1=1;

% length of second link l2
l2=0.5;
theta1=linspace(0,90,10);
theta2=linspace(0,90,40);
ct=1;

for i=1:length(theta1);
THETA1=theta1(i);
for j=1:length(theta2);
THETA2=theta2(j);


% coordinates

x0=0;
y0=0;

x1=l1*cosd(THETA1);
y1=l1*sind(THETA1);

x2=x1+l2*cosd(THETA2);
y2=y1+l2*sind(THETA2);

%plotting

plot([x0 x1], [y0 y1], [x1 x2], [y1 y2], 'linewidth',3)
axis([-0.1 1.5 0 1.5])


% cinematic view

M(ct)=getframe(gcf);
ct=ct+1;
end
end

movie(M)
videofile=VideoWriter('forward_kinematics.avi','Uncompressed AVI')
open(videofile)
writeVideo(videofile,M)
close(videofile)
Link for animation
Explanation
First, we input the length of two links. Then angle with each link is inserted using 'linspace' command. Coordinated are inputted with respective equations. Robotic arm motion is plotted using the plot command. At last cinematic view is created and saved.
Errors faced
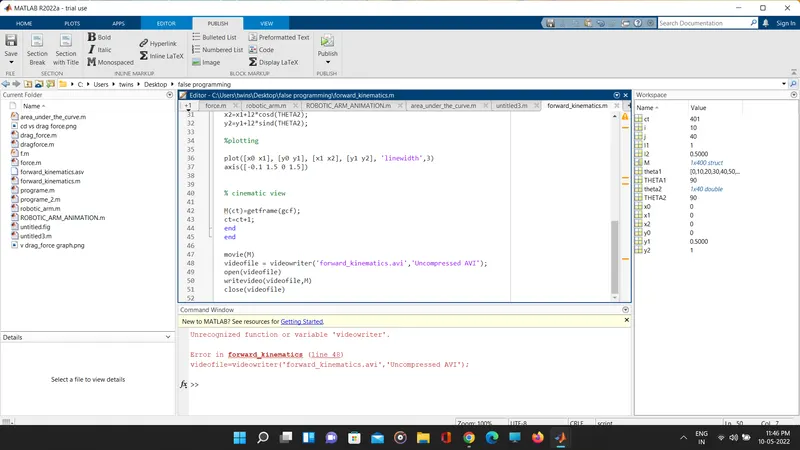
it was due to the wrong command spelling.