Week 2- 2R Robotic Arm Challenge
AIM: To write a program to simulate the forward kinematics of a 2R robotics arm in matlab
OBJECTIVE:
* To solve and simulate the forward kinematics of a 2R robotics arm and understand the movement of manipulator.
* To create the aniumation pf working of a 2R robotics arm.
INTRODUNCTION: A robotics arm is a robot manipulator,ususally programmable,with similar function to human arm.The links of the manipulator can be considered to form a kinematics chain .
*The base,which is clamped to the surface and all other link are joined throughhinge point.
*Link 1 (l1)making theta 1 with horizontal.
*Link 2 (l2) making theta 2 with horizontal.
INPUT:
x1 = l1 .cos(theta1)and y1 = l1.sin (theta1)
*similarly,the coordinates of end point of link 2 (l2)can also be found from trignometry as,x2 = x1+l2.cos(theta2)and y2 = y1+l2.sin(theta2).
MATLAB CODE:
% Forward kinematics of a 2R robotics arm manipulator and simulate it
clear all
close all
clc
% input
l1 = 1;
l2 = 0.5;
theta1 = linspace(0,90,10);
theta2 = linspace(0,90,10);
ct=1;
for i = 1: length(theta1)
THETA1 = theta1(i);
for j = 1:length(theta2)
THETA2 = theta2(j);
x0 = 0;
y0 = 0;
x1 = l1*cosd(THETA1);
y1 = l1*sind(THETA1);
x2 = x1+l2*cosd(THETA2);
y2 = y1+l2*sind(THETA2);
%plotting
plot([x0 x1],[y0 y1],[x1 x2],[y1 y2],'linewidth',3)
axis([-0.1 1.5 0 1.5])
pause(0.03)
M(ct) = getframe(gcf);
ct = ct+1;
end
end
movie(M)
videofile = VideoWriter('forward_kinematics.avi','uncompressed avi');
open(videofile)
writeVideo(videofile,M)
close(videofile)
ERROR AND REMEDIES:
*Basics types and syntax error where observed.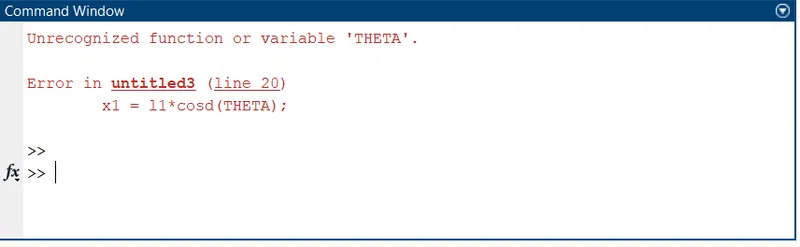
* The above error was rectified by putting *between l1and cosd(theta1)
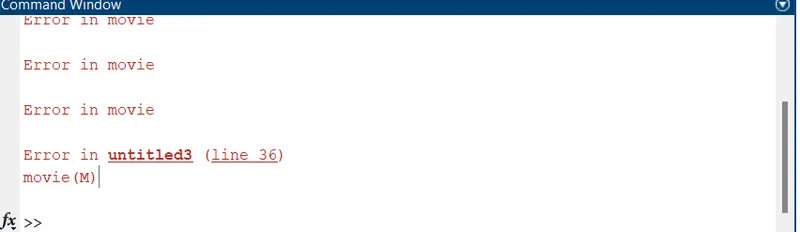
* The above error was observed because one of the loop was not movie as its syntax,so an "movie"was put at the loop.
RESULT:
* The following plot is obtained as the output:
YOUTUBE LINK :
https://youtu.be/v67jp_ZCVo8
GOOGLE DRIVE LINK :
https://drive.google.com/file/d/1e1eLXzjb8aO8qNAQB-DfCnKvCCOlsYQQ/view?usp=drivesdk