Week 2- 2R Robotic Arm Challenge
clear all
close all
clc

%program for forward kinematics of a 2R Robotic arm

%inputs
l1=10;
l2=5;
theta1=linspace(0,90,20);
theta2=linspace(0,90,20);

ct=1
for i=1:length(theta1)
THETA1=theta1(i);
for j=1:length(theta2)
    THETA2=theta2(j);

x0=0;
y0=0;

x1=l1*cosd(THETA1);
y1=l1*sind(THETA1);

x2=x1+l2*cosd(THETA2);
y2=y1+l2*sind(THETA2);

%plotting
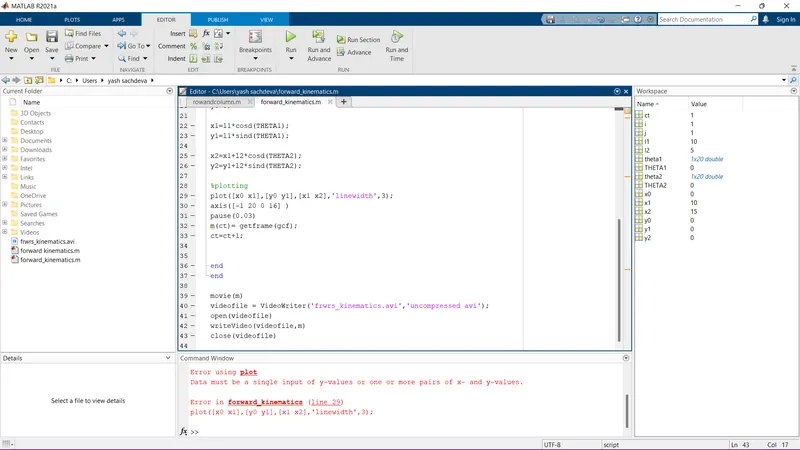
plot([x0 x1],[y0 y1],[x1 x2],[y1 y2],'linewidth',3);
axis([-1 20 0 16] )
pause(0.03)
m(ct)= getframe(gcf);
ct=ct+1;


end
end

movie(m)
videofile = VideoWriter('frwrs_kinematics.avi','uncompressed avi');
open(videofile)
writeVideo(videofile,m)
close(videofile)
ABOVE SHOWN IS THE CODE FOR PROGRAM
LINK FOR THE OUTPUT VIDEO.
https://drive.google.com/file/d/1ngqzvBw_1DgbRM6STPmLQPjjZLqBsrkt/view?usp=sharing
STEP WISE EXPLANATION
- Inputs are taken for length L1 and L2 i.e. 10 and 5 respectively.
- Theta 1 and theta 2 are taken on 20 values between 0 and 90. "linspace command"
- 'for' Loop is used multiple times one inside another to generate values, 400 figures will be generated.
- Then Mathematical relation provided, for generating the lines with respect to L1 and L2 and theta1 and theta2.
- after this, move to plotting stage. the mathematical expression is plotted.
- then for creating a movie used an array 'M' for saving all the frames.
ERROR FACED
Forget to add [y1 y2] in plot command.
Rechecked the entire code several times and then get to know the issue and then rectified.