Week 2- 2R Robotic Arm Challenge
Robotic arm challenge
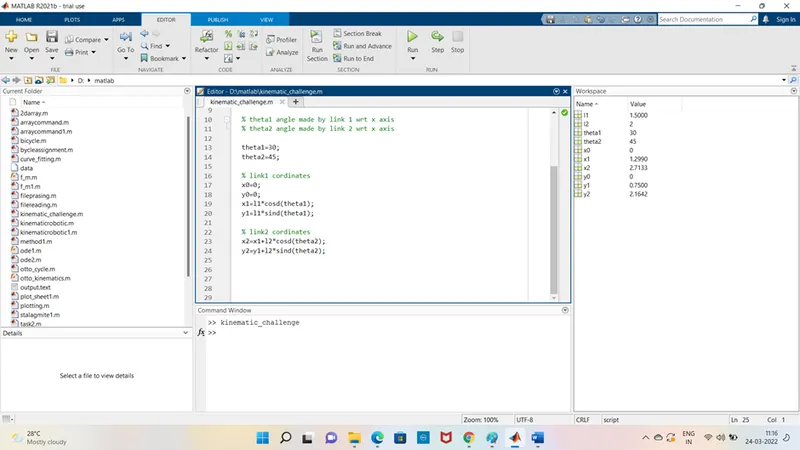
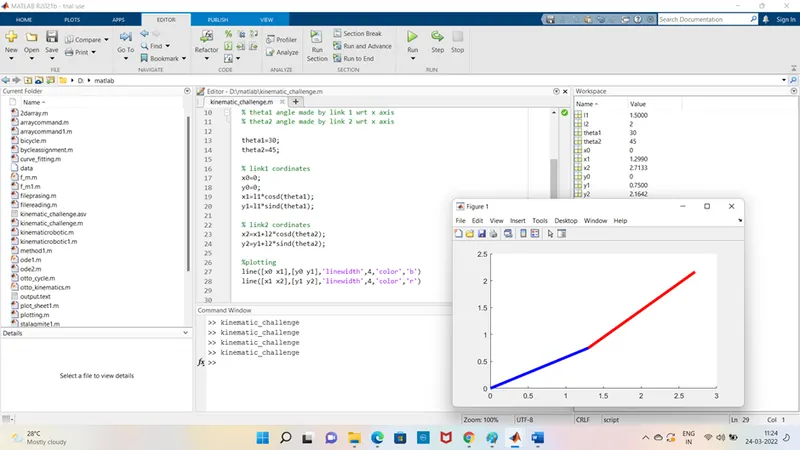
Step 1 = For fixed angles , Program for both links by defining their coordinates is executed . showned in picture 1 and picture 2.
picture1-
picture-2
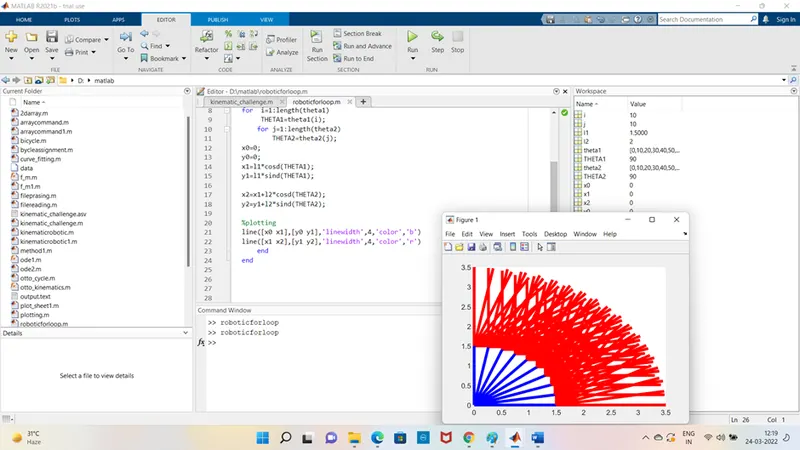
step -2 For differrent value of theta we used for loop. Program for same is mentioned in picture 3
picture-3
step3 = Program for kinematic movie.
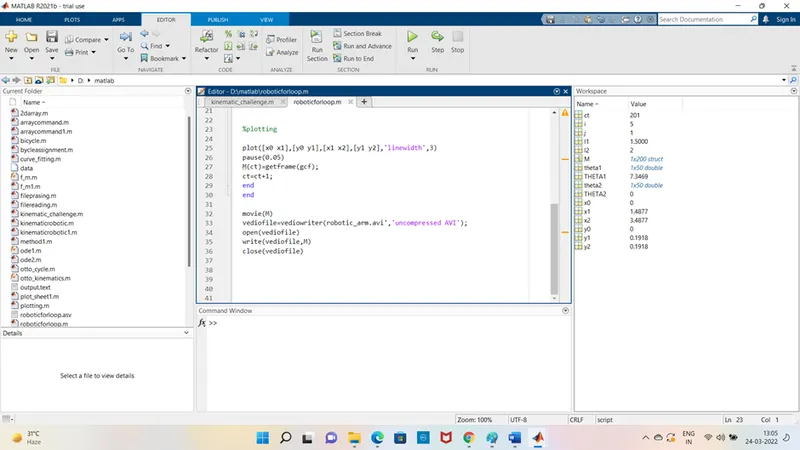
Remarks= I am not able to execute the vedio code as it was unsupported because of that link for same is not attached.