Week 2- 2R Robotic Arm Challenge
AIM : A program in Matlab to simulate the forward kinematics of a 2R Robotic Arm
Theory:
Kinematics is the study of the relationship between a robot's joint coordinates and its spatial layout, and is a fundamental and classical topic in robotics. Kinematics can yield very accurate calculations in many problems, such as positioning a gripper at a place in space, designing a mechanism that can move a tool from point A to point B, or predicting whether a robot's motion would collide with obstacles.
Objective :
The main objective behind this project is to determined the movement of manipulator on a different angles of first arm.
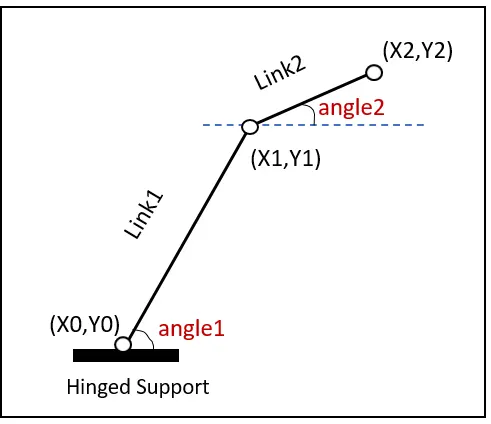
Program:
% program to simulate the forward kinematics of a 2R Robotic Arm

%lenght of first arm in m
l1 = 1;
%lenght of second arm in m
l2 = 0.5;
% angle of arms
  theta1 = linspace(0,90,20); %angle of first arm
  theta2 = linspace(0,90,20); %angle of second arm
  ct=1;
  for i = 1:length(theta1)
      THETA1 = theta1(i);
       for j = 1:length(theta2)
           THETA2 = theta2(j);

            % first end coordinate point of first arm
            x0 = 0;
            y0 = 0;
            %second end corodinate points of first arm
            x1 = l1*cosd(THETA1);
            y1 = l1*sind(THETA1);
            %cordinate points of second arm
            x2 = x1+l2*cosd(THETA2);
            y2 = y1+l2*sind(THETA2);

            % lines of 2r robotic arm

           plot ([x0 x1],[y0 y1],[x1 x2],[y1 y2],'linewidth',3)
           axis ([0, 1.5, 0,1.5])
            %animation for 2r robotic arm
            pause (0.03);
           M = getframe(gcf)
           ct = ct+1


       end
  end
movie (M)
videofile = VideoWriter('fwd_kin_challegne.AVI','uncompressed.AVI')
open (videofile)
write (videofile,M)
close (videofile)
Result:
The recorded video of the animation is attached with the report.
conclusion:
-
The kinematics of a robot relate the joint angles of a robot to the coordinate frames of its links.
-
A robot's configuration is a minimal expression of its links position, and usually consists of the robot's joint angles.
-
The animation shows the movement of the manipulators which helps to determine the different positions at which the manipulator moves.
- The animation also shows the defferent angles at which the first arm of the robot can be moved.