Week 2- 2R Robotic Arm Challenge
AIM-
program in Matlab to simulate the forward kinematics of a 2R Robotic Arm.
INTRODUCTION-
In this robotics arm like automobile ibdustries & aviation all the process like welding & painting are automatic.thies all the process are automatically done by robots.the design stage of robot need a work space i.e range which upto arm can be reach.
GOVERNING EQUATION-
We will take a simple robotic arm use two link for for the program. as per below image we have two length (l1&l2) making two angles with the horizontal axis respectively.
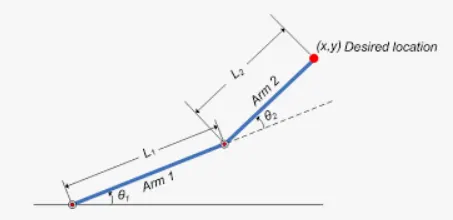
Link one is attached to the base and end of link is connected to thre other link 2 and end of link 2 is used to the which perform the disiear operation.
Equation of calculating the co ordinate of the link starting & ending point.
link1-
Starting point =[x0 ,y0]=[0,0]
Ending point=[x1,y1]=[l1cosd theta1,l1sind theta1]
link2-
Starting point =[x1 ,y1]=[l1cosd theta1,l1sind theta1]
Ending point=[x2,y2]=[x1+l2cosd theta2,y1+l2sind theta2]
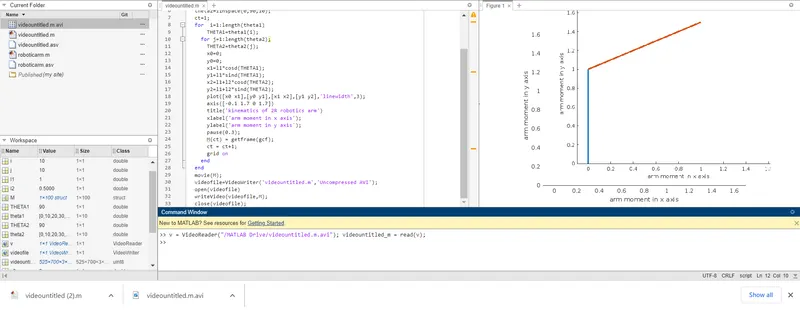
PROGRAM-
ERRORS-
Error1- I have missing the clear all at the start of program.