Week -2
Aim :
(1) Make a Simulink model of Doorbell using solenoid block with the following details
The switch block used is controlled by external physical signal.If the external signal is greater than the threshold parameter,then the switch is closed, else the switch will be in open condition.
The +ve termianl of the switch is connected to the switch & the -ve terminal is connected to the electrical reference.
The solenoid block is connected with the switch and the battery & will get a complete electrical circuit.
The port "C" is connected with mechanical reference.
The ideal translational sensor is connected with solenoid block R to pbserve the movement of the plunger.
PS Simulink converter is used to convert the physical signal to simulink signal.
Scope is connected with the ideal translational sensor to get the result / output.
Solver Configuration - Individual / Each physical network represented by a connected simscape block which requires solver setting information for simulation.
Simulink Model Briefing / Explaining
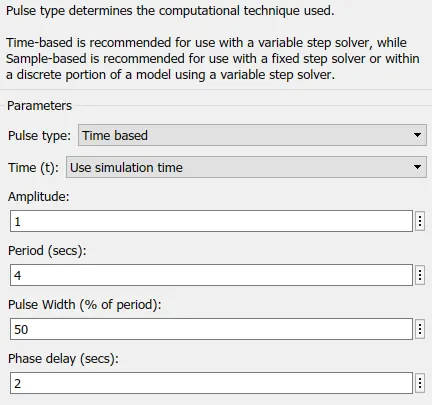
The pulse generator is used to vreate square wave pulses at regular intervals.
The block wave form parameters such as Pulse, Amplitude, width period, & phase delay determine the shape of the output waveform.
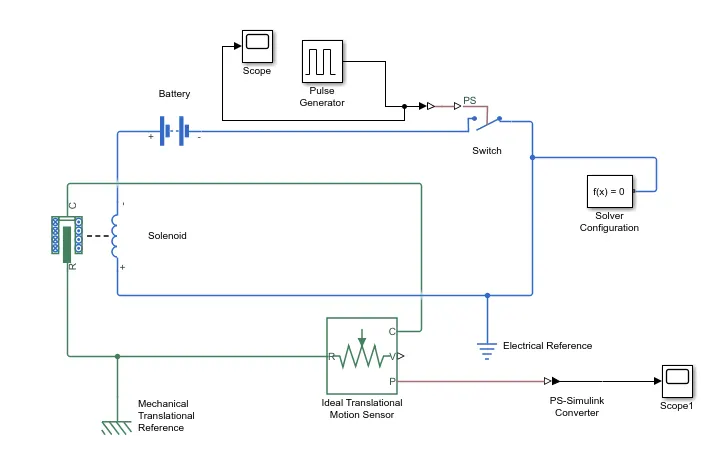
Simulink model of Doorbell using solenoid block with the following details
solenoid : This block implements the electrical and mechanical characteristics of a solenoid
The plunger Maximum stroke is implemented as a hard stop, the dynamics of which are set by the Contact stiffness and Contact damping parameters.
Battery
This block models a battery. If you select Infinite for the Battery charge capacity parameter, the block models the battery as a series internal resistance and a constant voltage source. If you select Finite for the Battery charge capacity parameter.

Pulse Generator
Pulse type determines the computational technique used.
Time-based is recommended for use with a variable step solver, while Sample-based is recommended for use with a fixed step solver or within a discrete portion of a model using a variable step solver.

PS - Simulink Converter
Physical Signal to a Simulink output signal.
The unit expression in 'Output signal unit' parameter must match or be commensurate with the unit of the Physical Signal and determines the conversion from the Physical Signal to the Simulink output signal.

Solver Configuration
Defines solver settings to use for simulation
Ideal Translational Motion Sensor
This block measures velocity or displacement in a mechanical translational network.
The sensor is ideal since it does not account for inertia, friction, delays, energy consumption, and so on.
The physical signal ports V and P report the velocity and position, respectively, of port R relative to port C. The measured velocity is positive when the velocity at port R is greater than the velocity at port C.
Electrical Reference
Electrical reference port. A model must contain at least one electrical reference port (electrical ground).

PS-Simulink Converter
Converts the input Physical Signal to a Simulink output signal.
The unit expression in 'Output signal unit' parameter must match or be commensurate with the unit of the Physical Signal and determines the conversion from the Physical Signal to the Simulink output signal.
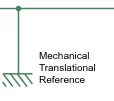
Mechanical Translational Reference
This block represents a mechanical translational reference point, that is, a frame or a ground. Use it to connect mechanical translational ports that are rigidly affixed to the frame (ground).
Final Result
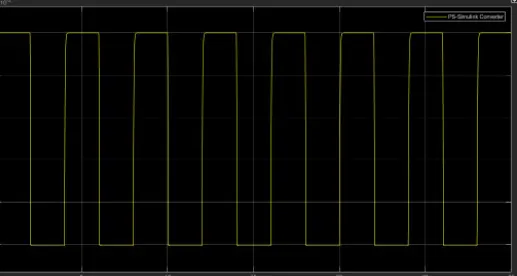
Time period given is 2 Seconds, to the pulse generator to open & close the switch,when the switch is closed, the solenoid block receives electrical power from the battery and the plunger move from the port R to C to hit the bell & produce sound.
(2) Use a thermistor to sense the temperature of a heater & turn on or turn off the fan as per below conditions
Given Data / Inputs
Temperature source: 20 °C from 0 to 10 seconds, 27 °C from 10 to 30 seconds, 23 °C from 30 to 50 seconds
Fan conditions: ON if the temperature above 25 °C, OFF otherwise
When Time = 0 seconds, then Temperature = 293K
When Time = 10 seconds, then Temperature = 293K
When Time = 10 seconds, then Temperature = 300K
When Time = 30 seconds, then Temperature = 300K
When Time = 30 seconds, then Temperature = 296K
When Time = 50 seconds, then Temperature = 296K
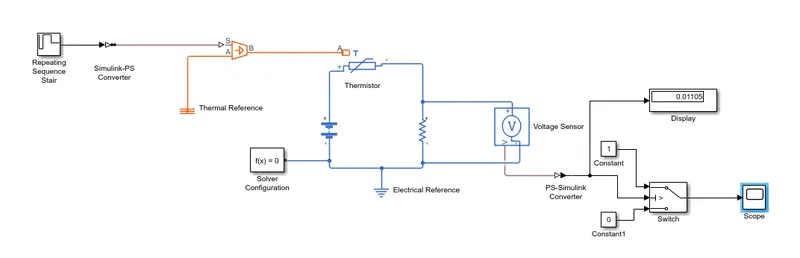
Controlled temperature source represents an ideal source of thermal energy which will maintain a controlled temperature difference regardless of the heat flow rate. The tempersture difference is set by the physical signal port S.
A positive difference temperature causes the temperature at port B to be greater than the temperature at Port A
Thermistor is a type resistor whose resistance is based on the temperature
The voltage source is used to convert the voltage measured between two points in physical signal
Voltage represents DC or AC
Elecrical block reference is mentioned
A linear resitor is used in order to control the amount of current from the battery
The solver configuration - Physical network of each network represents or connected with simscape blocks require solver setting information for simulation.
Time period is given 2 sec to the pulse generator to open & close the switch.
When the switch is closed the solenoid blocks receive electrical Power from the battery & the plunger move from Port R to C to hit the bell & sound produced.
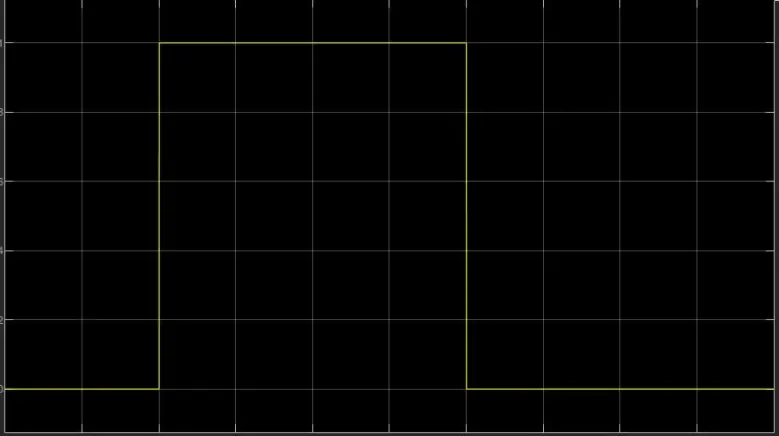
For provided data, as mentioned below
for 0 to 10 when fan is off condition because the temp is 293 ' K which is below the
threshold 298'k .
After 10 sec the temperture goes to 300'K then the switch will be ON condition,as the temperature exceeds 298 'K then
after 30 Sec fan will turn OFF as the temperature comes down to 296'k which is below the thresold temperature 298'K.
All the values are evaluated for the given task.