week-11 Joint creation and Demonstration
AIM:-
To demonstrate spherical, revolute, cylindrical, and translational joints between two rigid bodies and two deformable bodies.
THEORY:-
A distinguishing feature of multibody systems is the presence of joints that impose constraints on the relative motion of thevarious bodies of the system. Most joints used in practical applications can be modelled in terms of the so-called lower pairs likespherical, revolute, cylindrical, and translational joints.
Spherical Joint:
A spherical joint is used for allowing free rotation in two planes at the same time while preventing translation inany direction, including rotating in those planes.
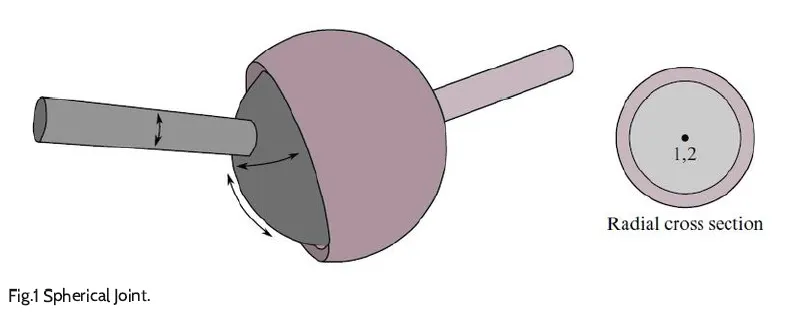
The relative motion of the rigid bodies is constrained so that nodes which are initially coincident remain coincident. In the abovefigure the socket’s node is not interior to the socket—LS-DYNA does not require that a rigid body’s nodes be interior to the body.
Revolute Joint:
A revolute joint is a one degree of freedom kinematic pair used frequently in mechanisms and machines. Thejoint constrains the motion of two bodies to pure rotation along a common axis.
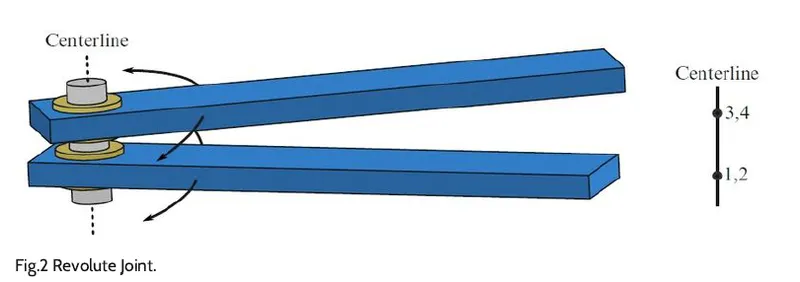
As shown in fig.2, Nodes 1 and 2 are coincident; nodes 3 and 4 are coincident. Nodes 1 and 3 belong to rigid body A; nodes 2 and4 belong to rigid body B. The relative motion of the two rigid bodies is restricted to rotations about the axis formed by the twopairs of coincident nodes. This axis is labelled the “centerline”.
Cylindrical Joint:
A cylindrical joint is a two degrees of freedom kinematic pair used in mechanisms. It provides single axis slidingfunction as well as a single axis rotation, providing a way for two rigid bodies to translate and rotate freely.
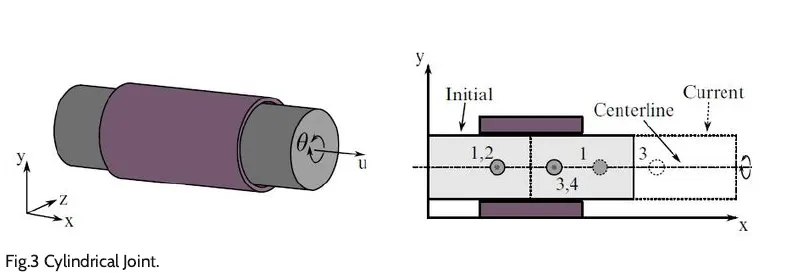
This joint is derived from the rotational joint by relaxing the constraints along the centerline. This joint admits relative rotationand translation along the centerline as shown in fig.3.
Translational Joint:
A Translational joint provides a linear sliding movement between two bodies.
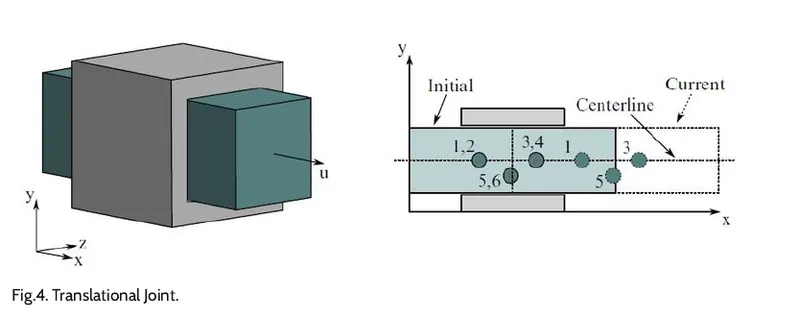
This is a cylindrical joint with a third pair of off-centerline nodes which restrict rotation. Aside from translation along thecenterline, the two rigid bodies are stuck together.
PROCEDURE :-
The different types of joints are created between two rigid bodies in LS-DYNA using keyword
*CONSTRAINED_EXTRA_NODES and between two deformable bodies using
*CONSTRAINED_NODAL_RIGID_BODY.
1) Revolute Joint for Rigid Bodies:-
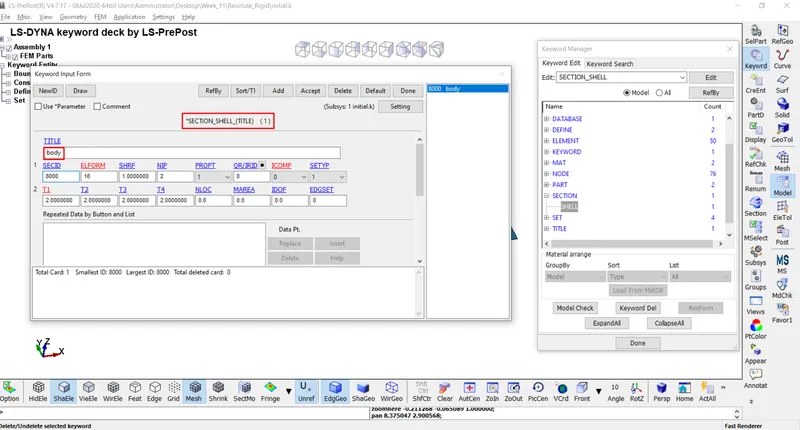
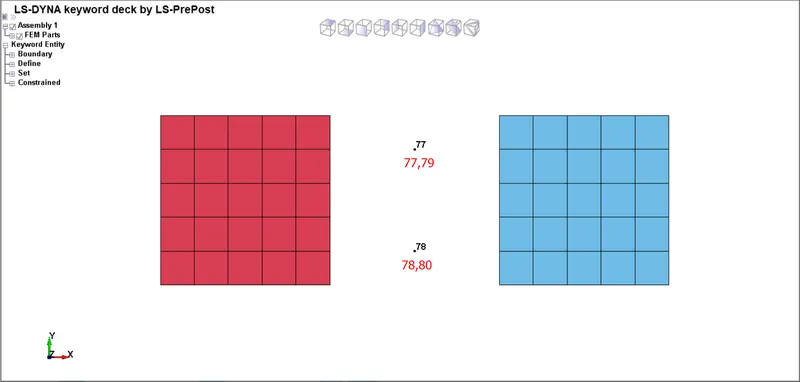
Open LS-PrePost, using options under Element and Mesh > Shape Mesher > Entity > 4N Shell, create two parts as shown in Fig., i.e red plate being part 1 and blue plate is part 2.
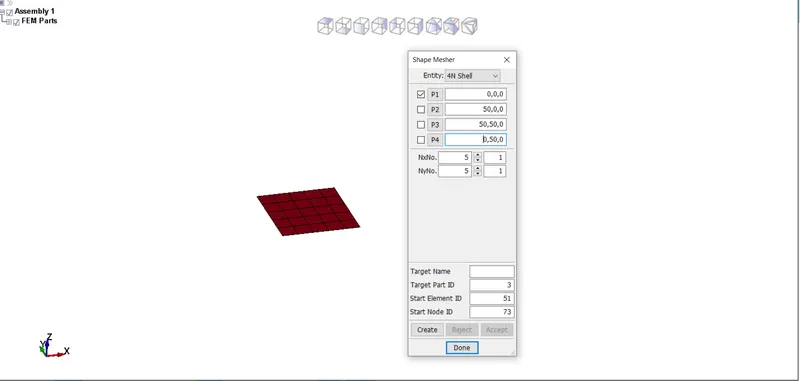
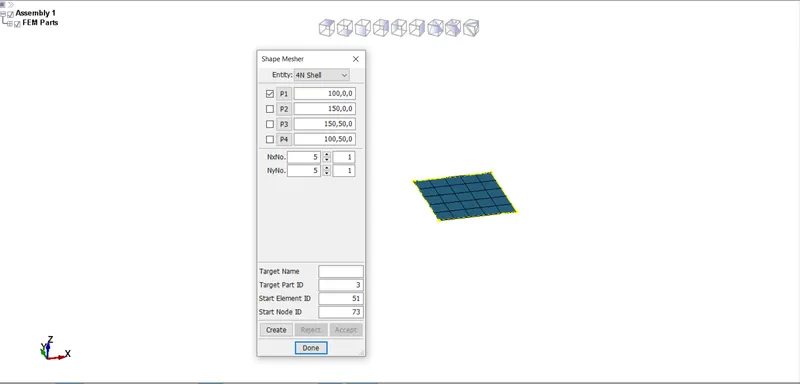
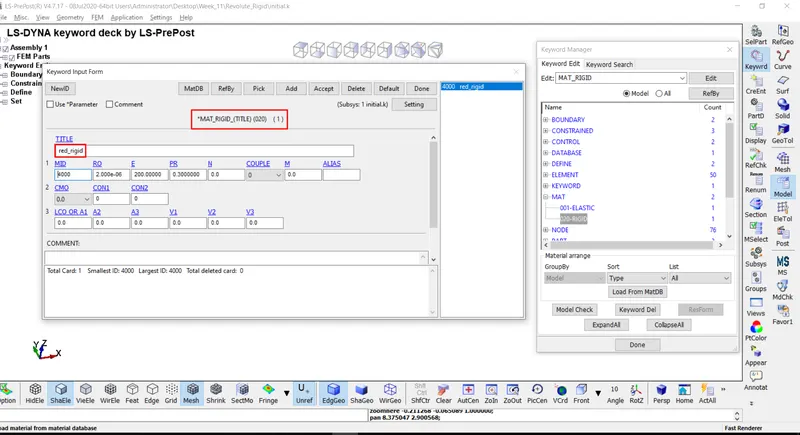
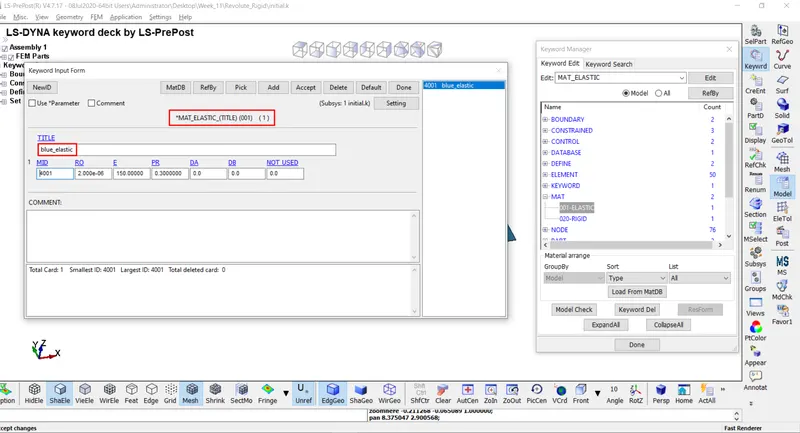
The material and section properties assigned to the parts can be seen in images below.
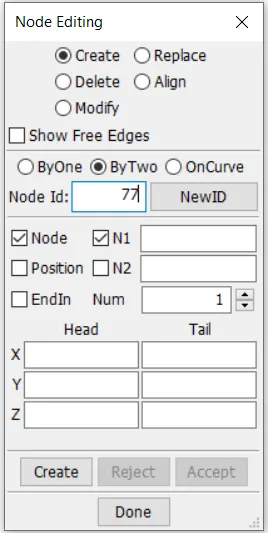
Two pairs of nodes are created using the option under Element Tools > Node Editing > Create > ByTwo > Node Id > Create, i.e node 77-79 and 78-80. The nodes 77 and 79 are coincident and nodes 78 and 80 are also coincident.
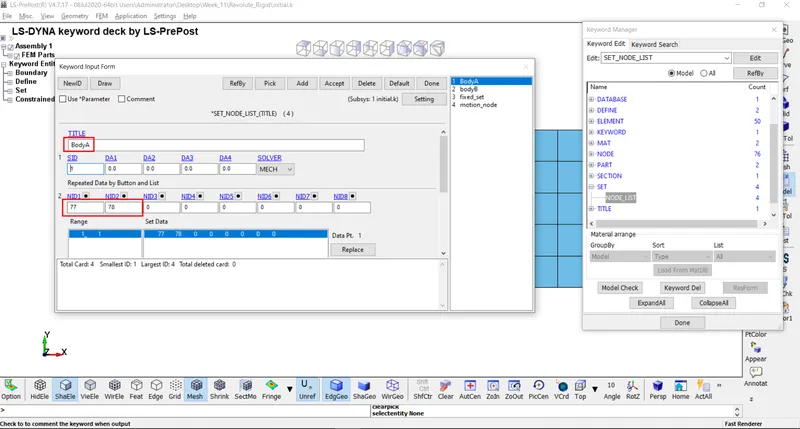
Now create a new node-set, where nodes 77 and 78 belong to one node-set, and nodes 79 and 80 belong to another node-set. This can be done using Create entity > Set Data > *SET_NODE > Create option.
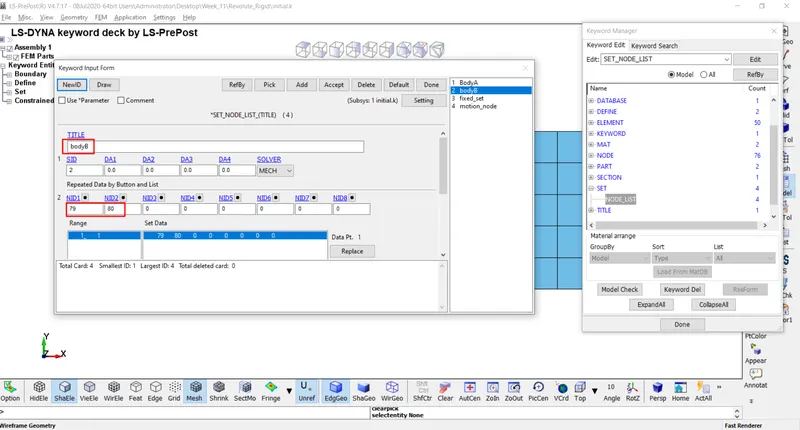
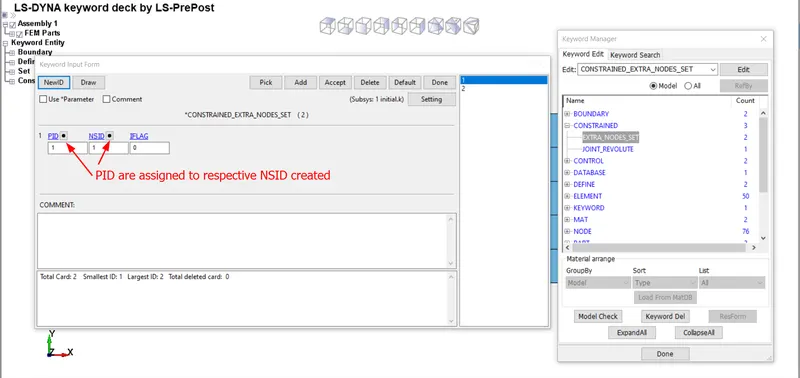
These newly created nodes (77,78,79,80) are in the space and do not belong to any of the parts now. So, For associating these nodes with part 1 and part 2, *CONSTRAINED_EXTRA_NODES_SET is used. Here node 77 and 78 belong to one part and 79 and 80 belong to another part.
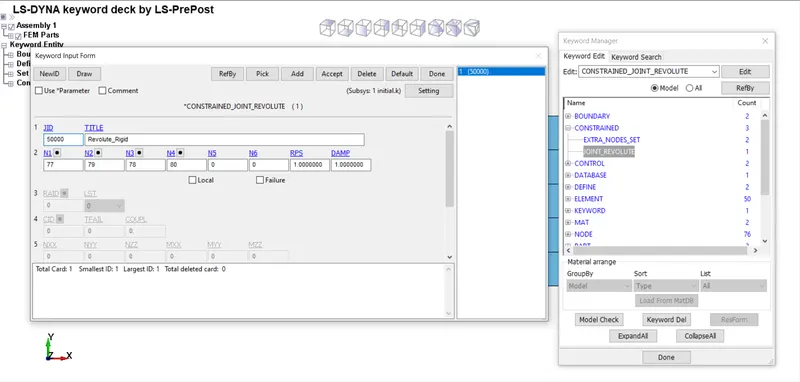
Now, the revolute joint is defined by using the *CONSTRAINED_JOINT_REVOLUTE keyword. Four nodes should be defined to create a revolute joint. N1 and N3 belong to body 1 and N2 and N4 belong to body 2.
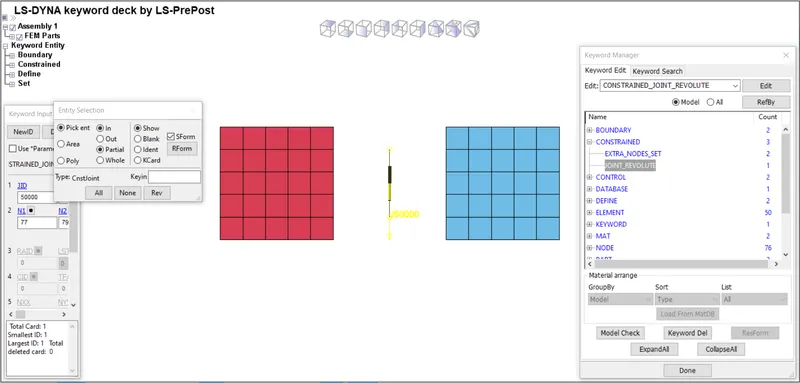
To check if the joint is properly defined, go to *CONSTRAINED_JOINT_REVOLUTE card and click on Draw.
Now, to make this revolute joint work, few boundary conditions are essential. So, a displacement along the Z direction is applied to one of the nodes in part 2. This is defined by the *BOUNDARY_PRISCRIBED_MOTION keyword. The z-translational DOF is kept free by assigning DOF=3 in the keyword.
Single point constraint (SPC) is also used to fix part 1 at its position. Several nodes on the edges of part 1 are selected and assigned *BOUNDARY_SPC. The figure below shows (left part) fixed nodes in part 1 which is marked in green colour and a node is selected to give displacement in part 2 which is denoted in red colour.
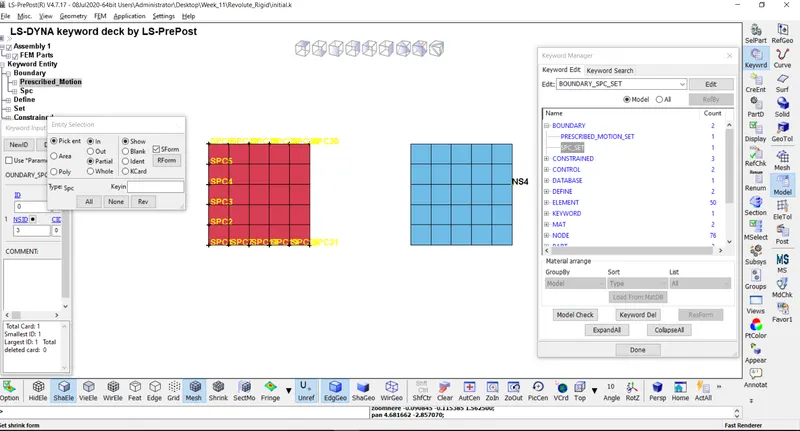
A displacement curve was also defined for the prescribed motion keyboard which is defined by LCID.
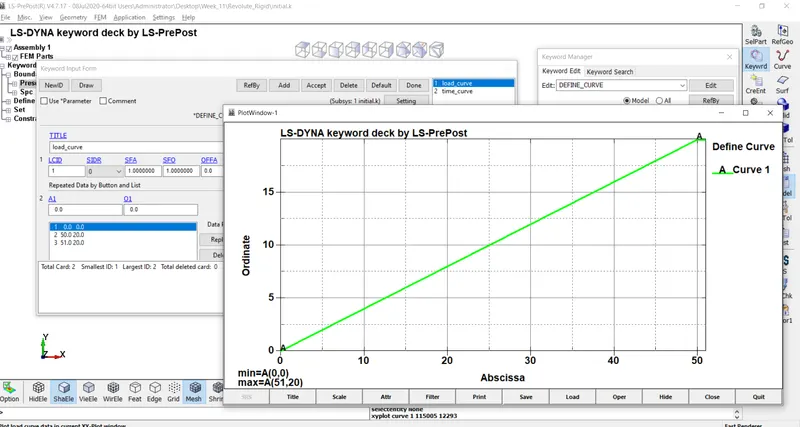
*CONTROL_TIMESTEP card is used and a load curve which is shown below is assigned through the LCTM option. The timestep calculated by the solver for these rigid bodies and this mesh size is large enough and hence for more stability, we use smaller time steps for explicit analysis.
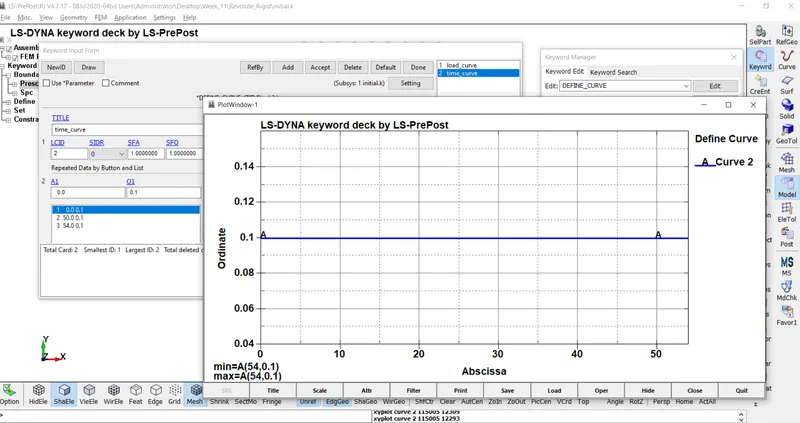
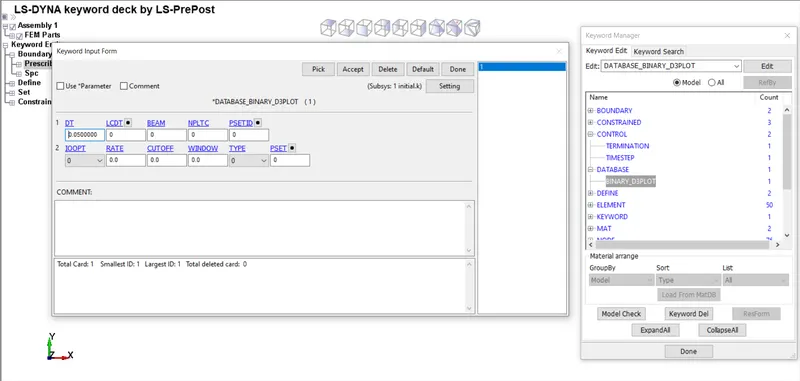
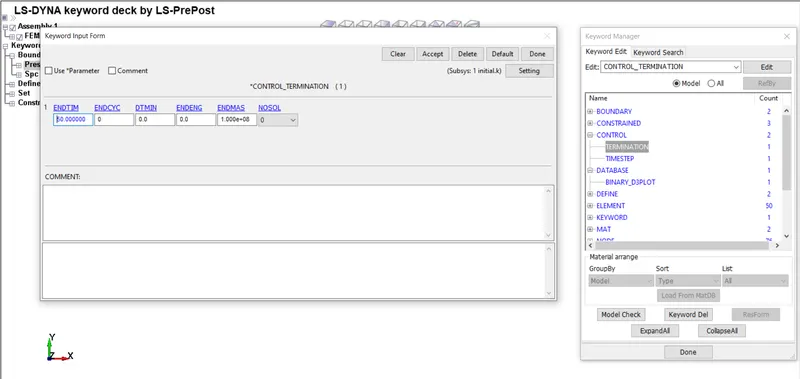
Other keywords cards required for post-processing like DATABASE_BINARY_D3PLOT and CONTROL_TERMINATION are then assigned and the model is been run in the Ls-Run.
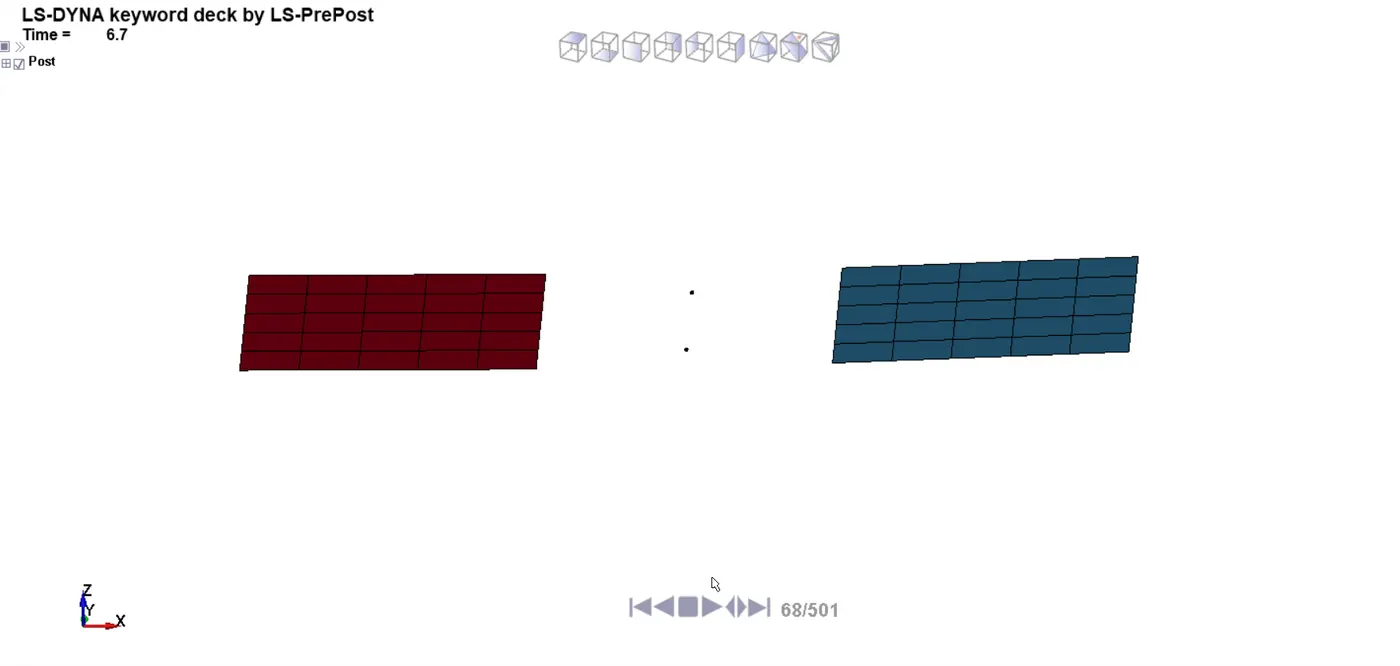
Simulation:-
I am not able to include my report further due to some bug so I am attaching a word document along with the required deliverables.