week-11 Joint creation and Demonstration
Aim: to use *CONSTRAINED_JOINT keyword and simulate follwoing joints,
1. Spherical joint
2. Revolute Joint
3. Cylindrical joint
4. Translational joint
-----------------------------------------------------------------------------------------
Given problem boundary conditions:
1. Rigidbody and deformable bodies hould be used
2. Use *CONSTRAINED_EXTRA_NODES for rigid bodies.
3. Use *CONSTRAINED_NODAL_RIGID_BODY for deformable bodies
-----------------------------------------------------------------------------------------
Common steps to all problems:
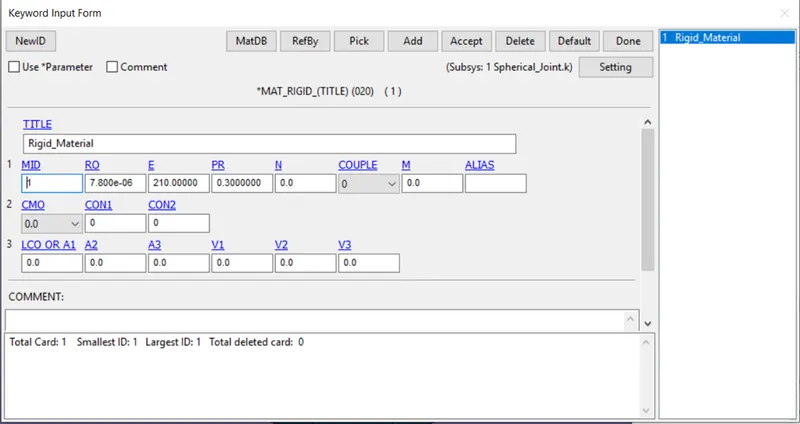
Material: *MAT_RIGID : Same rigid material is used for all rigidbody problems.
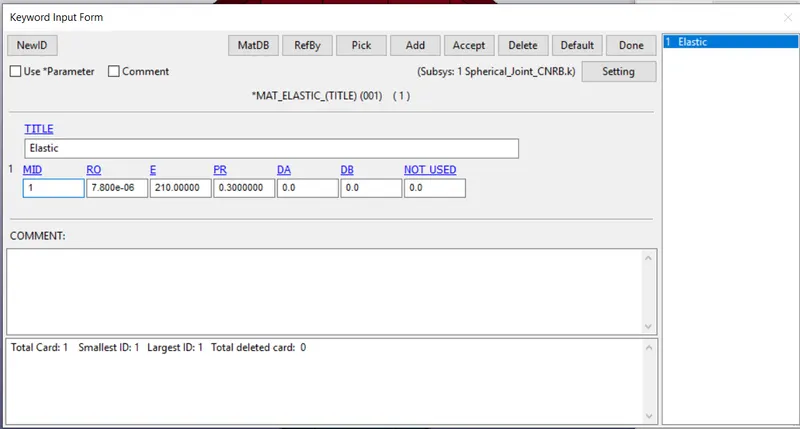
*MAT_ELASTIC: Elastic material is used for all deformable bodies.
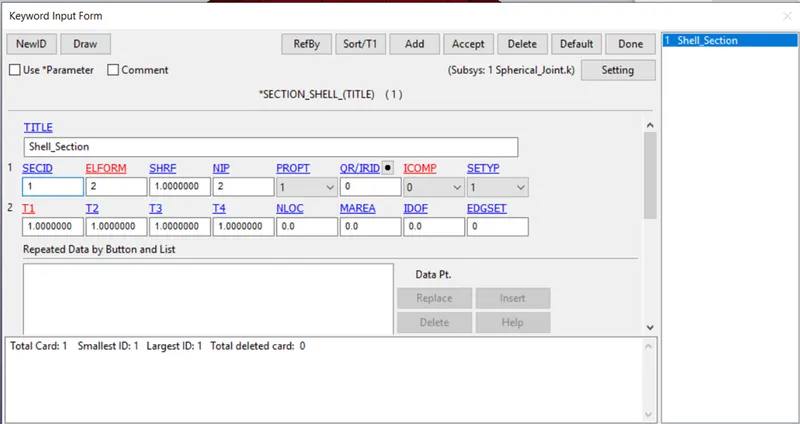
Section: Shell section is used for all joints and is kept constant for all problems.
Solution procedure
1. Spherical Joint
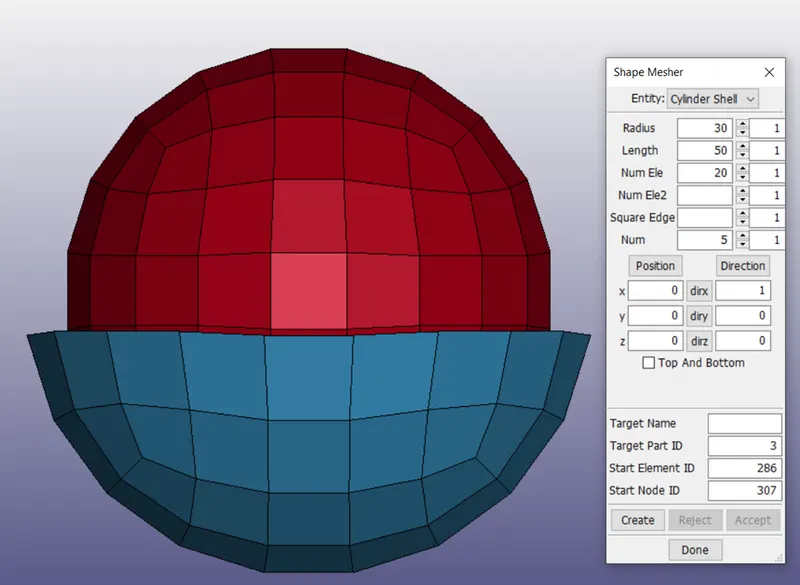
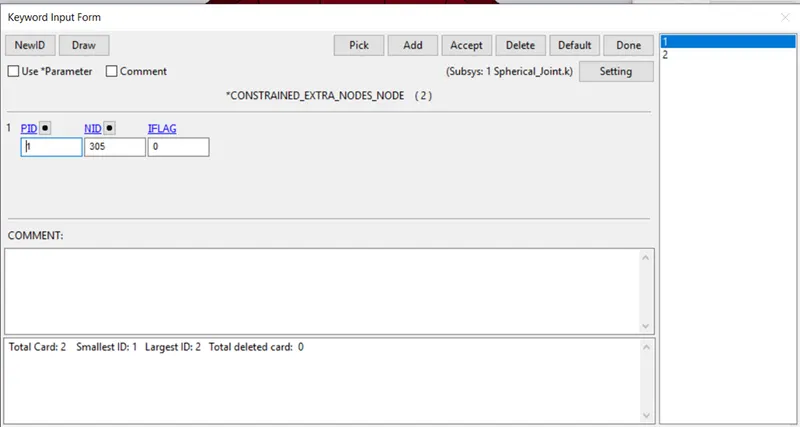
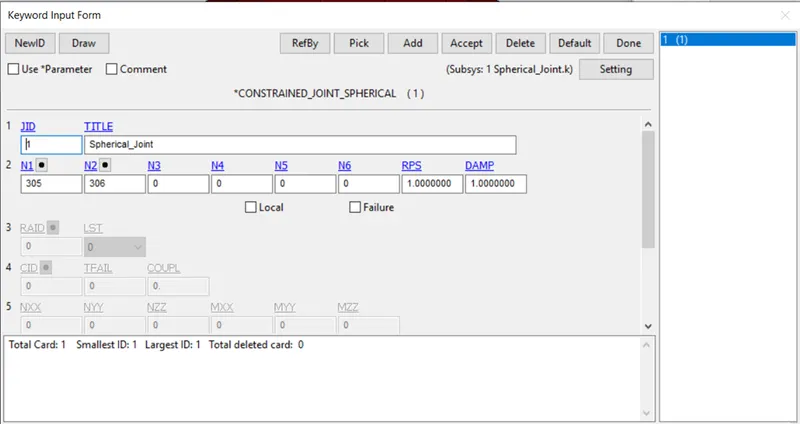
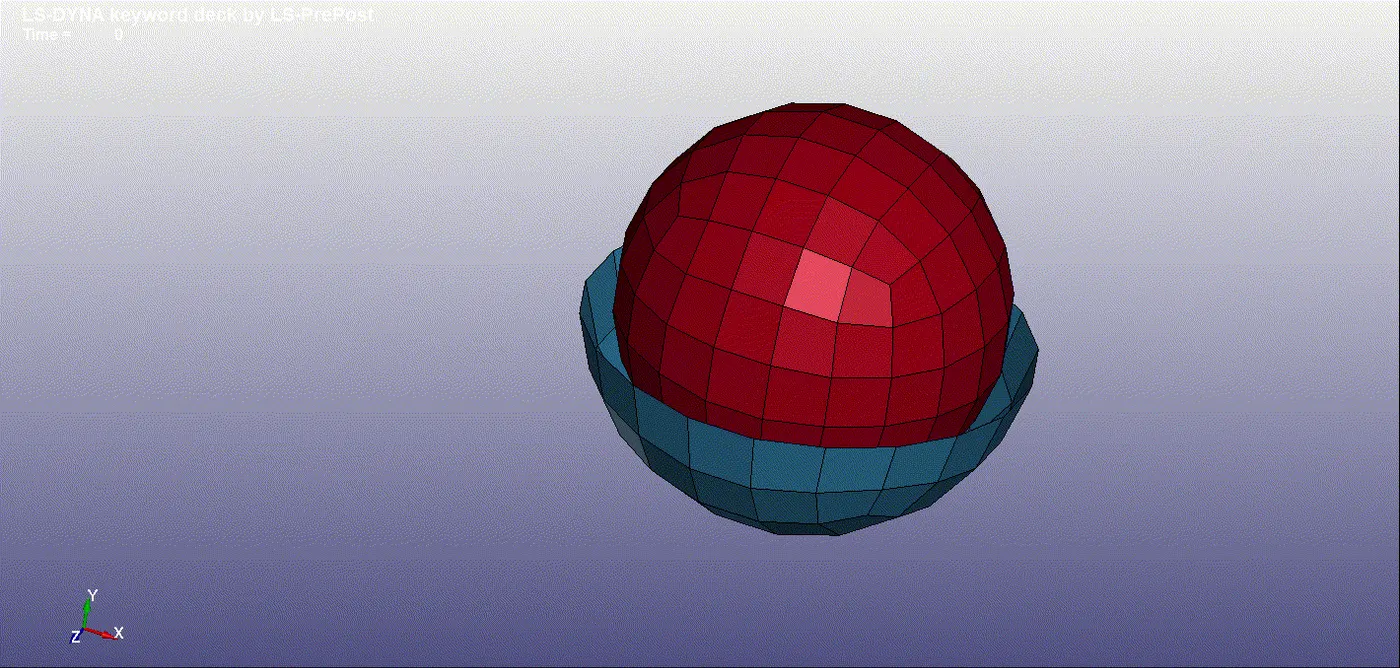
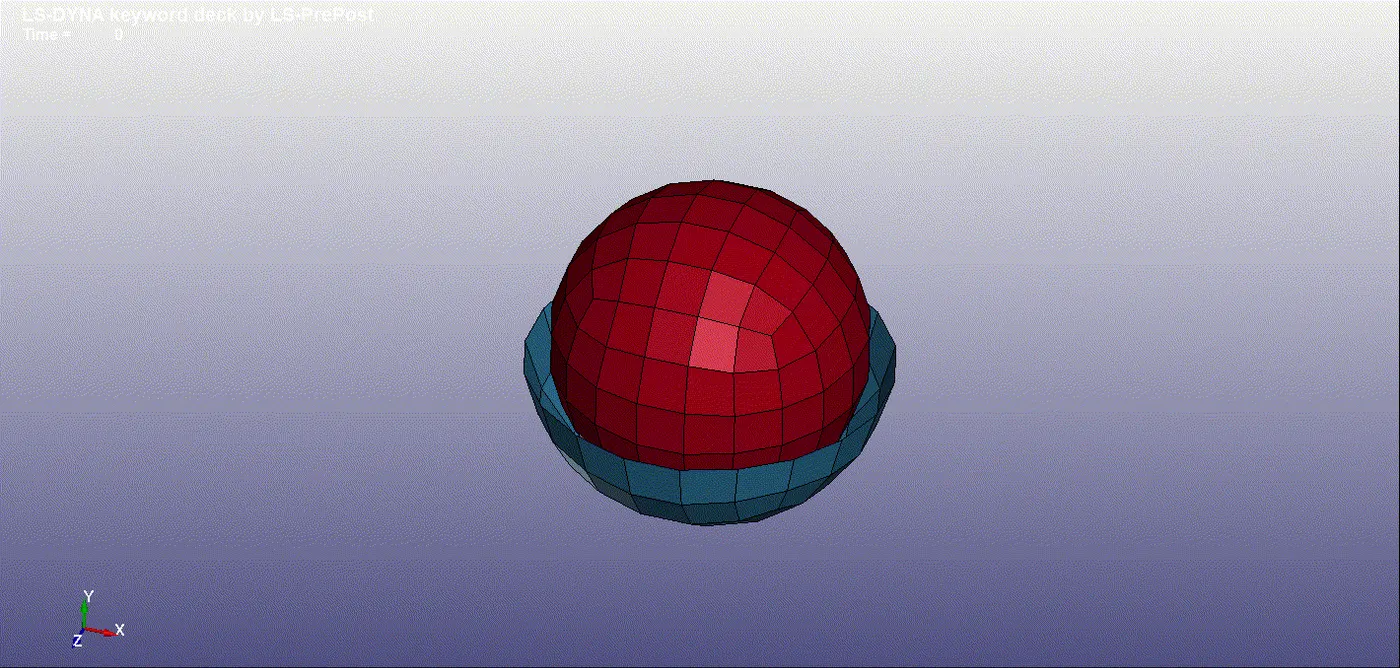
Spherical Joint deformable body with CNRB
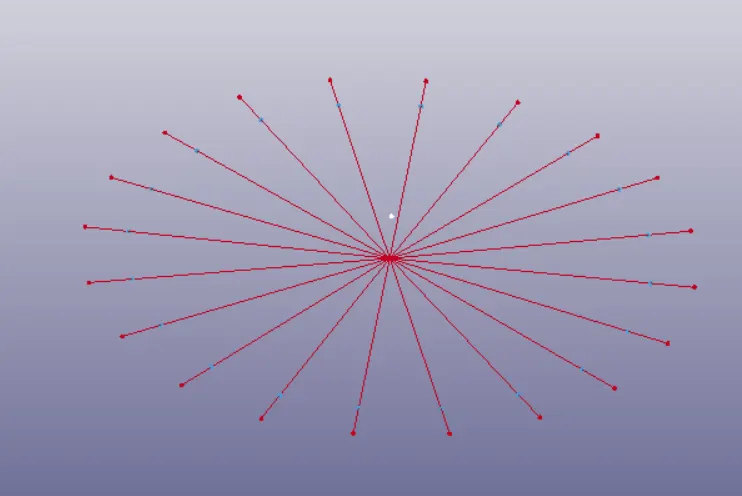
Problem is formulated similar to previous step. Material is changed to elastic and CNRB is created as shown below.
Results
------------------------------------------------------------------------------------------------------------
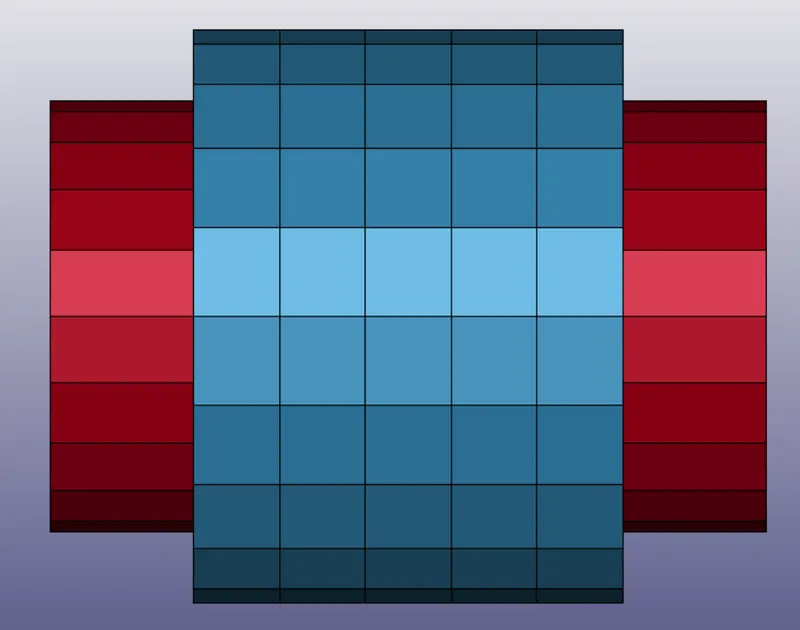
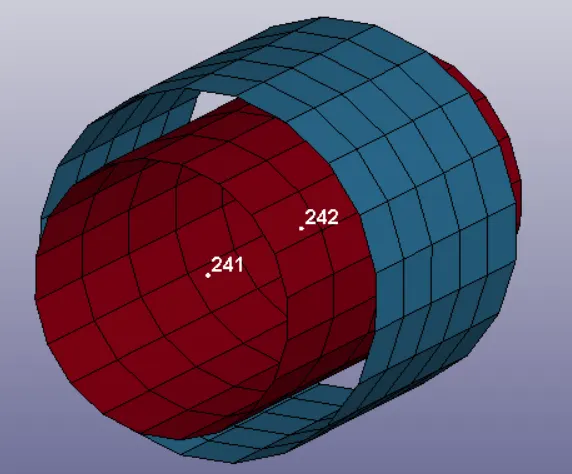
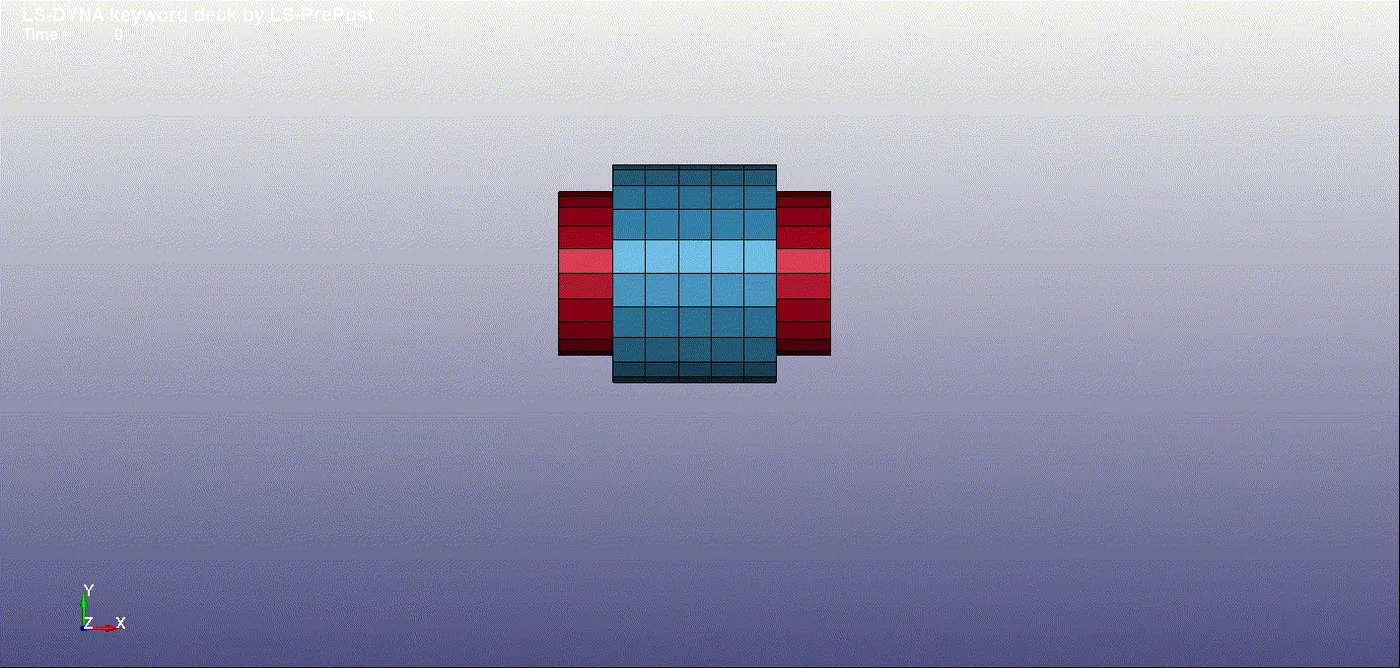
Cylindrical Joint
_____________________________________________________________________________
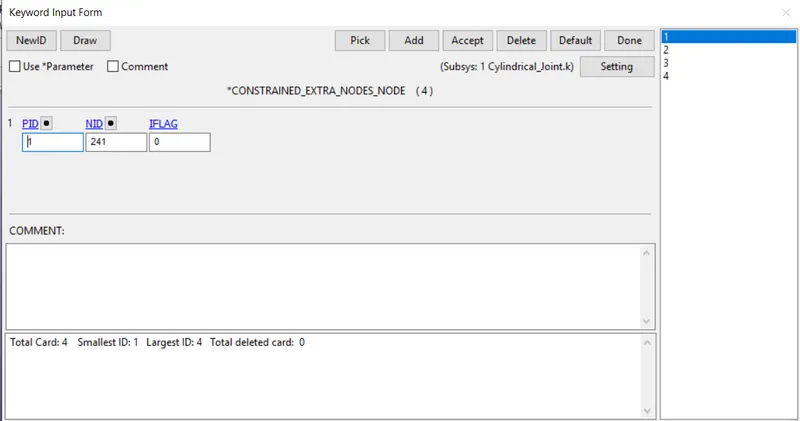
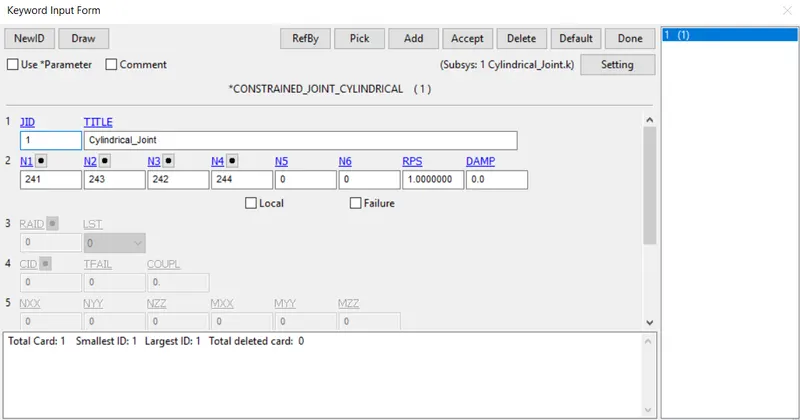
Result
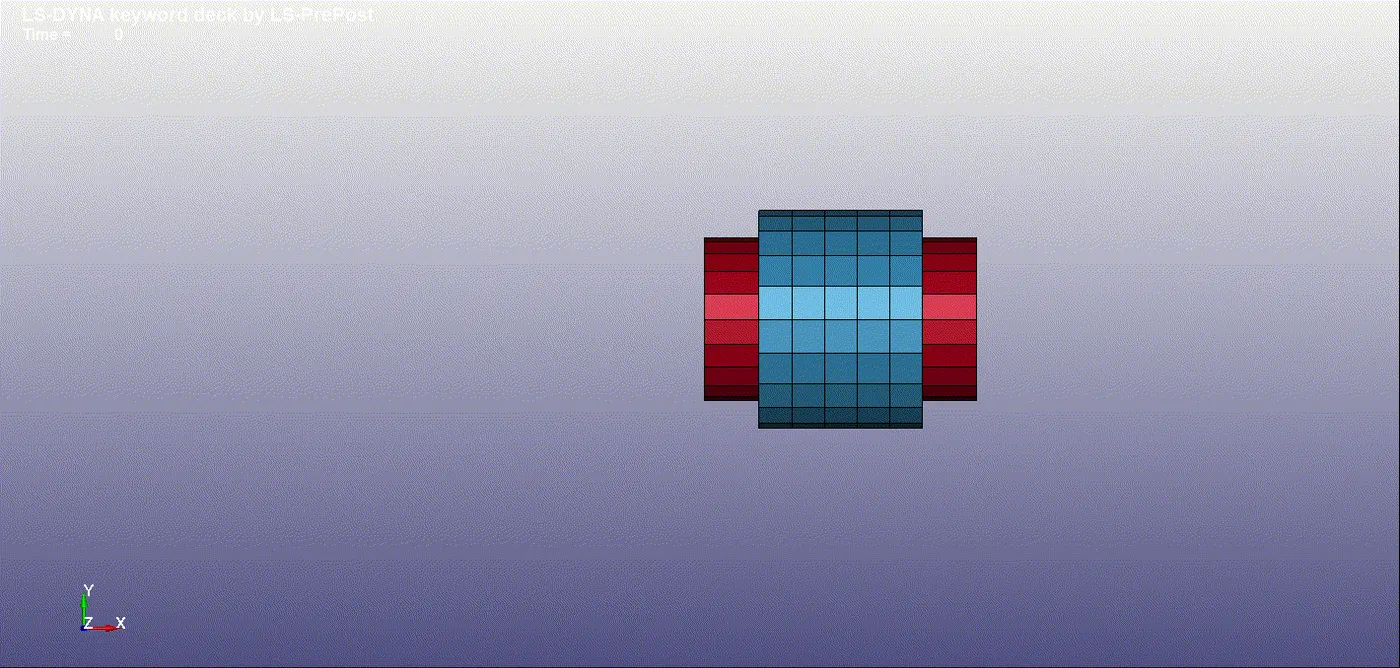
Cylindrical Joint CNRB:
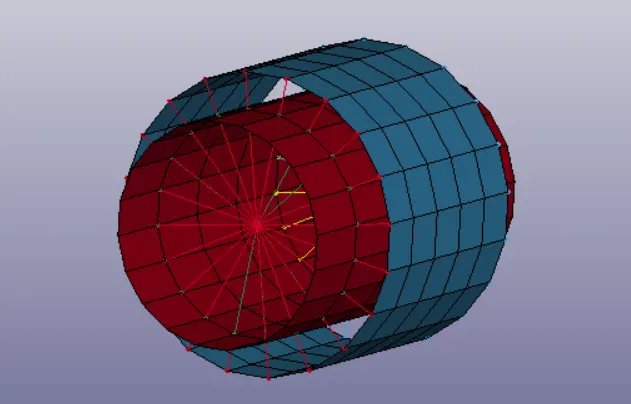
Results:
_____________________________________________________________________________
Revolute Joint
____________________________________________________________________________
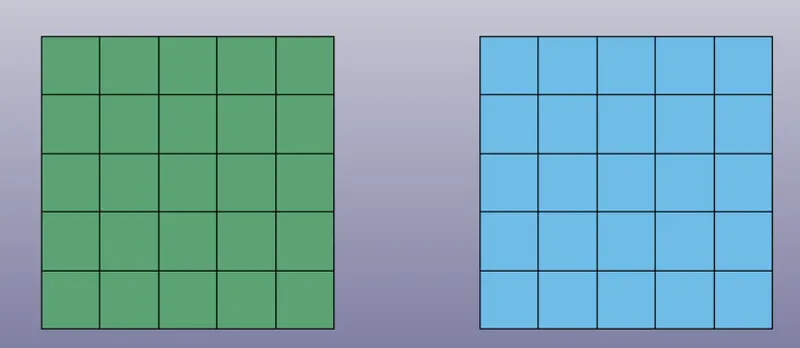
Results:
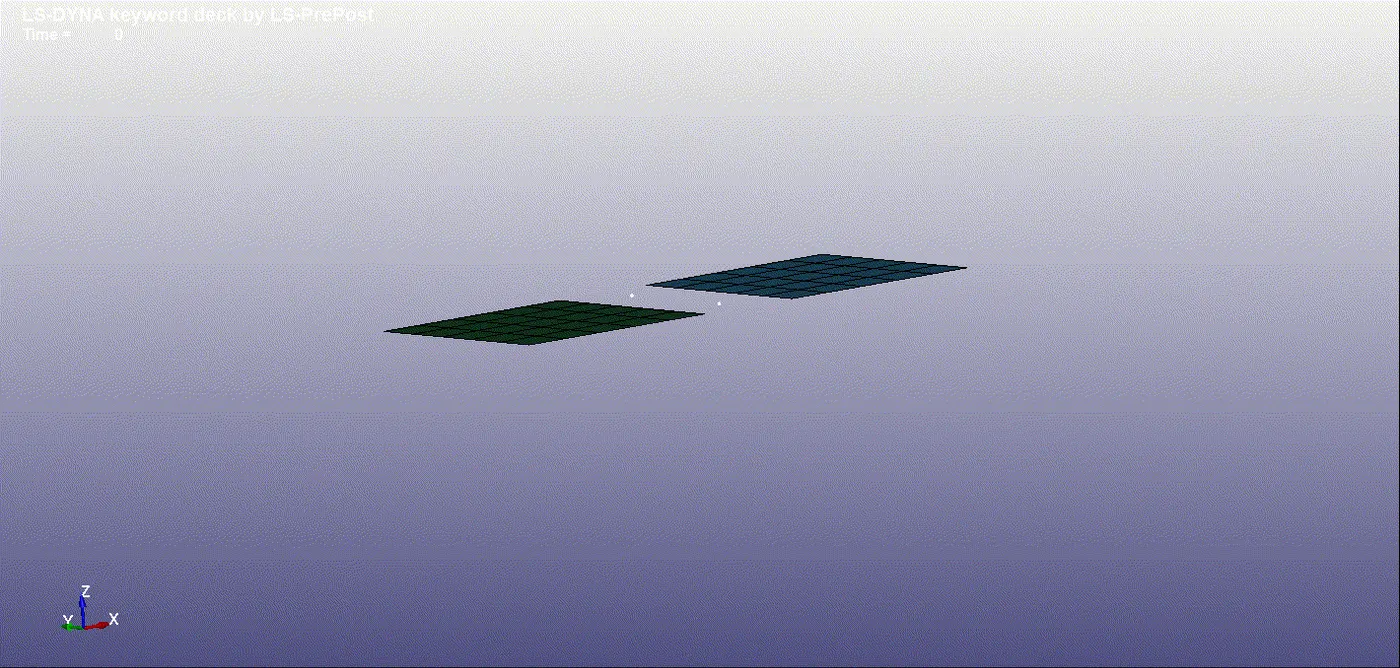
Revolute joint with deformable body
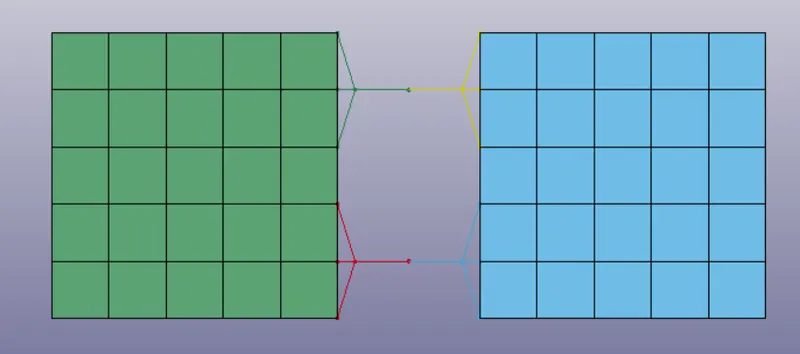
Results:
____________________________________________________________________________
Translational Joint
____________________________________________________________________________
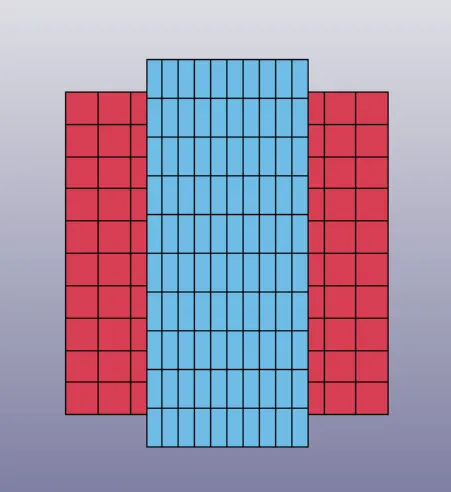
Results:
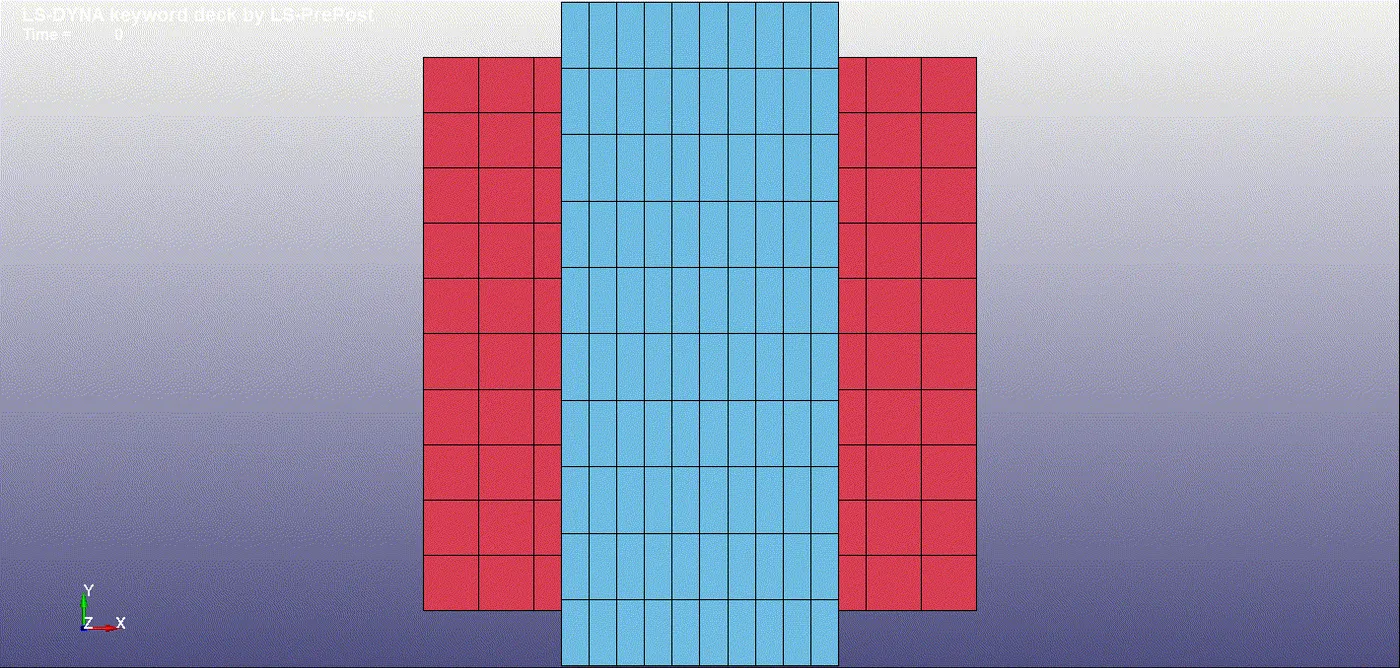
Translational joint with deformable bodies
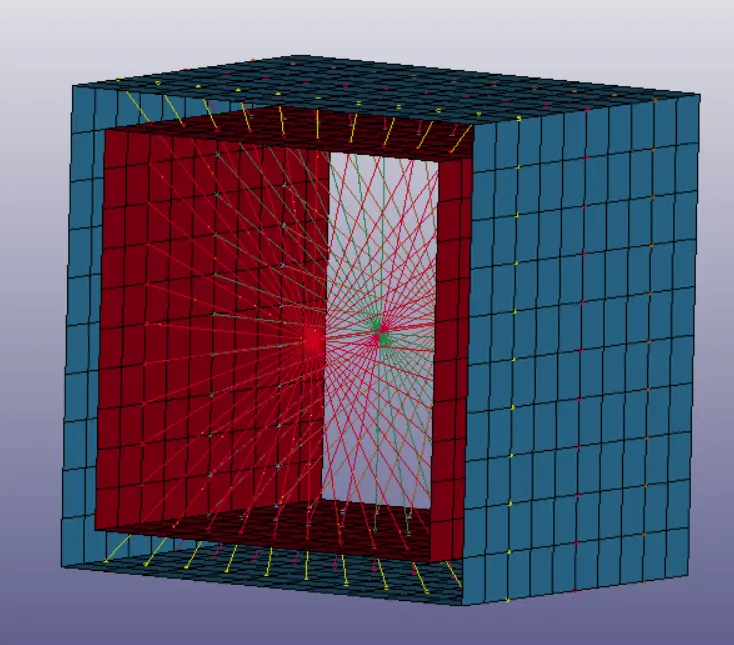
Results
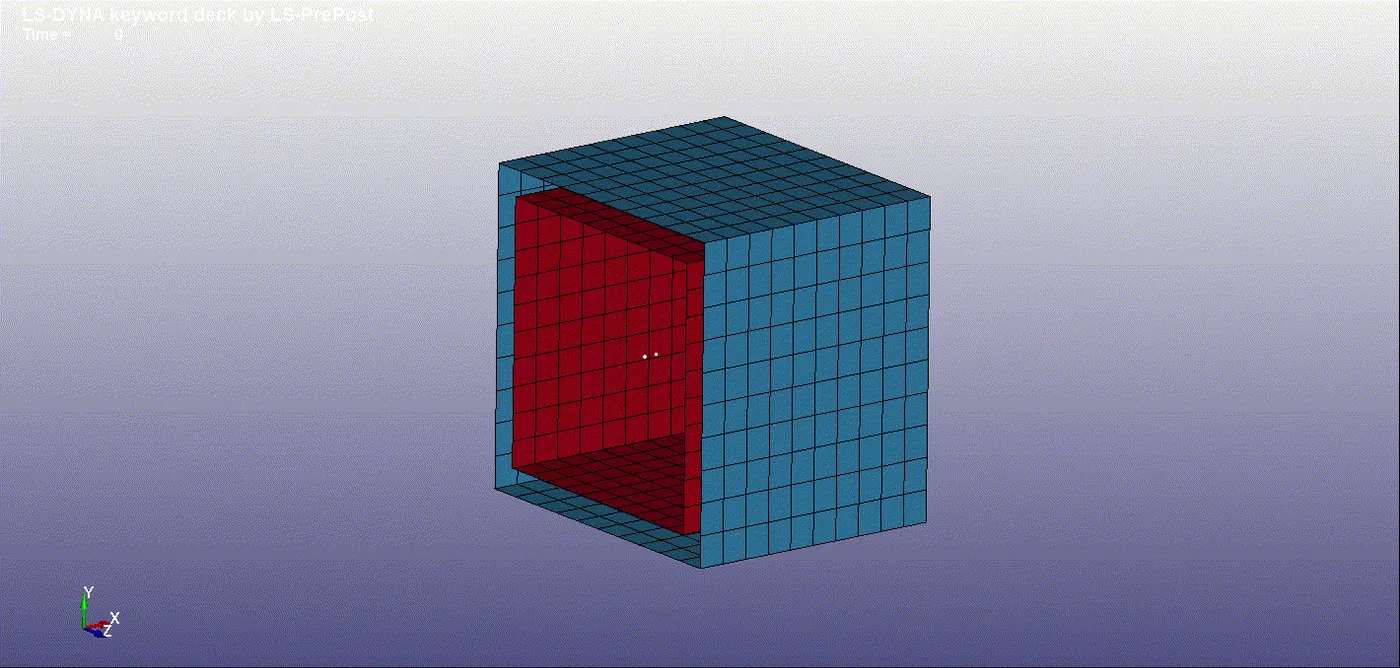
Conclusion:
Following joint kinematics were simulated.
1. Revolute joint
2. Cylindrical joint
3.Translational joiunt
4. Spherical joint