week-11 Joint creation and Demonstration
OBJECTIVE:-
To illustrate the mechanism of Spherical,Cylindrical,Translational and Revolute Joints between rigid bodies and Deformable bodies.
The various types of joints can be created in LS-DYNA using CONSTRAINED_JOINT Keyword.
PROCEDURE:-
JOINTS BETWEEN RIGID BODIES
1) REVOLUTE JOINT-
- Firstly, we need to create two rectangular shell mesh for joining them. Go to LS-PREPOST then MESH then SHAPER then 4N Shell. Here we need to create two parts with some distance.
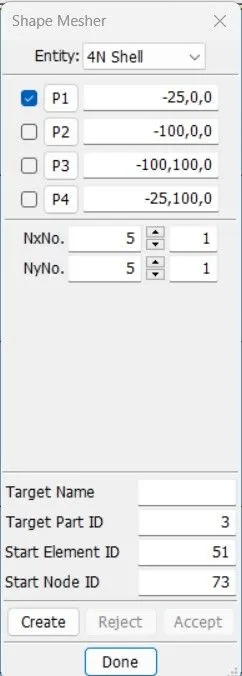
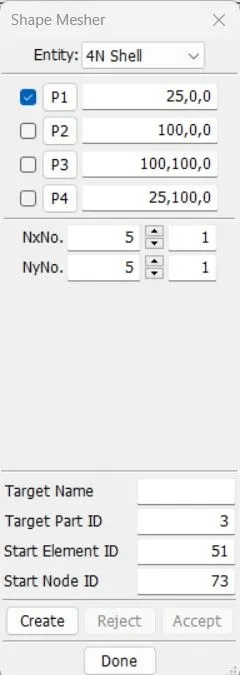
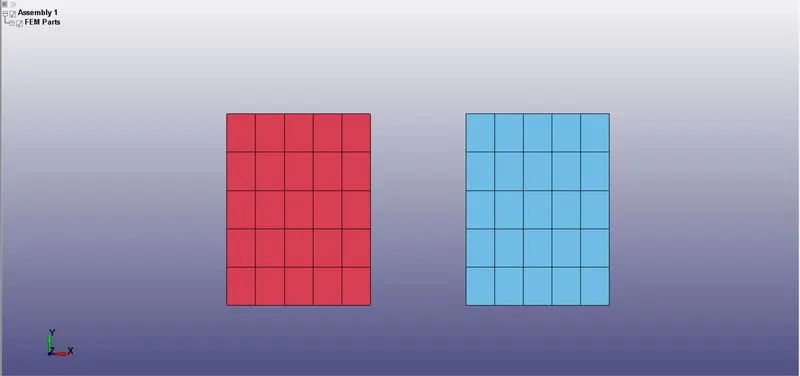
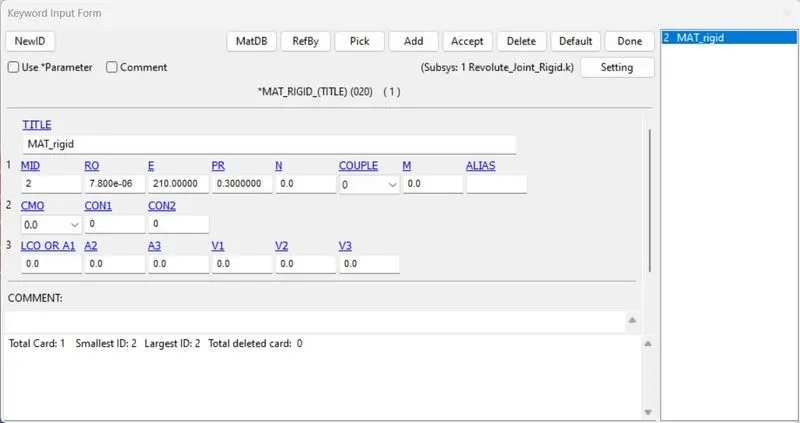
- Now we will define the material card for thid psrt for that we will go to Model and Keywords then ALL then MAT then 020_MAT_RIGID. Now here we will define density, Youngs Modulus, Poission's Ratio.
- Defining the section id for the part. For that we will go to model&keyword then all then section then shell. Here defining all the required parameters.
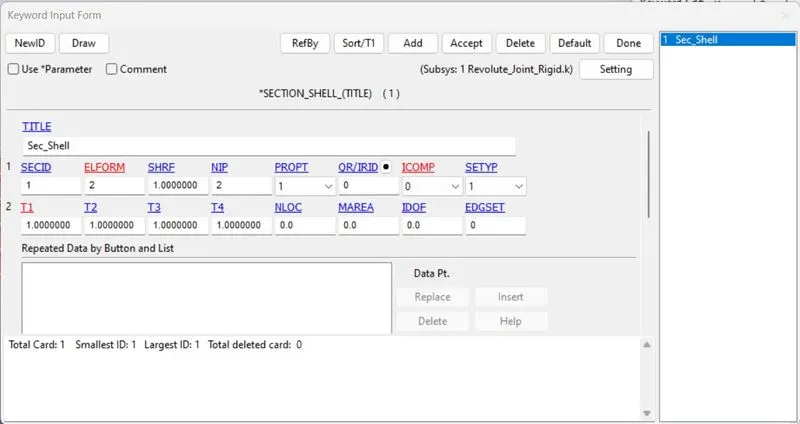
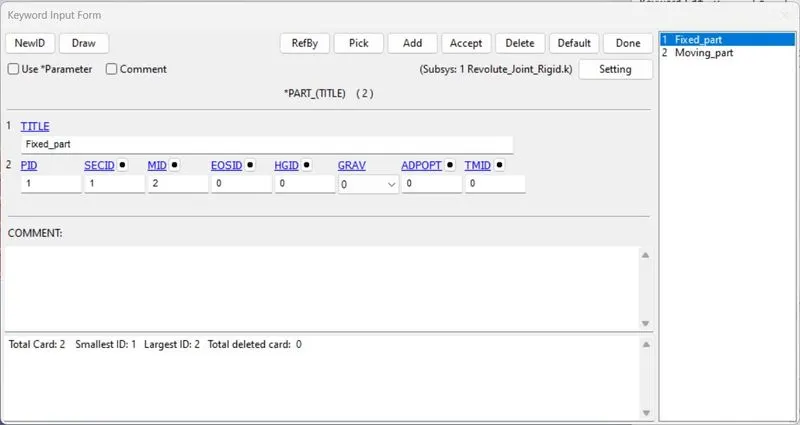
- Now we will define Section and MAT id to both the parts.
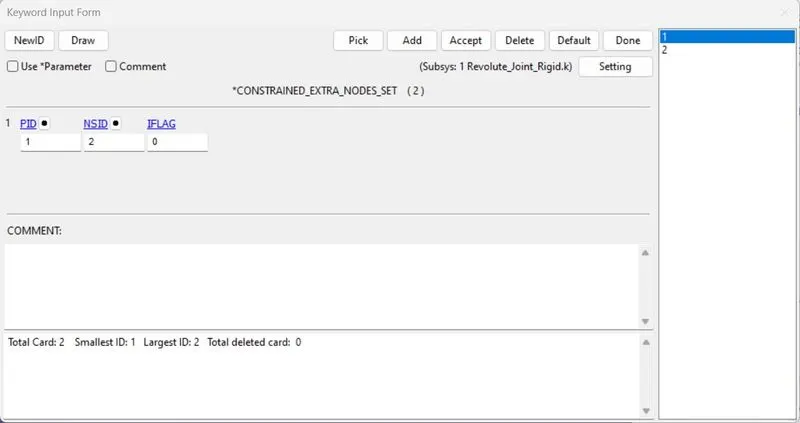
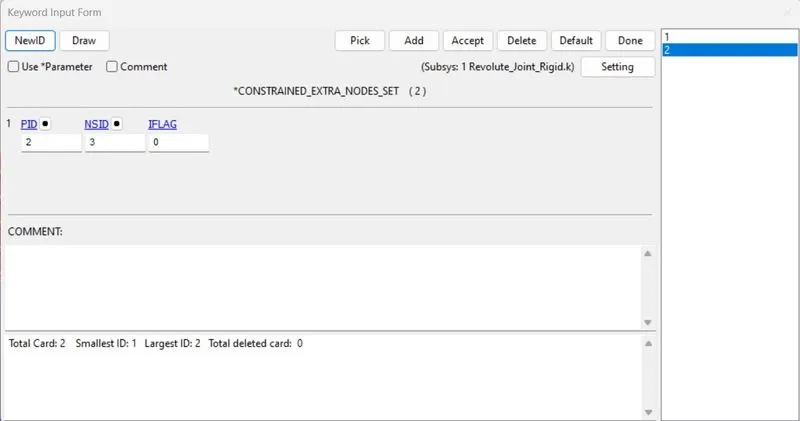
- Two pairs of nodes are created for constrainig, using Node edit option under Element Tools. The nodes 101,103 are constrained to part 1 and 102,104 to part 2 respectively, using CONSTRAINED_EXTRA_NODES card.
- Now a revolute Joint is created between them using the CONSTRAINED_JOINT using nodes N1 and N3 of part 1 and N2,N4 of part 2.
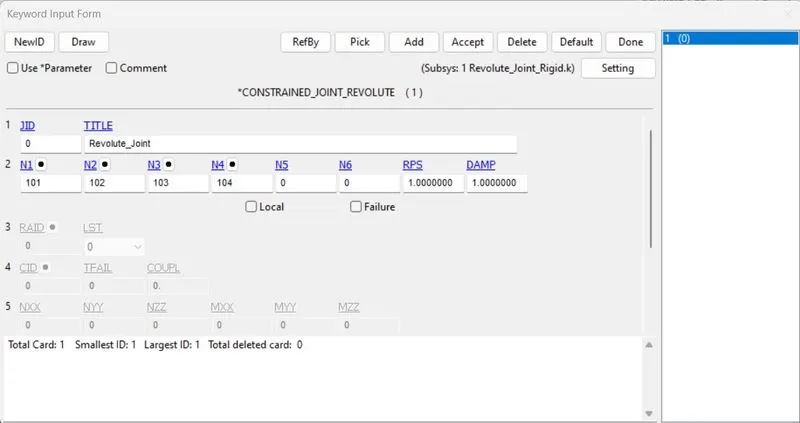
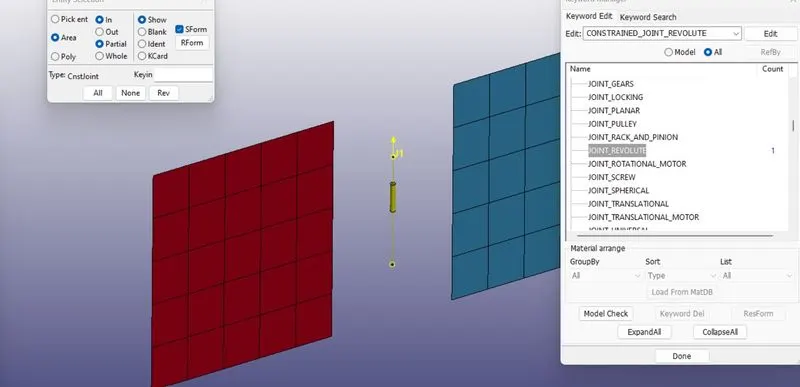
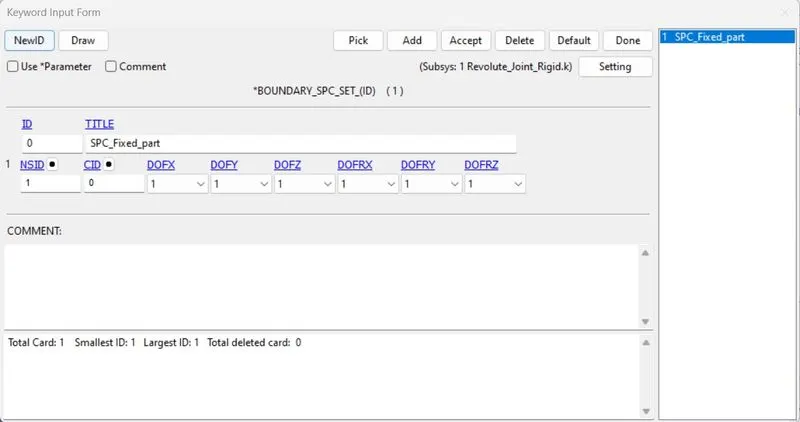
- Here part 1 that is right side elements are fixed at all nodes in order to prevent motion and part 2 that is left side elements are free for movement and a prescribe motion is given to it.
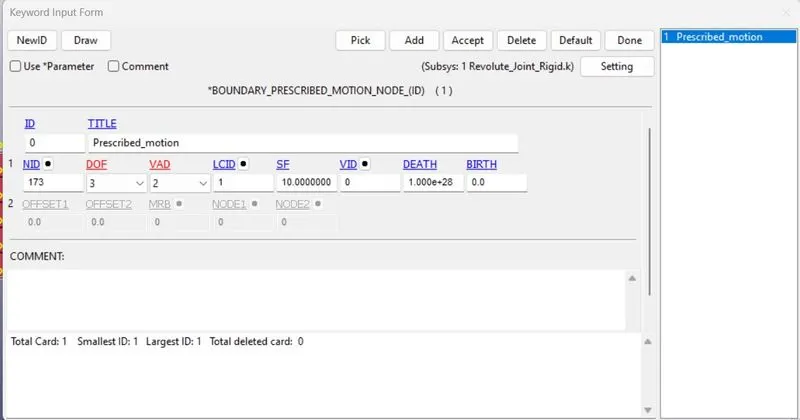
- Now load curve is defined with required displacement.
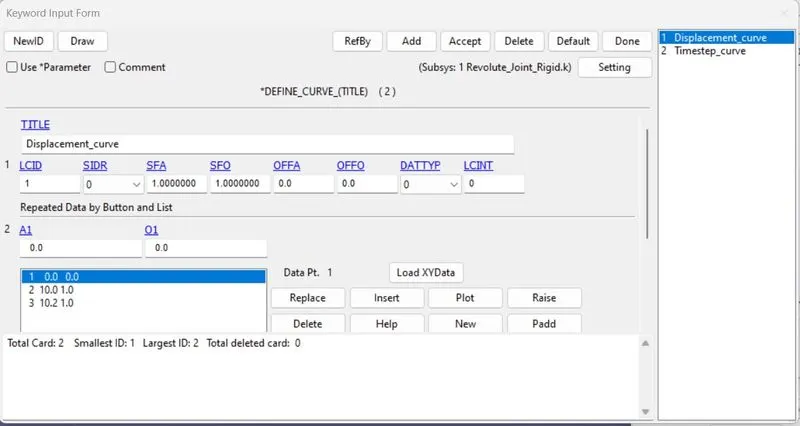
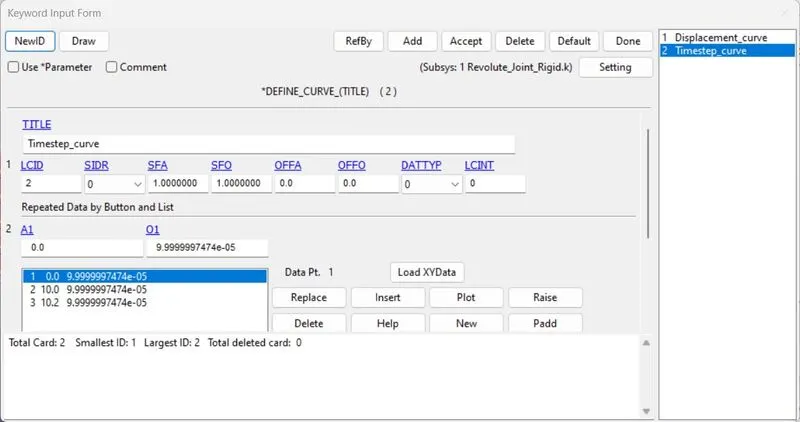
- The Control timestep is defined using the above timestep curve in the LCTM, and the termination time is given as 10 ms.
2) SPHERICAL JOINT-
- The first step is to create two spherical bodies in LS-DYNA using the entity option under shape mesher in element and mesh and choosing the spherical shell. The upper elements of the outer shell are deleted in order to get the required shape for that we will go to element tool then element edit then selecting the upper elements and deleting those.
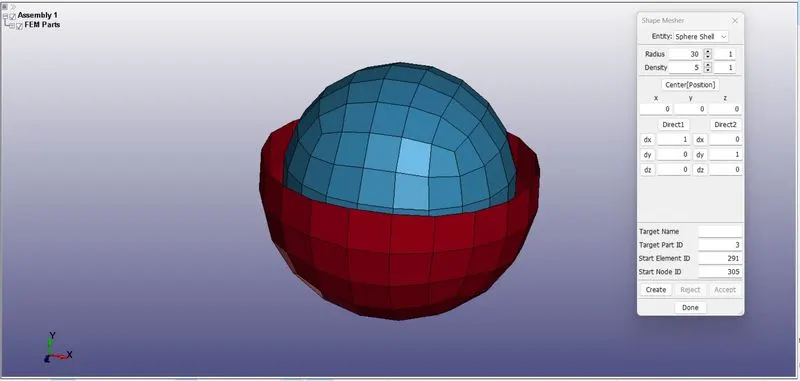
- The material and section properties are same as that of the spherical joint.
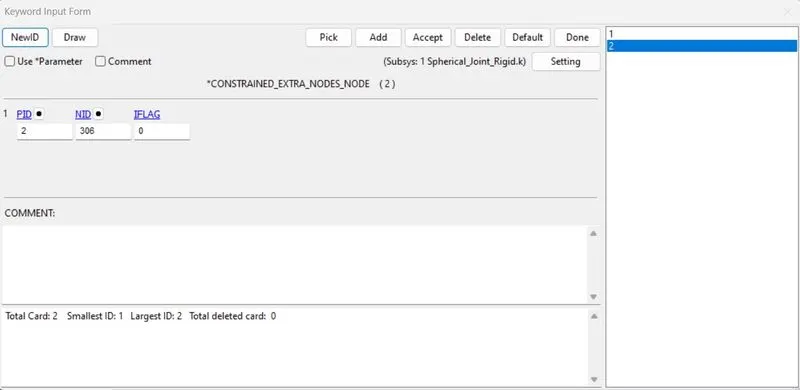
- After that we will will create two nodes for constraining using node edit option under element tools. the first node (305) is constrained to part 1, and the second node (306) is constrained to part 2. Using CONSTRAINED_EXTRA_NODES as shown below.
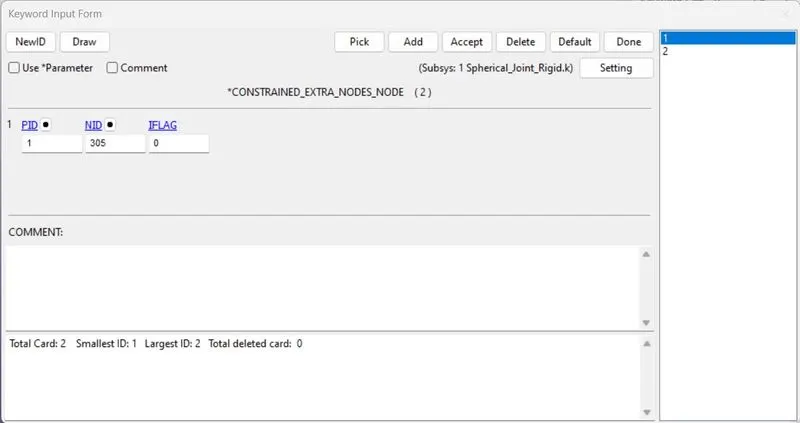
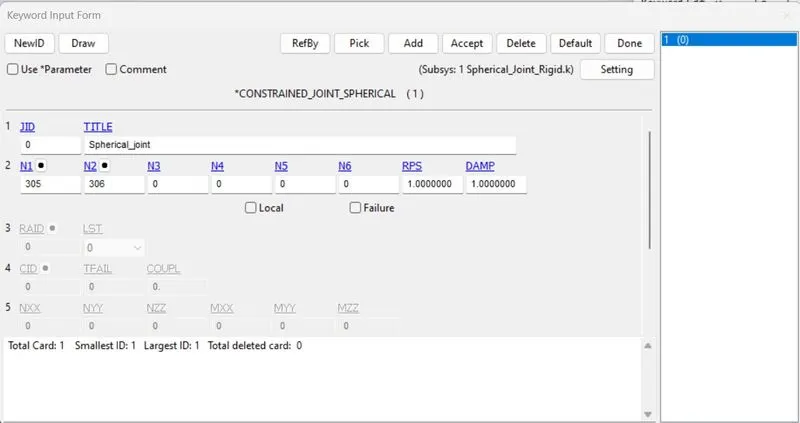
- A spherical Joint is then created between them, using the CONSTRAINED_JOINT.
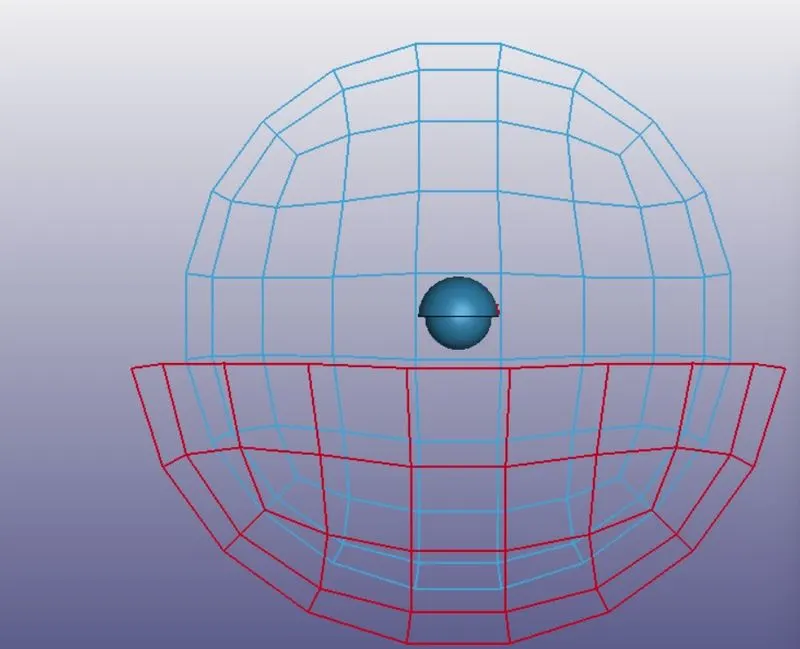
- An initial velocity of 20mm/ms is applied to part 2 that is inner sphere in all three rotational directions.
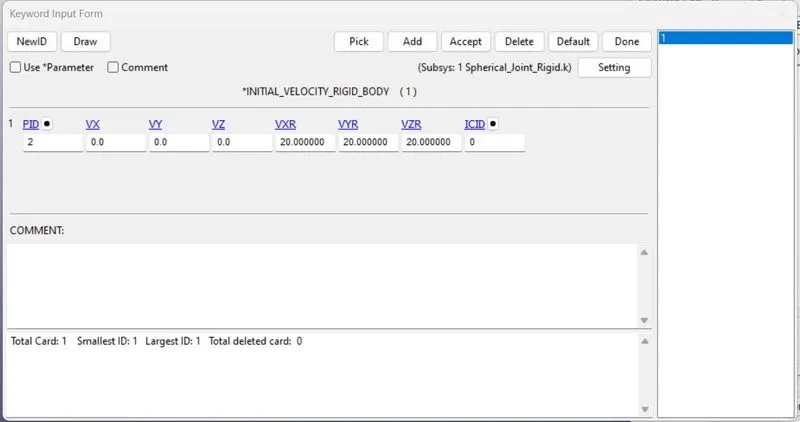
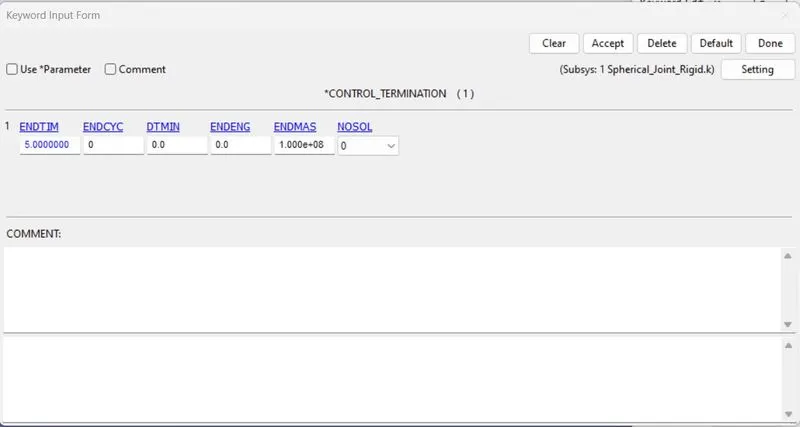
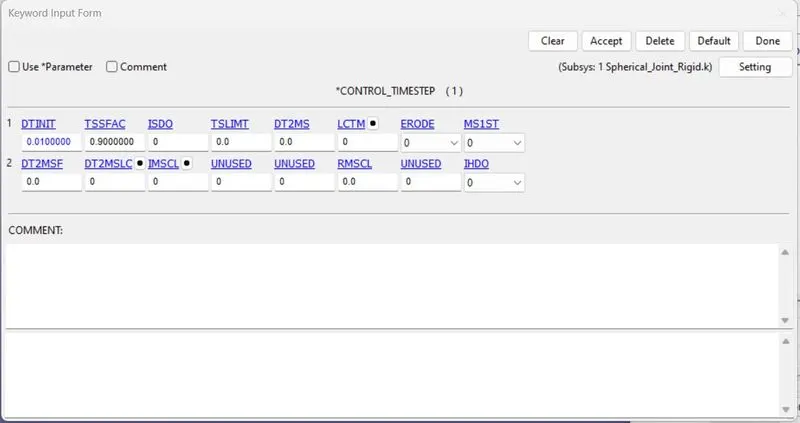
- The simulation is set for 5ms to run and DTINT is given as 0.01 ms.
3) CYLINDRICAL JOINT-
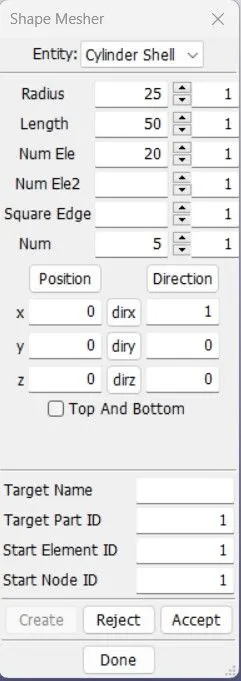
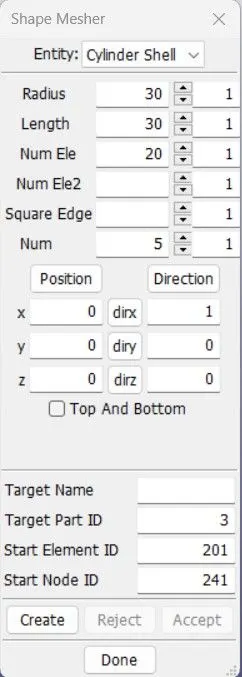
- The first step here is to create two bodies using Entity option under shape mesher in Element and Mesh and choosing cylindrical shell.
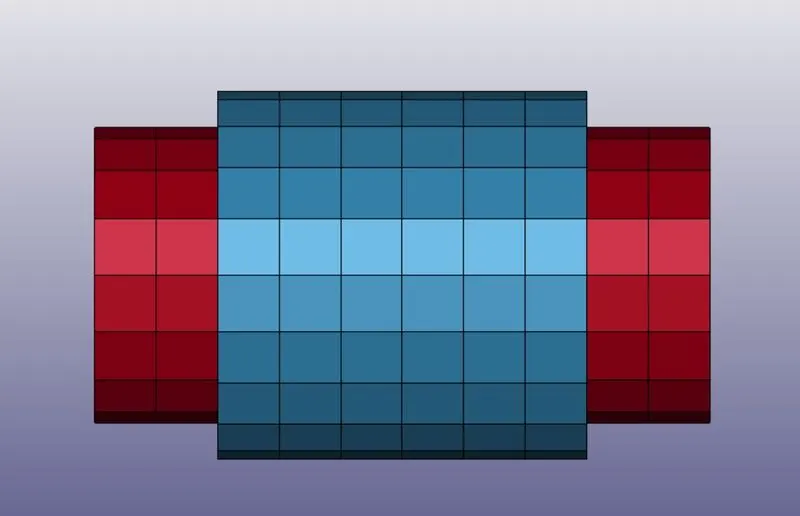
- The material and section properties are the same as that of the Revolute joint.
- Here two pairs of nodes are created for constraining using Node edit option under element tools. The nodes 321,323 are constrained to part 1 and 322 and 324 to part 2 respectively using COSNTRAINED_EXTRA_NODES card as shown below.
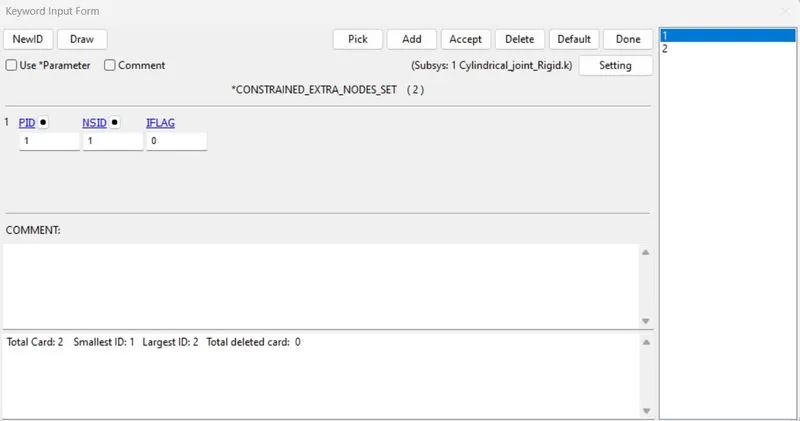
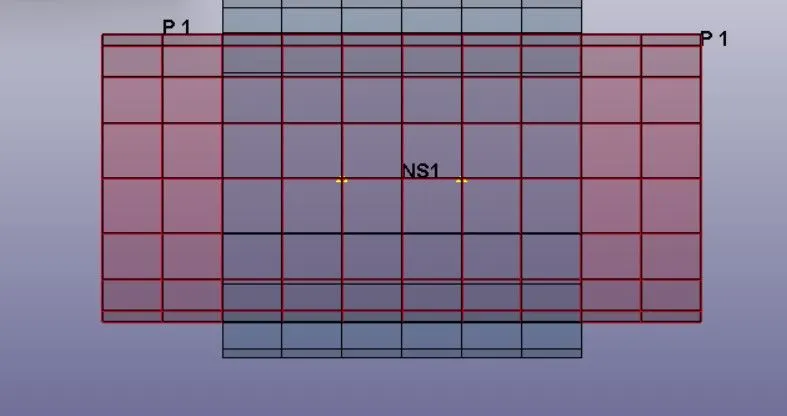
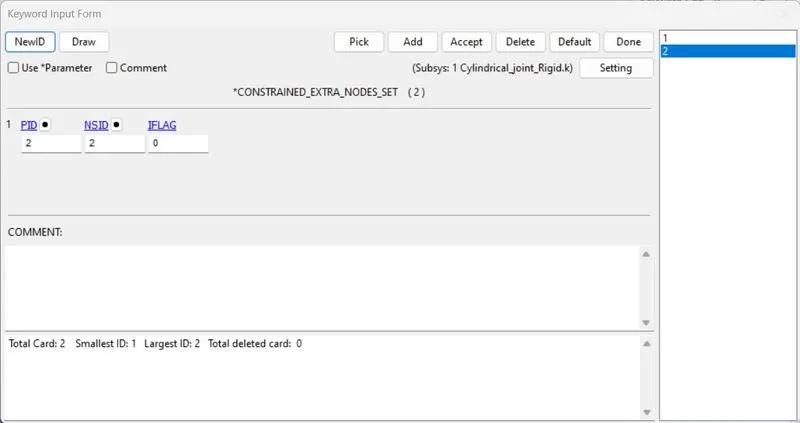
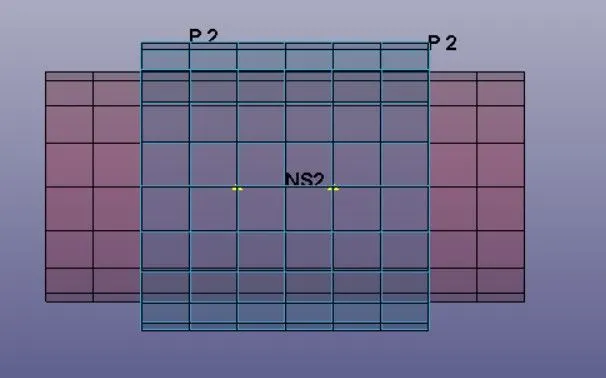
- Now a cylindrical joint is created in between them, using the CONSTRAINED_JOINT and using the nodes N1 & N3 of part-1 and N2 & N4 of part 2.
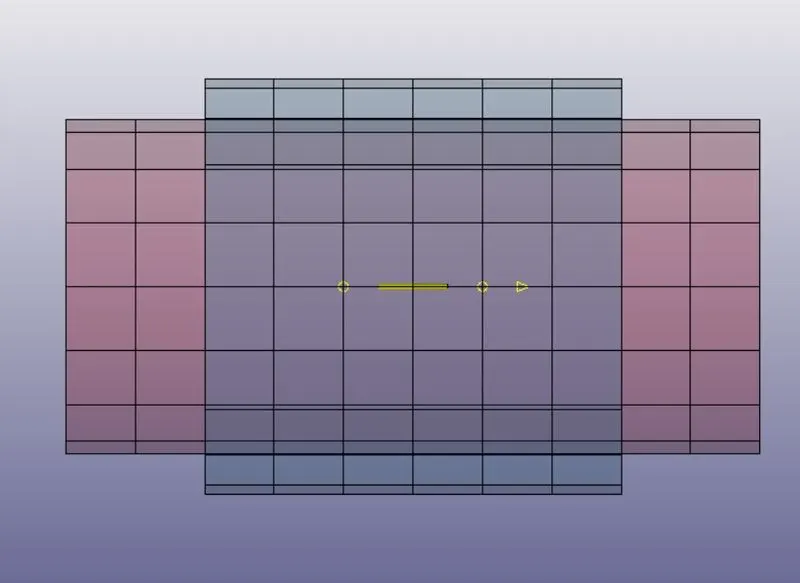
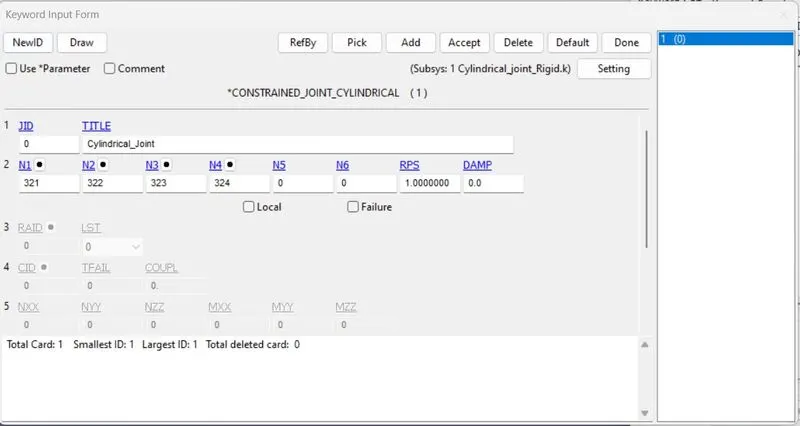
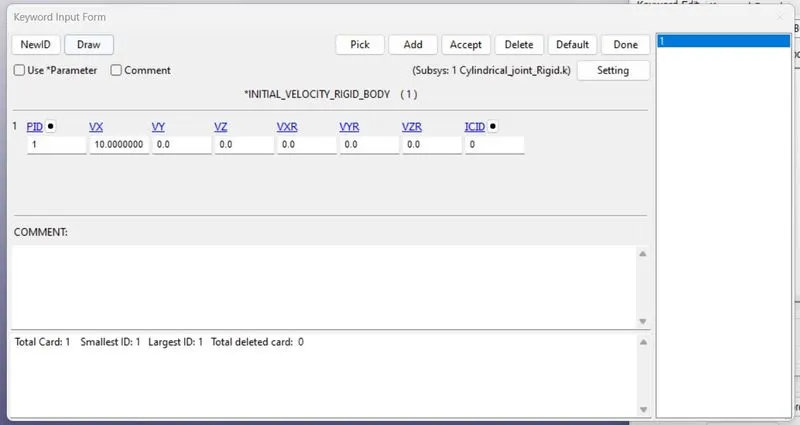
- Here part 2 which is blue one is fixed and part 1 which is red one is moving part. An initial Velocity of 10 mm/ms is given to part 1 in the X-Axis (Translational) direction.
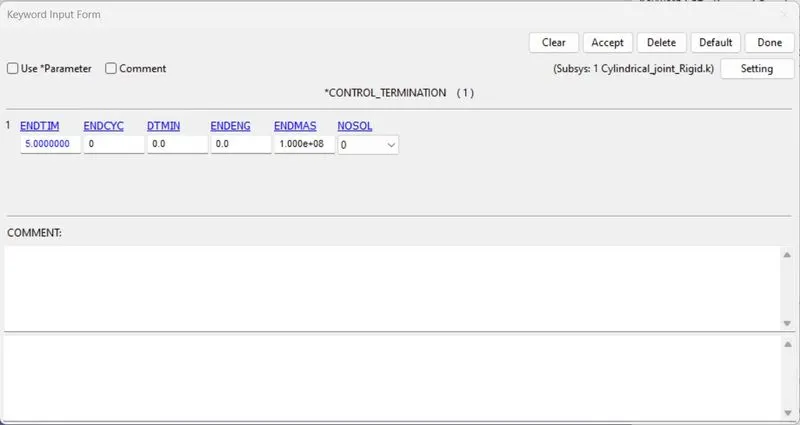
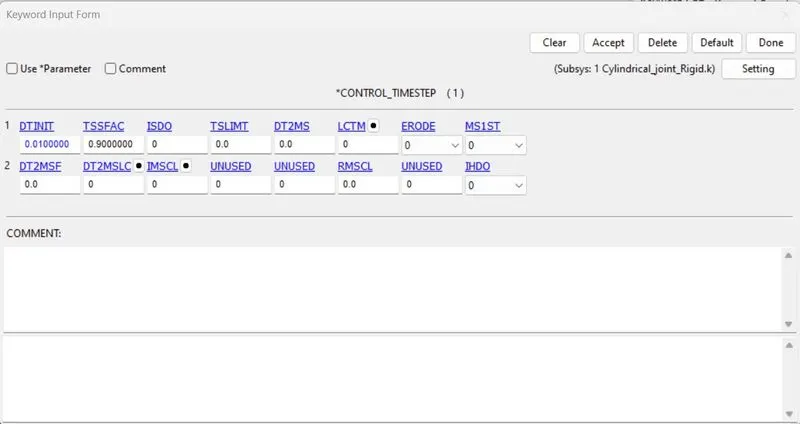
- The time given for simulation is set to run for 5ms and DTINT is given as 0.01 ms.
4) TRANSLATION JOINT-
- For this we will create the two bodies via Entity option under shape mesher in element and mesh and chooseing box shell.
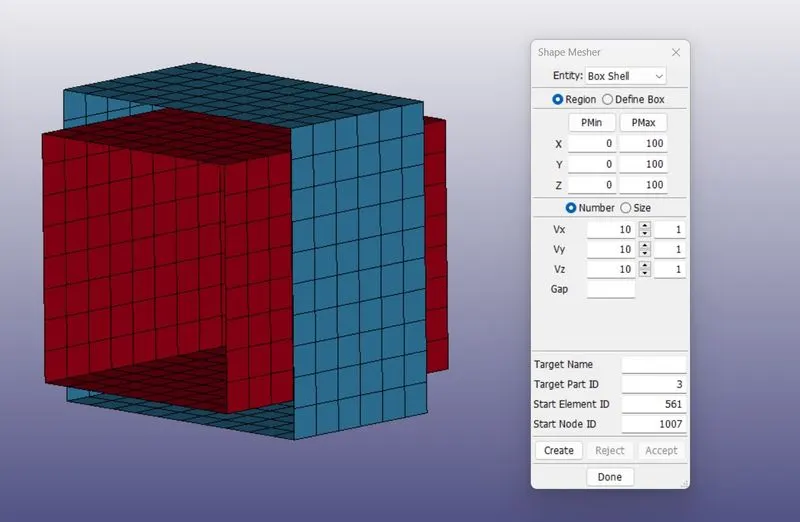
- The Material and Section card are the same as of revolute joint.
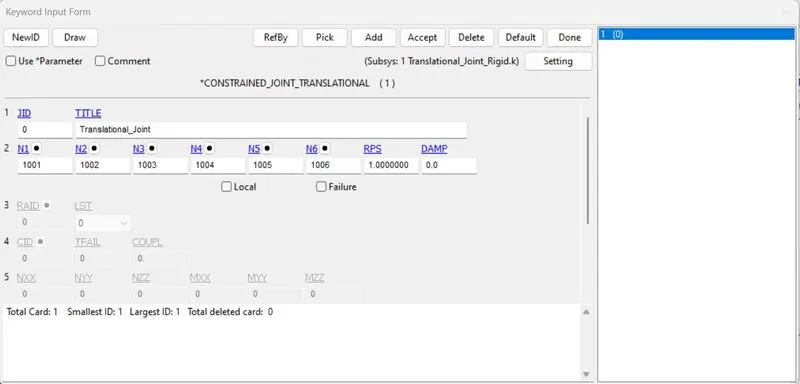
- Now here we have to create three pairs of nodes for constraining using node edit option under element tools. The node pairs 1001,1002 and 1003, 1004 are concident and collinear. the third pair 1005,1006 are concident and slightly away from the axis of the other two pairs in between them. The nodes 1001,1003 & 1005 are constrained to part 1 and 1002,1004 & 1006 to part 2 respectively, using CONSTRAINED_EXTRA_NODES card.
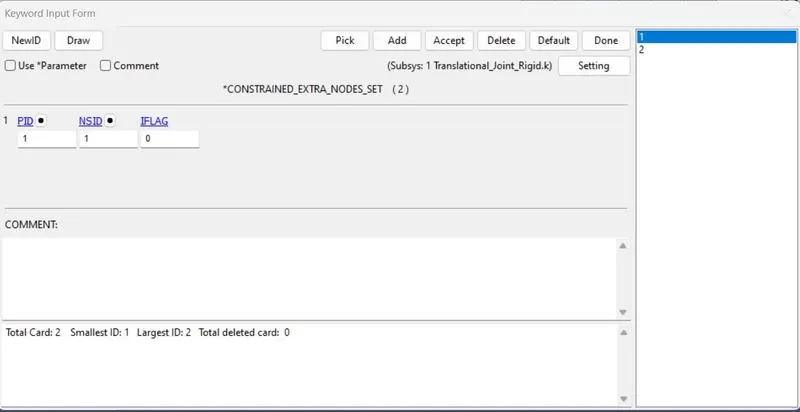
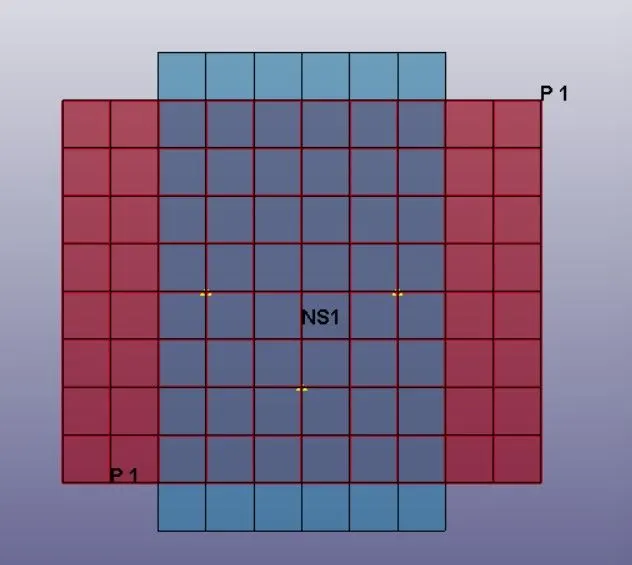
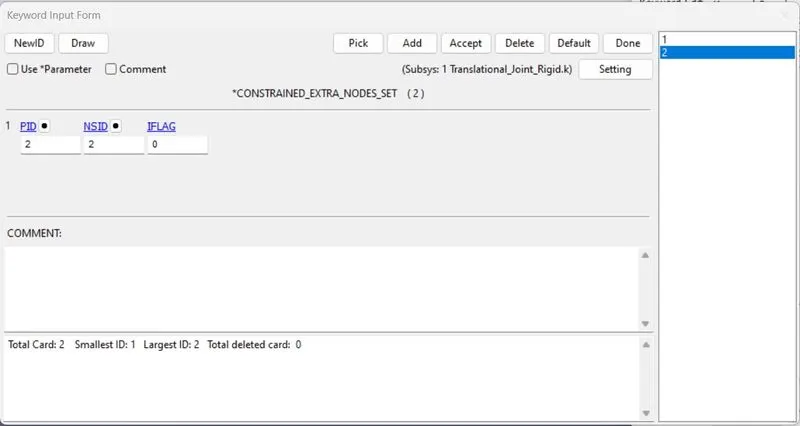
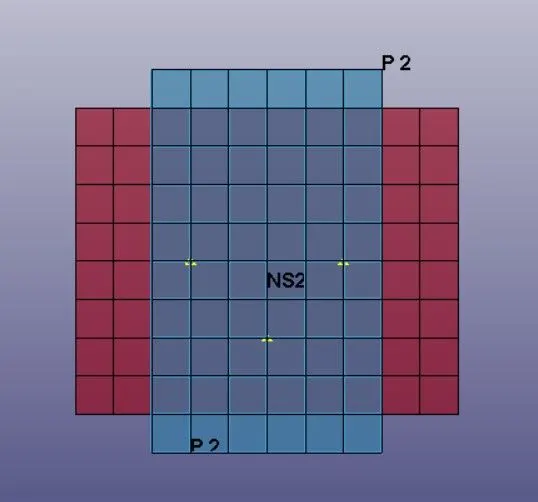
- Translational joint then created between them using CONSTRAINED_JOINT using nodes N1, N3 & N5 of part1 and N2, N4 and N6 of part 2.
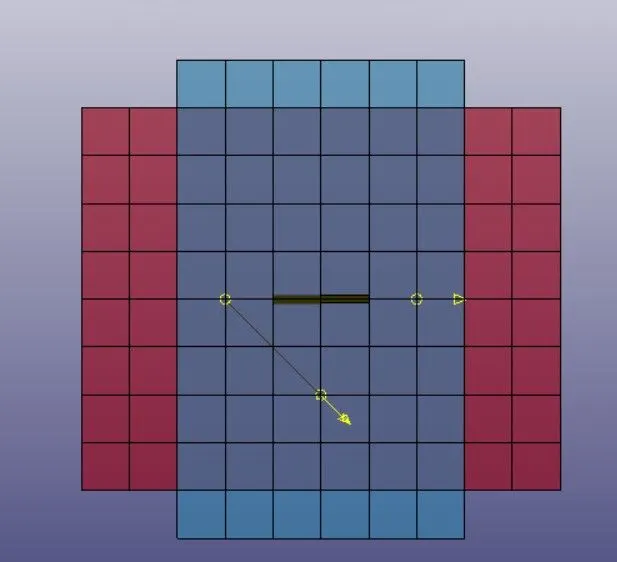
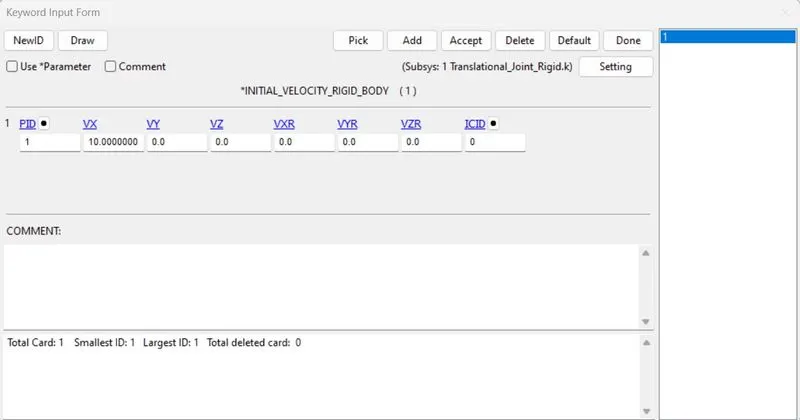
- Part 2 blue is fixed and part 1 red is the moving part. An initial velocity of 10 mm/ms is given to part 1 in the X-axis (translational) direction.
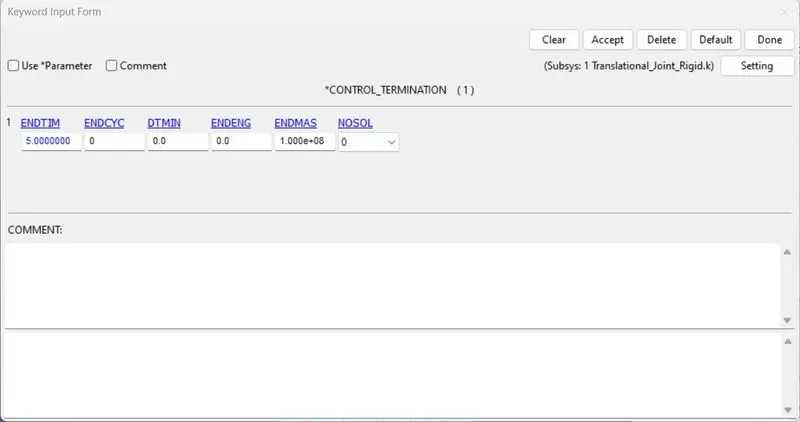
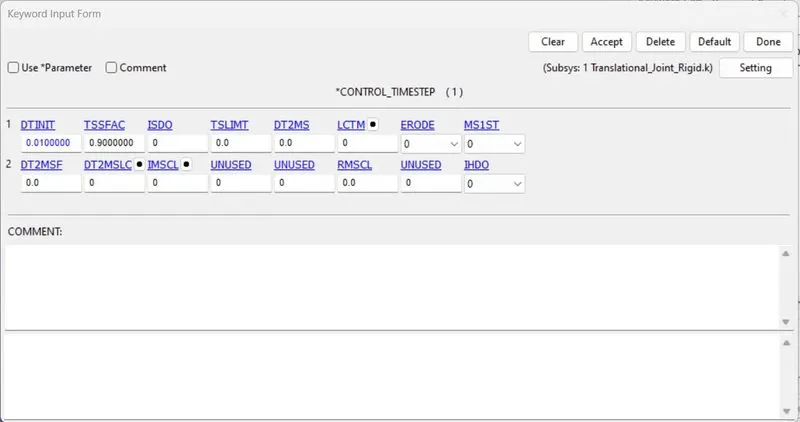
- Here the simulation time is set to run for 5ms and DTINIT is given as 0.01 ms.
JOINTS BETWEEN DEFORMABLE BODIES
1)SPHERICAL JOINT-
- Here also we will follow the same procedures of spherical joint for creating and assigning section, parts, material cards of the parts.
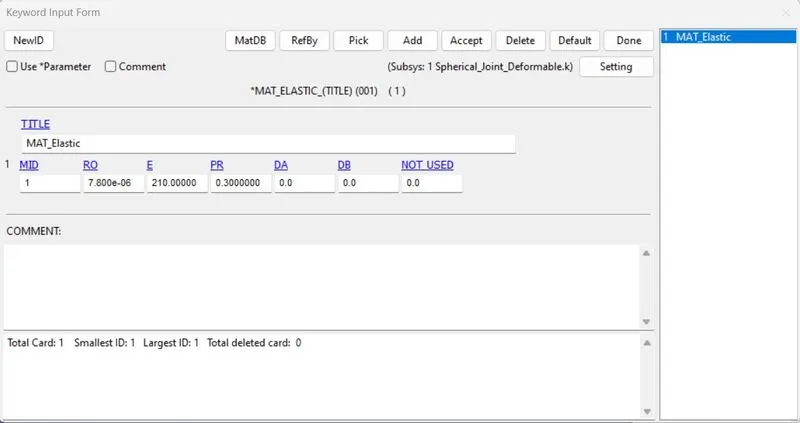
- Instead of MAT_RIGID we will go for MAT_ELASTIC and enter all the required parameters for the material.
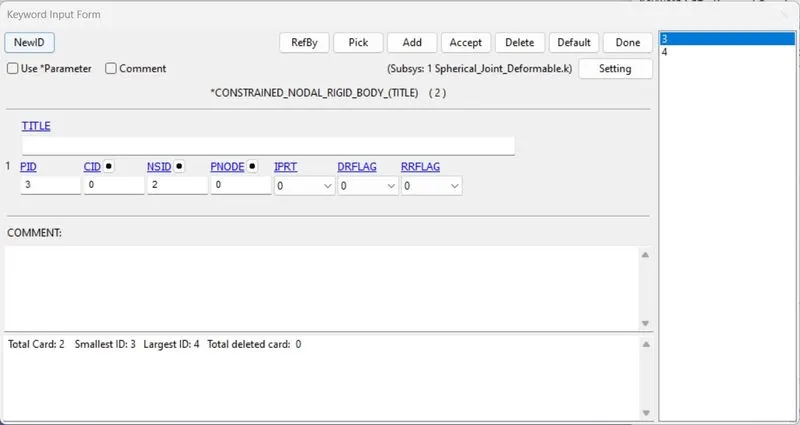
- Now instead of using CONSTRAINED_EXTRA_NODES we will go for CONSTRAINED_NODAL_RIGID_BODY (CNRB). Here we will uncheck PNode option, it is basically used between peripheral nodes of the outer and inner hemispheres for connecting them.
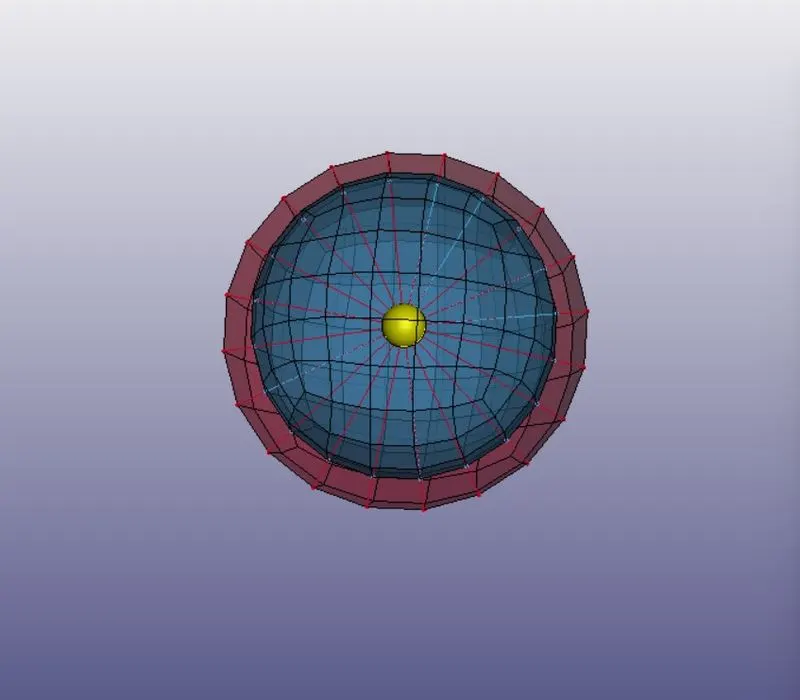
- A spherical joint is then created between them, using the CONSTRAINED_JOINT_SPHERICAL. The first node (305) is constrained to part 1 and the second node (306) is constrained to part 2.
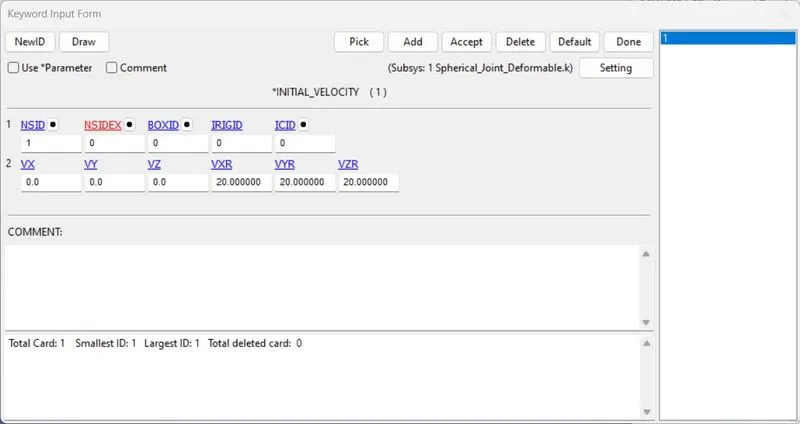
- Instead of INITIAL_VELOCITY_RIGID_BODY we will use INITIAL_VELOCITY to define velocity. In this case we eill apply the initial velocity to part 2 that is inner sphere in all three directions.
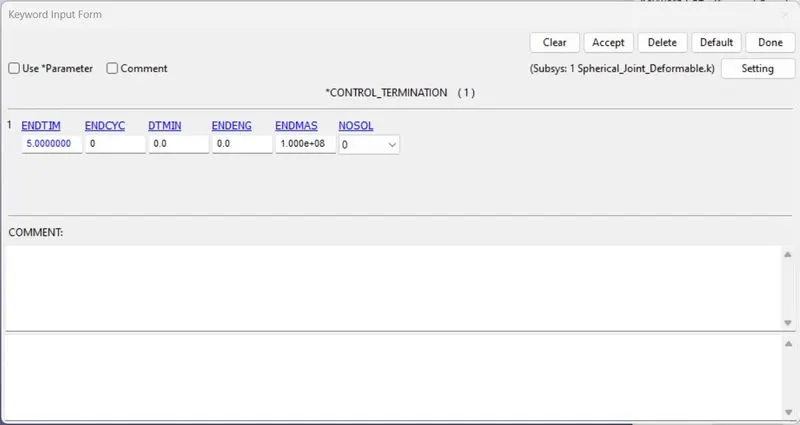
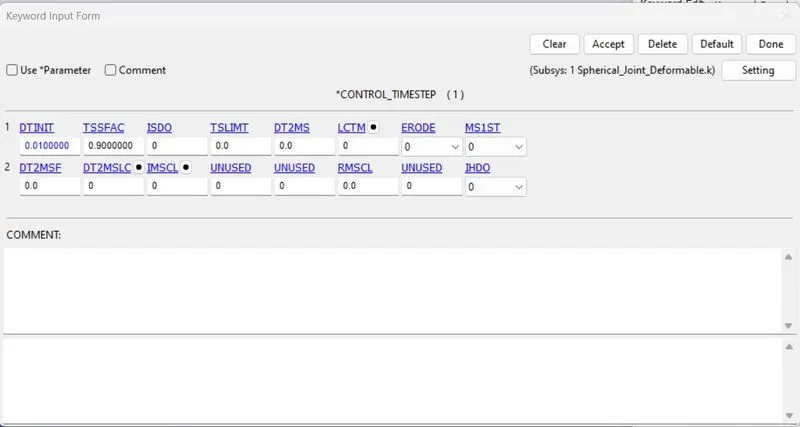
- The simulation is set to run for 5ms and DTINT is given as 0.01 ms.
2) REVOLUTE JOINT-
- Here also we will follow the same procedure of revolute rigid joint for creating and assigning section, parts, material cards of the part.
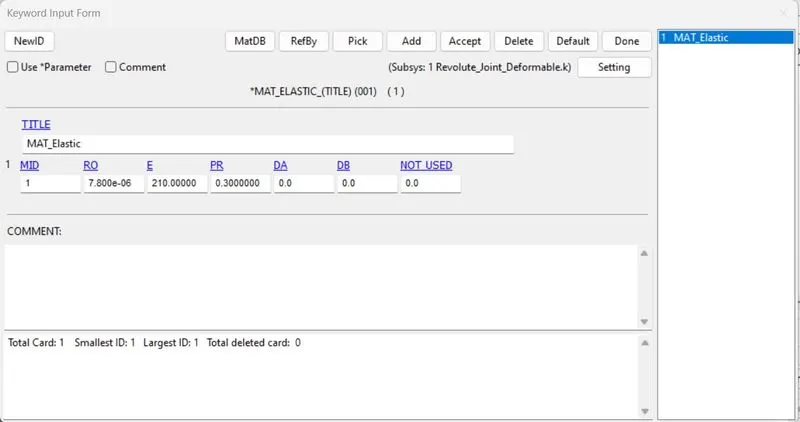
- Material card MAT_ELASTIC is defined with suitable parameters.
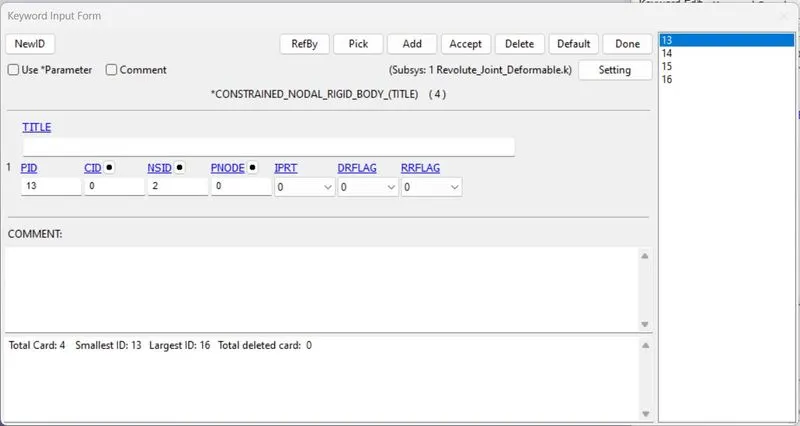
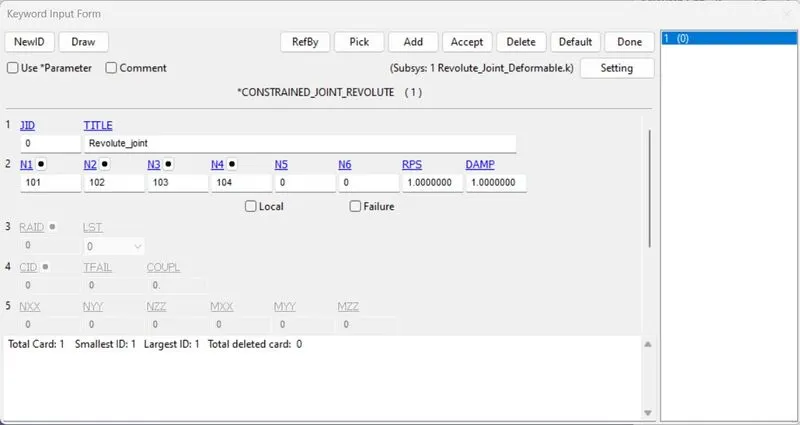
- We will create two pairs of nodes for constraining by using Node edit option under element tools. the node 101,103 are constrained to part 1 and 102,104 to part 2 respectively, using CONSTRAINED_NODAL_RIGID_BODIES card.
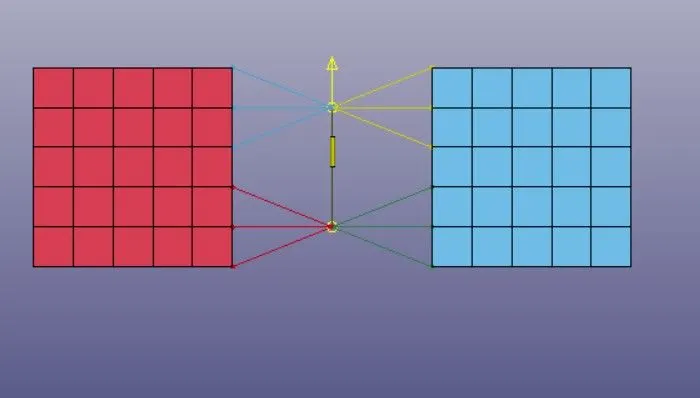
- A revolute joint is then created between them, using the CONSTRAINED_JOIN option using nodes N1 and N3 of part1 and N2,N4 of part 2.
- Part 1 red one is fixed and part 2 blue is moving part the part 1 is fixed with SPC's at all nodes in order to prevent motion and a prescribed motion is given to part 2, similar to the rigid revolute joint.
- A load curve is defined with the required displacement and assigned to LCID.
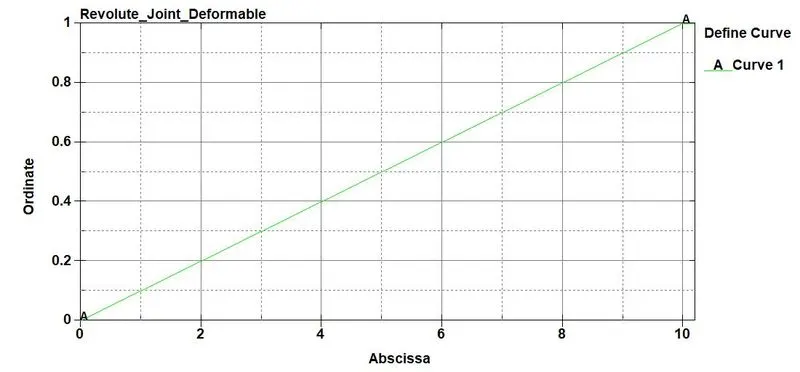
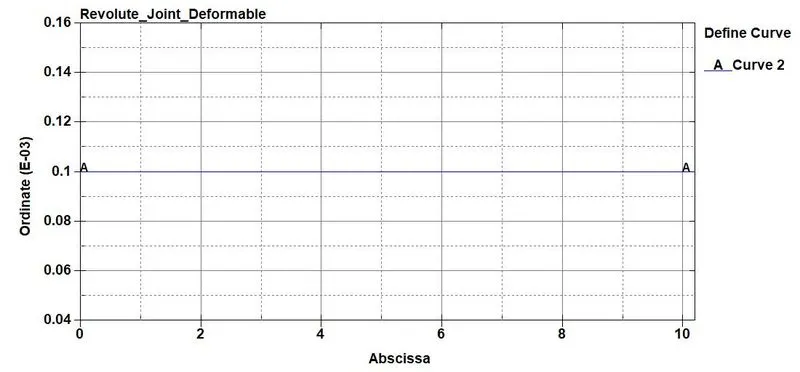
- The control timestep is defined using the above timestep curve in the LCTM and the termination time is given as 10ms.
3)CYLINDRICAL JOINT-
- For cylindrical deformable joint we will follow the same procedure as followed in cylindrical rigid joint.
- Here we will define material card as MAT_ELASTIC card with suitable parameters.
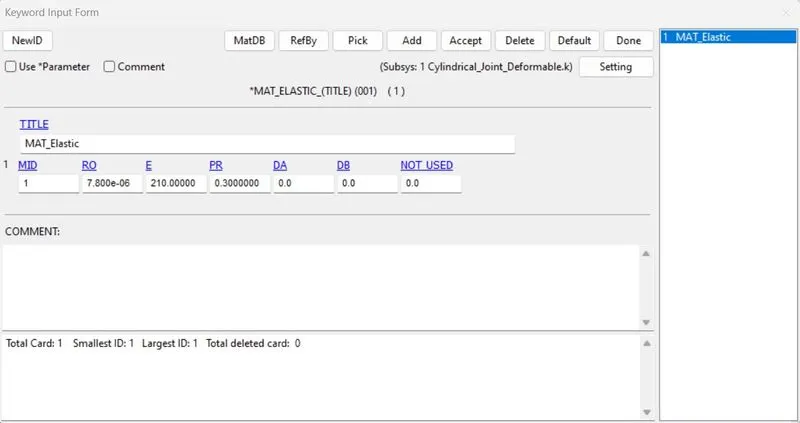
- Now we will create two pairs of nodes for constraining using node edit option under element tools. The node 321,323 are constrained to part 1 and 322,324 to part 2 respectively, using CONSTRAINED_NODAL_RIGID_BODY card.
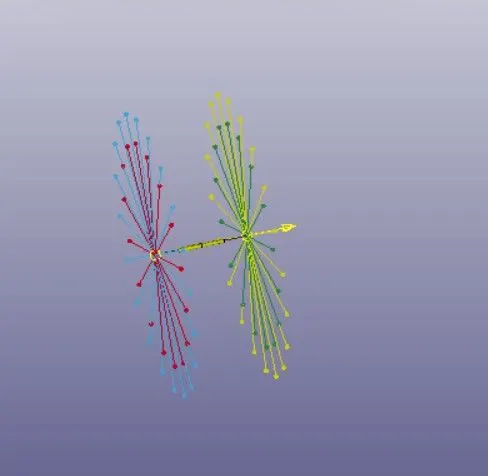
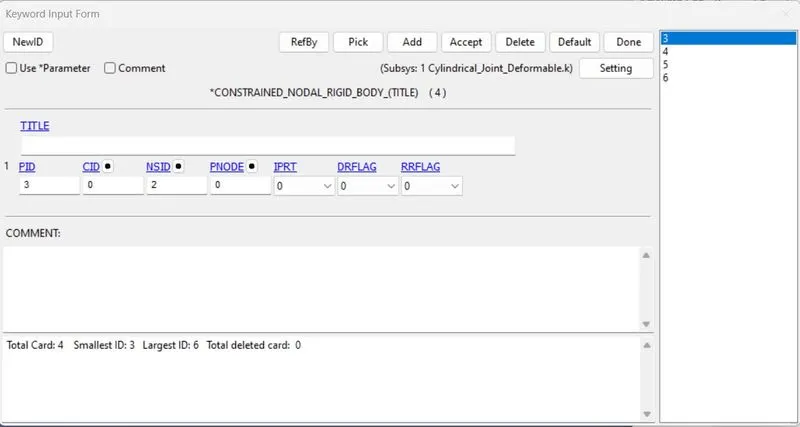
- A cylindrical joint is then created between them, using the CONSTRAINED_JOINT menu using the nodes N1 and N# of part 1 and N2,N4 of part 2.
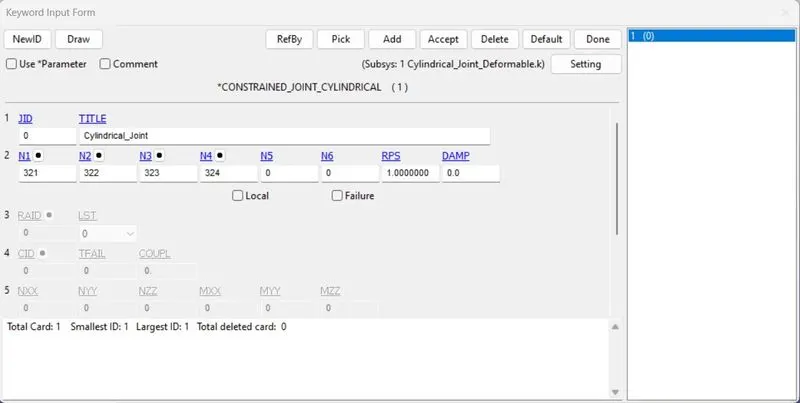
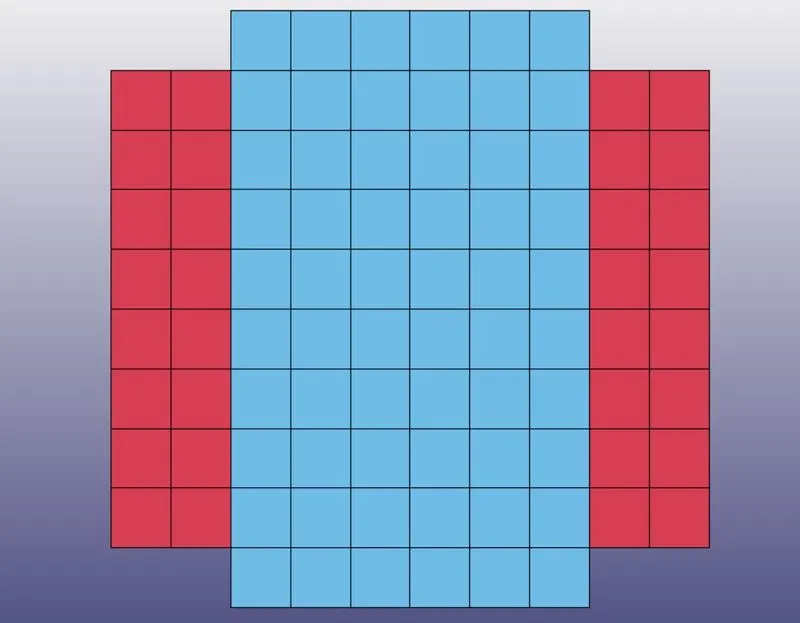
- Part 2 blue one is fixed and part 1 red one is having all DOF's (moving).An initial velocity of 10mm/ms is given to part 1 in the X-Axis (Translation) direction.
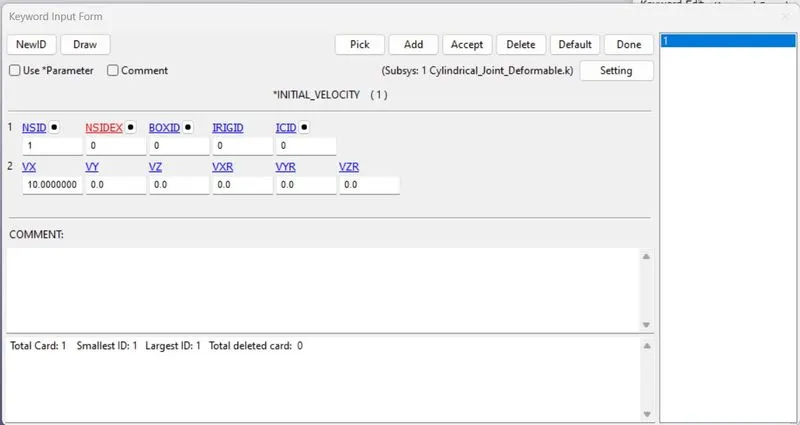
- The simulation is set for 5ms and DTINIT is given as 0.01 ms.
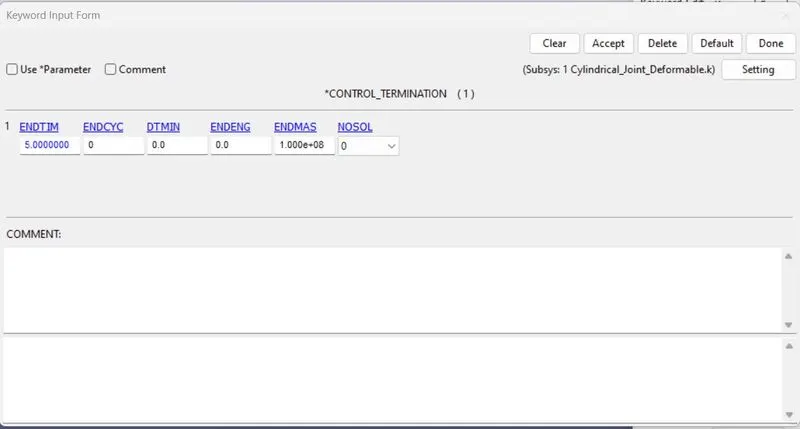
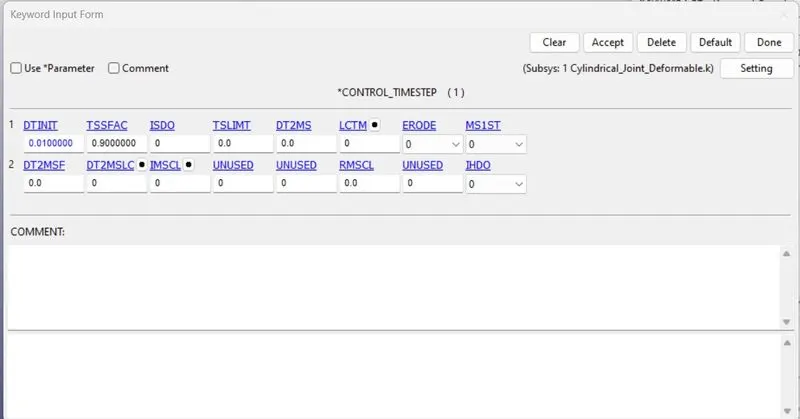
4)TRANSLATIONAL JOINT-
- Here also we will follow the same procedure as of Translational Rigid Joint .
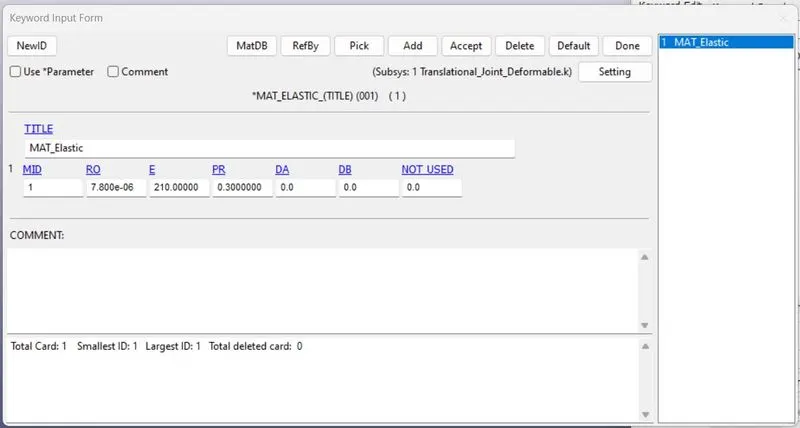
- We will defining the material card MAT_ELASTIC and defining all the parameters.
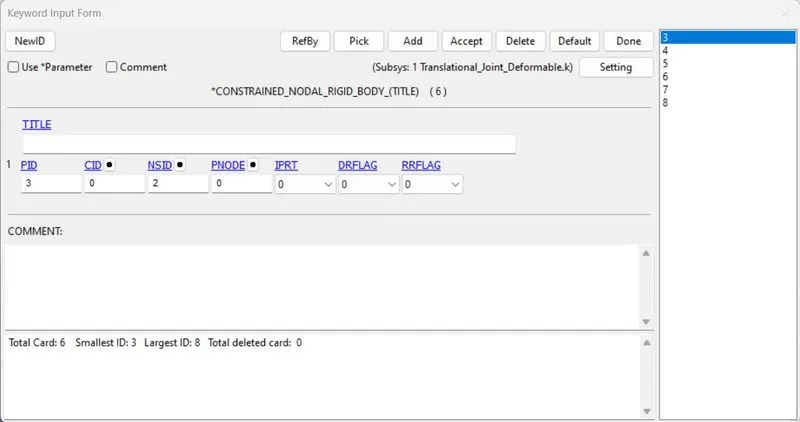
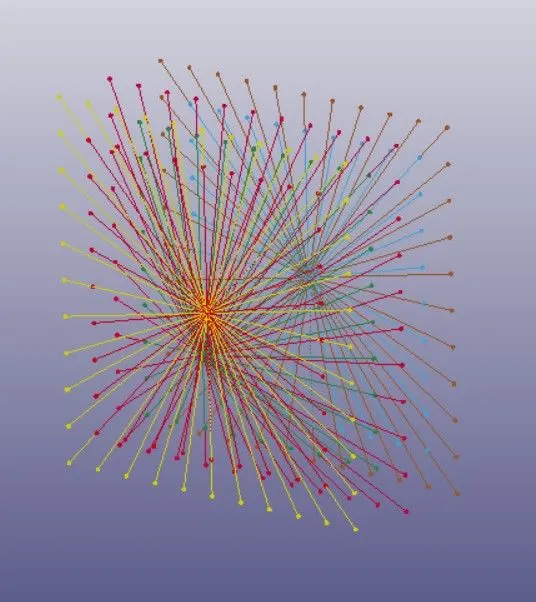
- Now creating CONSTRAINED_NODAL_RIGID_BODY using create entity then Constrained then CNRB. Now uncheck PNnode.Thre pairs of nodes are created for constraining, the node pairs 1001,1002 and 1003,1004 are concident and collinear. The third pair 1005,1006 is concident and slightly away from the axis of the other two pairs, in between them. The nodes 1001,1003 and 1005 are constrained to part 1 and 1002,1004 and 1006 to part 2 respectively using Constrained_Nodal_Rigid_bodies card.
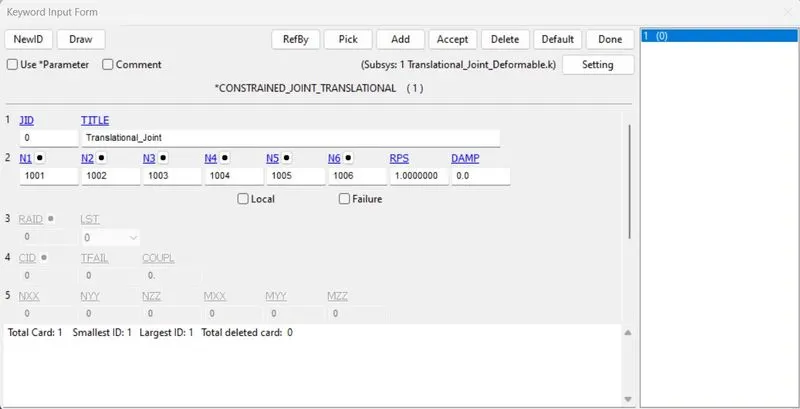
- A translational Joint is then created between them, using the constrained_joint menu, using nodes N1,N3 and N5 of part 1 and N2,N4 & N6 of part 2.
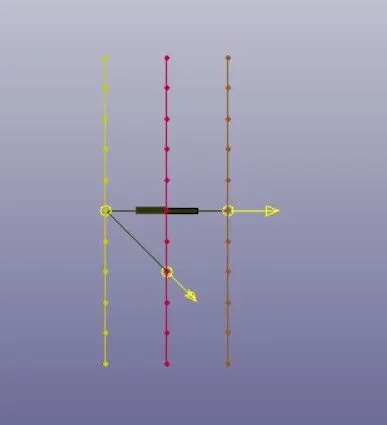
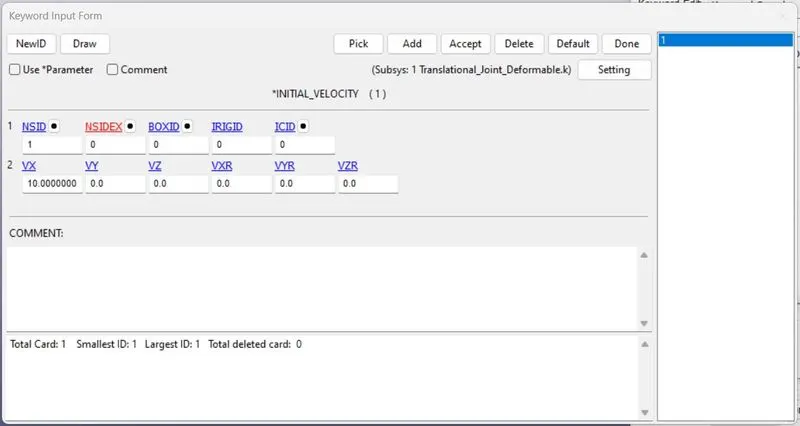
- Part 2 is blue which is fixed and part 1 is red which is moving part. An initial velocity of 10mm/ms is given to part 1 in the X-Axis (Translation) Direction.
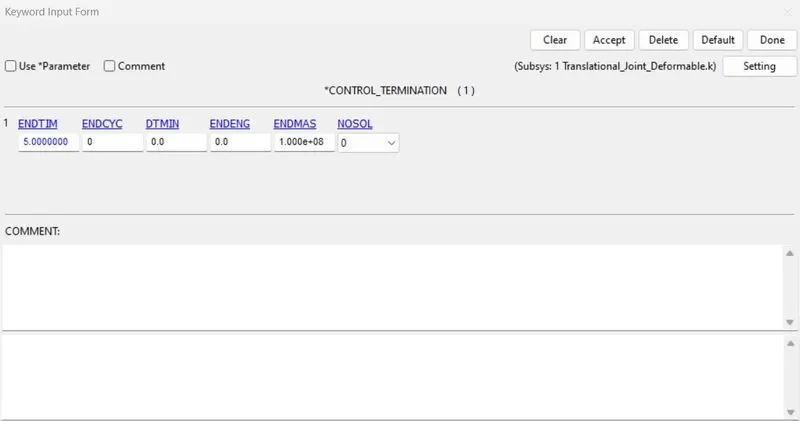
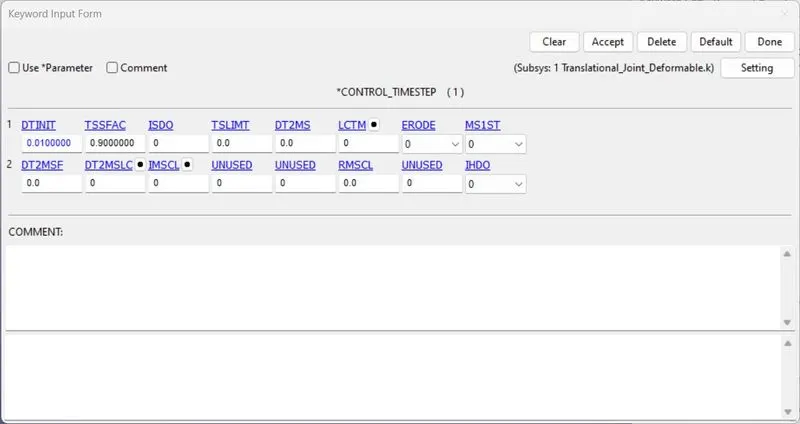
- The simulation is set to run for 5 ms and DTINIT is given as 0.01 ms.
CONCLUSION-
- The necessary keyword files are created for joints between rigid bodies such as Spherical, Revolute, Translational, Cylindrical Joints using CONSTRAINED_EXTRA_NODES and CONSTRAINED_JOINT tools.
- The necessary Keyword files are created for joints between deformable bodies such as Spherical, Revolute,Translational, Cylindrical Joints using CONSTRAINED_NODAL_RIGID_BODY(CNRB) and CONSTRAINED_JOINT tools.
- Finally ran the simulation for the respective joints and input files are attached with this challange.