Week-11 Challenge: Braking
1. For a defined driving cycle, calculate the energy required for braking.
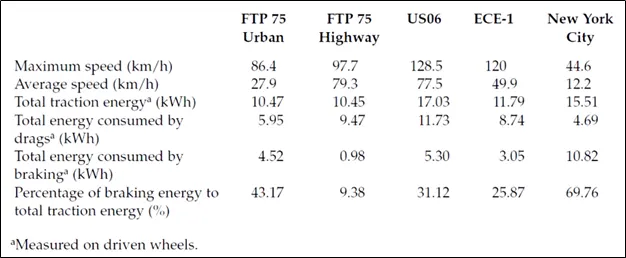
The braking performance is one of the most important concerns in vehicle safety. In urban area driving, a significant amount of energy is consumed in braking. Electrification of vehicles makes it feasible to recover some of the energy lost in braking.
A hybrid braking system was developed to ensure the efficient braking of the vehicle and recovering the braking energy. The design and control objectives of such a hybrid braking system are to ensure sufficient braking force to quickly reduce the vehicle speed, properly distributing the brake force to the front and rear axle, and also recover as much braking energy as possible. So understanding of braking energy of a driving cycle is important.
Now, it is also important to mention that braking energy also depends upon the type of driving cycle i.e. the higher number of time the vehicle will have rapid speed changes and will come to rest then the braking energy will automatically rise for that particular drive cycle than other driving cycle where the rapid speed changes don't occur.
Suppose we have UDDS cycle: -
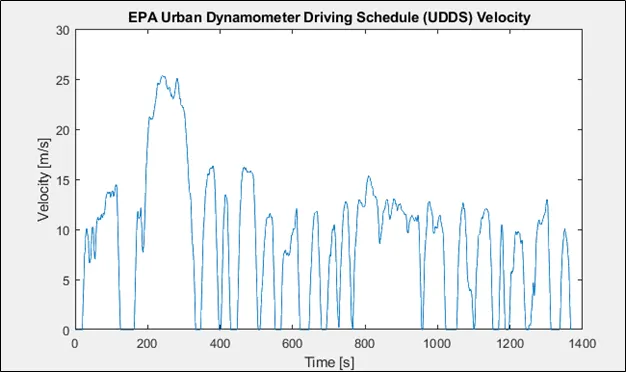
We can observe in this test cycle vehicle needs to stop in given time at some instance also for this we will apply brakes. We will calculate the power require for braking operation.
Please refer the attached sheet for complete calculation of Deacceleration energy require in UDDS cycle.
https://drive.google.com/file/d/1iUzRCWs9wNajJxM-nLx9wDF7rLRJqpOV/view?usp=sharing
- To reduce speed from 80 to 40 Kmph in 20 sec = 292 KJ
- To reduce speed from 80 to 0 Kmph in 10 sec = 560 Kj
2. Why electric motor can’t develop braking torque at high speed similar to starting? How electric and mechanical brakes are coordinated ?
The torque-Speed characteristic of motor is not exact same in the braking and motoring region.
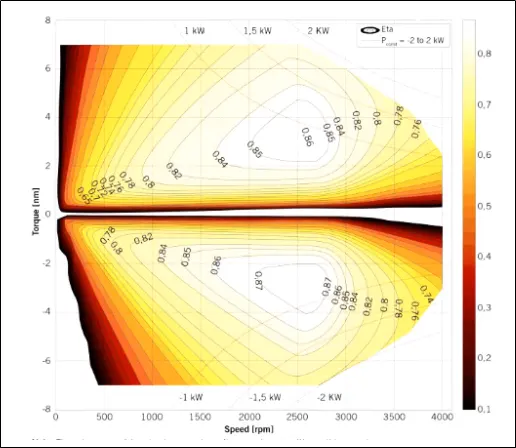
This is torque-speed contour plot of motor with efficiency.
We can see that, at the time of accelerating vehicle at starting the maximum torque available motor is operating at constant torque region, in that motor will have maximum torque available, but as motor starts deaccelerating motor characteristics are shifted towards braking region, in this we don’t have max torque available for braking as motor is already running at higher speed.
Due to this operation, electric motor can’t develop braking torque at high speed similar to starting
Electrical and mechanical braking systems can are coordinated by using Brake strategy subsystem
1) Serial Braking Strategy
2) Parallel Braking Strategy
Implementation of serial braking strategy
Once the brake pedal is pressed and depending on the level of depression, a brake torque is sent. Now this brake torque passes into the brake control strategy block. Here, firstly it is checked if battery state-of-charge is below 80% which is set as the maximum permissible level of charge. If that condition is satisfied, then the battery is recharged. The brake torque requested is compared to the maximum regenerative torque limit of the motor-generator. If the overall brake torque requested is less than or equal to the maximum regenerative torque, then the vehicle brakes purely on regenerative torque and the battery is charged. The amount of charge ultimately put in depends also on the motor-generator operation efficiency and the battery charging efficiency. If the overall brake torque requested is greater than what the motor-generator can provide, then the friction brakes kick-in. Now since the vehicle is front driven, it is checked if the total brake torque requested from front is less than or equal to maximum regenerative torque capability of motor-generator. If yes, then front braking is provided purely by regeneration and rear (non-driven axle) by friction. Once the total brake torque request increases further, then front friction brakes (driven axle) comes into play in combination with rear friction brakes and front regenerative braking, to satisfy the overall brake torque demand. This has been represented in a chart manner
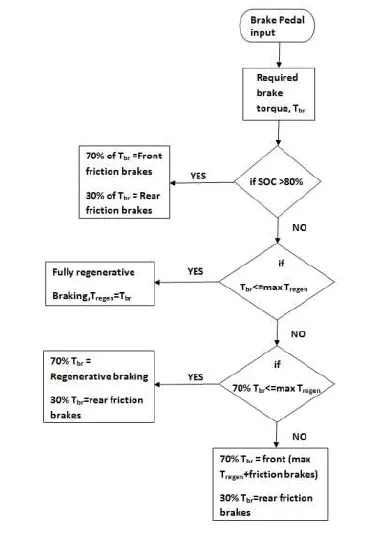
Parallel Braking:-
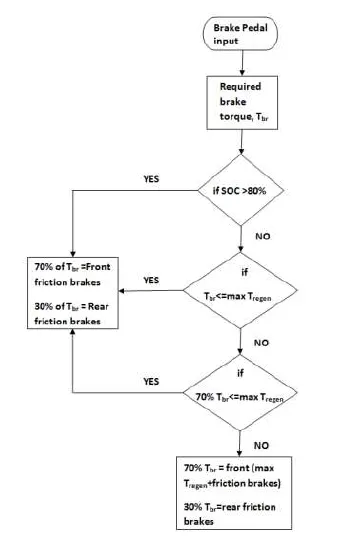
Once the brake pedal is applied and a desired overall brake torque request is sent from the driver block. This brake torque on passing through the brake control strategy gets divided between regeneration and friction braking at all times. The strategy is so modeled with the comfort and brake pedal feel in mind. As a parallel regenerative braking is an add-on to the conventional systems, it is devoid of any integrated control. So to make the transition and co-performance of regenerative braking with friction smooth, it is assigned in such a way that, there is a clear division between the amount of brake torque that will be achieved from regeneration and friction braking. On application of brakes and in keeping with the design of the motor-generator, it is designed to operate generator in a constant generator torque region. Motor-generator can provide a maximum of 322 Nm of generator torque at or under the base speed. The generator is scaled such that the base speed of the generator corresponds to a velocity of 124 [kmph], which is the maximum speed limit on most highways. Hence regeneration works, as long as the vehicle is braking from a speed of under 124 [kmph] and the requested brake torque on the front driven wheels, after the front-rear brake split is greater than or equal to maximum generator torque. If that condition is satised, then regenerative and friction braking operates in tandem else it’s just the friction brakes at the driven and non-driven axle. This has been represented in a ow chart manner in the g.1.5.
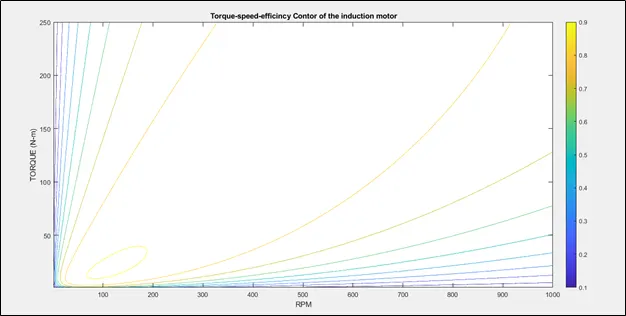
3) Make a MATLAB program which plots contour of given motor speed, torque and efficiency values. Attach the code as a .m file attach a screenshot of all the plots.
clear all;
close all;
clc;

Torque= linspace(1,250,250)             %Input Torque
Speed= linspace(1,1000,250)             %Input Speed
[w,T]= meshgrid (Speed,Torque);         %Converting to 2D array

Kc= 0.3;         % Coppper loss constact
Ki= 0.009;       % Iron loss Constant
Kw= 0.00005;     % Windage loss constat
C=30;            % constant loss

Pout= w.*T;         %Output Power
C_loss=Kc*(T.^2);   %Copper loss
I_loss=Ki*w;         %Iron loss
W_loss=Kw*(w.^3);    %Windage loss

Pin=Pout+C_loss+I_loss+W_loss+C;    %Input power
eff=Pout./Pin


contour(Speed,Torque,eff)
title('Torque-speed-efficincy Contor of the induction motor');
xlabel('RPM');
ylabel('TORQUE (N-m)');
Syntax Explanation:-
In this program we are plotting speed Vs torque characteristic with the efficiency values. For this, first we are defining speed and torque values of motor.
Then as we need to draw a contour, we convert this 1D array to 2D array using “MESHGRID” command.
Then we are defining the Cu constants for losses, like Cu loss constants, iron loss constant and windage loss constant.
Pi=Pout+Kc*T^2+Ki*w+Kw*^3+Constat loss
Using this formula, we calculate the efficiency and then plot the contour.
Result:-