Week-11 Challenge: Braking
Driving cycle
Driving Cyle is define as Speed V/s time characteristics of electric vehicle which helps to calculate fuel consumption for motor
useful for vehicle model simulation
Performance analysis of electric vehicle
Battery state and energy consumption analysis
Breaking
Kinetic energy in the form of heat dissipation takes place when brakes are applied in electric vehicle which follows law of conservation of energy
E= 1/2 mv^2
m = mass of the vehicle in Kg
v = velocity of the vehicle in m/s
E = Kinectic energy in KJ
velocity will be (v-vo) where, V is the speed of the vehicle, Vi the speed of the vehicle which brought to standstill condition
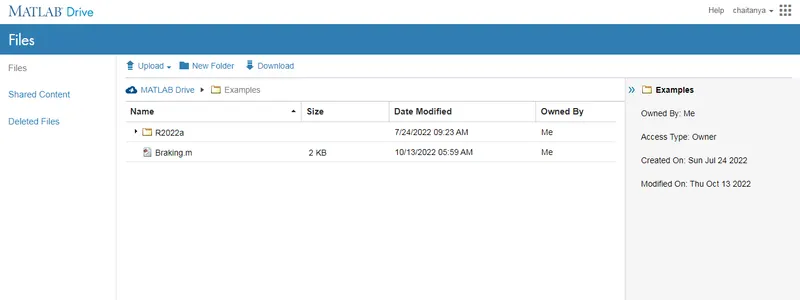
To access matlab file for program 2 and 3
step 1) /MATLAB Drive/Breaking.m
step 2) Matlab Drive
step 3)Matlab Drive Online
step 4)select Braking option
Total Energy consumed during Acceleration is 3.980957 KJ
The losses in the motor are classified into four types
1. Copper loss:
Copper losses are given by I^2 * R loss. Torque is proportional to the current. So the copper loss is given as:
Copper loss = Kc * T^2
2. Iron loss:
Iron losses are due to magnetic losses.
Iron loss = Ki * ω
3. Windage loss:
loss due to the friction between air and the rotor.
Windage loss = Kw * ω^3
4. Constant loss:
Constant losses in the motor are considered as C.
Total loss = (Kc * T^2) + (Ki * ω) + (Kw * ω^3) + C
Outpower can be calculated by multiplying the torque & velocity
Po = T * ω
So input power is sum of output power & losses.
Pi = Po + (Kc * T^2) + (Ki * ω) + (Kw * ω^3) + C