Week-11 Challenge: Braking
1)
For a defined driving cycle, calculate the energy required for braking.
Calculating the energy required for braking of UDDS Drive Cycle-
Braking: Braking is a condition to slow down or stops a moving vehicle as required. There are several techniques to apply brakes, which can be mechanical or electrical. The most commonly used technique is by applying friction. It consumes energy .The consumed kinetic Energy can be derived as following equation-
Braking Energy =1/2*mv^2
Where, Braking Energy is the kinetic energy in unit of Joule.
m- Total Mass of the Vehicle (Vehicle Mass + PayLoad) in unit of Kg.
v- (Initial Velocity-final Velocity) in unit m/s.
For Example if Initial speed of a vehicle is 35m/s and final speed is 20m/s. The mass of the vehicle is 800kg. Then the required kinetic energy for
Braking is - 0.5(800*15^2)=90000=90k
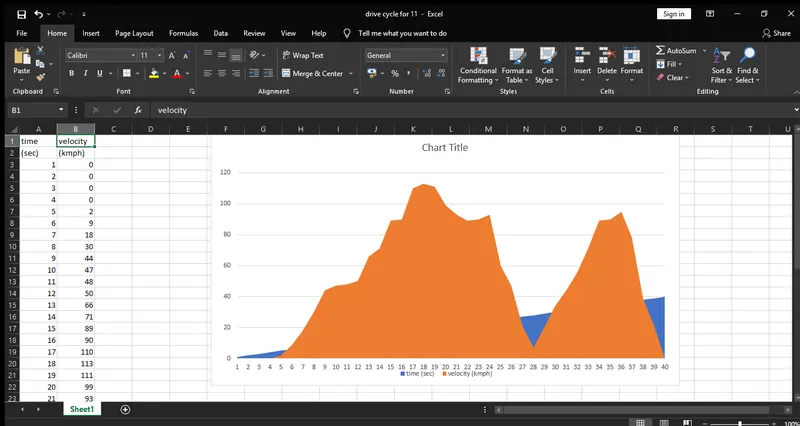
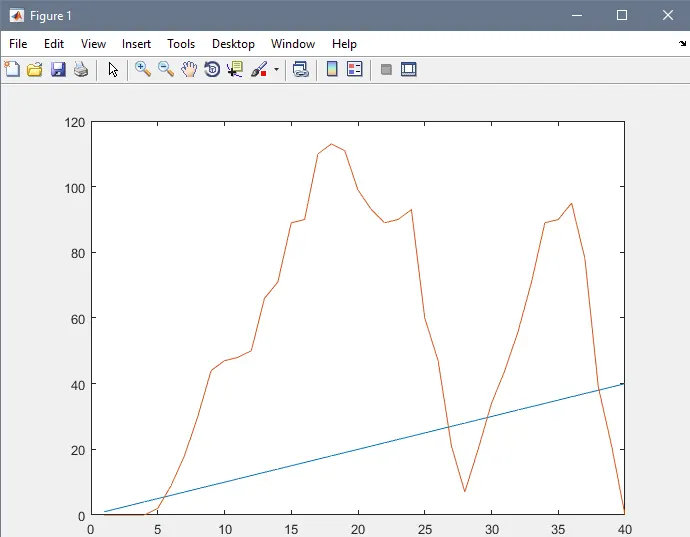
Here for a Drive cycle the required braking energy is calculated for each second of time to slow down or stop the vehicle- Braking Energy
Calculation for UDDS Driving Cycle
2)
Why electric motor can’t develop braking torque at high speed similar to starting? How electric and mechanical brakes are coordinated?
The braking torque in a electric motor is not as high as that of the accelaration torque at higher speeds.this can be attributed to many diffferent reasons.the rate of discharge of the battery is higher than the charging rate it can be said that the discharge rate can betwice as that rate of charging rate.there are other limitations to themotors in the form of power converters too.this power converter is customised 3 phase inverters which are bi directional as it needs to comvert regnerative braking energyback to dc current for the battery and this reduces the efficiency of the power converter at low speedsregenerative braking is very high as speed increases.the regenerative braking reduces as the effictiveness of inverter plays an important role and the overall efficiency reduces resulting in reduced braking torque.hence for effective braking at high speeds,we use a combination of hydraulic brake and regenerative brake.
There are different ways of coordinating between the hydraulic brakes and regnerative brakes.one of the brake control startegies involves series connection where both brakes are connected together which implies that in this scenario both brakes are used together and the next one in the parallel connection where either of the two barkes is operated individually whithout relying on one another depending on the braking requirements.
Types of control strategy
l.series: the braking is applied one after the other .either of regenerative and mechanical braking is applied alternatively.
2.parallel:both the brakes are applied.the regenarative and mechanical are applied in parallel.
when the brake pedal is applied it supplies the hydrualic fluid to the disc to slow the tires at the same time when the accelaration pedal is lifted a certain in amount of electricbrakes are applied at high speed,since the braking force is required is a high large amount og hydrualic brakes are applied and once the speed is reduced and the torque value is also high so the elctric brakes become pre dominate so the battery charging occu efficiently.the ECU system witha feedback system to find the torque region and regenerative braking predominates in the high torque region.
3)
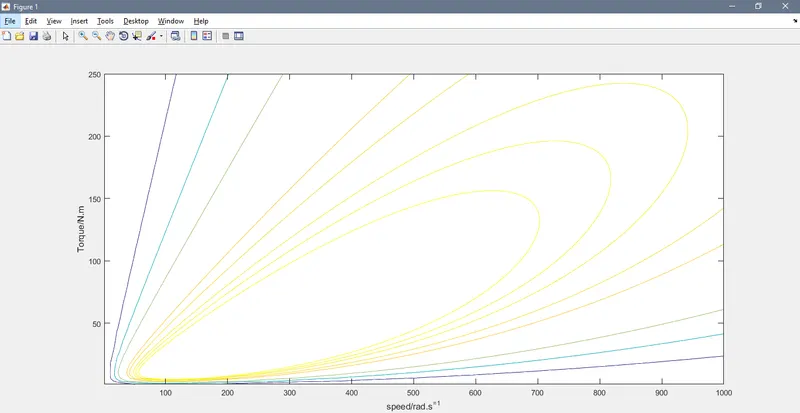
Make a MATLAB program which plots contour of given motor speed, torque and efficiency values. Attach the code as a .m file attach a screenshot of all the plots.
% A Program for plotting efficiency contours for
% electric motor.
%the x axis corresponds to motor speed (w),
%and the y axis to torque T.
% first, set up arrays for range.
x=linspace(1,1000);%speed,N.b. rad/s NOT rpm
y=linspace(1,250);%0to 40 N.M
% Allocate motors loss constants.
kc=0.2; % for copper losses
ki=0.008;% for oron losses
kw=0.00001; % windage losses
ConL=20; % for constant motor losses
% Now make mesh
[X,Y]=meshgrid(x,y);
outputpower=(X.*Y); % Torque x speed = power
B=(Y.^2)*kc; % Copper losses
C=X*ki; % Iron losses
D=(X.^3)*kw % windage losses
Inputpower = outputpower + B + C + D + ConL;
Z=outputpower./Inputpower;
% We now set the efficiencies for which a contour
% will be plotted.
V=[0.70,0.80,0.85,0.90,0.91,0.92,0.925,0.93];
box off
grid off
contour(X,Y,Z,V);
xlabel('speed/rad.s^=^1'),ylabel('Torque/N.m');
hold on
% Now plot a contour of the power output
%The array output power has
% already been calculated.We draw contours at
% 3 and 5 kW.
V=[8000,10000];
contour(X,Y,Outputpower,)