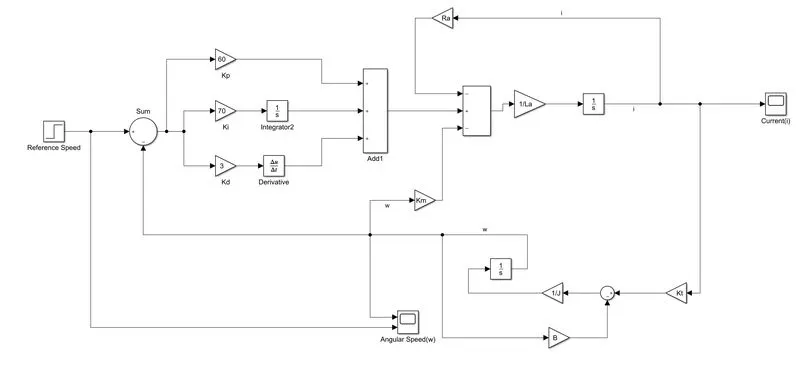
Project - Speed Control of a Direct Current (DC) motor
Speed Control of a Direct Current (DC) motor
Design parameters of DC Motor :
J = 0.01 : moment of inertia in kg-m^2
B = 0.1 : Motor viscous friction constant in N-m-s
Km = 0.01 : back EMF constant in v/rad/s
Kt = 0.01 : Motor torque constant in N-m/amp
Ra = 1 : Resistance of armature circuit in ohms
La = 0.5 :Inductance of the armature circuit in henries
Mathematical Modelling :
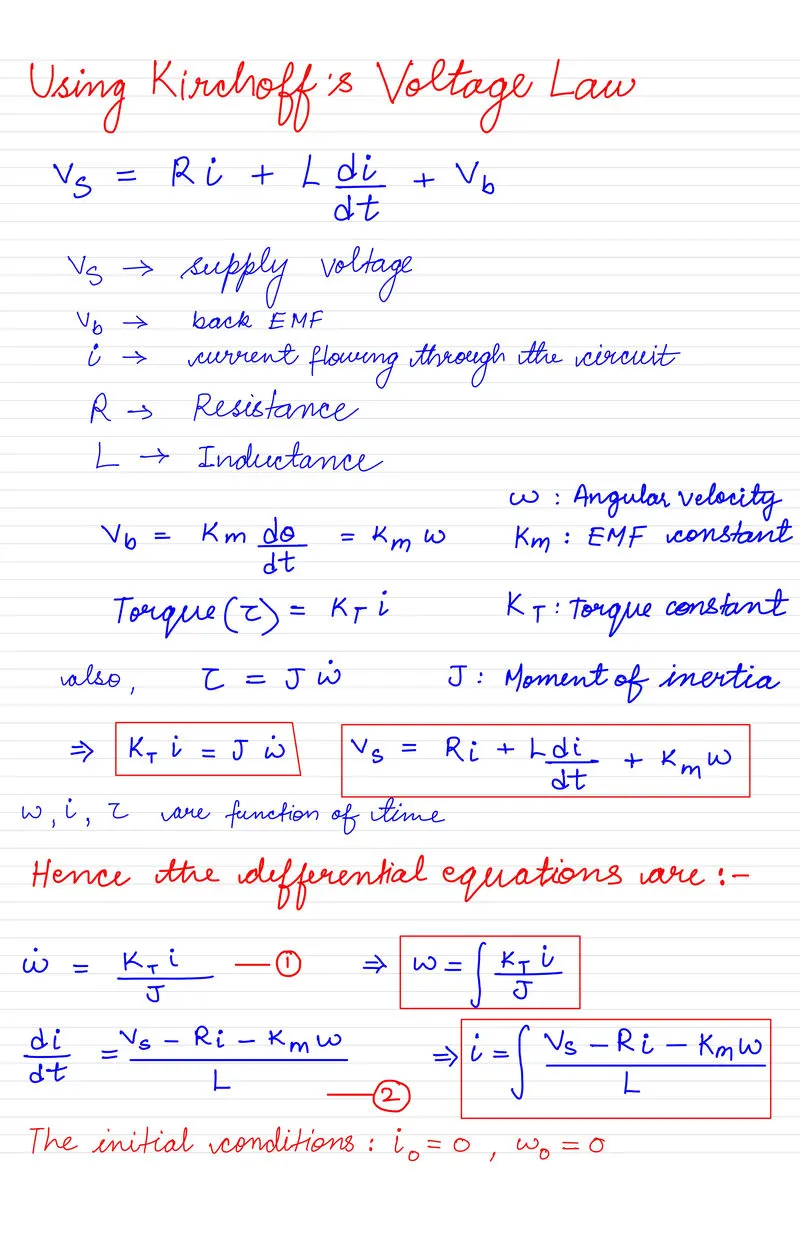
MATLAB Script for the design parameters:
% Design parameters of DC Motor
J = 0.01; % moment of inertia in kg-m^2
B = 0.1; % Motor viscous friction constant in N-m-s
Km = 0.01; % back EMF constant in v/rad/s
Kt = 0.01; % Motor torque constant in N-m/amp
Ra = 1; % Resistance of armature circuit in ohms
La = 0.5; %Inductance of the armature circuit in henries
r = roots([J*La (J*Ra + B*La) (B*Ra + Kt*Km)]);
A = [-B/J Kt/J; -Km/La -Ra/La];
B1 = [0; 1/La];
K = place(A,B1,r);
Kp = K(1);
Kd = K(2);
Ki = 15;
Poles : -9.9975, -2.0025
From the pole placement method:
Kp = -1.4762e-15
Kd = 2.2204e-16
Control Design Objectives :
1. Settling Time < 2 seconds
2. Overshoot < 5%
3. Steady State Error < 1%
Using the pole placement method , the control design objectives were not met, hence after several trial and errors,
Kp = 60, Ki = 70 , Kd= 3 are taken for finer feedback control.
Now,
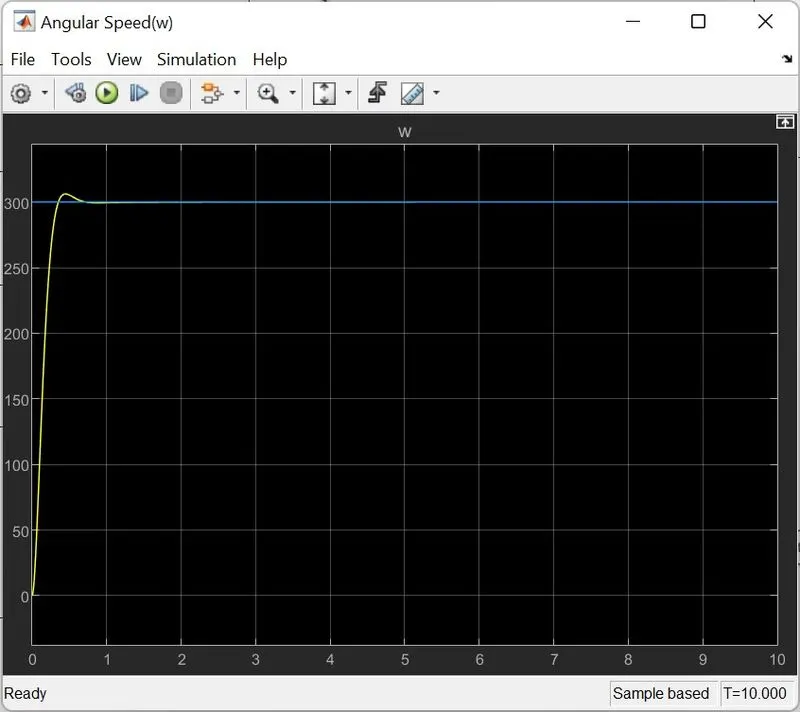
For reference, a step input of speed of 300 rpm, initial value = 0 and step time = 0 was taken
Sample Time = 10 seconds
Solver for modelling : ode4 (Runge-Kutta)
Fixed Step Size = 0.001
Blue : Reference
Yellow : Output Speed
Observations from the output speed :
1. Settling Time < 1 sec (less than 2 sec)
2. Overshoots to 310 rad/sec, then settles to 300 for the rest of the time
[(310-300)/300] *100 = 3.33% overshooting ( less than 5%)
3. Steady state error = 300-300 = 0 ( less than 1%)
Hence, the control design objectives are met.
Blocsks used :
Step , Integrator, Derivative, Gain, Scope, Sum , Add