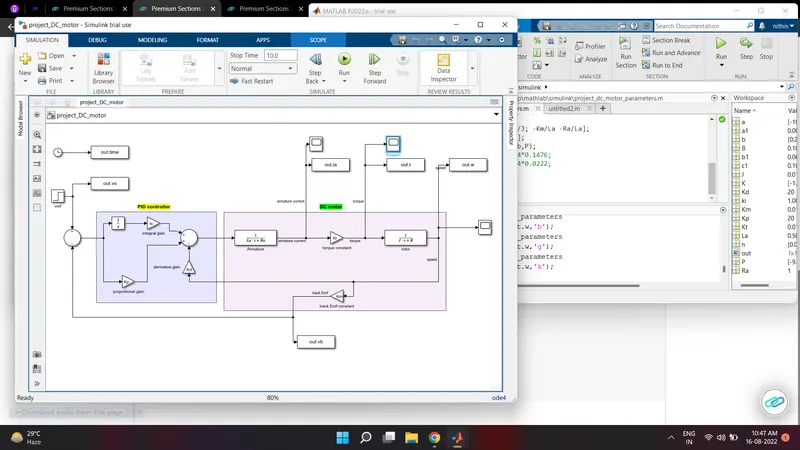
Project - Speed Control of a Direct Current (DC) motor
conditons considerd for DC motor
J = 0.01; % moment of inertia of motor(kg-m^2)
B = 0.1; % motor viscous friction constant (N-m-s)
Km = 0.01; % back EMF constant (v/rad/s)
Kt = 0.01; % motor torque constant in (N-m/amp)
Ra = 1.0; % resistance of armature circuit(ohm)
La = 0.5; % inductance of armature circuit(henrry)
a1 = J*La; % charecteristic equation coefficients
b1 = J*Ra+B*La;
c1 = B*Ra+Kt*Km;
n = [a1 b1 c1];
P = roots(n); % poles
a = [-B/J Kt/J; -Km/La -Ra/La];
b = [0; 1/La];
K = place(a,b,P);
%Kp = 1.0e-14*0.1476;
%Kd = 1.0e-14*0.0222;
at first the gain was set as kp and kd as poles and ki =0 the resulting speed dosent matches the requirements (settling time more than 2 sec was observed). after that the ki was increased then the overshoot exeeded to more than 5%.
therfore the kp kd and ki it taken as zero and then selected accordingly.
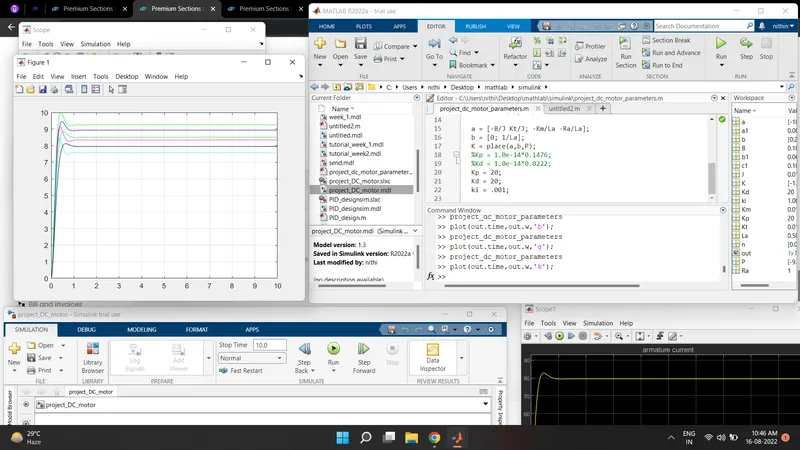
At
Kp = 20;
Kd = 20;
ki = .001;
the speed satisfies the requirement of oveshoot less than 5%, settling time lessthan 2sec and steady state error lessthan 1%.
at the givan 12v input the dc motor produces a speed of approx 8rad/sec. ie 76rpm.