Project - Speed Control of a Direct Current (DC) motor
Aim:- To desin a simulink model for a Direct Current (DC) motor. Use the PID contoller to control the speed of the motor.
First I will write all the parameters of required for DC motor.
The parameter for DC Motor
j=0.01;% moment of inertia
B1=0.1; % motor viscus constant
km=0.01; %back emf constant
kt=0.01;% motor torque constant
Ra=1; % resistance of armature circuit
La=0.5; %inductance of armature circuit
Simulink Model of DC Motor
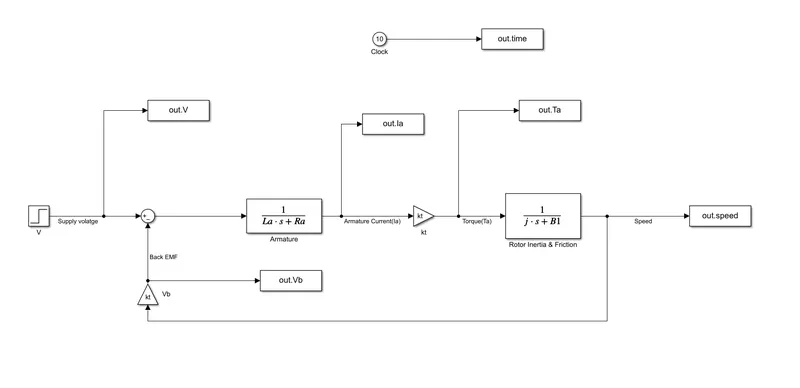
The result we got when we applied a Voltage of 230 V
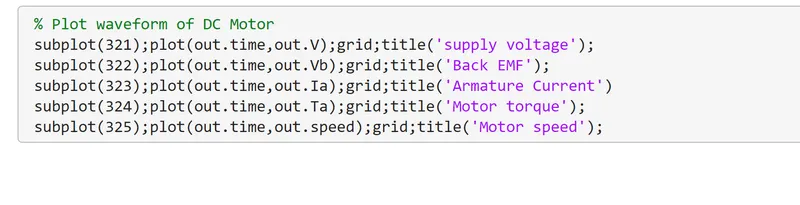
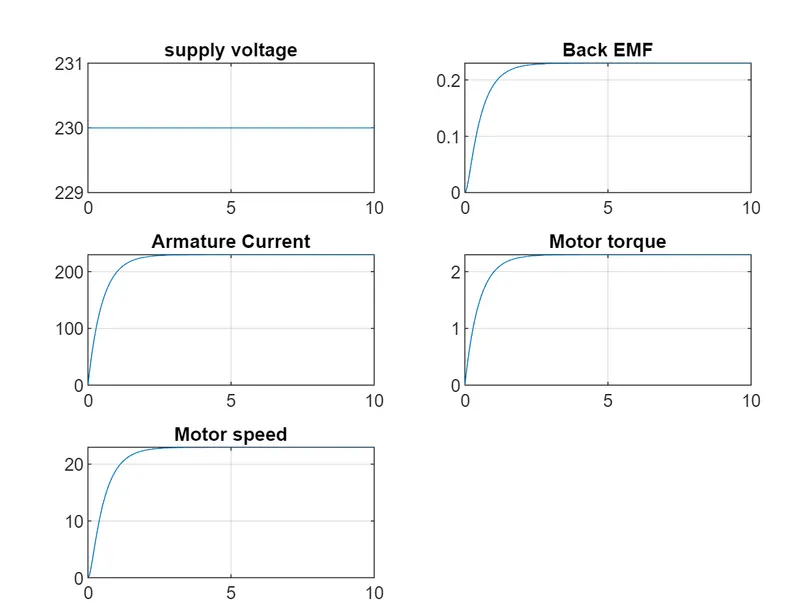
Now, I will design a PID contoller to control the speed of the motor and get the desire speed
The parameter of PID contoller
A=[-B1/j kt/j; -km/La -Ra/La];
B=[0; 1/La];
% Placement of Poles
fn=1; % natural Frequency
wn=2*pi*fn; % frequency in radian/sec
zeta=0.5; % under damped
p1=-zeta*wn+wn*sqrt(zeta^2-1); %pole 1
p2=-zeta*wn-wn*sqrt(zeta^2-1); % pole 2
P=[p1;p2]
K=place(A,B,P) % for getting proportional(kp) and derivative gain(kd)
kp=K(1);
kd=K(2);
ki=10; % integral gain value given by us manually
Simulink Model of DC Motor using PID controller
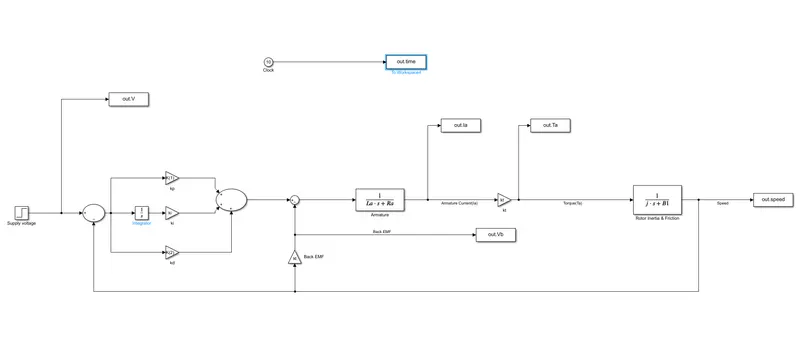
Case 1:- The result we got when we applied a Voltage of 230 V, kp=38.31 , kd=-2.85 , ki=10.
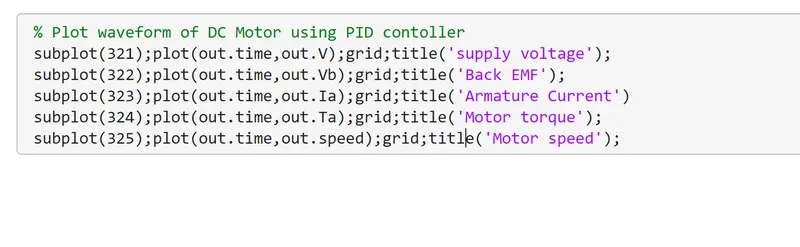
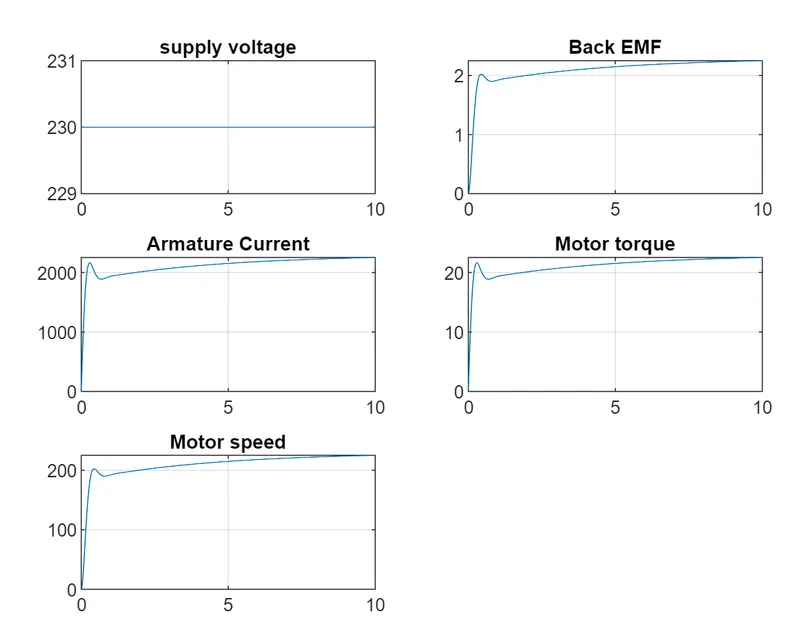
We can see by using the PID contoller we are getting the speed of motor close to supplied voltage.
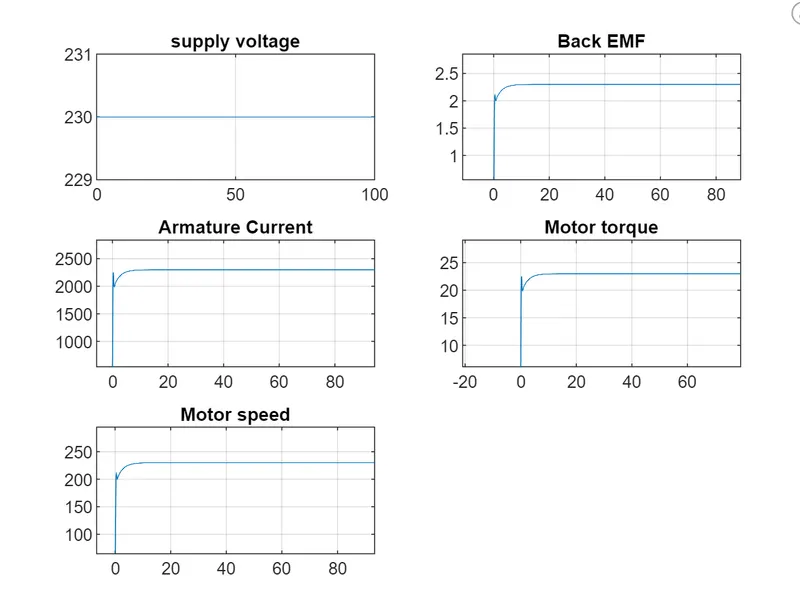
Case 2:- The result we got when we applied a Voltage of 230 V, kp=38.31 , kd=-2.85 , ki=20.
Case 3:- The result we got when we applied a Voltage of 230 V, kp=38.31 , kd=-2.85 , ki=30
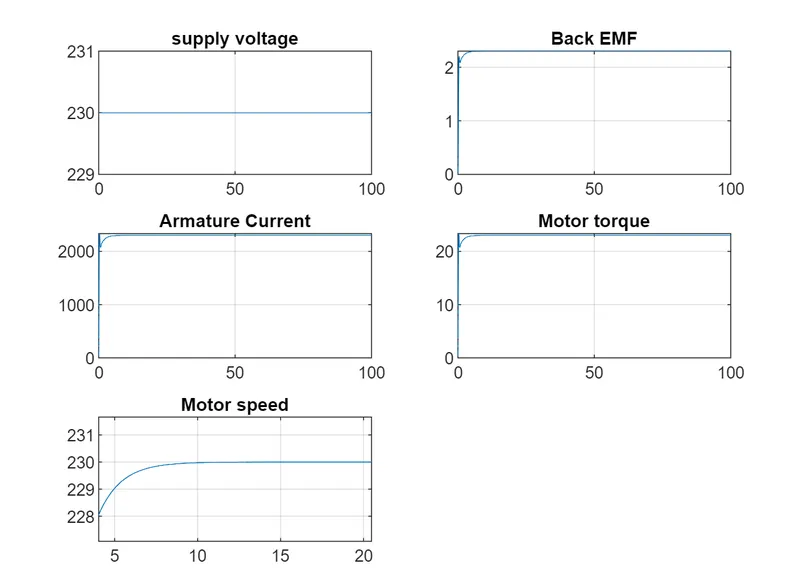
At Ki=20 & 30 we are getting the same speed. This mean we have maintain the desire speed of the motor