Project - Speed Control of a Direct Current (DC) motor
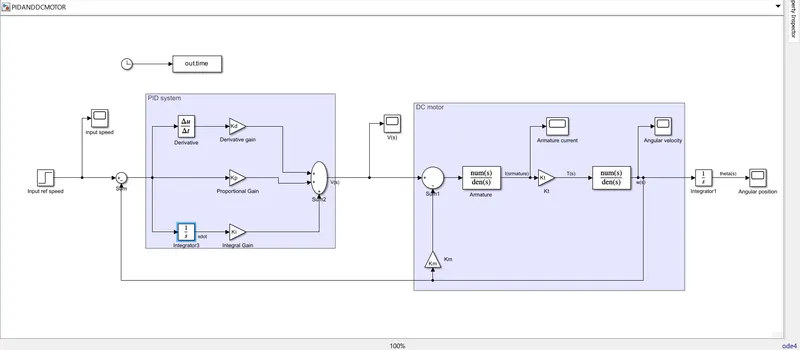
Ans) A Simulink model for the DC motor is developed as per the schematic shown in Figure above.
With inputs like:
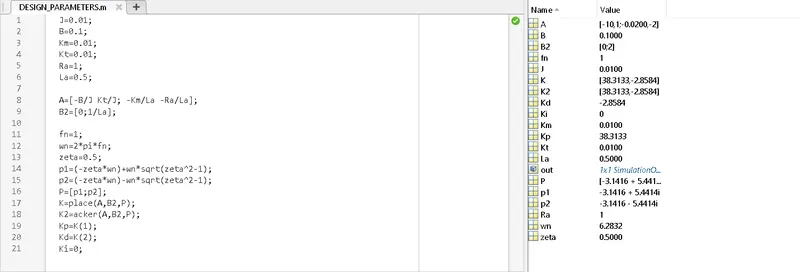
J=0.01; moment of inertia
B=0.1; motor viscous friction const
Km=0.01; Back enf const
Kt=0.01; motor torque const
Ra=1; Armature current
La=0.5; Armature inductance
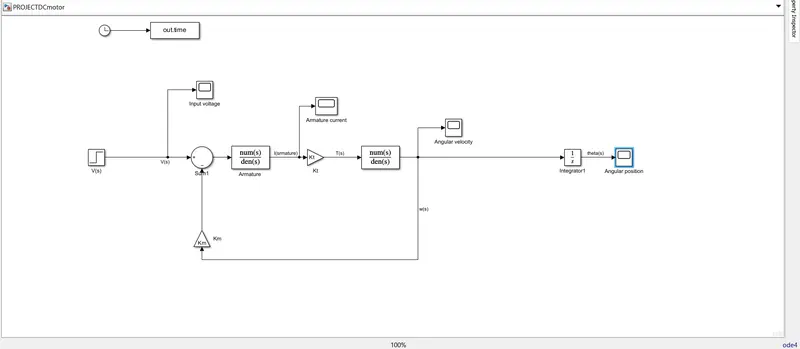
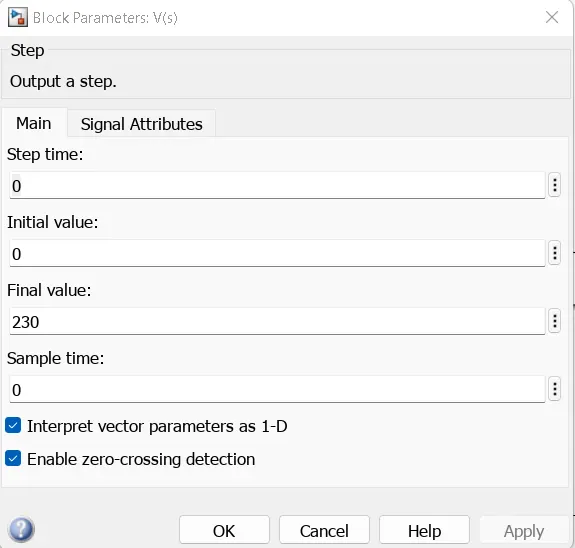
For 230V
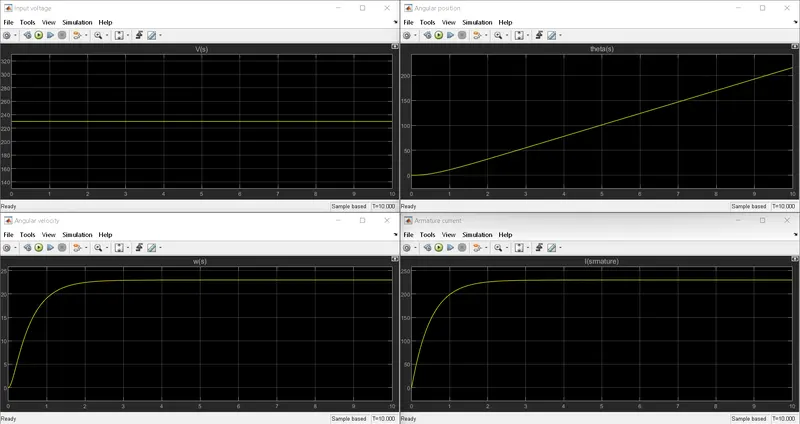
The PID controller is designed to control the speed of the motor as required
A=[-B/J Kt/J; -Km/La -Ra/La];
B2=[0;1/La];
fn=1;
wn=2*pi*fn;
zeta=0.5;
p1=(-zeta*wn)+wn*sqrt(zeta^2-1);
p2=(-zeta*wn)-wn*sqrt(zeta^2-1);
P=[p1;p2];
K=place(A,B2,P);
K2=acker(A,B2,P);
Kp=K(1);
Kd=K(2);
Ki=0;
1)
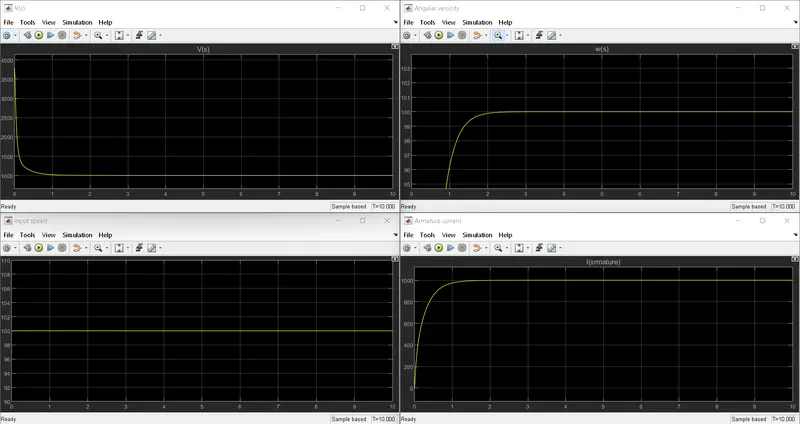
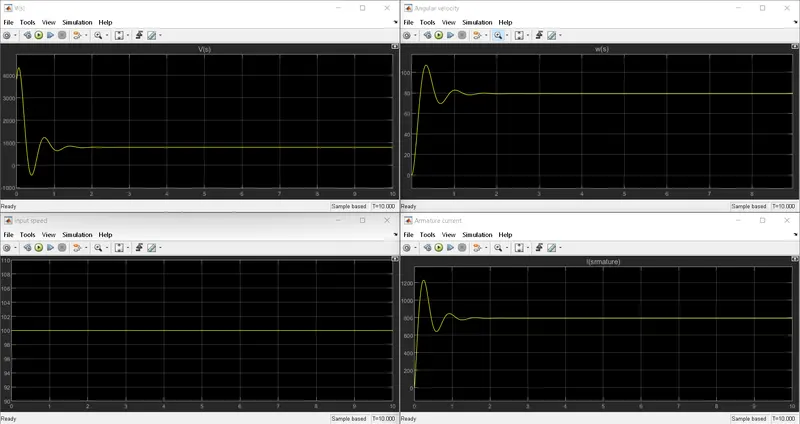
FOR SPPE 1000
Kp=38.3133;
Kd= -2.8584;
Ki=0;
1)
FOR :100
Kp=38;
Kd=7.06;
Ki=30;