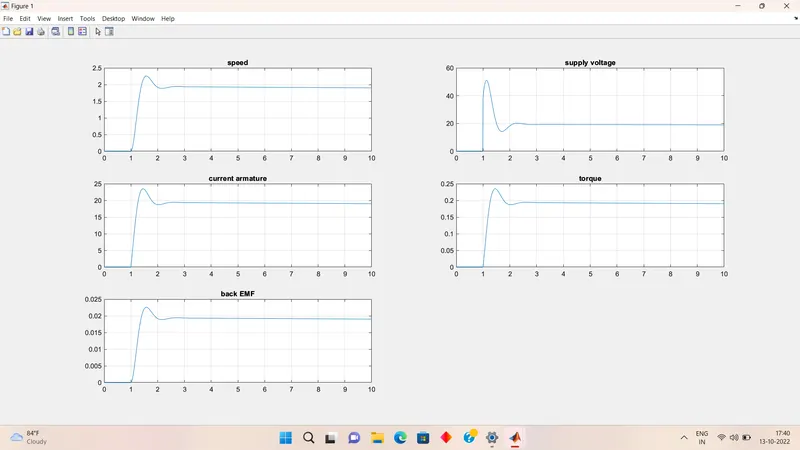
Project - Speed Control of a Direct Current (DC) motor
ANSWER SCRIPT:
What is a DC Motor?
A DC motor defined as a class of electrical motors that convert electrical direct current electrical energy into mechanical energy.
From the above definition, we can conclude that any electric motor that is operated using direct current or DC is called a DC motor. We will understand the DC motor construction and how a DC motor converts the supplied DC electrical energy into mechanical energy in the next few sections.
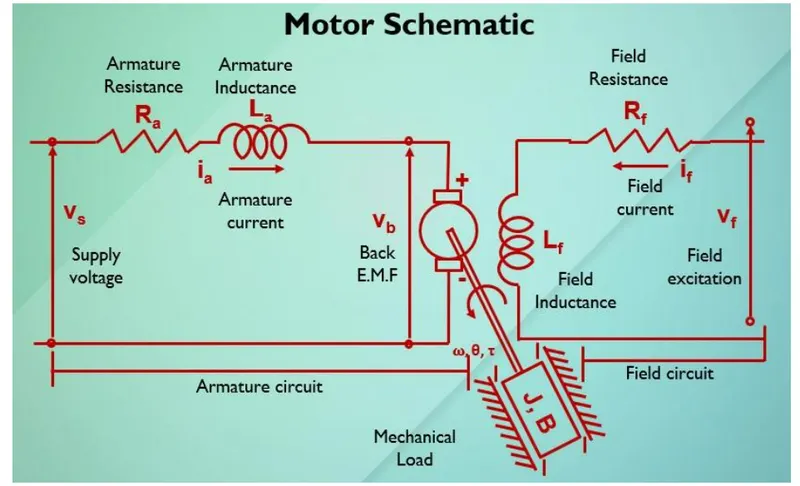
DC Motor Diagram
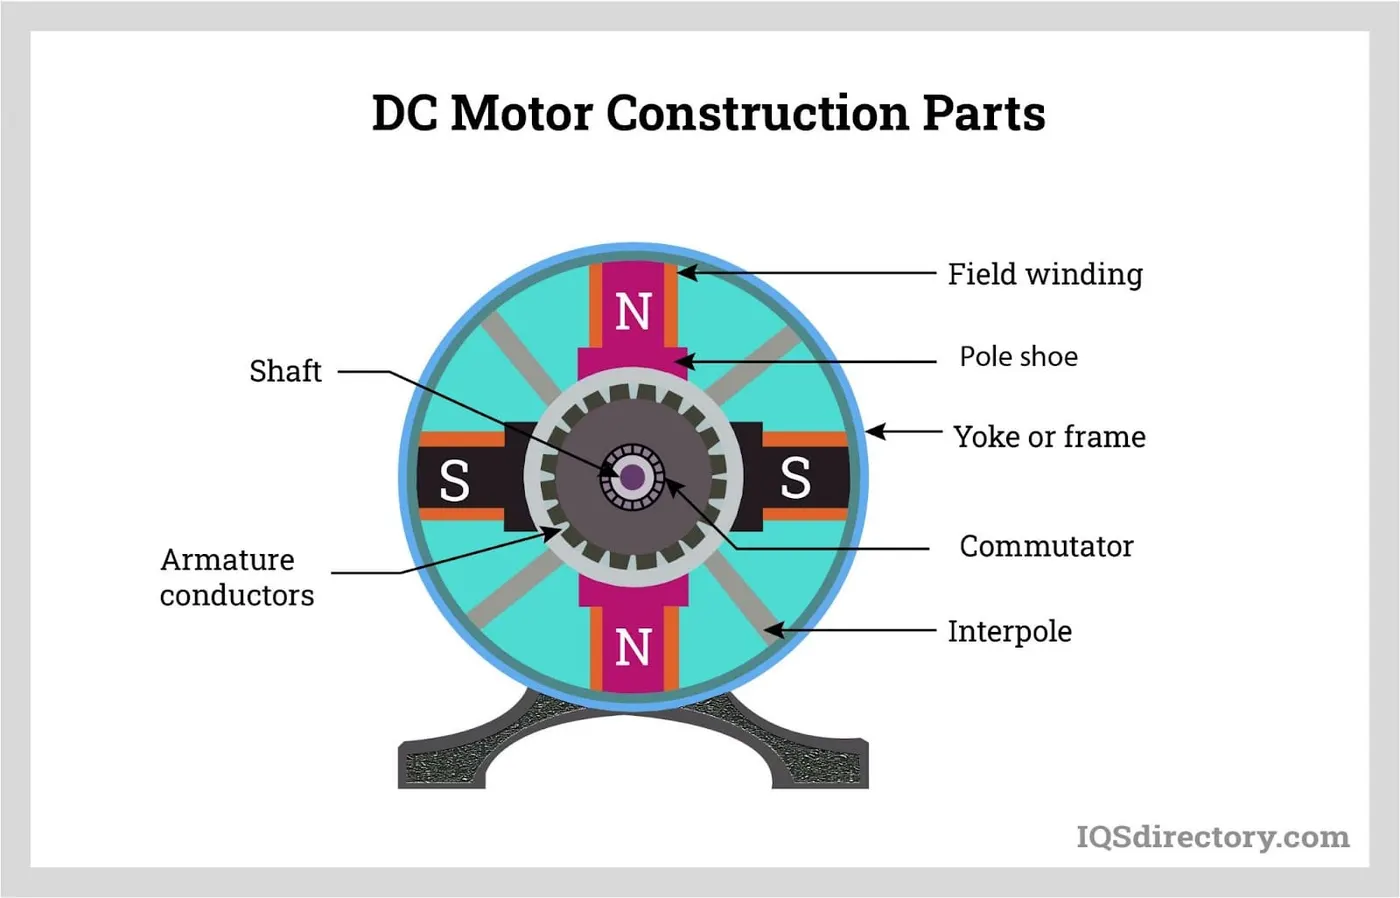
Different Parts of a DC Motor:
A DC motor is composed of the following main parts;
1.Armature or Rotor:
The armature of a DC motor is a cylinder of magnetic laminations that are insulated from one another. The armature is perpendicular to the axis of the cylinder. The armature is a rotating part that rotates on its axis and is separated from the field coil by an air gap.
2.Field Coil or Stator:
A DC motor field coil is a non-moving part on which winding is wound to produce a magnetic field. This electro- magnet has a cylindrical cavity between its poles.
3.Commutator:
The commutator of a DC motor is a cylindrical structure that is made of copper segments stacked together but insulated from each other using mica. The primary function of a commutator is to supply electrical current to the armature winding.
4.Brushes:
The brushes of a DC motor are made with graphite and carbon structure. These brushes conduct electrical current from the external circuit to the rotating commutator. Hence, we come to understand that the commutator and the brush unit are concerned with transmitting the power from the static electrical circuit to the mechanically rotating region or the rotor.
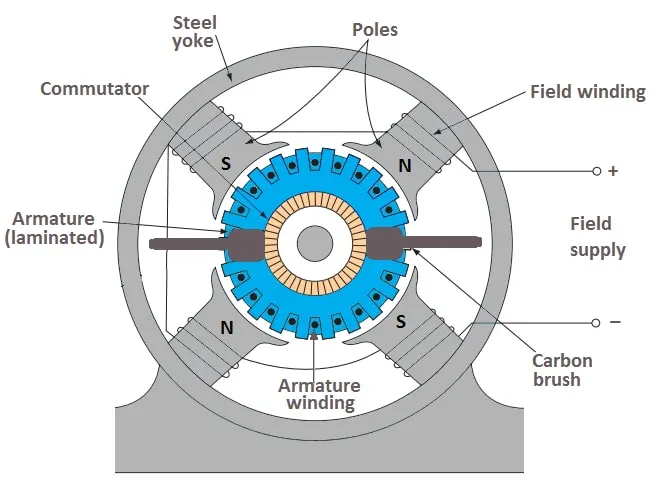
DC Motor Working:
A magnetic field arises in the air gap when the field coil of the DC motor is energised. The created magnetic field is in the direction of the radii of the armature. The magnetic field enters the armature from the North pole side of the field coil and exits the armature from the field coils South pole side.
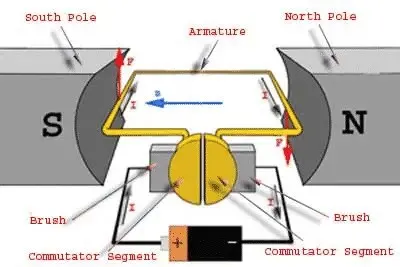
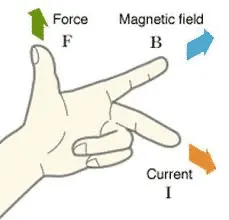
The conductors located on the other pole are subjected to a force of the same intensity but in the opposite direction. These two opposing forces creat a torque that causes the motor armature to rotate.
Principle:
When kept in a magnetic field, a current carrying conductor gains torque and develops a tendency to move. In short, when electric fields and magnetic fields interact, a mechanical force arises. This is the principle on which the DC motors work.
What is a PID Controller?
A PID controller is an instrument used in industrial contorl applications to regulate temperature, flow, pressure, speed and other process variables. PID controllers use a control loop feed back mechanism to control process variables and are the most accurate and stable controller.
PID control is well-established way of driving system towards a target position or level. It's practically ubiquitous as a means of controlling temperature and finds application in myriad chemical and scientific process as well as automation. PID control uses closed -loop control feedback to keep the actual output from a process as close to the target or setpoint output as possible.
PID Controller Block Diagram:
A closed-loop system like a PID controller includes a feedback control system. This system evaluvates the feedback variable using a fixed point to genrate an error signal. Based on that, it alterrs the system output. This procedure will continue till the error reaches zero otherwise the value of the feedback variable becomes equivalent to a fixed point.
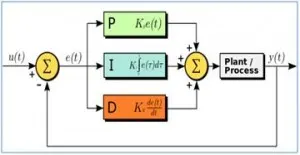 PID CONTROLLER Working of PID Controller:
The basic idea behind a PID controller is to read a sensor, then compute the desired actutator output by calculating proportional, integral and derivative responses and summing those three components to compute the output.
P- Controller:
Proportional or P- controller gives an output that is proportional to current error e(t). It compares the desired or set point with the value or feedback process value. The resulting value multiplied with a proportional constant to get the output. If the error value is zero, then this controller output is zero.
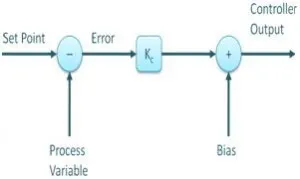
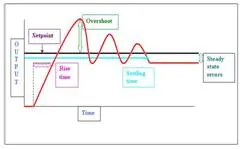 P-CONTROLLER P-CONTROLLER RESPONSE
This controller requires biasing or manual reset when used alone. This is because it never reaches steady -state condition. It provides stable operation but always maintains the steady-state error. The speed of the response is increased when the proportional consatnt Kc increases.
I-Controller:
Due to the limitation of P-controller where there always exists an offset between the process variable and setpoint, I-controller is needed, which provides necessary action to eliminate the steady state error. It integrates the error over period of time until the error value reaches zero. It holds the value to the final control device at which error becomes zero.
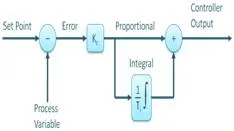
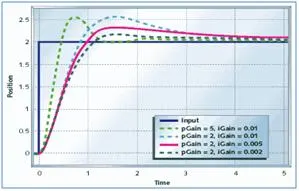
PI-CONTROLLER PI-CONTROLLER RESPONSE
Integral control decreases it's output when a negative error takes place. It limits the speed of response and affects the stability of the system. The speed of the response is increased by decreasing integral gain,Ki.
D-Controller:
I-controller doesn't have the capability to predict the future behavior of error. So it reacts normally once the setpoint is changed. D-controller overcomes this problem by anticipating the future behavior of the error. Its output depends on the rate of change of error with respect to time, multiplied by derivative constant. It gives the kick start for the output there by increasing system response.
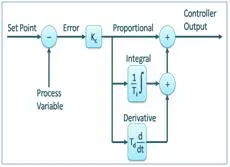
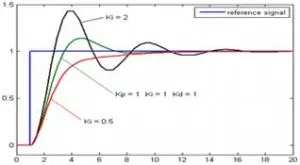
PI-CONTROLLER PI-CONTROLLER RESPONSE
So finally we observed that by combining these three controllers, we can get the desired response for the system. Different manufactures design different PID algorithms.
Mathematical Model of DC Machine:
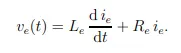
Since above equation is linear, by transforming in the Laplace domain the signals, it can be written as:
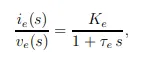
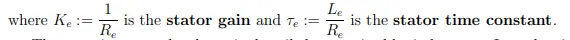
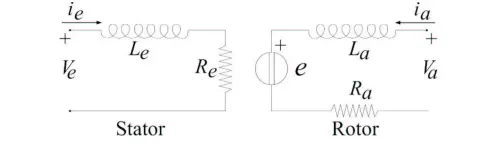
The rotor is assumed to be a single coil characterized by inductance La and resistance Ra, but it has to be taken into account the back EMF of the motor. The equation associated with such an electric circuit is given by
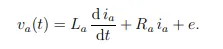
Again, since relation (16) is linear, by transforming in the Laplace domain the signals, it can be written as:
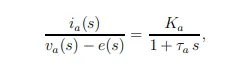
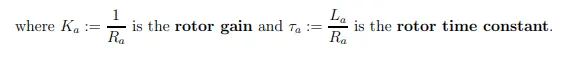
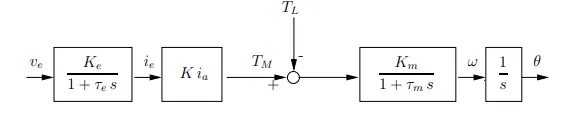
AS WE WANTED TO BUILT SIMULINK MODEL OF SPEED CONTROL OF A DIRECT CURRENT DC MOTOR
We have used below code to develop the model;
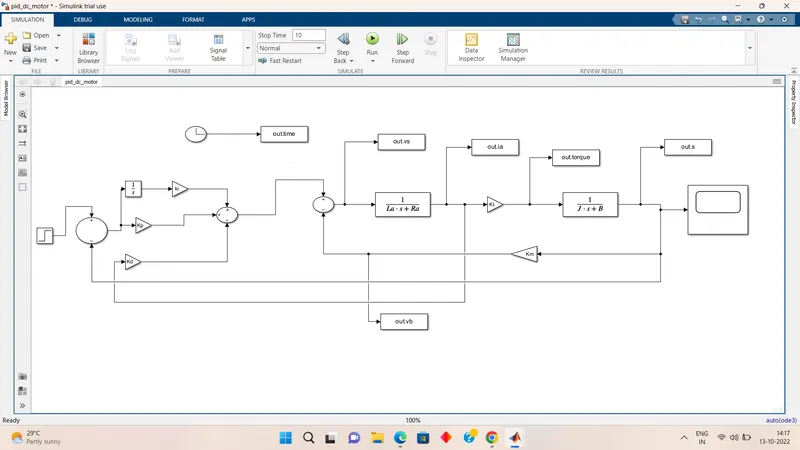
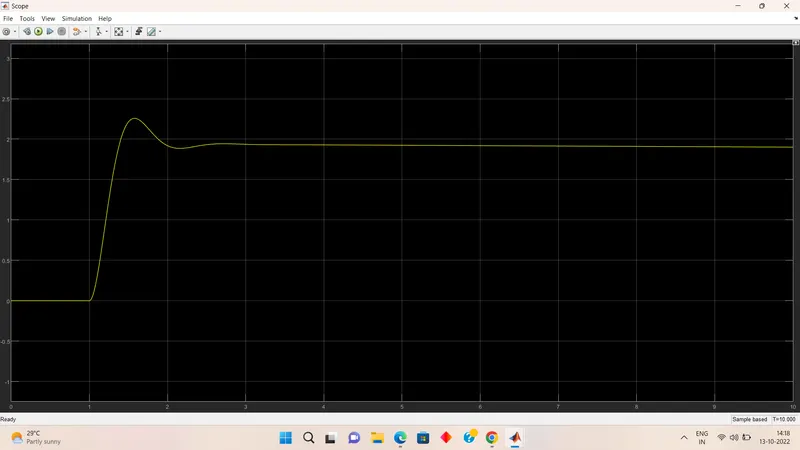
>> subplot(322);plot(out.time,out.vs);grid;title('supply voltage')
>> subplot(323);plot(out.time,out.ia);grid;title('current armature')
>> subplot(324);plot(out.time,out.torque);grid;title('torque')
>> subplot(325);plot(out.time,out.vb);grid;title('back EMF')