Project - Position control of mass spring damper system
Q)
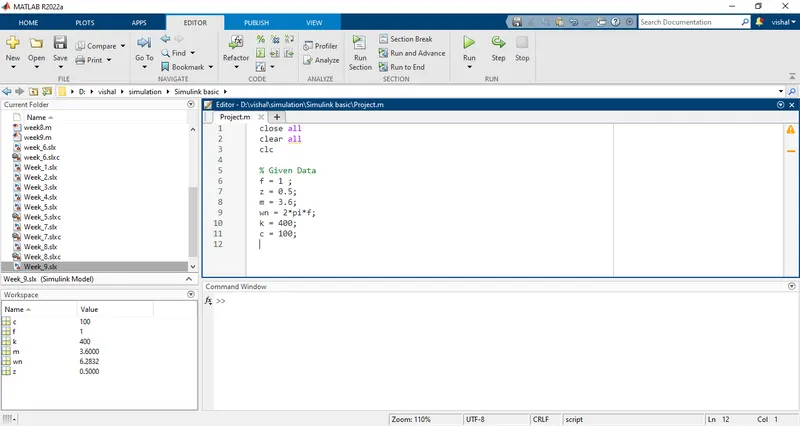
% Program
close all
clear all
clc

% Given Data
f = 1 ;
z = 0.5;
m = 3.6;
wn = 2*pi*f;
k = 400;
c = 100;
The input values of the c, k, m, f, wn, Zeta:-
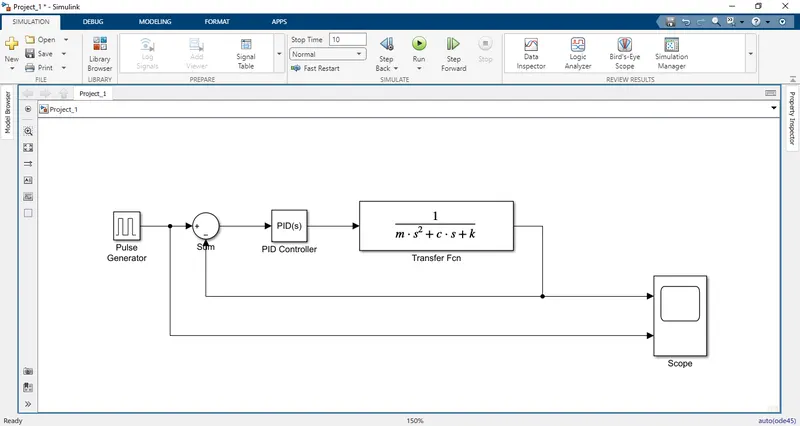
Circuit Diagram:-
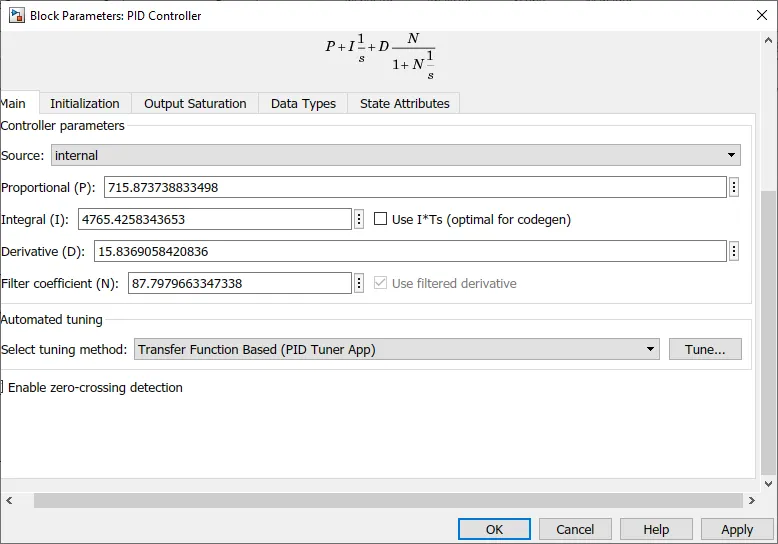
PID controller after the tunned signal:-
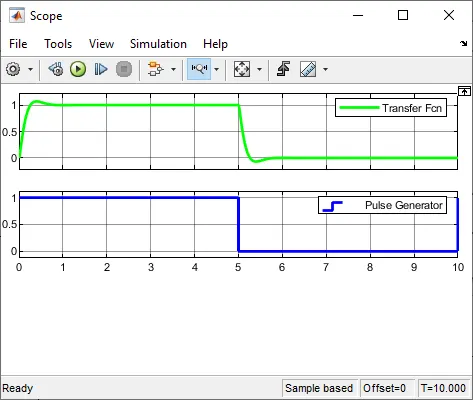
Summary:- The input is given in the form of the pulse generator which is given to the sum block by which the input to the PID block is been applied and the function block is been use for the mass spring damper system and we get the output. As the scope shows that the tuned signal and input signal are nearby same.