Project - Position control of mass spring damper system
Aim :- To obtain a position control of spring mass
*The transfer equation will be ,
`f(t)-cdx/dt-kx(t)=mdx^2/dt^2`
By applyaing laplace transform we get ,
`F(s)-csX(s)-kX(s)=ms^2X(s)`
But second order transfer function is ,
`T(S)=(wn)^2/(s^2+2*zeta*wn*s+wn^2)`
By compairing above equation
`1/ (ms^2+Cs+k)=(wn^2)/(s^2+2*zeta*wn*s+wn^2)`
we got ,
`wn=sqrt(1/m)`
`zeta=c/(2*(sqrt(c*k))`
*The state space model for spring damper system is ,
`A =matrices [0 1;-k/m -c/m]; B =matrices [0;1/m];`
*We can find a pole ,
`p1 = -wn*z+wn*sqrt(z^2-1)`
`p2 = -wn*z-wn*sqrt(z^2-1)`
P = [p1;p2] %Creating a pole matrices
K = place(A,B,P)
Kp = K(1);
Kd = K(2);
Ki = 100;
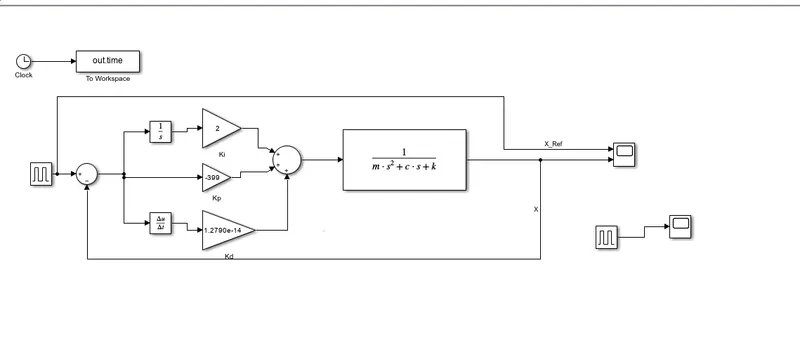
*For building a simulink model Blocks which has to be used:-
1.Clock %Clock block is used for simulation time.
2.To Workspace %The workspace block logs a data connected to its input ports to a workspace from a simulink model.
3.Pulse Generator %Pulse generator is used to generate pulses.
3.Transfer Function %Transfer function block contain transfer function for operation.
4.Integrator %The integrator block outputs the value of the integral of its input signal with respect to time.
5.Derivative %Derivative block is for getting derivative.
5.Gain % The gain block multiplies the input by a constant value.
6.Sum % The sum block is used for addition.
7.Scope %Scope block is for plotting output waveform.
Simulink Model:-
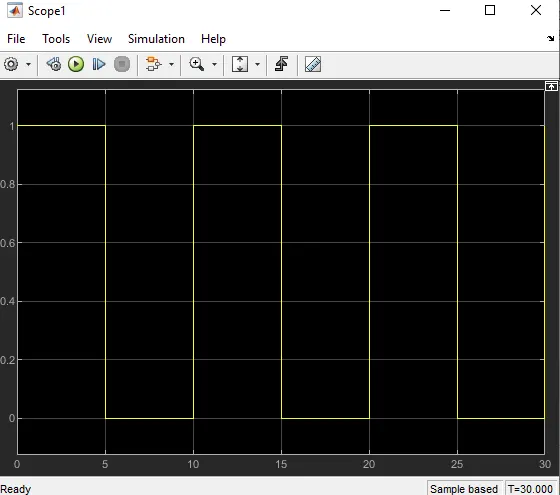
Rerence Signal :-
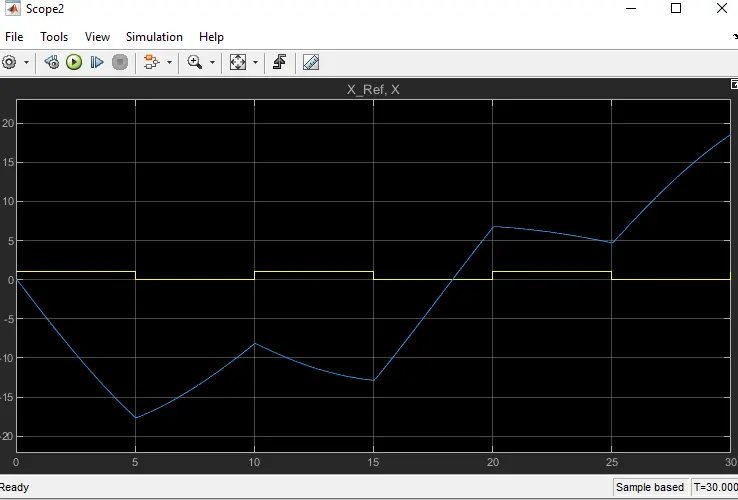
Case 1:-
When Kp=-399 Ki=2 Kd= 1.2790e-14
Case 2:-
Kp=1000 Ki=15000 Kd=95
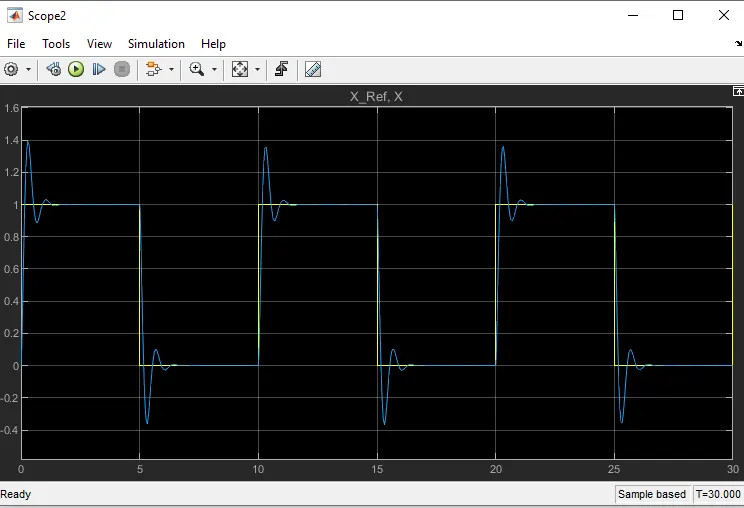
Case 3:-
Kp=2600 Ki=15000Kd=96
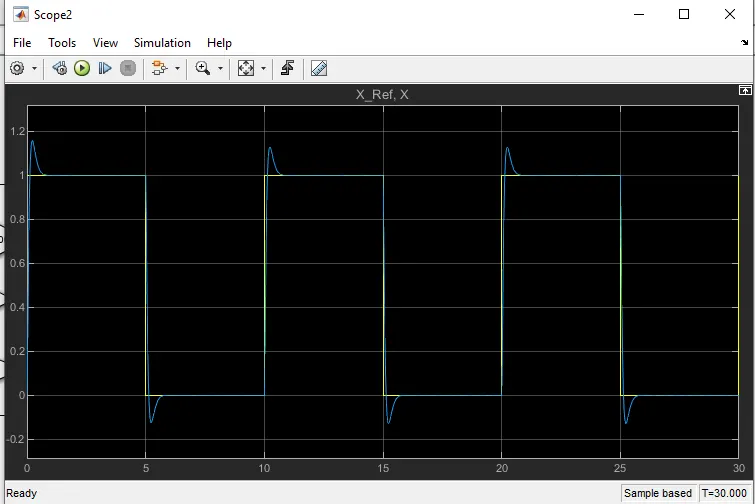
Conclusion:-
From this project of spring mass damper system of position control form scope output it is clear that we can control the position of spring mass damper sytem by varrying the input gain of Kp , Ki & Kd.