Project - Position control of mass spring damper system
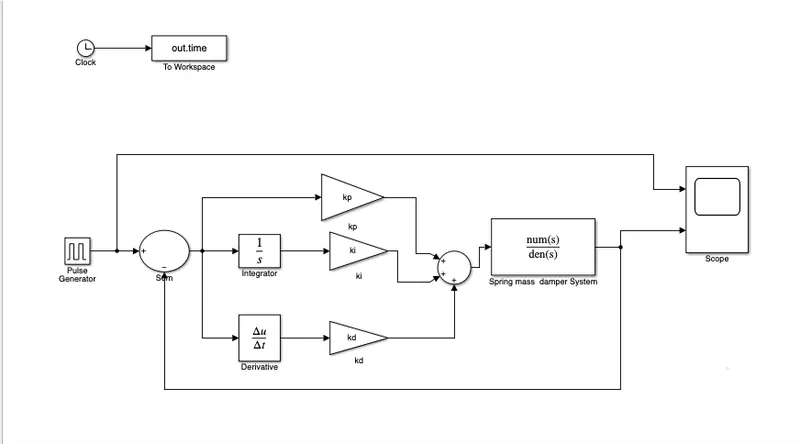
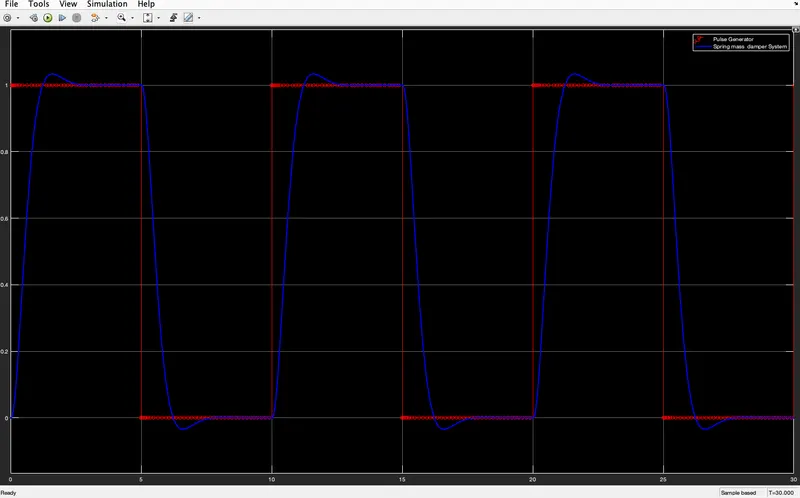
Obtain the transfer function of a mass spring damper system and use it in the model. Add a PID controller to adjust the force on mass so that its position follows a reference signal.
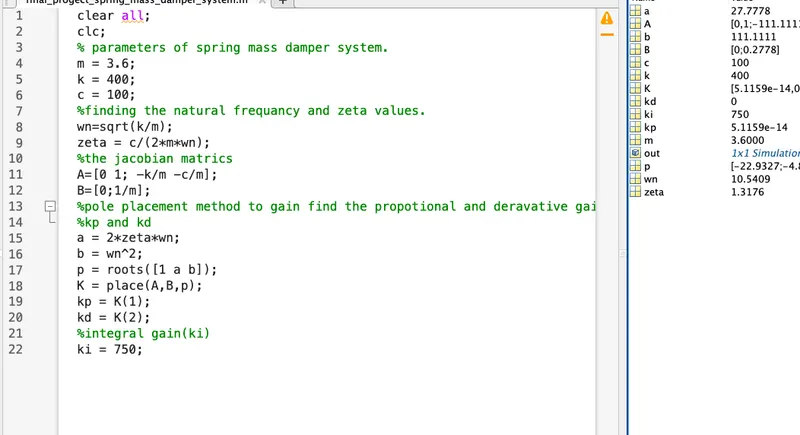
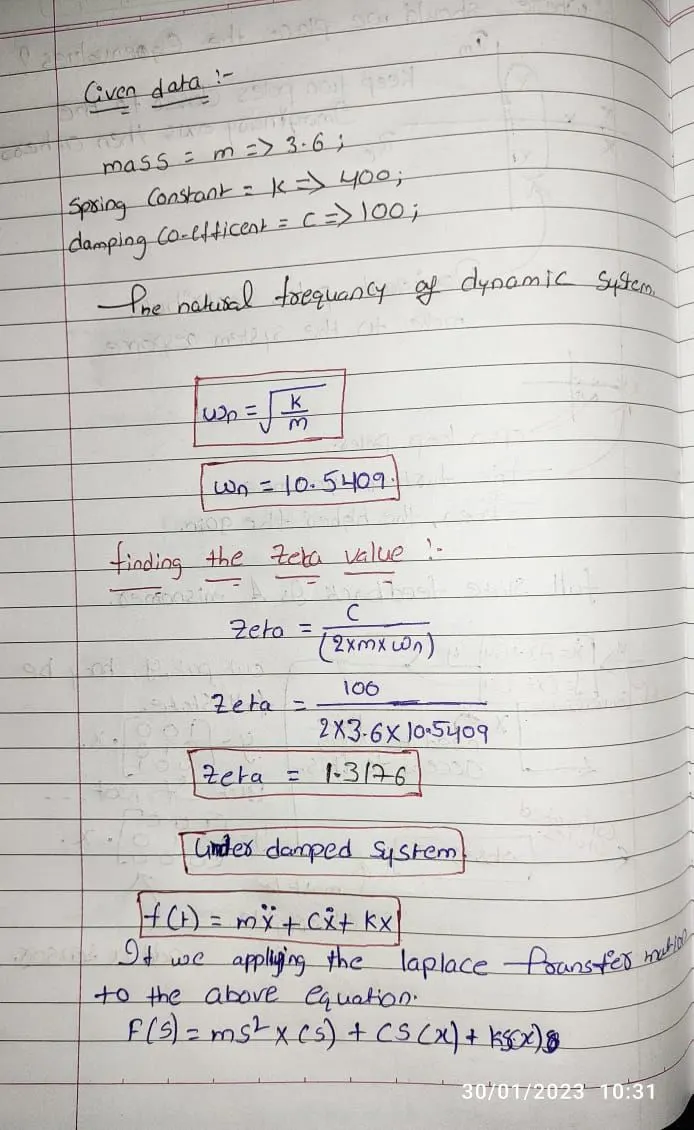
Take m = 3.6; %kg k = 400; %N/m c = 100; %Ns/m .
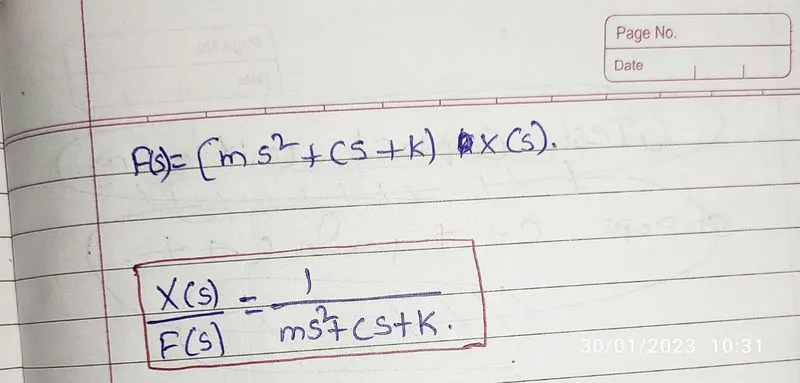 Lets go for the tracking...
K = place(A,B,p)
we using of place commend we get kp and kd values.
here A ,B jacobian matrix(The Jacobian matrix is a matrix of partial derivatives that describes the rate of change of a vector-valued function with respect to its inputs.)
p = roots([1 a b])
a = 2*zeta*wn;
b = wn^2;
kp = K(1) = 5.115907697472721e-14 ;
kd = K(2) = 0 ;
Integral Gain ki : - Which represents the proportionality constant between the integral of the error signal and the control signal.
ki = 750;