%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%
%% Skill-Lync -> Hybrid Drives Development
% Project 2 - Conventional Vehicle Model
% By - sathish saripudi
% Description:
%% Initialization File
% Initialization file for loading the variables for the Conventional vehicle simulation model
%% Vehicle Parameters
M = 1500; % Vehicle weight [kg]
Cr = 0.015; % Rolling resistance coefficient
Rw = 0.35; % Rolling radius [m]
Cd = 0.33; % Drag coefficient
Af = 2; % Frontal area [m2]
rhoa = 1.225; % Air density [kg/m3]
% Vwind = 0; % Wind velocity [kmph]
g = 9.81; % Gravitational acceleration [m/s2]
theta = 0; % Slope [deg]
myu_road_tire = 1; % Coefficient of friction between tire - road interface
%% Powertrain Parameters
FDR = 3.73; % Final Drive Ratio / Diff Ratio
DiffEff = 0.99; % Differential efficiency (assumed independent of operating conditions)
NumGear = 4; % Number of gears in transmission
TransGear = [1:NumGear]; % Transmission Gears
TransRatio = [3.06, 1.62, 1, 0.7]; % Corresponding Transmission ratios
TransEff = 0.90; % Transmission efficiency (assumed independent of operating conditions)
TC_SR = [0, .5, .6, .7, .8, .87, .92, .94, .96, .97, 1]; % Torque Converter Speed Ratio (Matlab default) -> TurbSpd/PumpSpd
TC_TR = [2.232, 1.5462, 1.4058, 1.2746, 1.1528, 1.0732, 1.0192, 1, 1, 1, 1]; % Torque Converter Torque Ratio (Matlab default) -> TurbTrq/PumpTrq
TC_Cf = 1e-4 * [.72558, .66322, .63463, .59042, .51331, .4144, .29287, .22444, .12186, .04386, 0]; % Torque Converter Capacity Factor (Matlab default) -> PumpTrq/PumpSpd^2 [Nm/rpm^2]
load Vehicle_Data/Engine_data_1_9L_Saturn_95kW
load Vehicle_Data/Trans_Shift_map
load Vehicle_Data/EM_Honda_Insight_10kW
load Vehicle_Data/ESS_NiMH6
ESS_init_soc = 0.8;
ESS_soc_max = 0.9;
ESS_soc_min = 0.6;
%% Driver Parameters
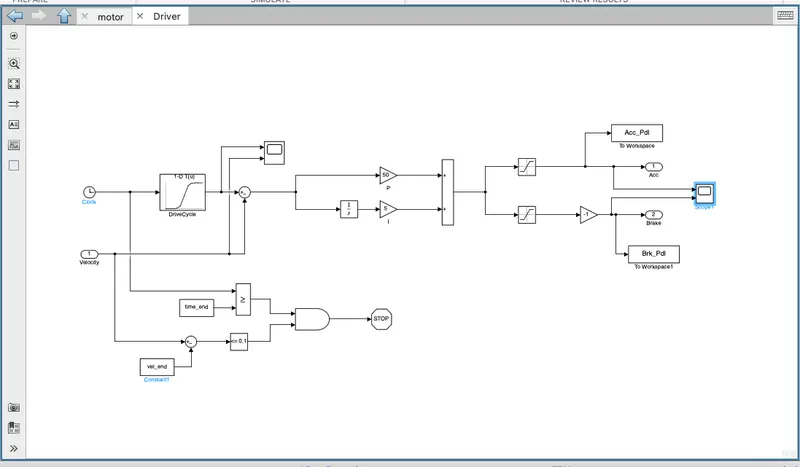
Kp = 10; % P gain for driver PI model
Ki = 1; % I gain for driver PI model
Drive_Cycle_Select = 1; % Drive cycle selection
% Drive cycle values in m/s
if Drive_Cycle_Select == 1
load DriveCycles/UDDS;
elseif Drive_Cycle_Select == 2
load DriveCycles/HWFET;
elseif Drive_Cycle_Select == 3
load DriveCycles/FTP;
elseif Drive_Cycle_Select == 4
load DriveCycles/US06;
elseif Drive_Cycle_Select == 5
load DriveCycles/NEDC;
elseif Drive_Cycle_Select == 6
load DriveCycles/WLTP;
end
time_end = cyc_time(end);
vel_end = cyc_vel(end);
%% Renaming variables
time =tout;
Acc_Pdl = Acc_Pdl; % Accelerator pedal [%]
Brk_Pdl = Brk_Pdl; % Brake pedal [%]
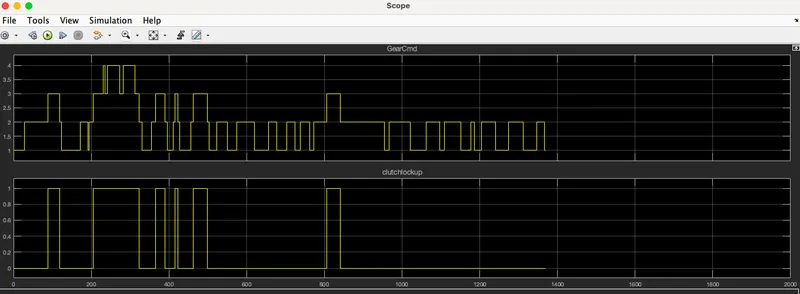
Gear_Cmd = Gear_CMD; % Transmission gear
Trans_In_Spd = Trans_In_Spd; % Transmission input speed [rpm]
Trans_Out_Spd = Trans_out_Spd;% Transmission output speed [rpm]
Eng_Trq = Eng_Trq; % Engine brake torque [Nm]
Eng_Spd = Eng_Spd; % Engine speed [rpm]
Eng_Fuel_Consump = Eng_Fuel_Consumption; % Engine fuel consumption [g]
Veh_Dist = Veh_Dist; % Distance traveled by vehicle [km]
Veh_Spd = Veh_Spd; % Vehicle speed [kmph]
Wheel_Speed = WheelSpd; % Wheel speed [kmph]
Eng_Fuel_Rate = Eng_Fuel_Rate; % Engine fuel rate [%]
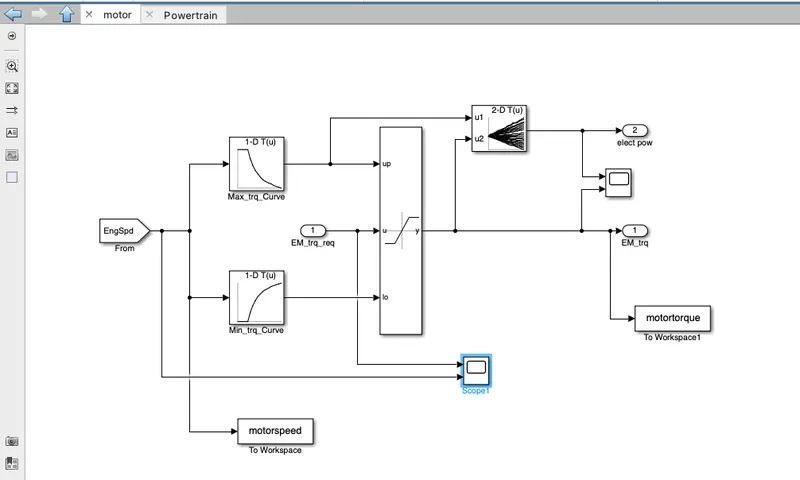
EM_Speed = motorspeed; % Electric Motor Speed
EM_Power = motorpower; % Electric Motor Power
EM_Torque = motortorque; % Electric Motor Torque
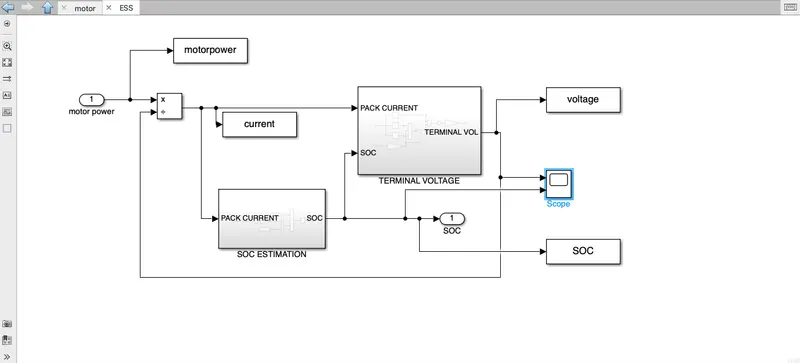
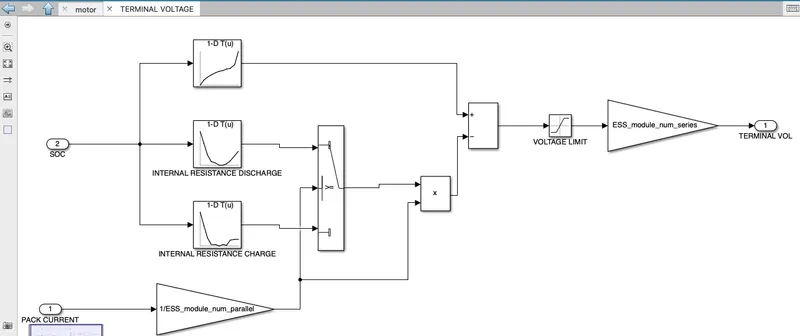
Term_Volt = voltage; % Terminal Voltage of battery
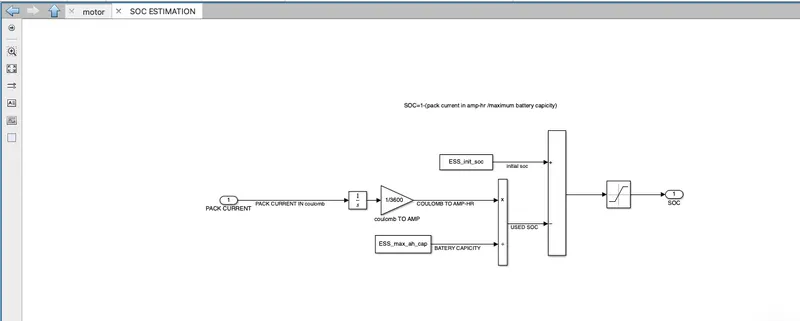
Soc = SOC; % State Of Charge
Pack_Current = current; %Pack current of battery
%% Data Analysis
Eng_Pwr = Eng_Spd.*pi/30.*Eng_Trq/1000; % Engine brake power [kW]
rho_petrol = 0.7197; % Density of petrol [kg/L]
kmpl = Veh_Dist(end)/(Eng_Fuel_Consump(end)/1000/rho_petrol); % Fuel economy [kmpl]
%% Plotting vehicle characteristics time trace transmission IN/OUT and Wheel Speed
figure(1)
hold on
grid on
plot(time, Trans_In_Spd, 'linewidth', 1, 'Color', 'black');
plot(time, Trans_Out_Spd, 'linewidth', 1, 'Color', 'red');
plot(time, Wheel_Speed, 'linewidth',1, 'color', 'blue')
ylabel('Speed [rpm]')
xlabel('Timem [s]')
xlim([0, time(end)]);
ylim([0, 6000]);
legend('Trans Input','Trans Output','Wheel Speed');
%% Plotting Engine speed, Engine Torque, Engine Power,Engine fuel rate,Engine fuel consumption wrt Time
figure(2)
subplot(4,1,1)
plot(time,Eng_Trq,'linewidth',1,'color','black')
xlim([0, time(end)]);
xlabel('Time [s]')
ylabel('Torque [Nm]')
legend('Engine Torque')
grid on
subplot(4,1,2)
plot(time,Eng_Pwr,'linewidth',1,'color','blue')
xlim([0, time(end)]);
xlabel('Time [s]')
ylabel('Power [KW]')
legend('Engine Power')
grid on
subplot(4,1,3)
plot(time,Eng_Fuel_Rate,'linewidth',1,'color','red')
xlim([0, time(end)]);
xlabel('Time [s]')
ylabel('Fuel Rate [%]')
legend('Engine Fuel Rate')
grid on
subplot(4,1,4)
plot(time,Eng_Fuel_Consumption,'linewidth',1,'color','green')
xlim([0, time(end)]);
xlabel('Time [s]')
ylabel('Fuel Consumption')
legend('Engine Fuel Consumption')
grid on
% Plotting fuel economy Vs Engine Fuel consumption
figure(3)
plot(Eng_Fuel_Consumption,Eng_Fuel_Rate,'color','r')
xlabel('Fuel consumption')
ylabel('Fuel Rate [%]')
title('Fuel economy Vs Fuel Consumption')
grid on
%% Potting Accelerator pedal, Brake pedal and gear command with respect to time
figure(4)
subplot(2,1,1)
hold on
plot(time, Acc_Pdl, 'linewidth', 1, 'Color', 'black');
plot(time, Brk_Pdl, 'linewidth', 1, 'Color', 'red');
ylabel('Pedal [%]')
xlabel('Time [s]');
xlim([0, time(end)]);
grid on
legend('Accel','Brake');
title('Acceleration & Brake Pedal wrt Time')
subplot(2,1,2)
plot(time, Gear_Cmd, 'linewidth', 1, 'Color', 'black');
xlim([0, time(end)]);
xlabel('Time [s]');
ylabel('Gear');
grid on
title('Gear command wrt Time')
% Plotting gear command vehicle desired with actual speed
figure(5)
subplot(2,1,1)
plot(Veh_Spd, Gear_Cmd, 'linewidth', 1, 'Color', 'black');
xlabel('Speed [rpm]');
ylabel('Gear');
grid on
title('Gear command wrt vehicle speed')
subplot(2,1,2)
plot(Veh_Dist, Gear_Cmd, 'linewidth', 1, 'Color', 'red');
xlabel('Distance [kmpl]');
ylabel('Gear');
grid on
title('Gear command wrt Distance')
%% Plotting engine operating points on engine fuel map
figure('Name','Engine Operating Points');
hold on
grid on
title('Engine Operating Points','fontsize',12);
p1=plot(Eng_map_spd*30/pi,Eng_max_trq,'linewidth',2,'color','r');
p2=line([Eng_map_spd(end)*30/pi Eng_map_spd(end)*30/pi],[0 Eng_max_trq(end)]);
set(p2,'linewidth',1,'linestyle','--','color','k');
p3=line([Eng_map_spd(1)*30/pi Eng_map_spd(1)*30/pi],[0 Eng_max_trq(1)]);
set(p3,'linewidth',1,'linestyle','--','color','k');
[c,h] = contour(Eng_map_spd'*30/pi,Eng_map_trq,Eng_fuel_map');
clabel(c,h);
xlabel('Engine Speed [rpm]');
ylabel('Engine Torque [Nm]');
title('Engine Fuel Consumption Map [g/s]');
legend([p1 p3],{'Max Curve','Operating Points'});
axis([Eng_map_spd(1)*30/pi Eng_map_spd(end)*30/pi 0 Eng_map_trq(end)]);
%% State of Charge, Pack Current, And Terminal Voltage with respect to Time
figure(6)
subplot(3,1,1)
plot(time,Pack_Current,'linewidth',1,'color','black')
xlim([0, time(end)]);
xlabel('Time [s]')
ylabel('Current [W]')
legend('Pack Current')
grid on
subplot(3,1,2)
plot(time,Soc,'linewidth',1,'color','blue')
xlim([0, time(end)]);
xlabel('Time [s]')
ylabel('Charging [%]')
legend('State Of Charge')
grid on
subplot(3,1,3)
plot(time,voltage,'linewidth',1,'color','red')
xlim([0, time(end)]);
xlabel('Time [s]')
ylabel('Voltage [V]')
legend('Terminal Voltage')
grid on
%% Motor Speed, Torque, Motor input power with respect to Time
figure(7)
subplot(3,1,1)
plot(time,EM_Power,'linewidth',1,'color','black')
xlim([0, time(end)]);
xlabel('Time [s]')
ylabel('Power [W]')
legend('Electric Motor Power ')
grid on
subplot(3,1,2)
plot(time,EM_Torque,'linewidth',1,'color','blue')
xlim([0, time(end)]);
xlabel('Time [s]')
ylabel(' Torque [Nm]')
legend('Electric Motor Torque')
grid on
subplot(3,1,3)
plot(time,EM_Speed,'linewidth',1,'color','red')
xlim([0, time(end)]);
xlabel('Time [s]')
ylabel('Speed [Rpm]')
legend('Electrical Motor Speed')
grid on
%% Plotting EM Operating Points on motor input power Map
figure('Name','Electric Motor Operating Points');
hold on
grid on
title('Electric Motor Operating Points','fontsize',12);
p1=plot(EM_map_spd*30/pi,EM_max_trq,'linewidth',2,'color','r');
p2=line([EM_map_spd(end)*30/pi EM_map_spd(end)*30/pi],[0 EM_max_trq(end)]);
set(p2,'linewidth',1,'linestyle','--','color','k');
p3=line([EM_map_spd(1)*30/pi EM_map_spd(1)*30/pi],[0 EM_max_trq(1)]);
set(p3,'linewidth',1,'linestyle','--','color','k');
[c,h] = contour(EM_map_spd'*30/pi,EM_map_trq,EM_inpwr_map');
clabel(c,h);
xlabel('Motor Speed [rpm]');
ylabel('Motor Torque [Nm]');
title('Motor Input Power Map [g/s]');
legend([p1 p3],{'Max Curve','Operating Points'});
axis([EM_map_spd(1)*30/pi EM_map_spd(end)*30/pi 0 EM_map_trq(end)]);
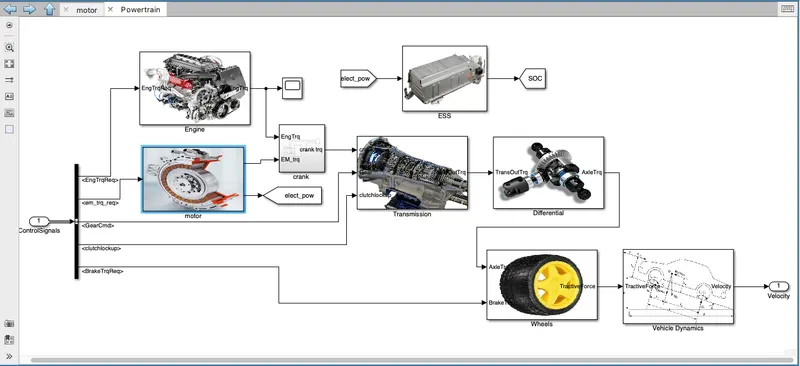
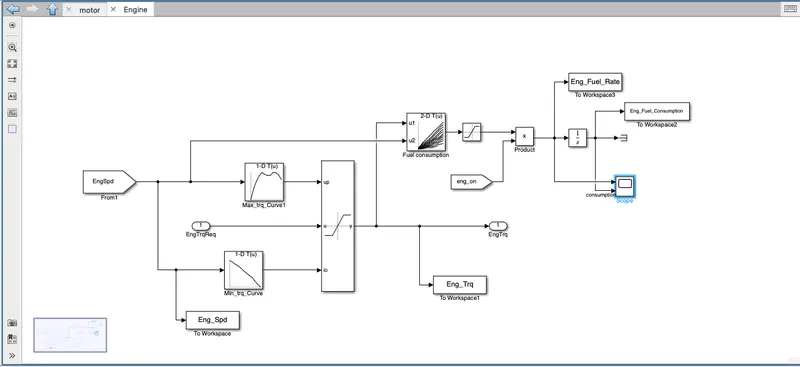
I.C. engine: In this instance, chemical energy is transformed into mechanical energy since the combustion of the energy fuel inside the i.c. engine occurred.
The combustion process can provide a reciprocating motion, which tries to rotate the generator in order to generate power and store it in the battery.
Battery: This device is used to store electricity produced by a generator.
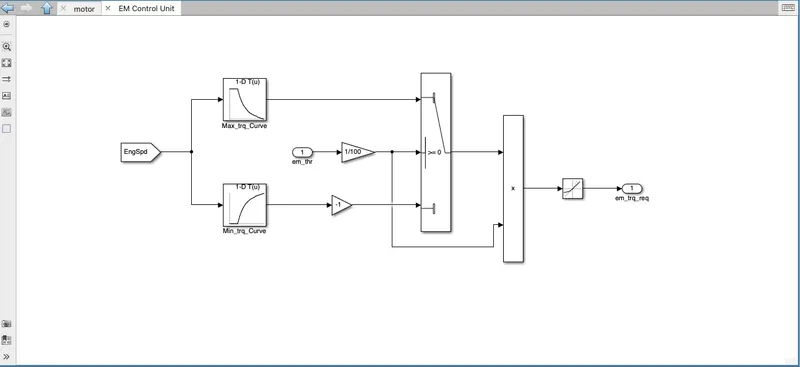
Electric motor: This component drives the vehicle and draws energy from the battery as needed.
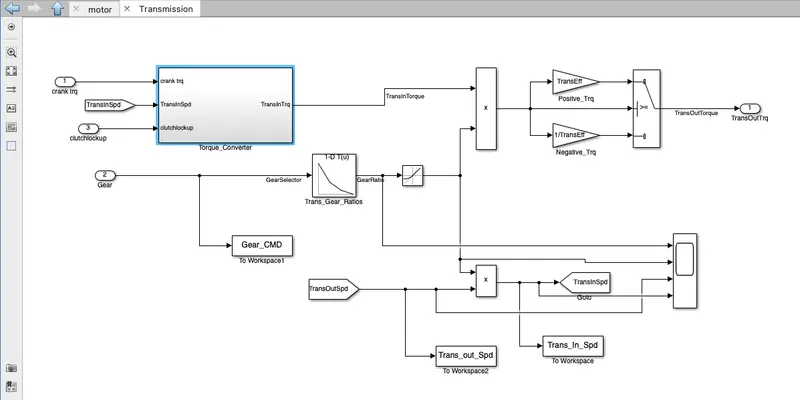
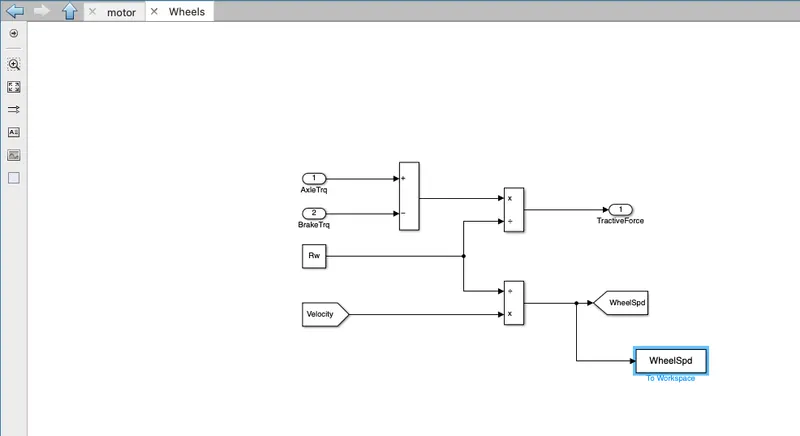
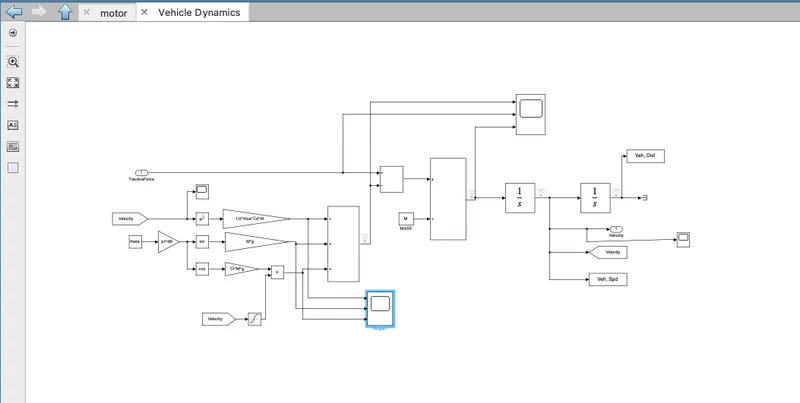
Transmission: It is used to create a tractive force if the vehicle and also it leads to the dynamic of the vehicle.
Electric hybrid cars produce enough power to fulfil performance requirements.
carry enough fuel to keep you going for a reasonable distance.
Should be productive.
causing the least pollution to the environment.
The vehicle may have one or more energy sources and energy converters, such as electric and fuel cell motors, battery and electric motors, and gasoline and diesel engines, among others.
A hybrid vehicle will generally have multiple flows and two energy sources and converters. one will usually be a bi-directional energy source and converter & the other can be a bi-directional or uni-directional
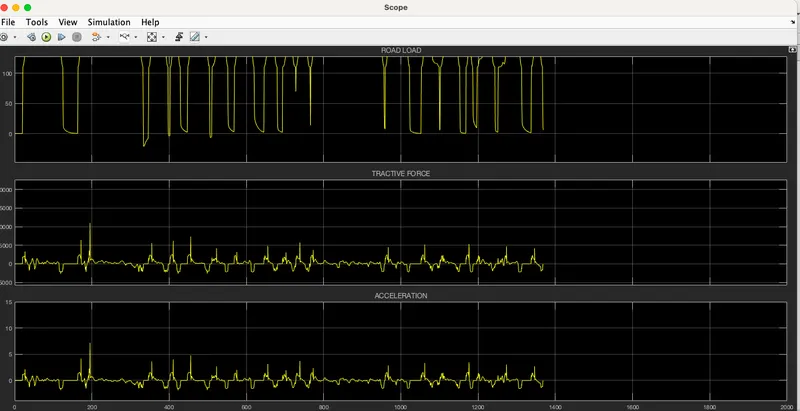
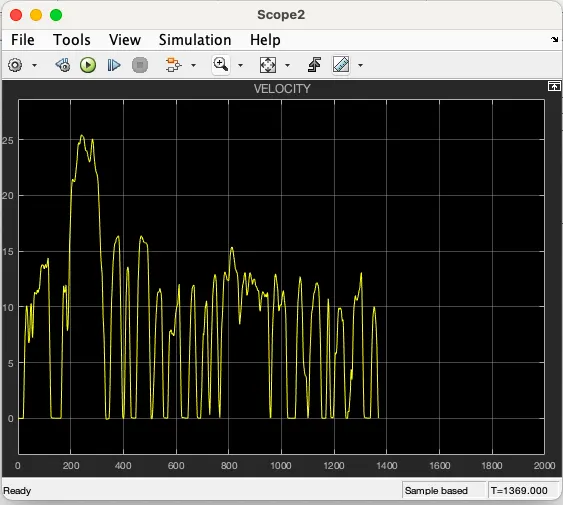
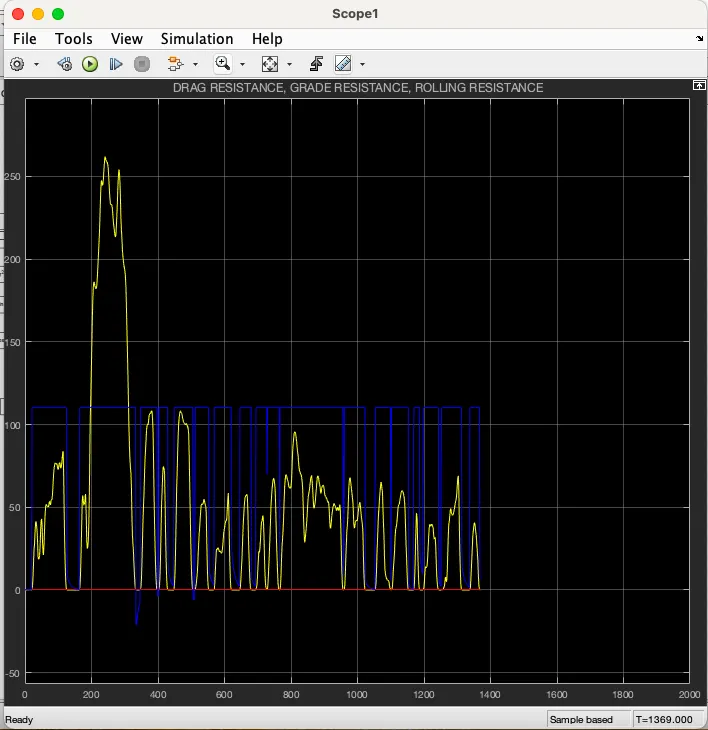
PLOTES ARE STORED IN BELOW FILES.