Project - Position control of mass spring damper system
1.)
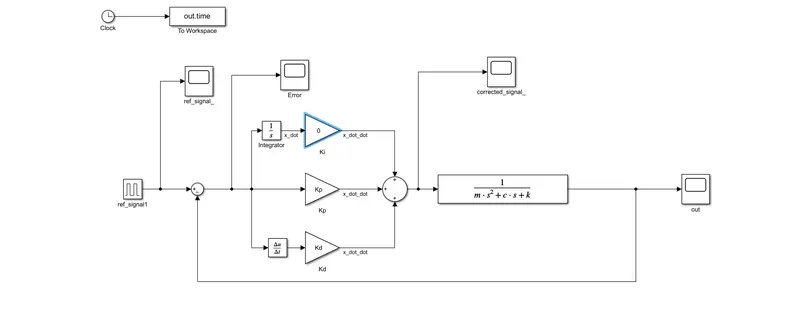
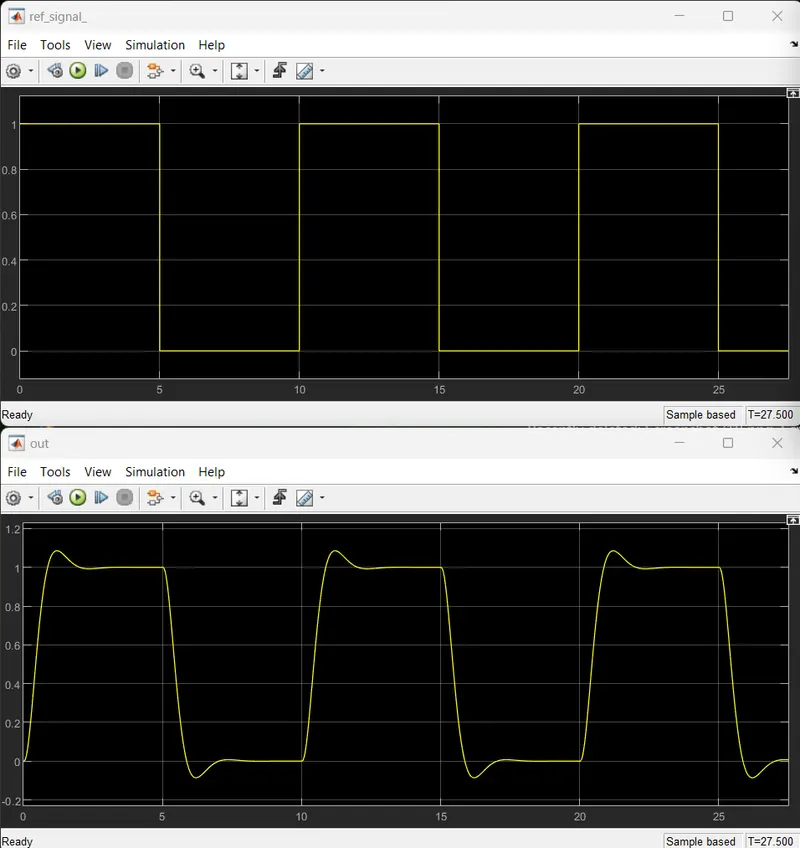
- Obtained the transfer function of a mass spring damper system and used it in the model. Also added a PID controller to adjust the force on mass so that its position follows a reference signal.
- m = 3.6 kg
- k = 400 N/m
- c = 100 Ns/m
- The reference signal is shown in the question.
- The simulink model for the above conditions are as follows:
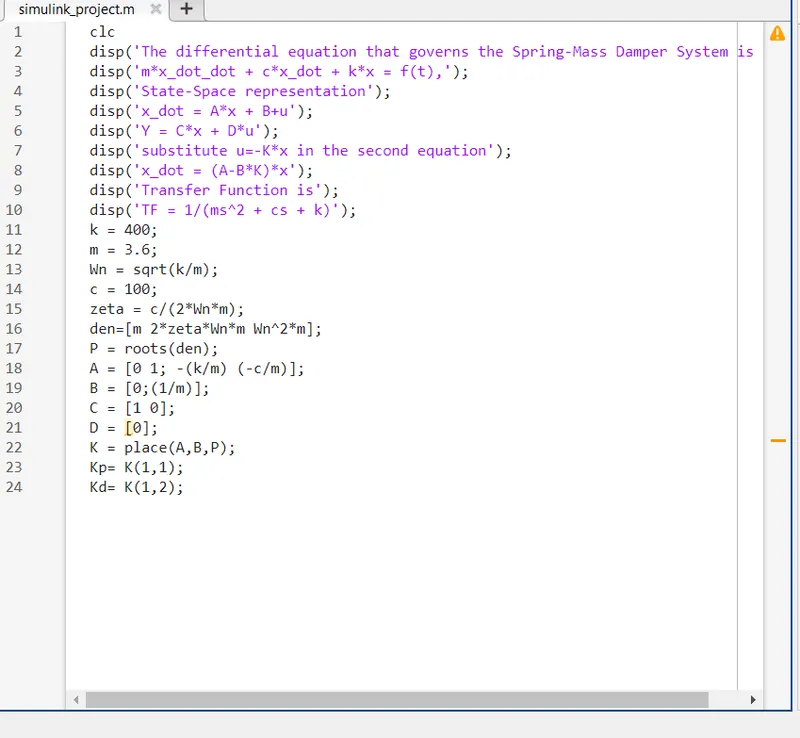
- The matlab script to run the above simulink model is
- The workspace is shown below
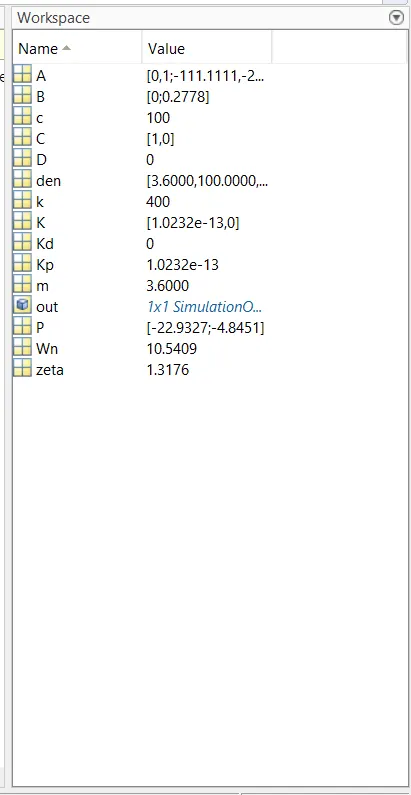
- The values of Kp & Kd are found out using the quations in the matlab script, while the value of Ki is given manually, and verified for different values of Ki.
- When Ki=0
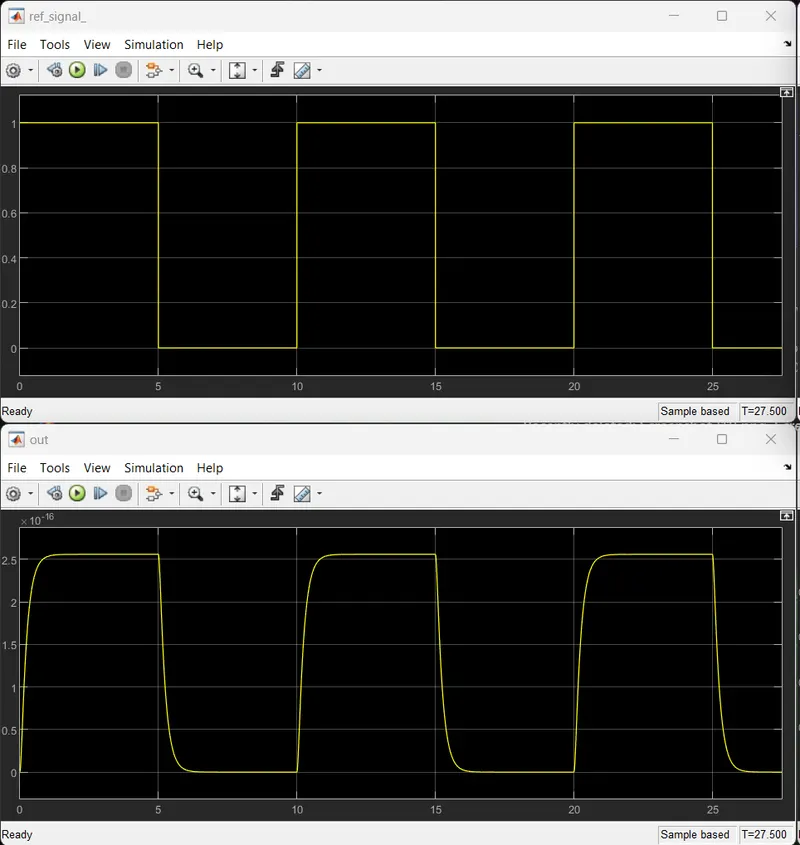
- Ki=1
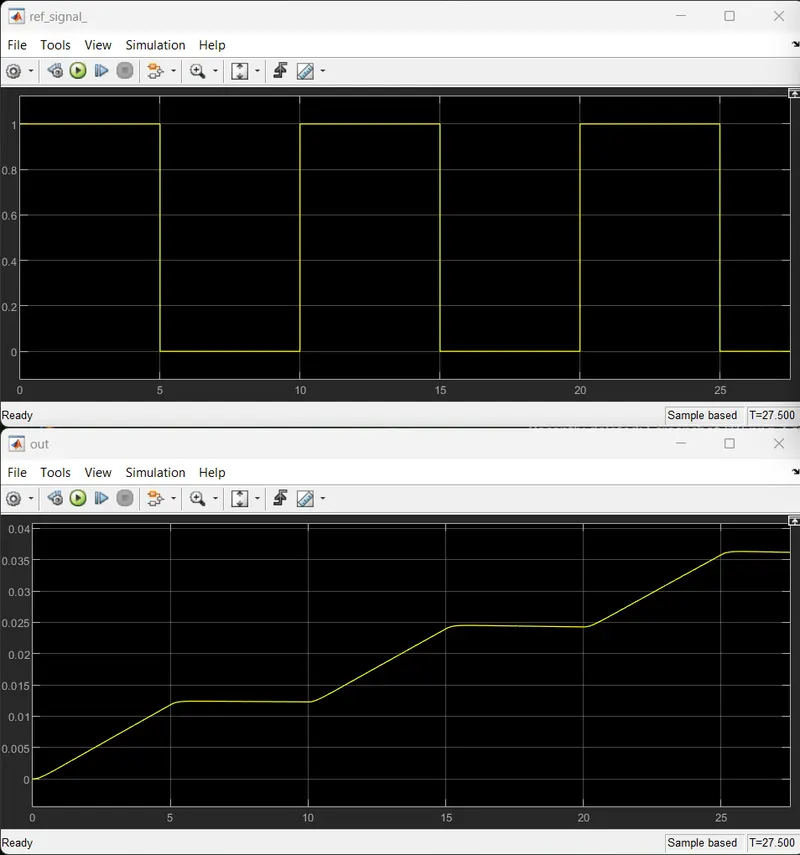
- Ki=10
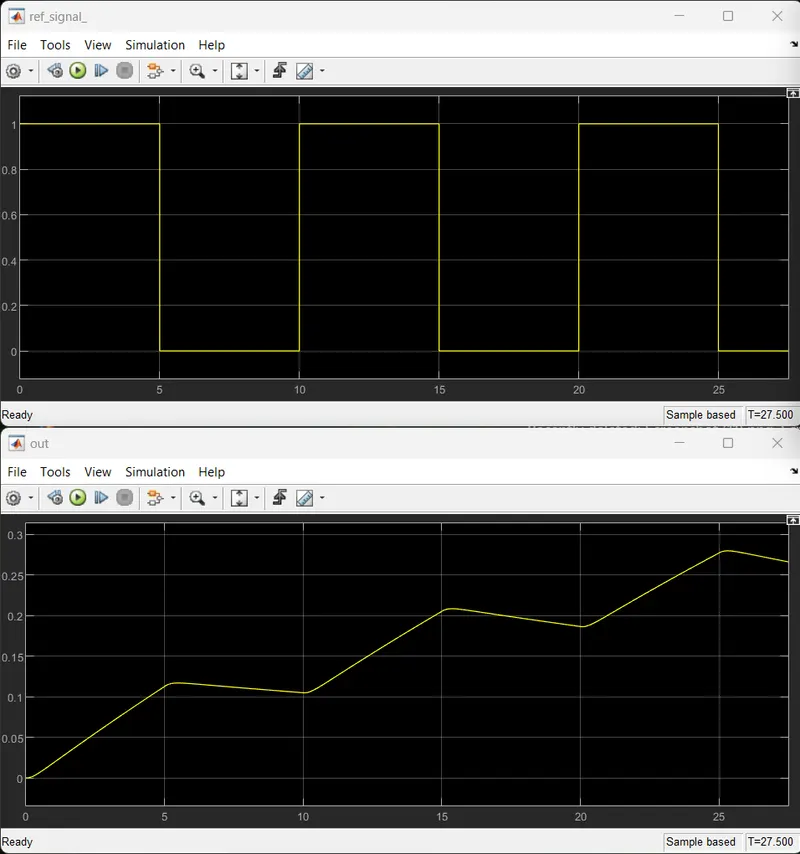
- Ki=100
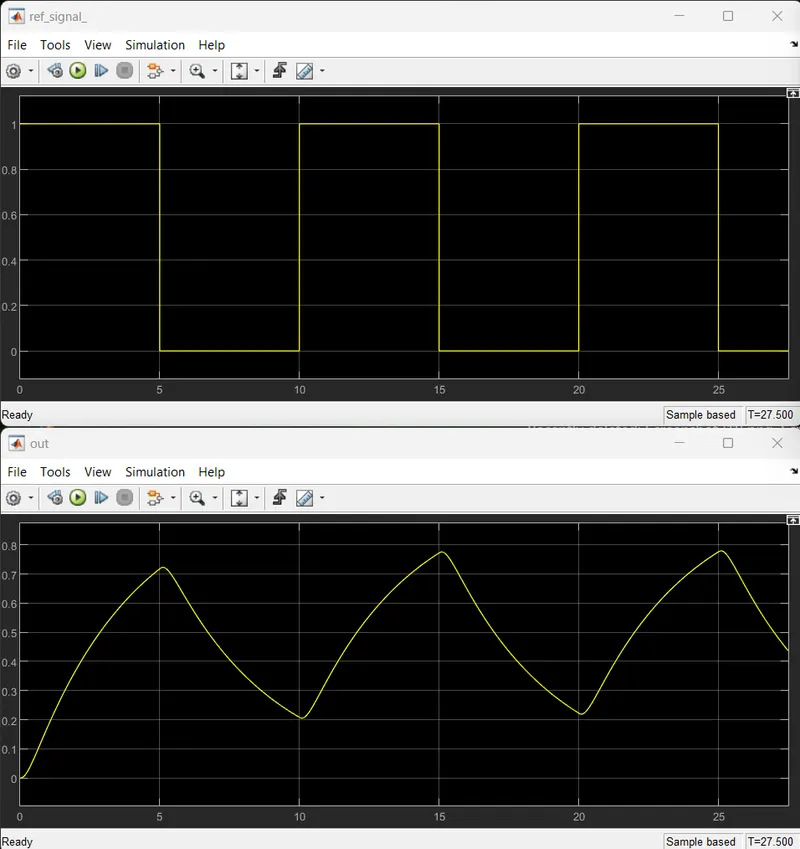
- Ki=500
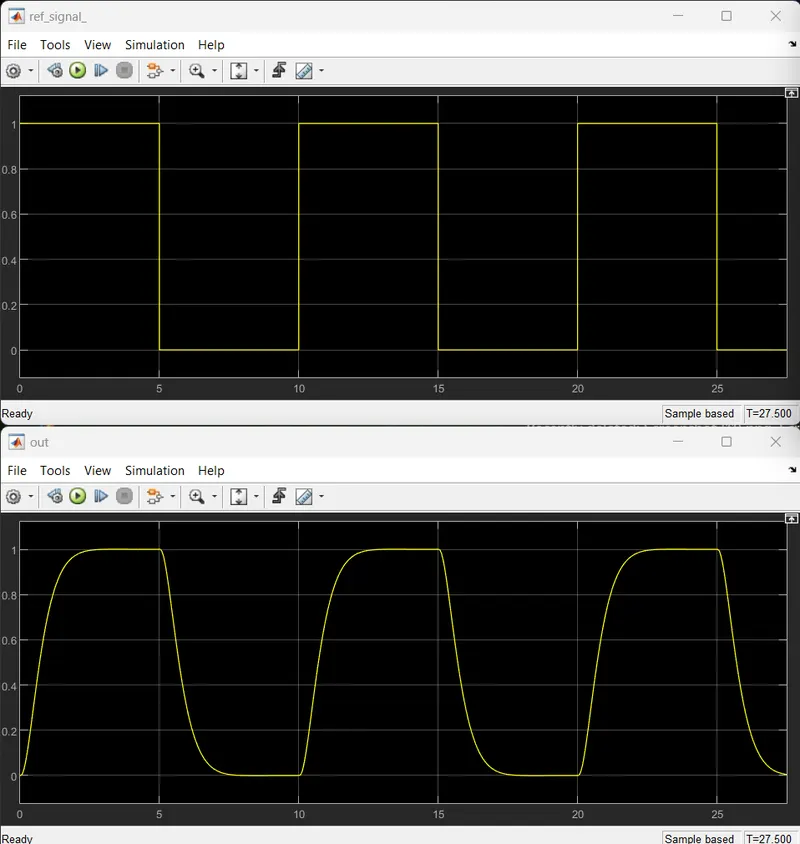
- Ki=1000
- The supporting documents have been uploaded.