Project 1
AIM
Develop a double-acting actuator model using Simscape Multibody and Simscape components.
REQUIREMENTS
The mechanical system of the cylinder needs to be built using Simscape Multibody library components / blocks, and the hydraulic system needs to be modelled using Simscape library physical components.
MODEL
- The piston cylinder arrangement
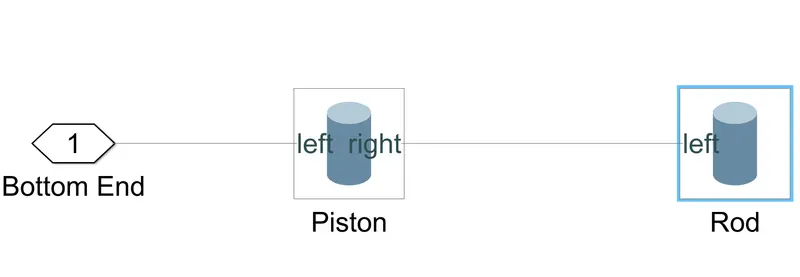
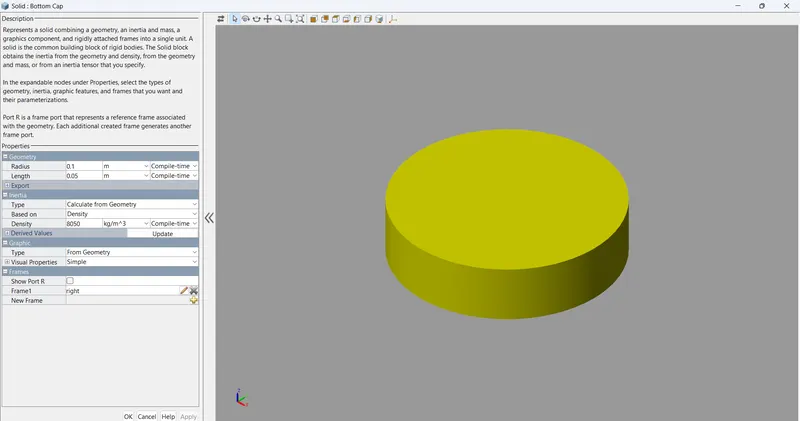
- The Piston dimensions
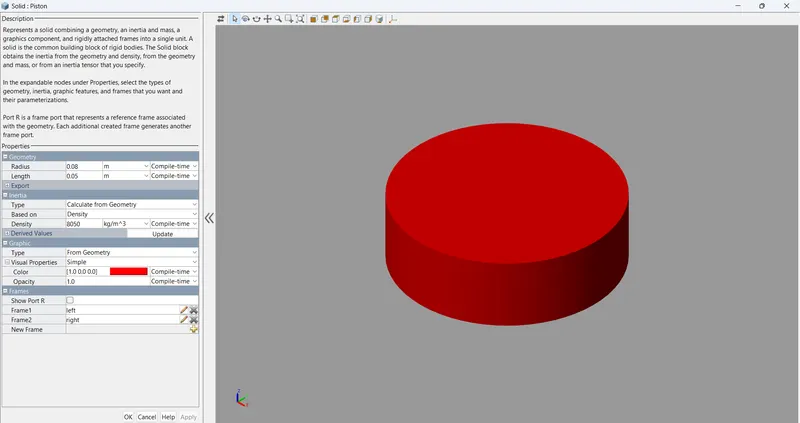
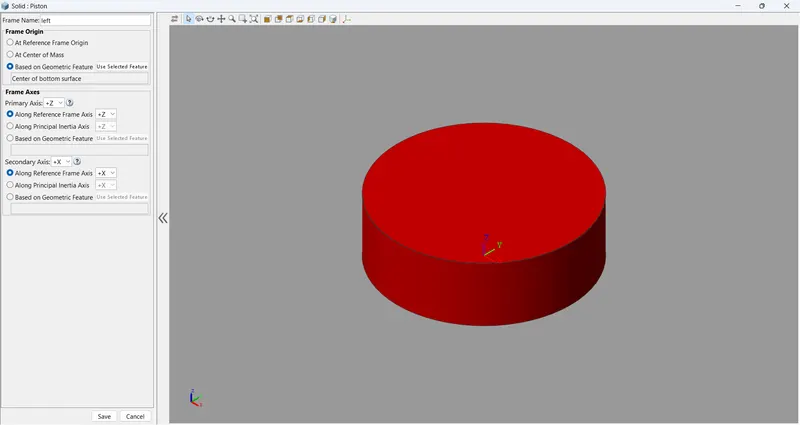
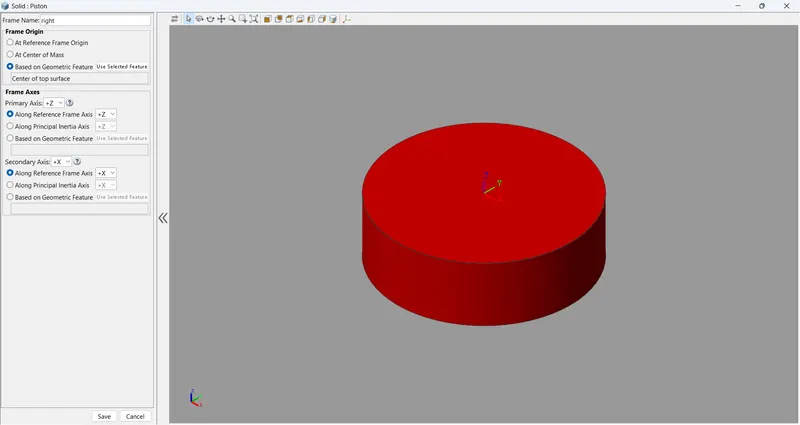
- The Rod dimensions
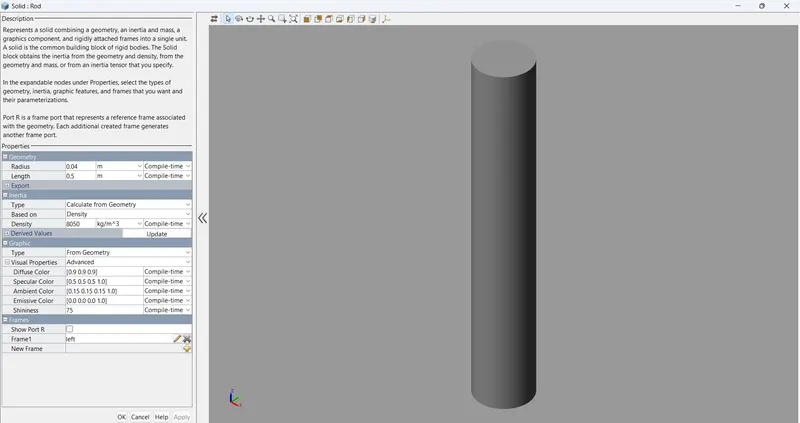
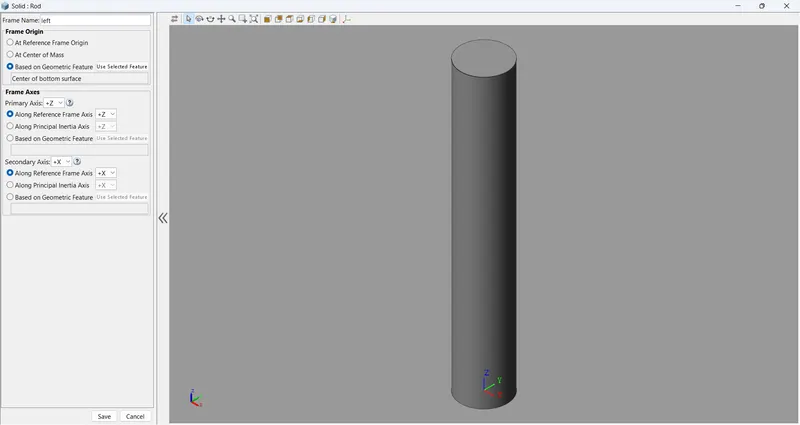
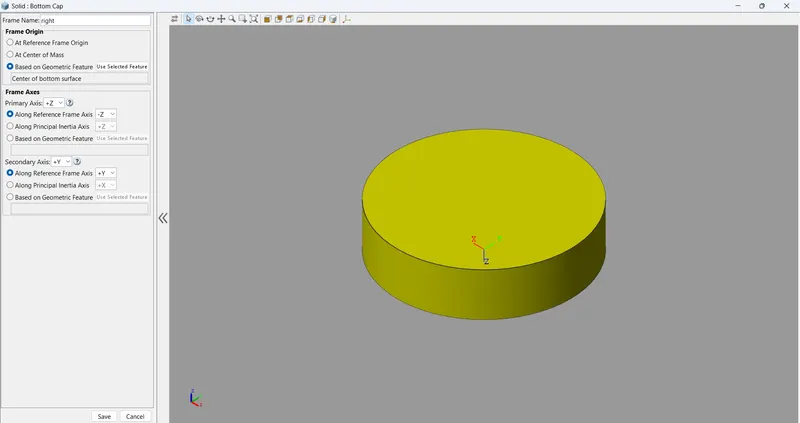
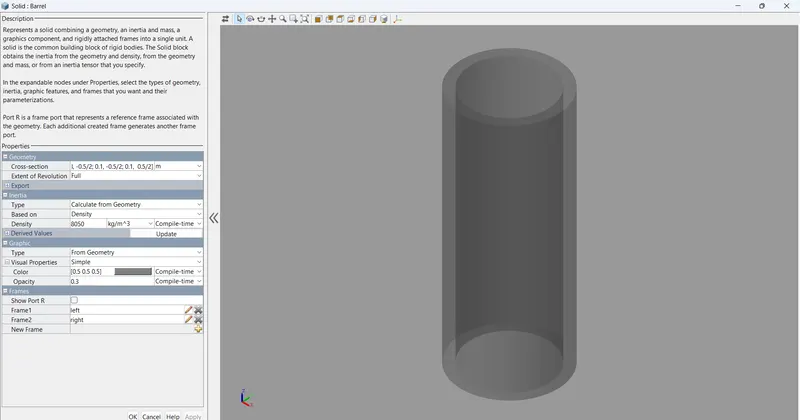
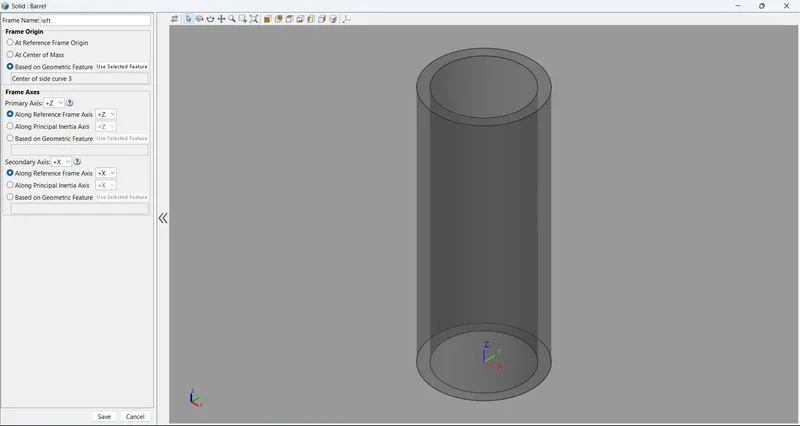
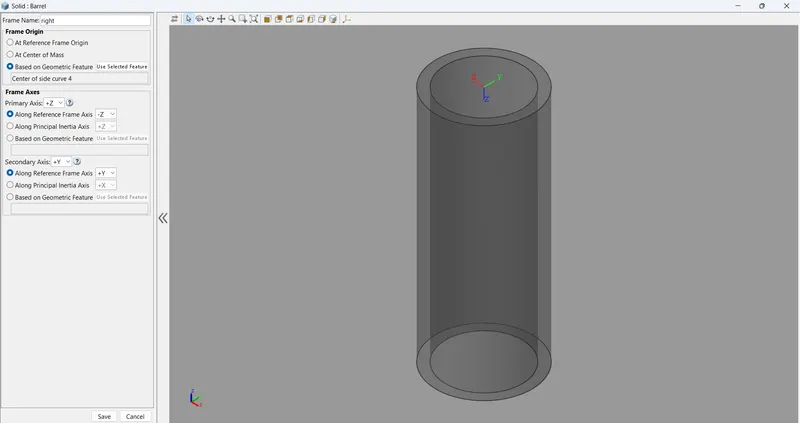
- The cylinder model
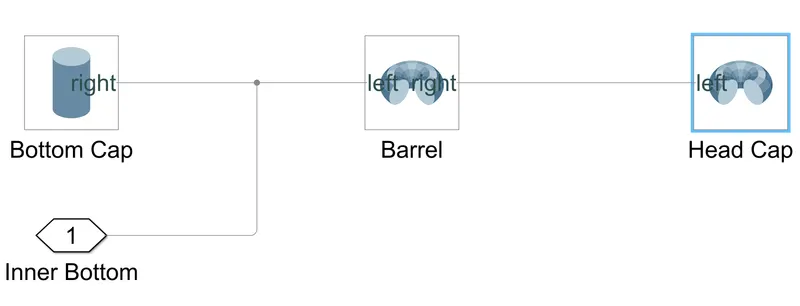
- The Cylinder dimensions
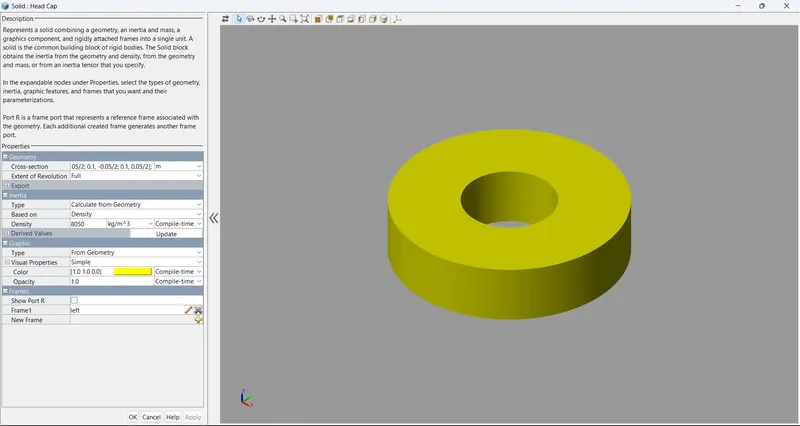
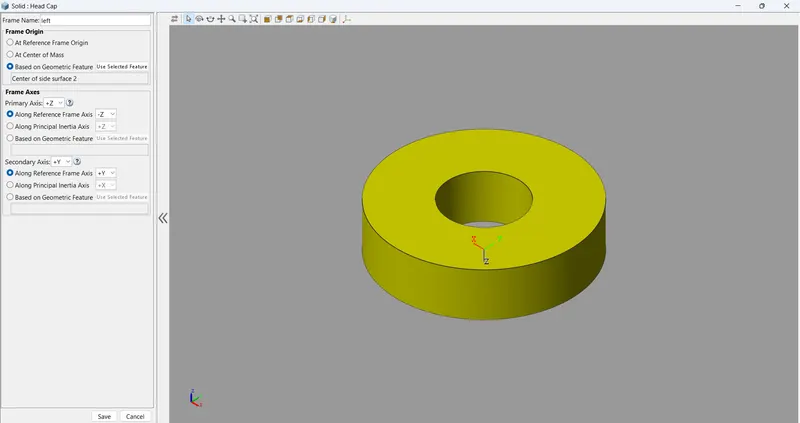
- The Hydraulic systems design
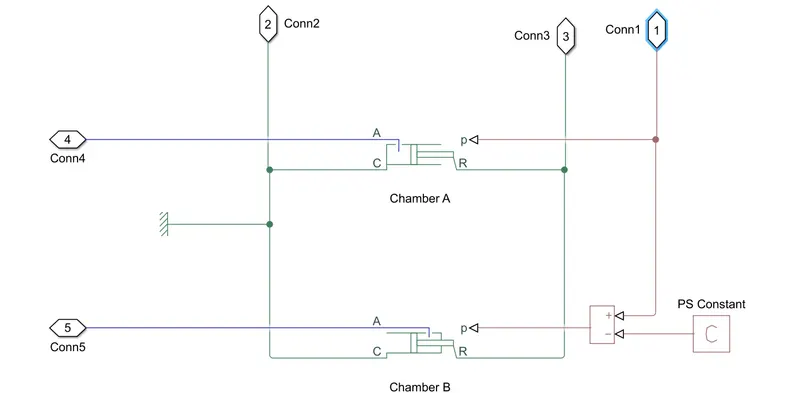
- Hydraulic ciscuit design
- Has been designed in reference to Hydraulic Interface - Dump Trailer with Hydraulic Cylinder.
- Hydraulic Interface - Dump Trailer with Hydraulic Cylinder - MATLAB & Simulink - MathWorks India
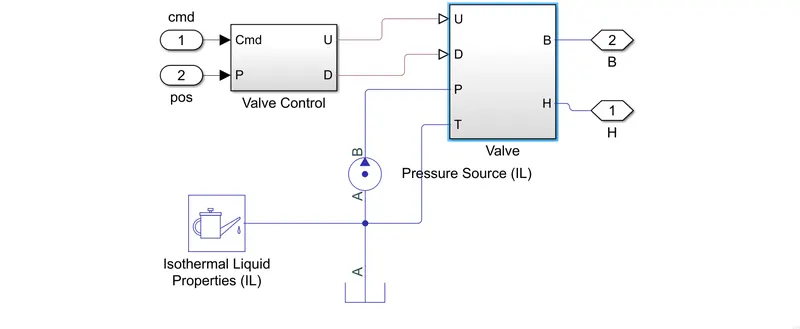
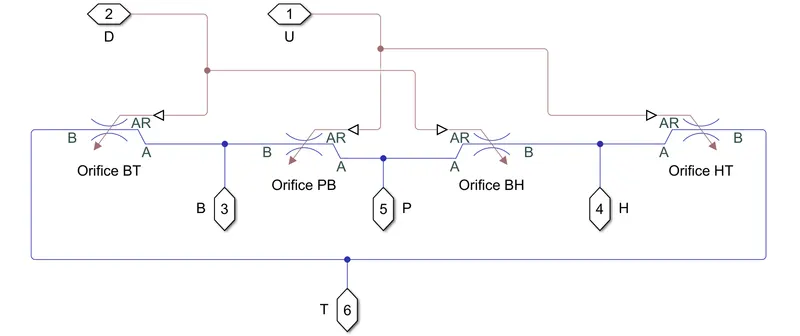
- Valve design
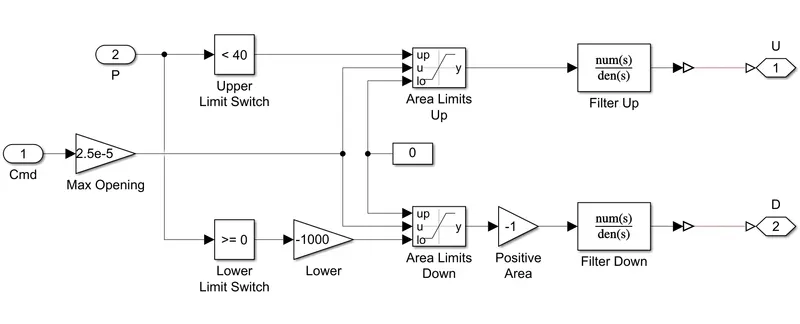
- Valve control design
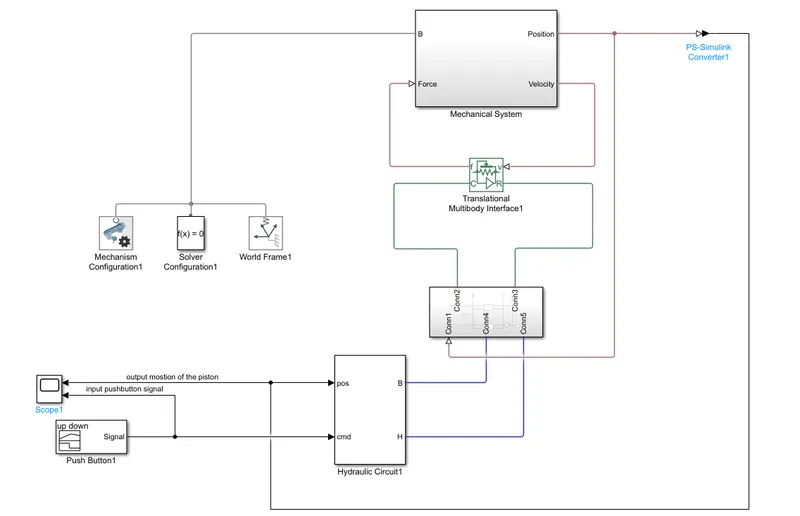
- The complete model
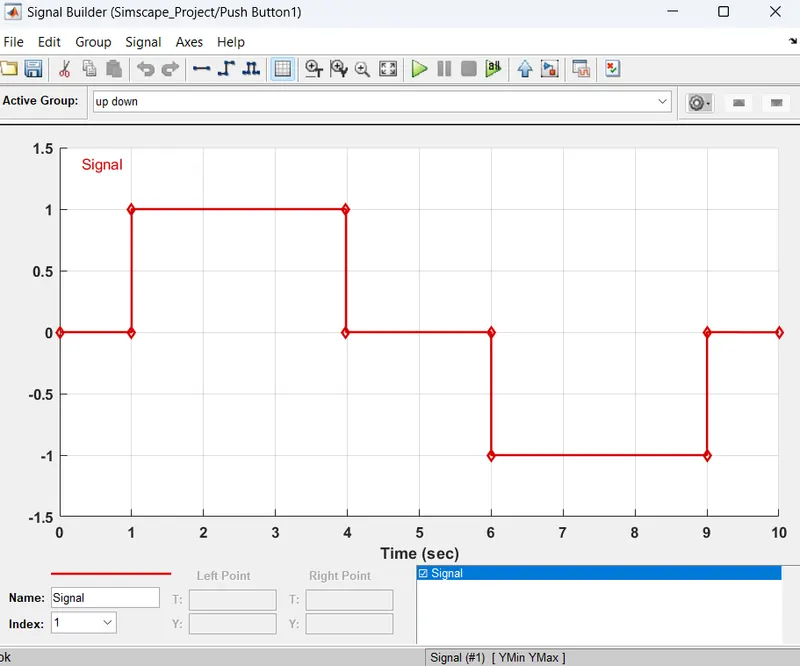
- The input signal (push button)
- The output signal generated
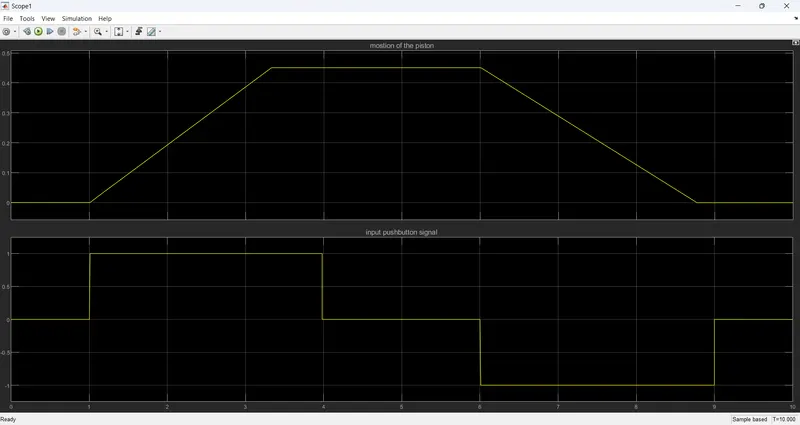
CONCLUSION
- Here the Mechanical system of the cylinder is built using Simscape Multibody library components/blocks and the Hydraulic system is modeled using Simscape library physical components.
- The Input signal to the valve is given from the Signal Builder block.
- Under the mask of the Double-Acting Hydraulic Cylinder block in the scissor hoist are the mechanical and hydraulic subsystems, which are connected by a Translational Multibody Interface block.
- The Prismatic Joint block in the mechanical subsystem provides the position information to the two actuators in the hydraulic subsystem, the Head Chamber and Bottom Chamber, that have the opposite settings of the Mechanical orientation parameter.
- The Constant block C provides a position signal offset to the Head Chamber actuator because when the Bottom Chamber is at dead volume (where position p = 0), the Head Chamber is at a maximum stroke.
- All the relevent documents have been uploaded.