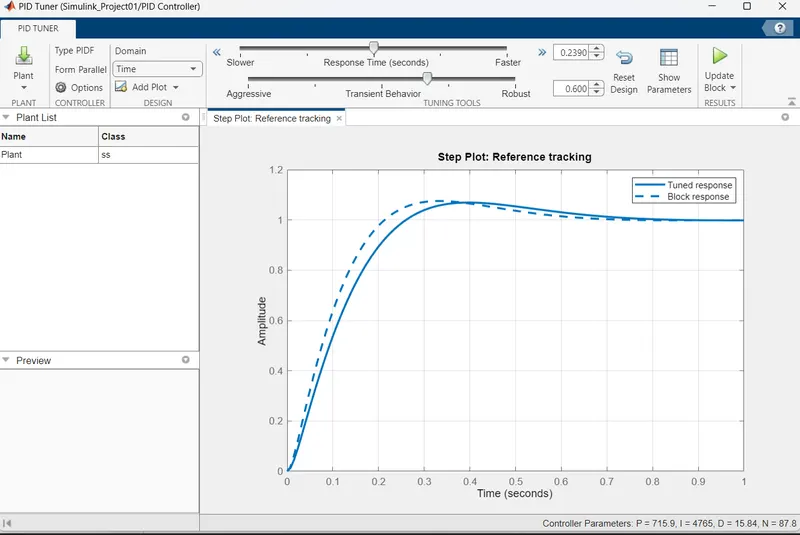
Project - Position control of mass spring damper system
Q No 1
Ans :
i) Transfer function of a mass spring damper system:
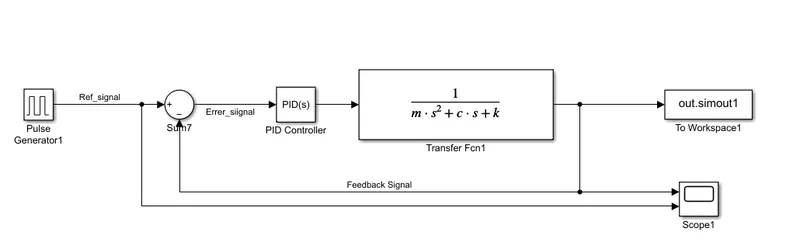
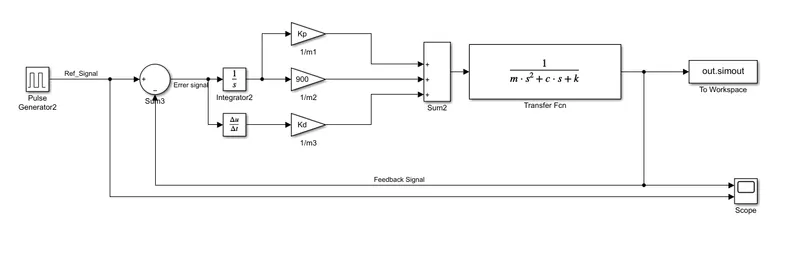
1. First of all we connect the PID controller Block and then the transfer fun block.
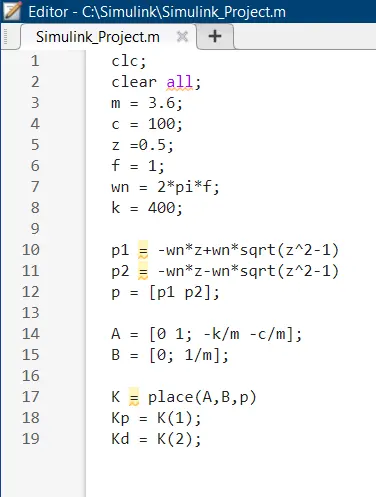
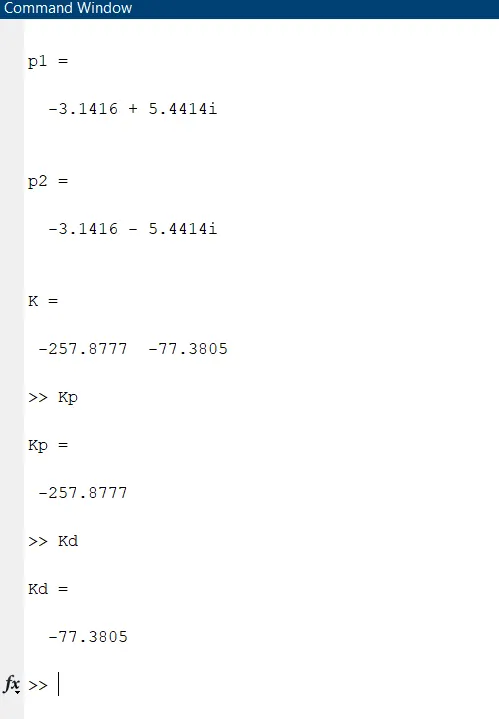
2. In PID Controler Kp,Kd values are find by using the place Command
3. Ki(ie. 900) value is asumed for the sutable result.
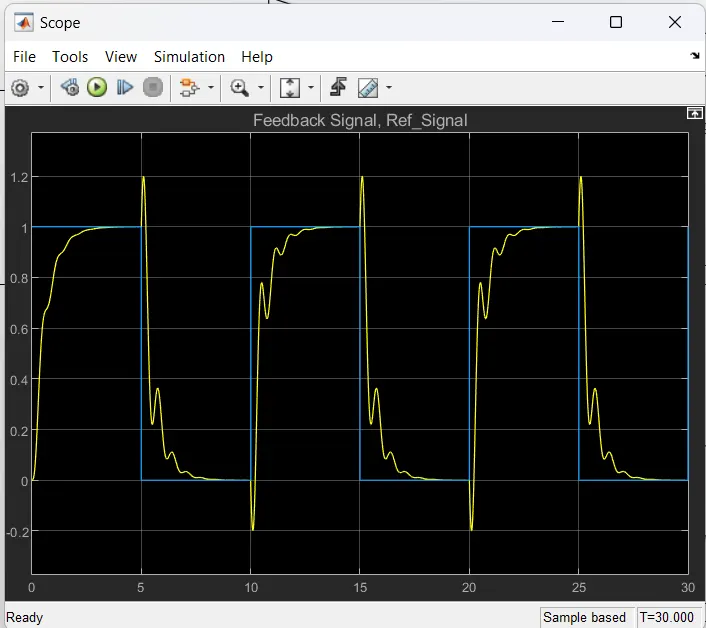
Poles are Imaginary pair with negative equal real part and equal but aposite imaginary parts then system behaves like the underdamped.
poles lying on the left hand of the plane which indicate it is a stable system.
ii) By Adding a PID controller
1. In witch we replace the PID design by PID Control Block.
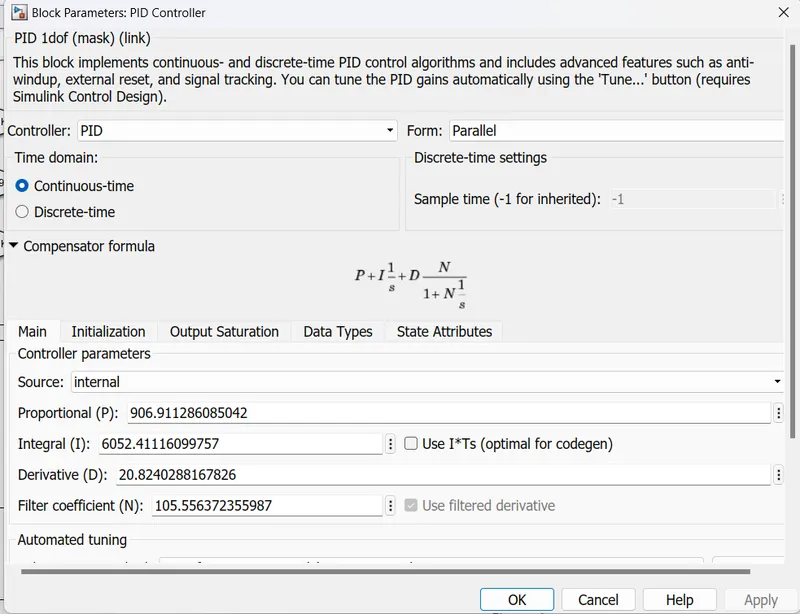
2. And place the Kp,Ki,Kd values manualy and tune it.
3. Adjust the Graph and Update the Block.
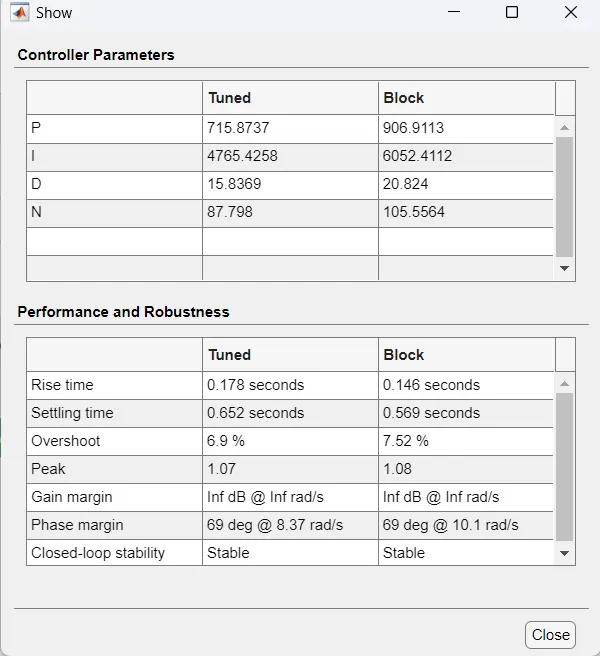
4. we get the updated values of Kp,Kd,Ki.
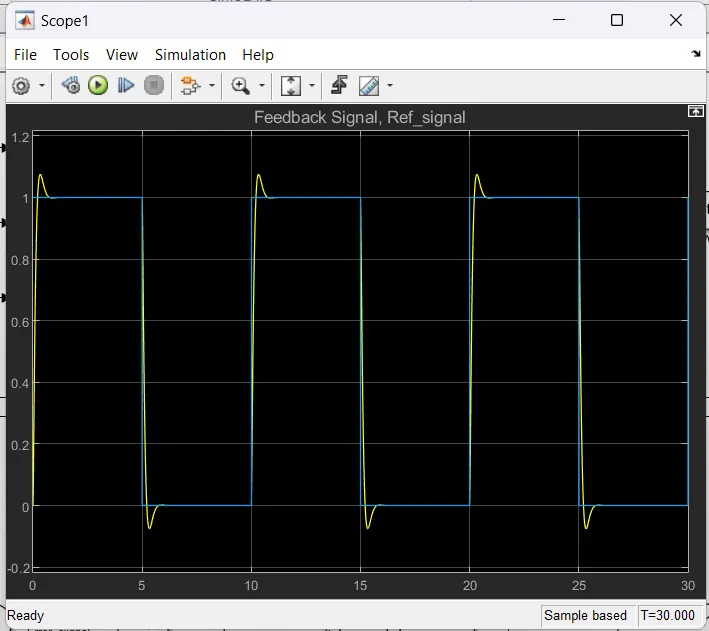
we find the graph is geting stable when the overshoot value and pick value is lower.