Project - Position control of mass spring damper system
Given Parameters are:-
m=3.6; %kg;
k=400; %N/m
c=100; %Ns/m
Here,
Kp & Kd find out using place function.
Kp=-257.88;
Kd=-59.28;
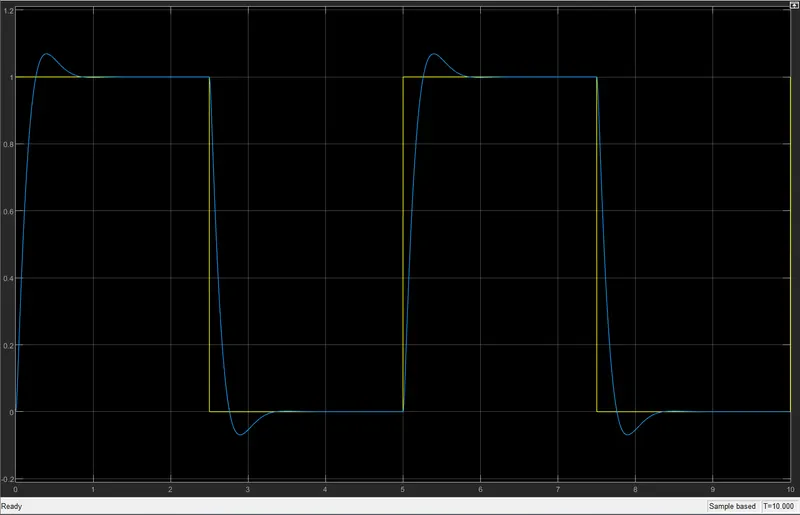
Reference input signal as given in graph-
Amplitude= 1; Period= 5 sec & pulse width of 50%.
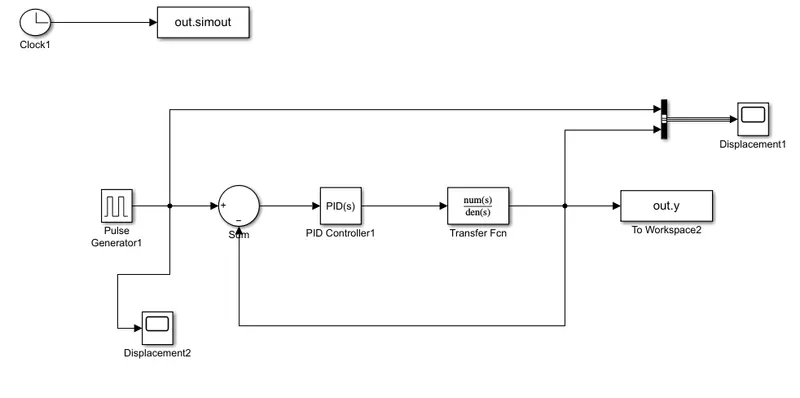
Case-1) Spring mass damper using PID Controller directly-
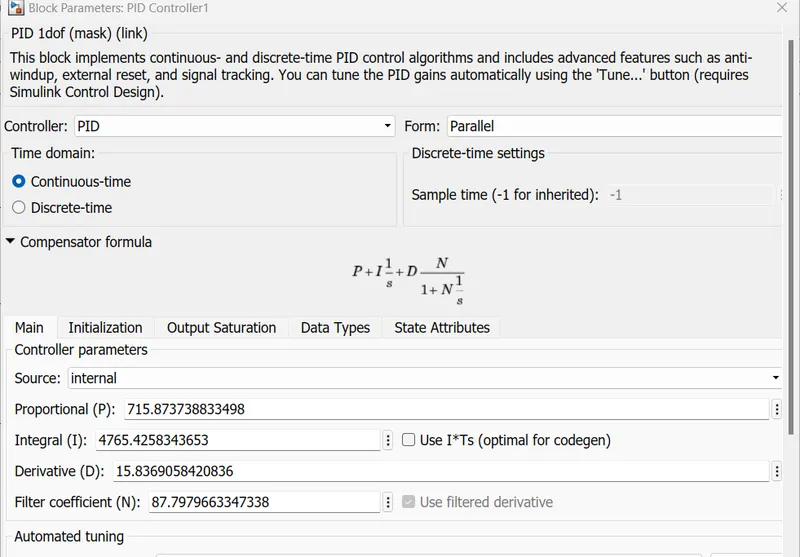
Here PID controller auto tune values of P, I & D controller.
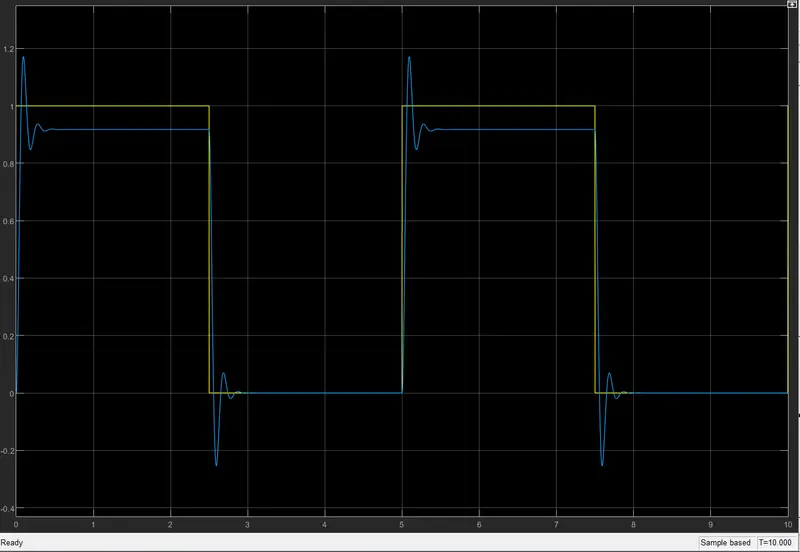
Response:
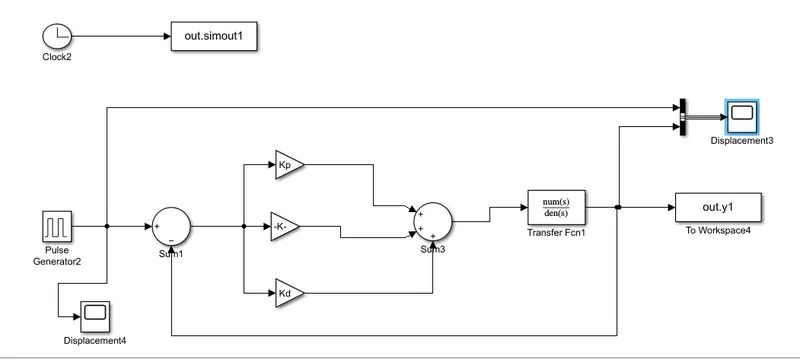
Case-2) Spring mass damper using PID controller with place command:-
Here,
Kp & Kd find out using place function.
Kp=-257.88;
Kd=-59.28;
Response:
Summary:-
with these project & all weeks challenges, we have learned a lot in simulink basics module.
we can design spring mass damper model and evaluate various responses by using different values of zeta and with different values of integral controller.
With place command we can calculate PI controller values also. we can directly use transfet function and PID controller block also. In PID controller Tuning menu helped for calculating PID values directly.
Please find the attached files of model and response graph & the relevant data in .m file for your information and reference purpose only.