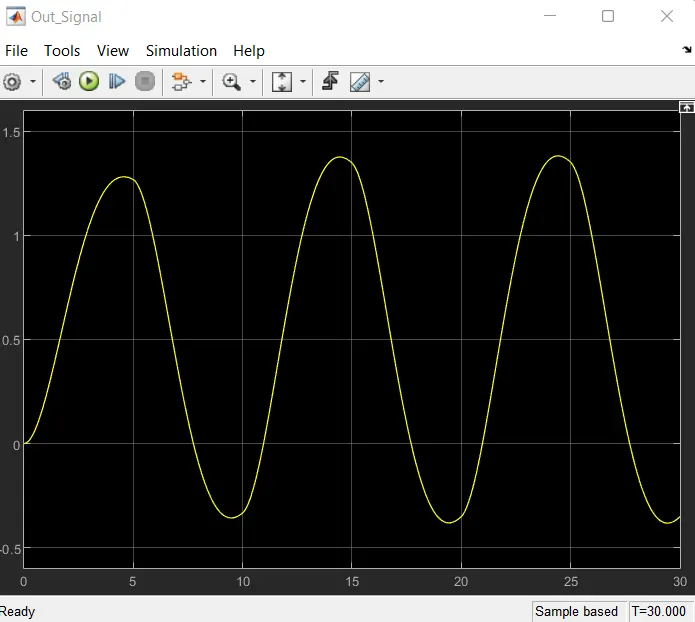
Project - Position control of mass spring damper system
Let first we see the simulink model:-
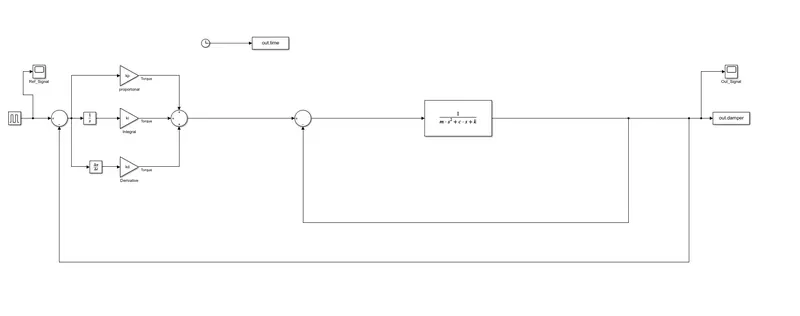
Now we see the script file:-
%% design parameters
m=3.6;
k=400;
c=100;
%%Equivalent Wn
wn=6.2832;
fn=1.0;
%%design parameters
zeta=0.5; %%underdapmed system design
%%Desired poles
p1=-zeta*wn+wn*sqrt(zeta^2-1);
p2=-zeta*wn-wn*sqrt(zeta^2-1);
P=[p1;p2];
%%Design of PID controller
A=[0 1; -k/m -c/m];
B=[0 ; 1/m];
%%pole placement design
K=place(A,B,P);
%%kp,kd & ki
kp=3.8602;
kd=628.00;
ki=0;
OUTPUT:-
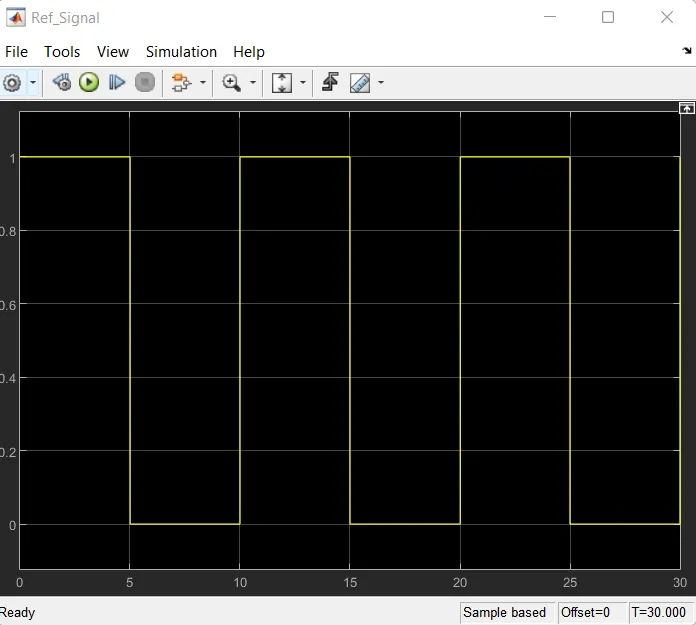
i)Reference signal:-
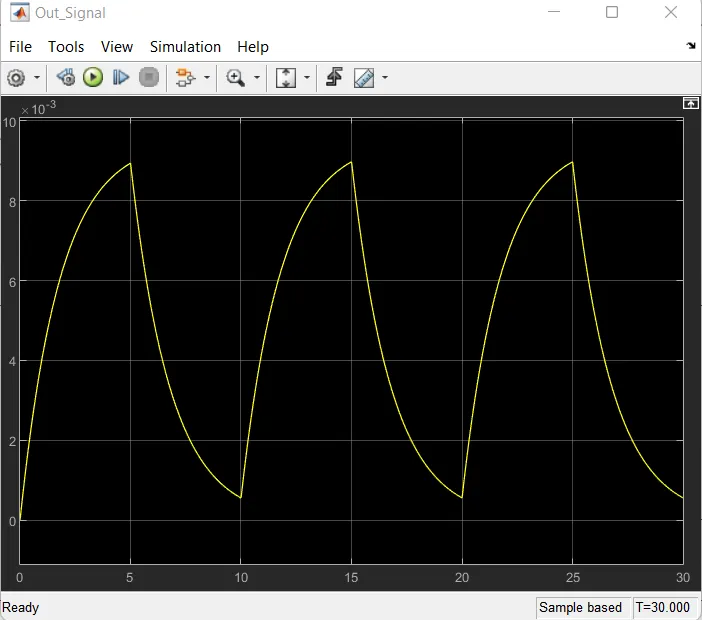
ii)Output Signal(When ki=0):-
ii)Output Signal(When ki=400):-