Project - Position control of mass spring damper system
1)
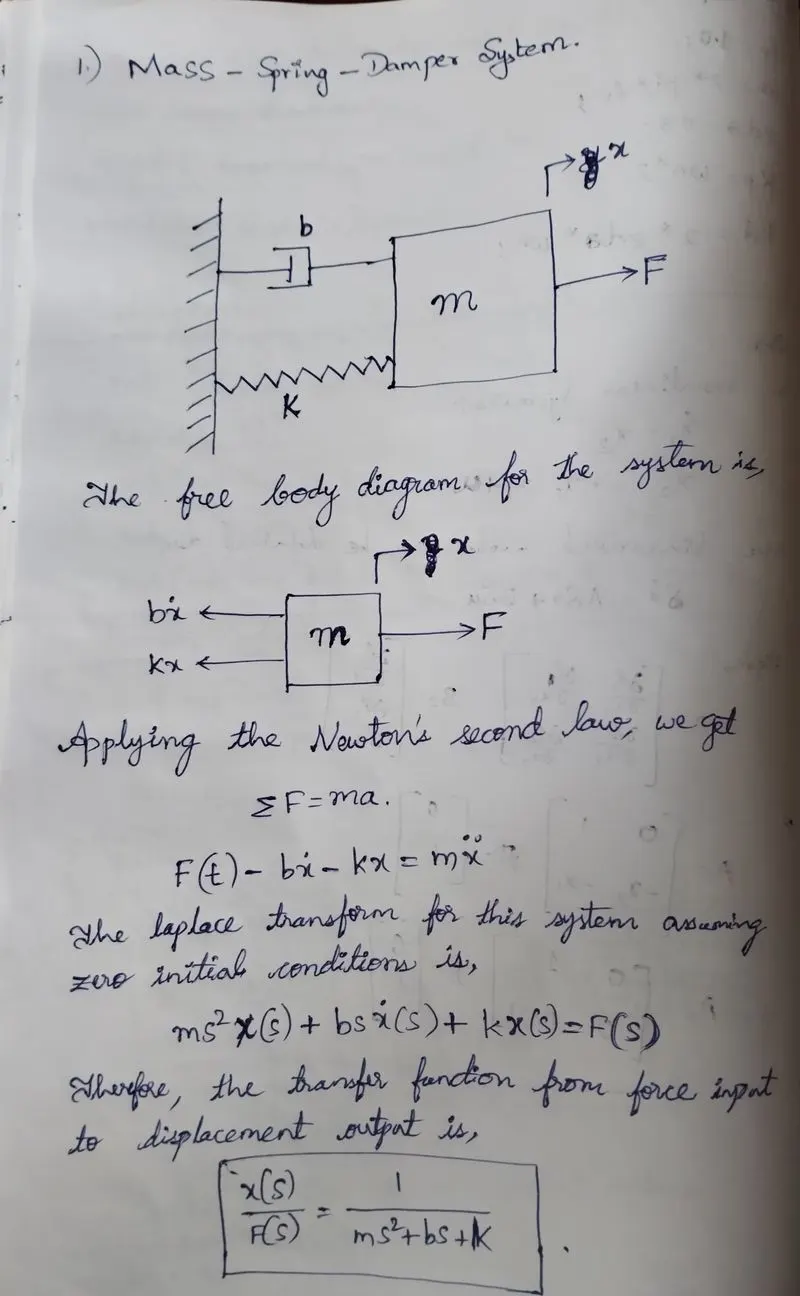
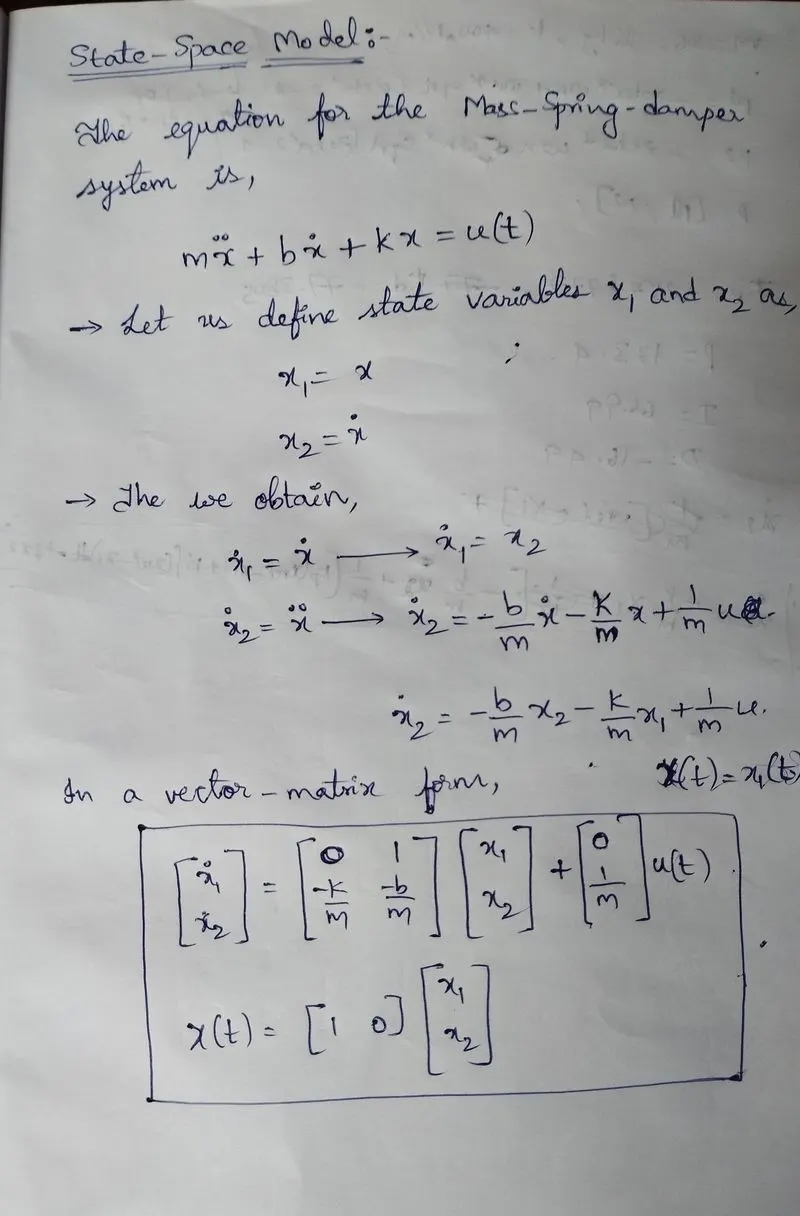
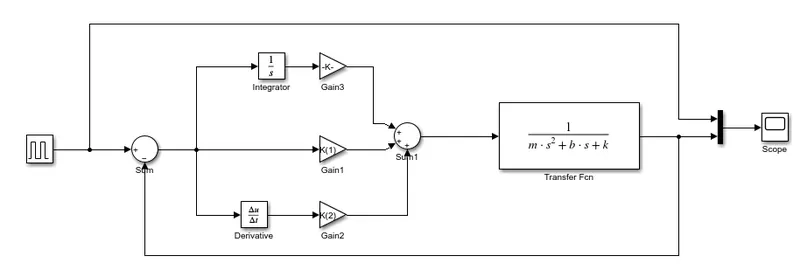
Simukink model:
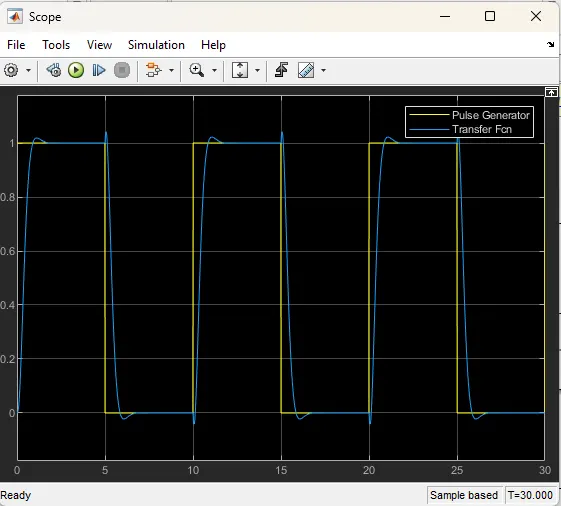
The simulink model is designed for the Mass Spring Damper system with PID controller, and the scope shows the response between the response of Spring mass damper with PID and without PID.
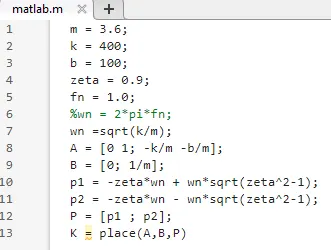
Matlab code:
Matlab code is generated to give the values of the Mass, Spring, and Damper constants, Zeta, Wn, A matrix and B matrix, Poles, and Kd, Kp as shown below,
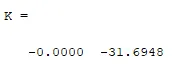
Output:
Conclusion:
By using the PID controller to the Spring Mass Damper system, we reduce the Overshoot, undershoot, delay time, response time, which shown in the graph.