Project - Position control of mass spring damper system
In the model, the mass spring damper system was employed as a transfer function. To change the force on mass such that its location complies with a reference signal, include a PID controller. The pulse wave form generator's pid control and transfer function matlab model.
In this project, a mass spring damper system that may move in any direction is being controlled by a PID controller that was created using Simulink.
Kd and Kp, which are parameters determined by the place command (K=place(A,B,P)), should be included. (use gain block to mention values of Kp, Kd, and Ki).The output current of the model serves as the source of feedback for Kd.Manually adjust various Ki values and evaluate the effects on the outcomes. And for comparison, I've included screenshots for various Ki values and a simulated graph.
Commands:
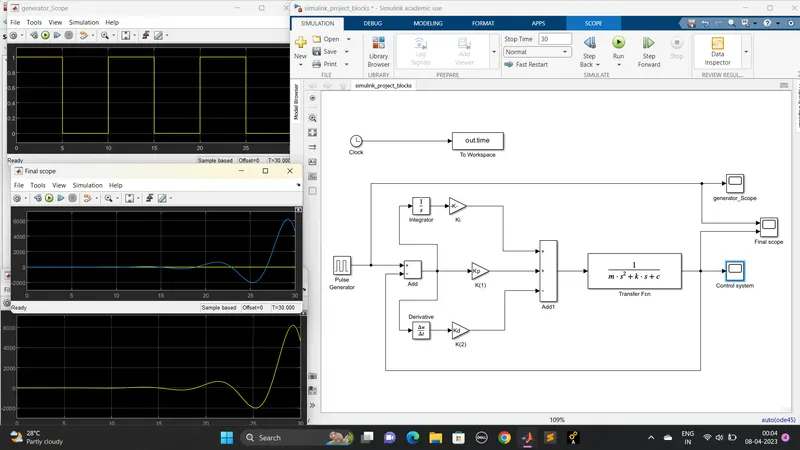
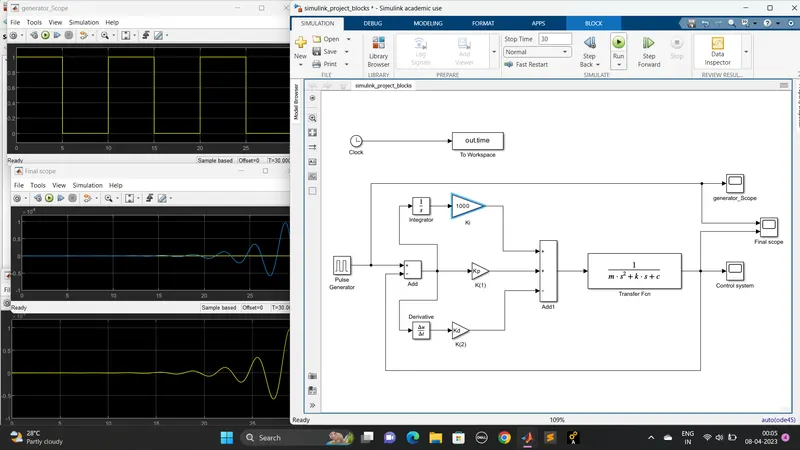
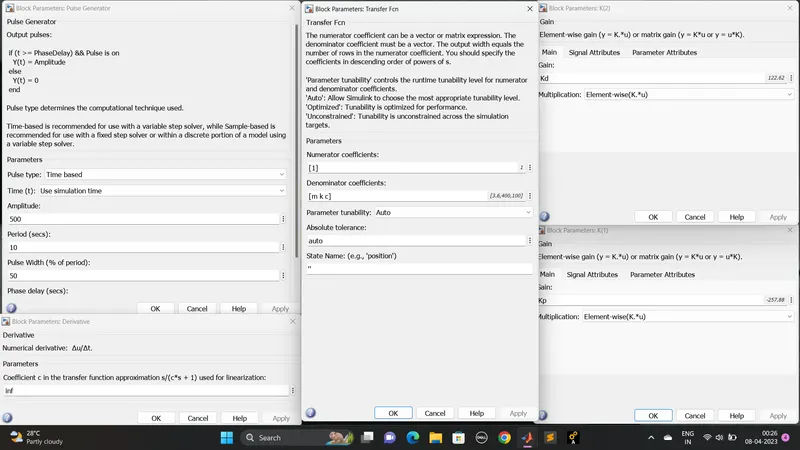
to finish the project "Position Control of Mass Spring Damper System" and incorporate the transfer function into the model. When using Matlab and Simulink Wave from Plot, add a PID controller to the force on the mass so that it can be made to follow a reference signal.