Project
The aim is to prepare a technical report explaining the model properties & comments on the results of all terrain BAJA vehicle,
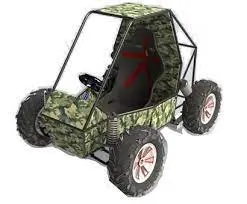
All terrain vehicle is also known as light utility vehicle, the image of baja vehicle is as follows,
Case : 1
Simscape model for baja atv with cvt :
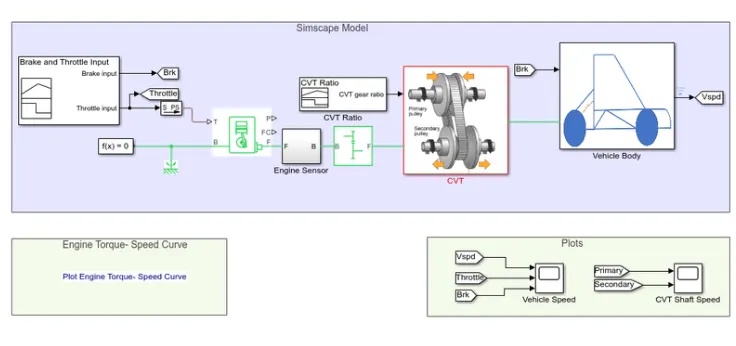
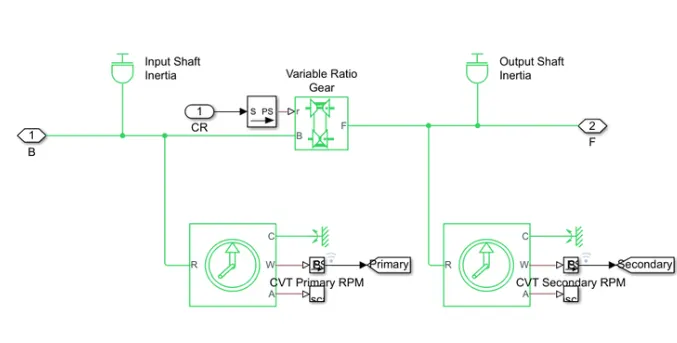
The simscape model of cvt consists of signal builder,generic engine,motion sensor,vehicle transmission,vehiclebody,tyres and solver configuration blocks,the cvt subsystem include transmissin block,input and output shaft inertia aand motion sensors, and it has initial engine rpm of 2100 and mechanical rotation for the driven pulley and driver is 0.8 & 0.7.
CVT :
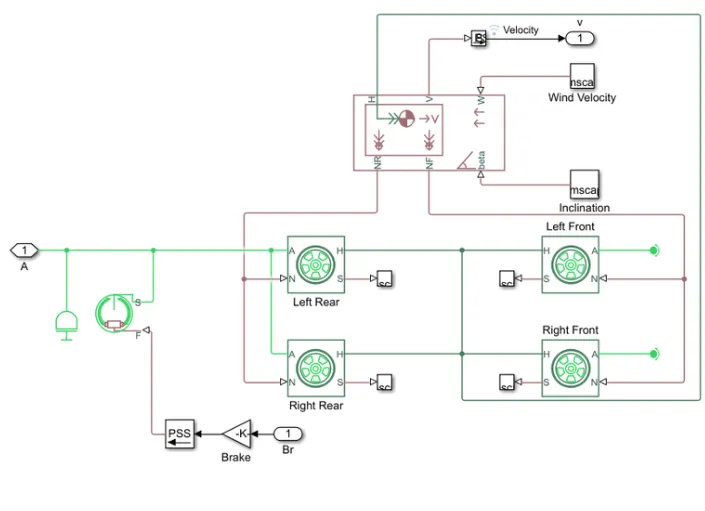
Vehicle body subsystem:
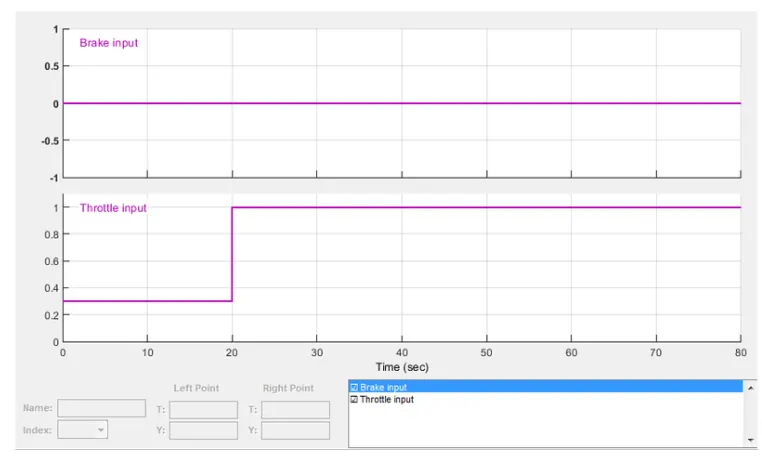
The signal builder is used as input for brake, throttle and gear ratio, brake input is maintained as 0 for overall simulation, the trottle input is given as 0.3 for 20 secs and increases to 1 for overall simulation,
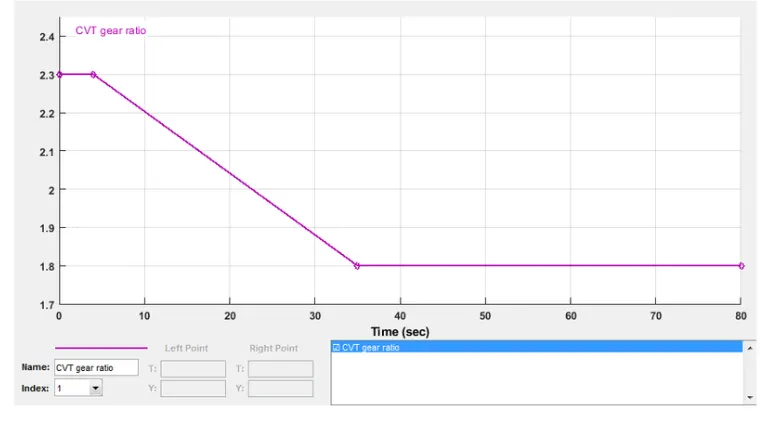
Cvt gear ratio block input:
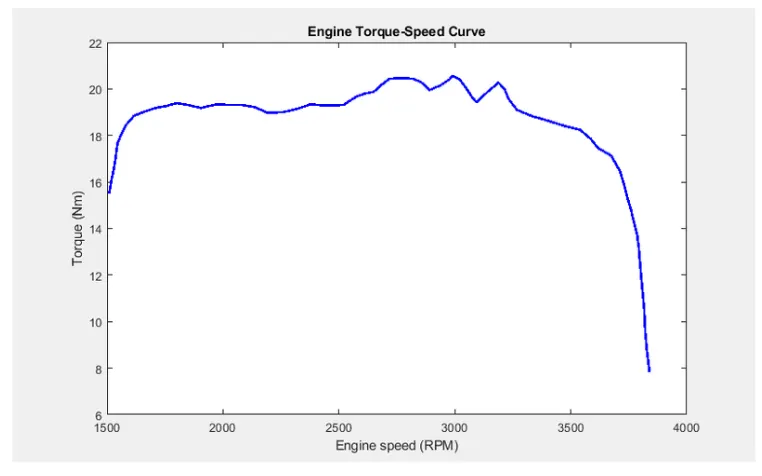
Engine torque speed curve:
Output for case :1
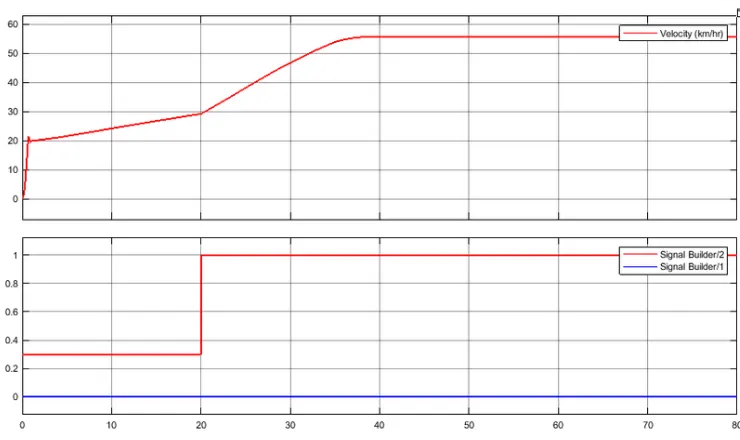
The graph vehicle attain its maximum speed (v=55km/hr) at full throttle = 1 after 30 sec and then remain constant, the brake input value is zero,
Cvt shaft speed plot:
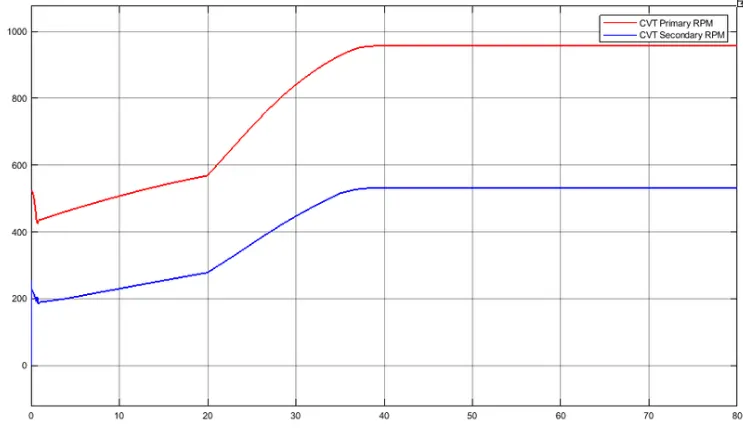
The value differ with respect to the gear ratio,
Case : 2
Simsacpe model for baja ATV with CVT using dashboard:
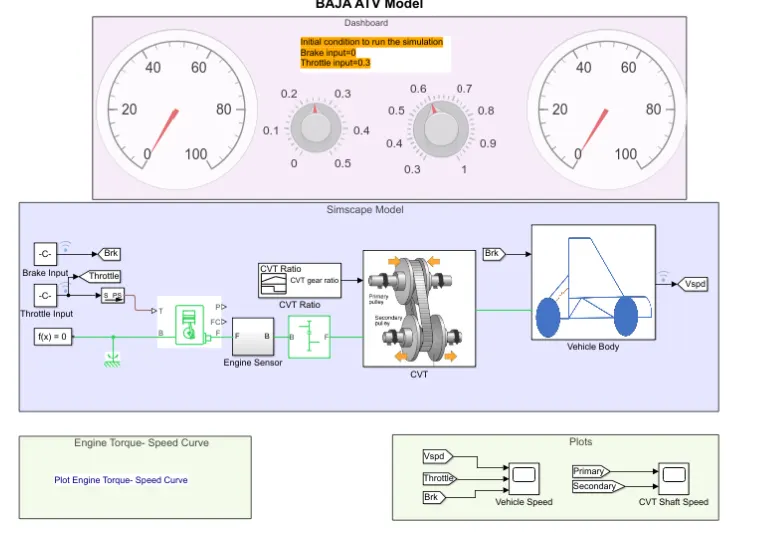
The dashboard which contains knobs to control the input,in this case th input throttle & brake are not provided using signal builder for the user.
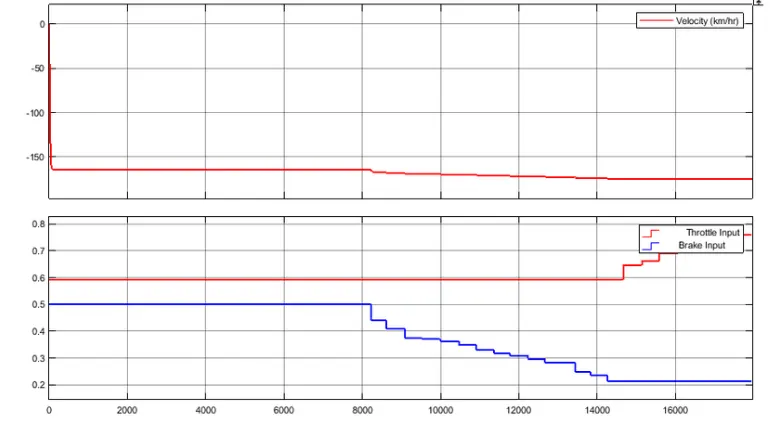
Output:
CVT shaft speed plot:
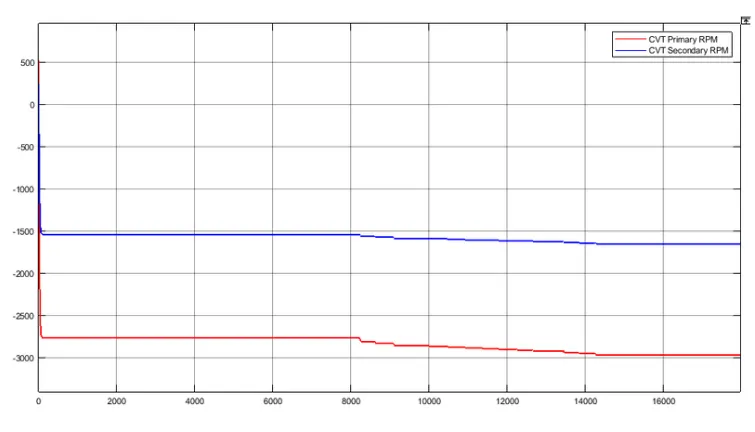
STUDY : 2
Case :1
Simscape model for baja with CVT using lookup table:
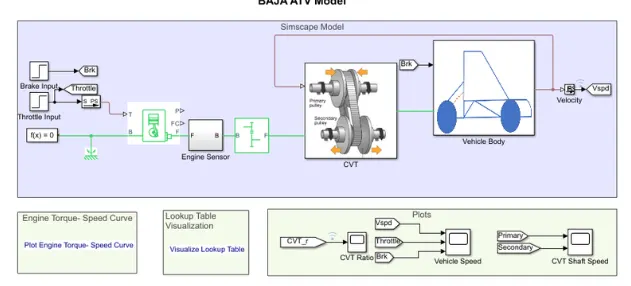
CVT subsystem:
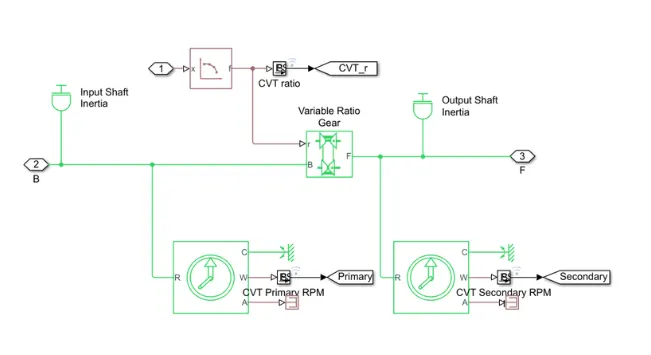
The different with the model and the first is the gear ratio input to CVT is provided using a lookup table, are same as before,
Vehicle body subsystem:
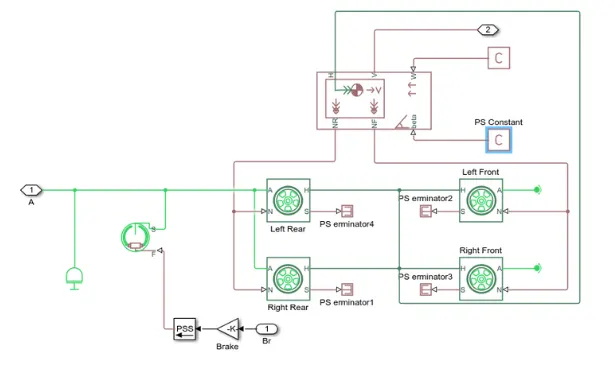
CVT gear ratio :
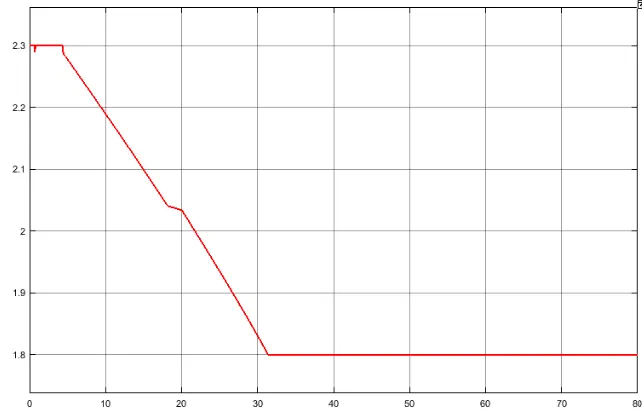
Lookup table:
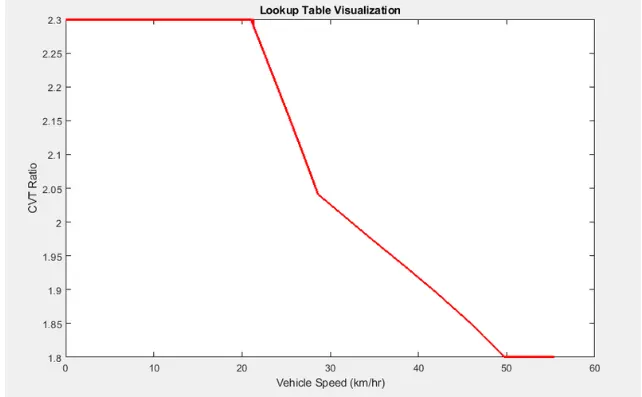
output:
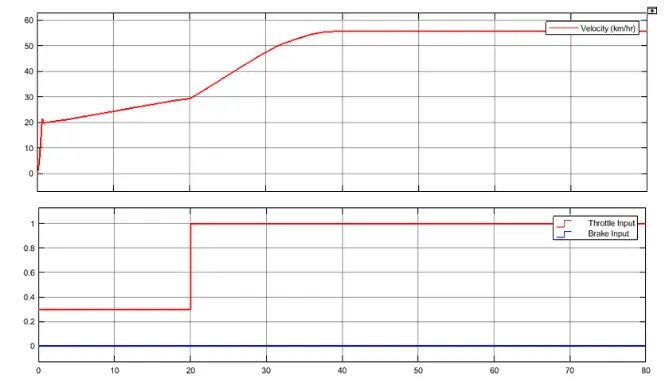
case :2:
Simscape model for baja atv with cvt using lookup table & dashboard,
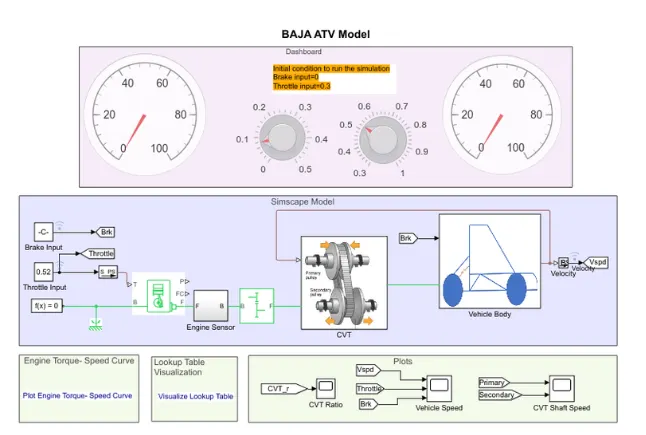
output of case 2:
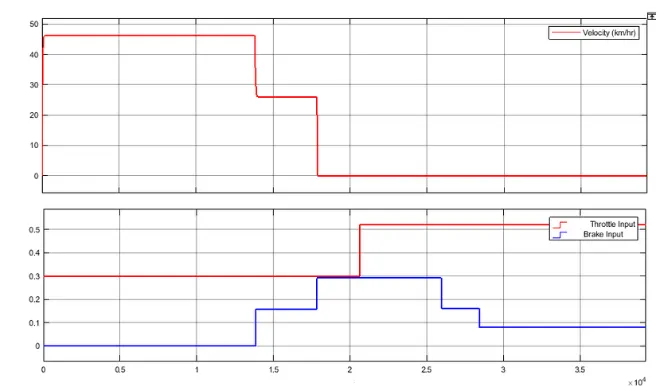
it is similar to the cvt dashboard in which velocity can be observed with change in throttle and brake inputs leads to increase velocity,
The conclusion is thus 4 models of baja cvt is analysed and report has been completed.