Project
1.System-level simulation of all-terrain vehicle.
BAJA ATV WITH DASHBOARD MODEL
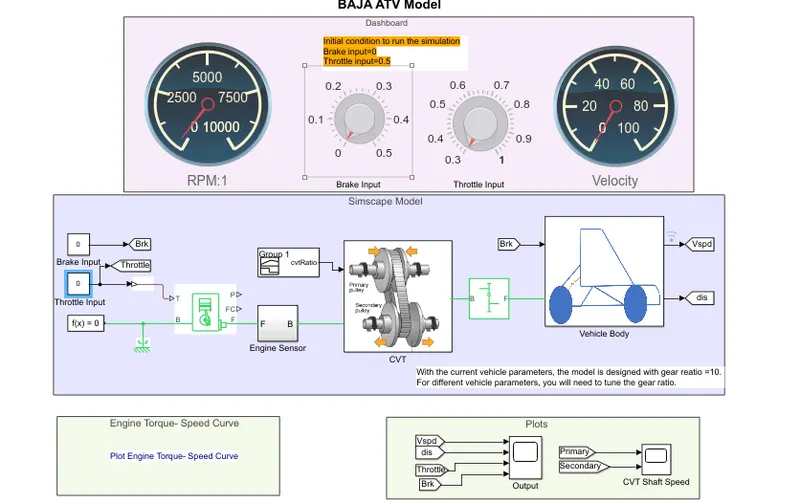
This is a dashboard simulation model for ATV. In this input is given through brake and throttle knobe. Different values are given and velocity,RPM and CVT shaft speed are being observed along with other values.
Initial conditions to run the simulation are brake = 0 and throttle = 0.5.
In this model Generic engines are employed because only basic parameters are used. The input to the CVT is generated by signal builder.
The layout of CVT is given below.
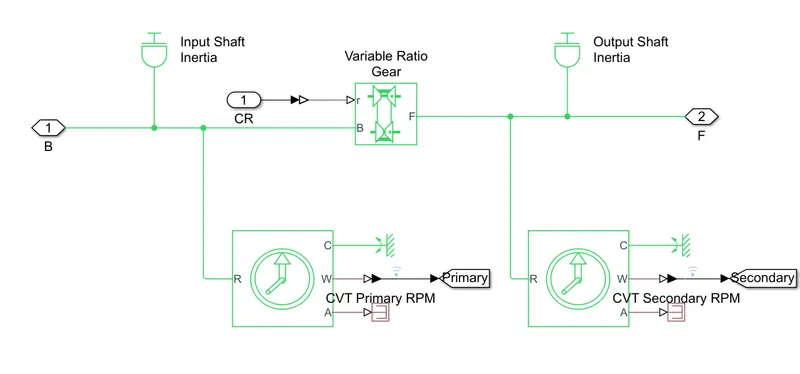
Ideal rotational motion sensors are used here.
The simulink model for vehicel body is
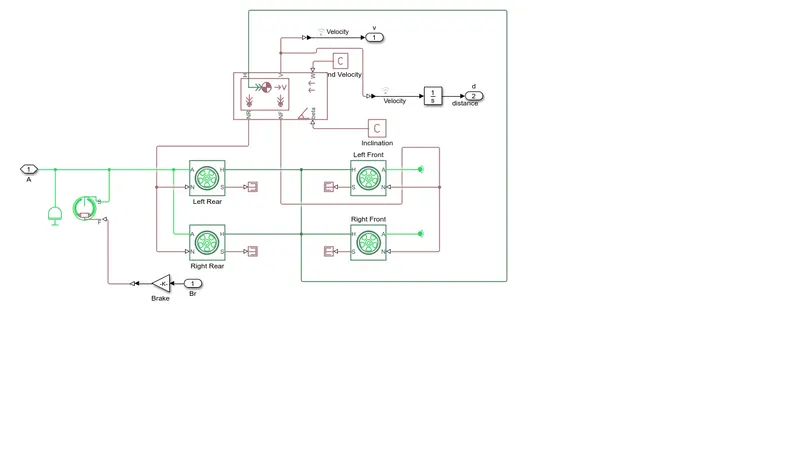
Velocity and distance is being determined from vehicle body. This then fed to the scope later on.
Two wheel per axle configuration is adopted.
Conditions:
1. Brake=0 and throttle=0.5
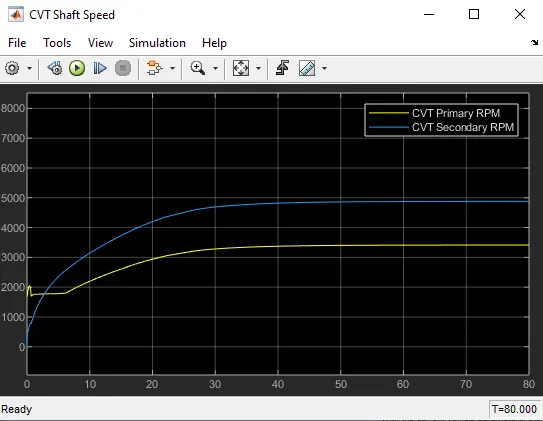
CVT rpm obtained is shown above. It shows that after 25 seconds the RPM becomes constant and reach saturation.
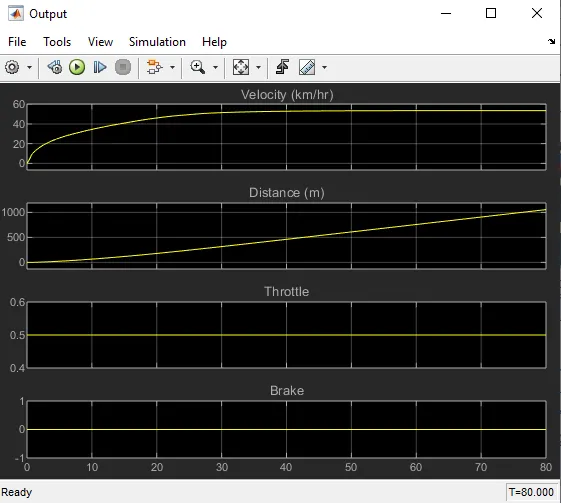
The Velocity and Distance from the vehicel body obtained for the throttle of 0.5 and zero brake.
2. Brake 0.4 and throttle=0.5
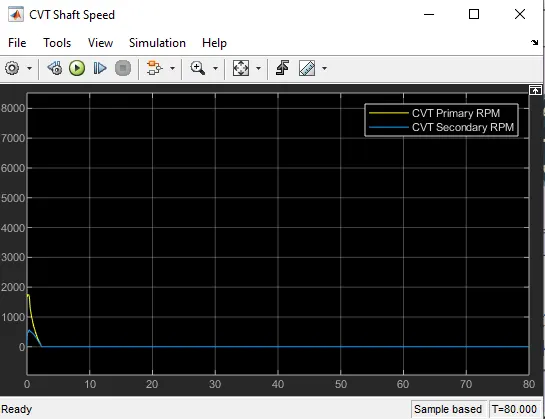
As the break value is increased the decrease in rpm can be observed. The RPM value has been brought down to zero after 3 seconds.
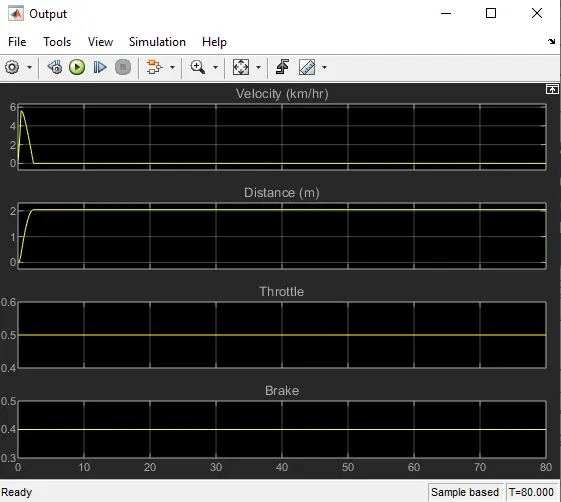
After initial increase in velocity, drop in velocity with increase in diatance is observed.
3. Break=0.4 and throttle=0.9
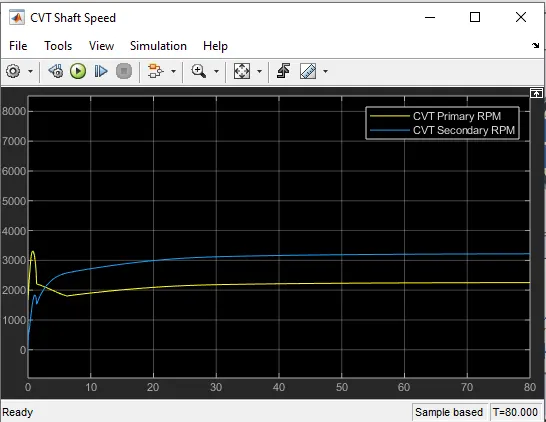
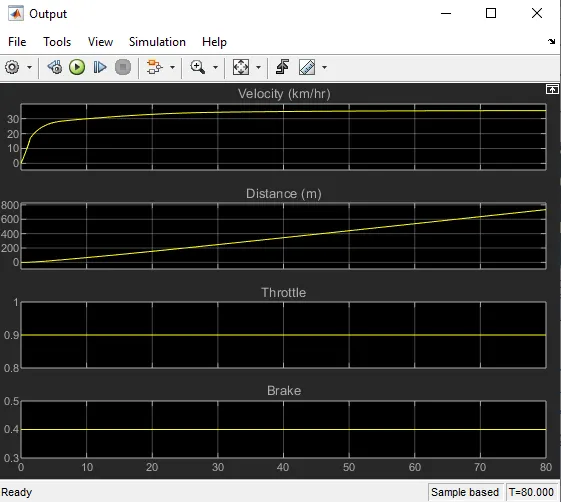
With the constant increase in distance the velocity increases. Velocity reaches saturation at 25 seconds.
Conclusion
Thus system level analysis of ATV simulation has been successfully completed. The analysis are done for three different valuues of brake and throttle. Various parameters are being checked.
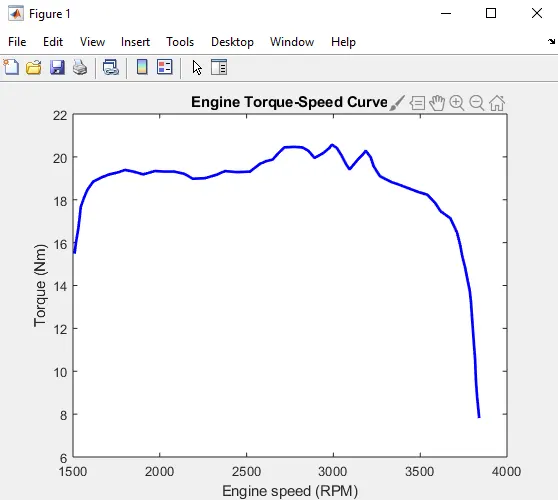
With increase in the RPM/Gear turn ratio the increases ubto a limit and when reaches a certain rpm the torque reduces and velocity increases.