Project
Hi,
I would like to share you a technical report for the baj all terrain vehicle art model, i have downloaded the model from the given link and made a clear observation about the system level simulation.
This model is explaining the working principle of the Baja all terrain vehicle, the major parts used in this system are throttle, brake, generic engine, Continously variable transmission(CVT) and vehicle body with Front and rear tyre, brake by combining this above mentioned parts the baja all terrain vehicle model is created and simulated, i would like to explain all parts used in this simulation.
THROATLE INPUT
I would like to start this with throtle input, they have used knob to give the value for the throatle this value can vary between 0.3 to 1. this input value is connected with goto block and input value for the generic engine(T). this input signal denotes the phisical input values of throatle applied to a system.
BRAKE INPUT
This input signal denotes the phisical input values of a brake applied to a system, They have used knob to give the value for the brake this value can vary between 0 to 0.5. this input value is connected with goto block to use somewhere in the model.
GENERIC ENGINE
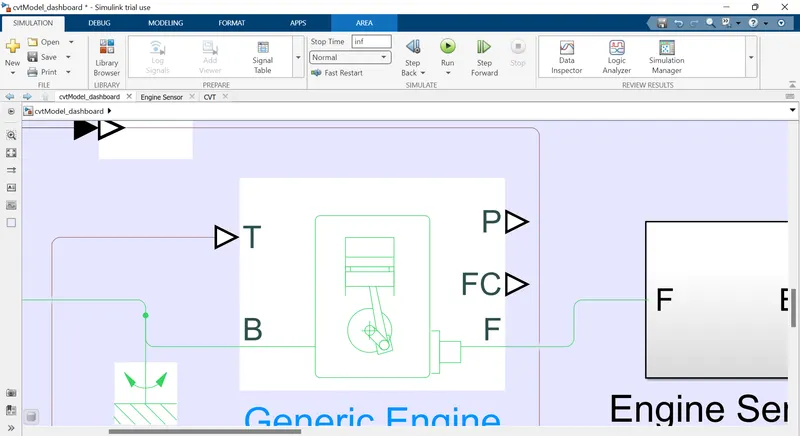
This is the main engine block of this overall system, this is representation of actual engine, in this model we are giving throatle input from previous block and B is the mechanical rotational port so that is connected with mechanical rotational reference, so by changing throatle input we can able to adjust the speed of a engine. the another end of the mechanical rotational port is connected through the RPM sensor to CVT Input shaft.
CVT
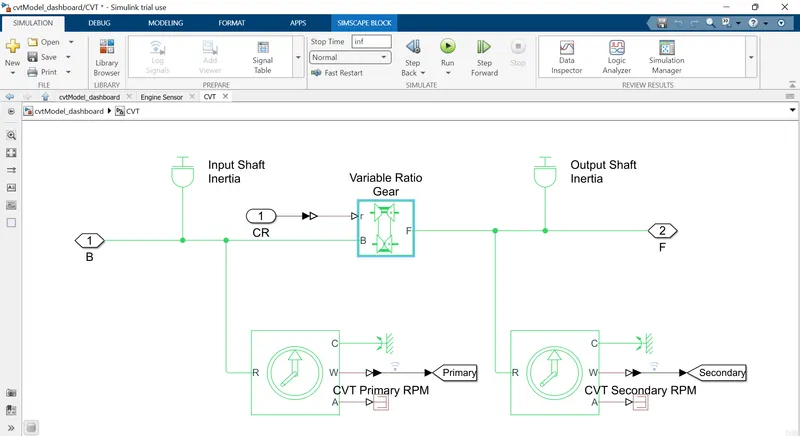
Continously variable Transmission is a type of automatic transmission, the major component of the CVT is two width adjustable pullies and connecting belt, by adjusting the width of the pullys we can able to change the transmission ratio infinitely, in this model we are using variable gear ratio block in CVT subsystem. this CVT gear ratio is given by signal builder block, in a variable gear ratio block we are giving that throatle speed as Base input and F is connecting as a output with respect to the given Gear gear ratio. in both input and output speed they are connected sensors to monitor the speed.
VEHICLE BODY
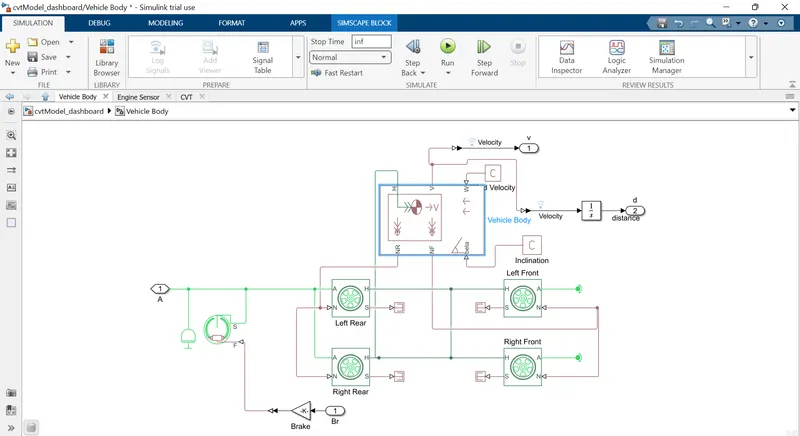
Then by using simple gear we are connecting those shaft speed to vehicle body, at first we are connecting this speed value with the brake shoe, the brake value is given by the Brake input after that that speed is connected to both rear wheels mechanical rotational conserving ports and those other end is connected to mechanical translational conserving ports. this mechanical translational values are connected to the vehicle body's translational conserving port.NR and NF are the physical signal ports that are connected with all 4 wheels in this vehicle body we can able to give inclination and wind speed for good accuracy in results by giving all this data we can able to figure out the velocity of the vehicle motion.then this velocity and output Speed are given in dashboard for monitoring.
 D
Thus the BAJA ATV MODEL is working.
Thanks,
DHARAN KUMAR R.