Project
AIM-Study the BAJA All terrain vehicle by comparing diffrent models with the help of simulink.
OBJECTIVE-
1) prepare a detailed report on all components used in creation of model and explaining the function of the all components and subsystem.
2) comparison between all five models present in file.
3)detailed analysis of all results.
Introduction-
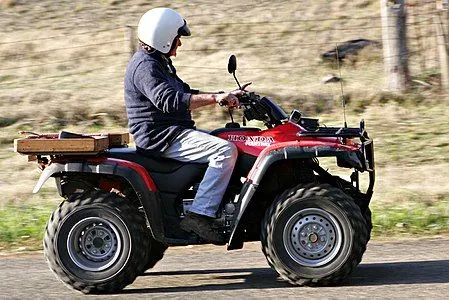
An all-terrain vehicle (ATV), also known as a light utility vehicle (LUV),[1] a quad bike, or simply a quad, as defined by the American National Standards Institute (ANSI); is a vehicle that travels on low-pressure tires, with a seat that is straddled by the operator, along with handlebars for steering control. As the name implies, it is designed to handle a wider variety of terrain than most other vehicles. Although it is a street-legal vehicle in some countries, it is not street-legal within most states, territories and provinces of Australia, the United States or Canada.
By the current ANSI definition, ATVs are intended for use by a single operator, although some companies have developed ATVs intended for use by the operator and one passenger. These ATVs are referred to as tandem ATVs.[2]
The rider sits on and operates these vehicles like a motorcycle, but the extra wheels give more stability at slower speeds. Although most are equipped with three or four wheels, six-wheel models exists and existed historically[3] for specialized applications. Multiple-user analogues with side-by-side seating are called utility terrain vehicles (UTVs) or side-by-sides to distinguish the classes of vehicle. Both classes tend to have similar powertrain parts. Engine sizes of ATVs currently for sale in the United States (as of 2008 products) range from 49 to 1,000 cc (3.0 to 61 cu in).
INTRODUCTION TO BAJA SAE-
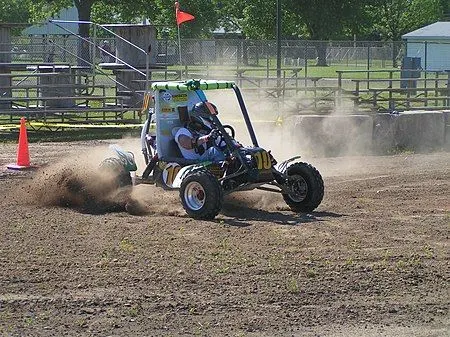
Baja SAE is an Collegiate Design Series competition run by the Society of Automotive Engineers International (SAE International). Teams of students from universities all over the world design and build small off-road cars. The cars all have engines of the same specifications. As of 2018 the engine has been an unmodified Briggs & Stratton Model 19 Vanguard engine single-cylinder with a displacement of 305cc and power output of approximately 10 bhp (7.5 kW).
The goal in Baja SAE racing is to design, build and race off-road vehicles that can withstand the harshest elements of rough terrain. The vehicles used in Baja SAE racing are often similar in appearance to dune buggies. Before 2007, the events were called "Mini Baja."
Each year as many as 141 Baja cars are entered in the Baja SAE events across the US and around the world. International events are endorsed by SAE International[1][2] and are held in Brazil, Korea, South Africa and México.
All cars must adhere to SAE International's rules, and pass SAE's technical inspection and judging; a car may not race until all safety inspections are passed. Small engine manufacturer Briggs & Stratton sponsors Baja SAE teams by providing the SAE sanctioned engine free of charge, at a replacement rate of one engine for every two years in competition.
There are multiple dynamic events, photographed by Official SAE Photographer Jethro Gaines of J. Gaines Studio, usually four per event, as well as a single four-hour endurance race. The dynamic events include hill climbs, sled pulls, maneuverability events, rock crawls, and suspension & traction events. Previously the cars had to be able to float and propel itself on water under its own power. This was changed from the 2012 competitions onward due to safety concerns.
Static events, such as written reports, presentations and design evaluations are provided by participating teams. This is when the teams are judged on ergonomics, functionality, and producibility of their cars; ensuring that the final placement of the team does not rest solely on the vehicle's performance but rather on a combination of static and dynamic events. Required reports detail the engineering and design process that was used in developing each system of the team's vehicle, supported with sound engineering principles.
Also, a cost report that provides all the background information necessary to verify the vehicle's actual cost is used to rate the most economically feasible for production. These reports are submitted weeks in advance of each event, where the presentations and design evaluations are given on site in the presence of SAE design judges. Teams with noticeable differences between the car and the cost report can be audited, where if the report and car do not match, the team will be served penalty points.
Starting in 2022, all cars will be required to utilize a 4WD drive train system. Top teams have locked into a standard design in recent years, so the new drive train requirements serves as an opportunity for students to design systems from the ground up and shake up the design possibilities.
A continuously variable transmission (CVT)-
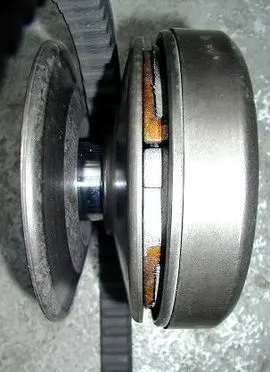
A continuously variable transmission (CVT) is an automatic transmission that can change seamlessly through a continuous range of gear ratios. This contrasts with other transmissions that provide a limited number of gear ratios in fixed steps. The flexibility of a CVT with suitable control may allow the engine to operate at a constant RPM while the vehicle moves at varying speeds.
CVTs are used in automobiles, tractors, motor scooters, snowmobiles, bicycles and earthmoving equipment.
The most common type of CVT uses two pulleys connected by a belt or chain; however, several other designs have also been used at times.
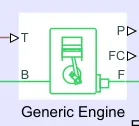
Represents a system-level model of spark-ignition and diesel engines suitable for use at initial stages of modeling when only the basic parameters are available. Optional idle speed and red line controllers are included.
The throttle input signal T lies between zero and one and specifies the torque demanded from the engine as a fraction of the maximum possible torque. If the engine speed falls below the Stall speed, the engine torque is blended to zero. If the engine speed exceeds the Maximum speed, the simulation stops and issues an error message.
Connections F and B are mechanical rotational conserving ports associated with the engine crankshaft and engine block, respectively. Connections P and FC are physical signal output ports through which engine power and fuel consumption rate are reported.
2)Variable gear ratio-
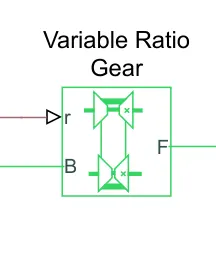
Represents a variable ratio gearbox such as implemented by mechanical belt CVT, electric, or hydraulic transmissions. The physical signal input r defines the ratio of input to output angular shaft velocities.
Connections B (base) and F (follower) are mechanical rotational conserving ports. Specify the relation between base and follower rotation directions with the Output shaft rotates parameter.
3)Vehicle Body
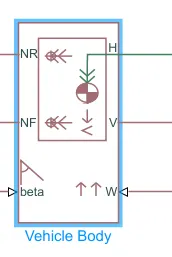
Represents a two-axle vehicle body in longitudinal motion. The block accounts for body mass, aerodynamic drag, road incline, and weight distribution between axles due to acceleration and road profile. The vehicle can have the same or a different number of wheels on each axle. Optionally include pitch and suspension dynamics or additional variable mass and inertia. The vehicle does not move vertically relative to the ground.
Connection H is the mechanical translational conserving port associated with the horizontal motion of the vehicle body. The resulting traction motion developed by tires should be connected to this port. Connections V, NF, and NR are physical signal output ports for vehicle velocity and front and rear normal wheel forces, respectively. Wheel forces are considered positive if acting downwards. Connections W and beta are physical signal input ports corresponding to headwind speed and road inclination angle, respectively. If variable mass is modeled, the physical signal input ports CG and M are exposed. CG accepts a two- element vector representing the x and y distance offsets from vehicle CG to additional load mass CG. M represents the additional mass. If both variable mass and pitch dynamics are included, the physical signal port J accepts the inertia of the additional mass about its own CG.
inputs-
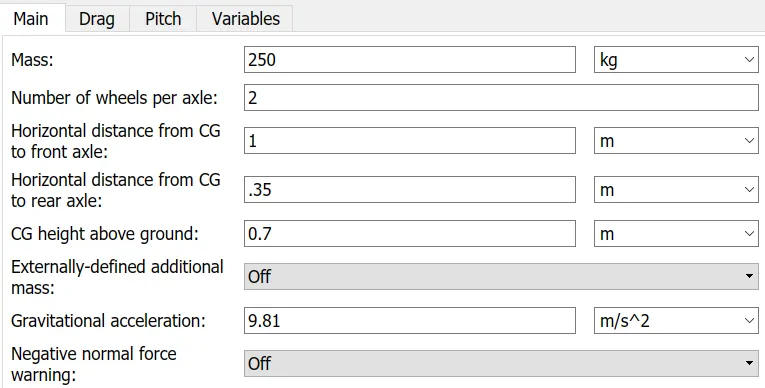
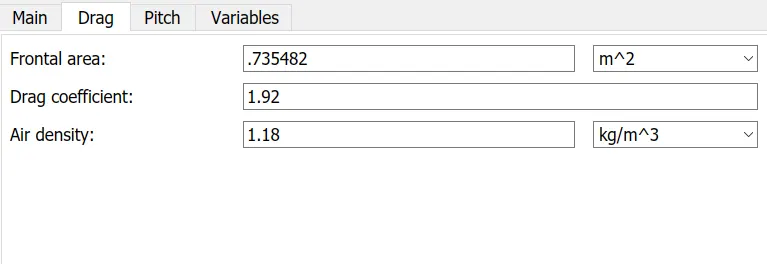
4)Simple Gear-
Represents a fixed-ratio gear or gear box. No inertia or compliance is modeled in this block. You can optionally include gear meshing and viscous bearing losses.
Connections B (base) and F (follower) are mechanical rotational conserving ports. Specify the relation between base and follower rotation directions with the Output shaft rotates parameter. Optionally include thermal effects and expose thermal conserving port H by setting Friction model to a temperature-dependent setting.
5)double show brake-
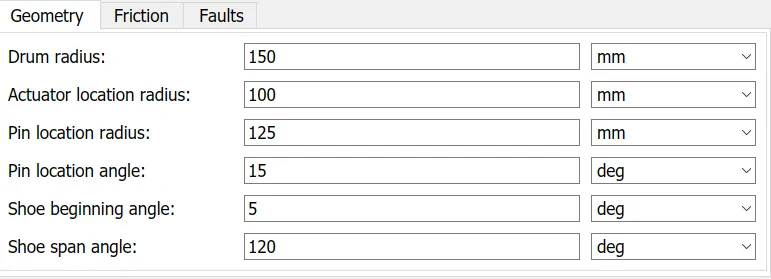
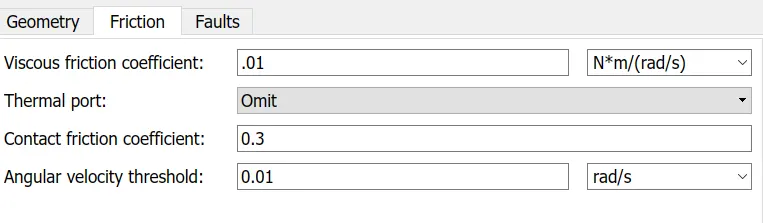
Represents a brake arranged as two pivoted rigid shoes symmetrically installed inside or outside a drum and operated by one actuator. The actuator force causes the shoes to exert a friction torque on a shaft connected to the drum.
Connection S is a conserving rotational terminal associated with the drum shaft. Connection F is a physical signal port representing the force input to the actuator. Positive force creates friction torque that resists shaft rotation. Optionally include thermal effects and expose thermal conserving port H by setting Thermal port to Model.
input
6)tire-
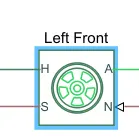
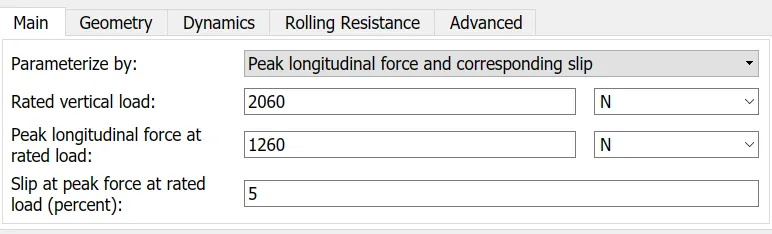
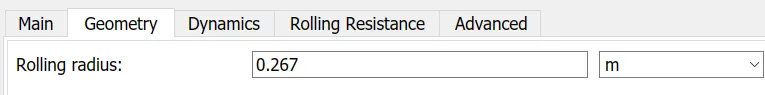
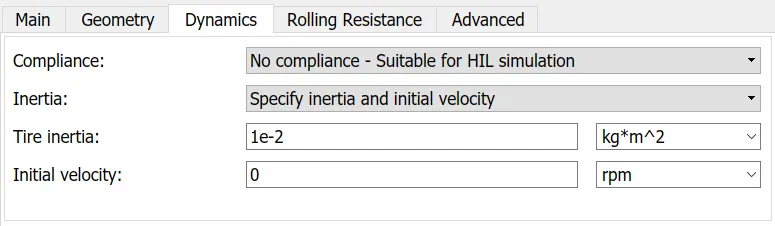
Represents the longitudinal behavior of a highway tire characterized by the tire Magic Formula. The block is built from Tire-Road Interaction (Magic Formula) and Simscape Foundation Library Wheel and Axle blocks. Optionally, the effects of tire inertia, stiffness, and damping can be included.
Connection A is the mechanical rotational conserving port for the wheel axle. Connection H is the mechanical translational conserving port for the wheel hub through which the thrust developed by the tire is applied to the vehicle. Connection N is a physical signal input port that applies the normal force acting on the tire. The force is considered positive if it acts downwards. Connection S is a physical signal output port that reports the tire slip. Optionally expose physical signal port M by setting Parameterize by to Physical signal Magic Formula coefficients. Physical signal port M accepts a four element vector corresponding to the B, C, D, and E Magic Formula coefficients.
inputs
signal builder-
input signal
BAJA ATV MODEL WITH OUT DASHBORD-
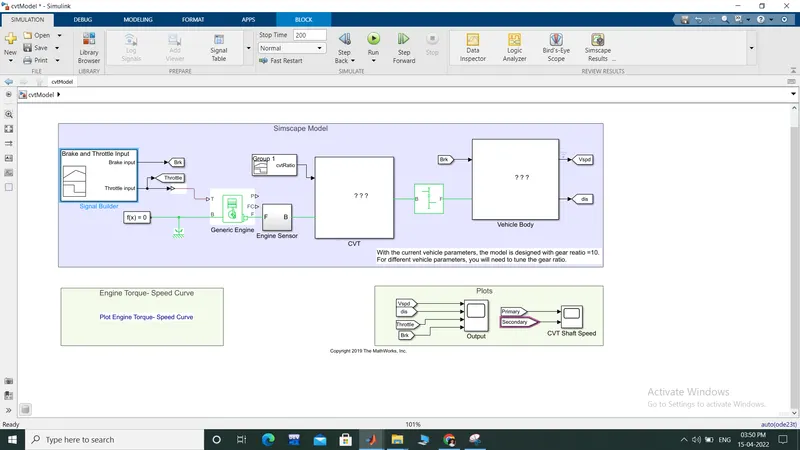
following are the steps to follow to start model working-
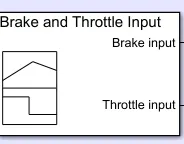
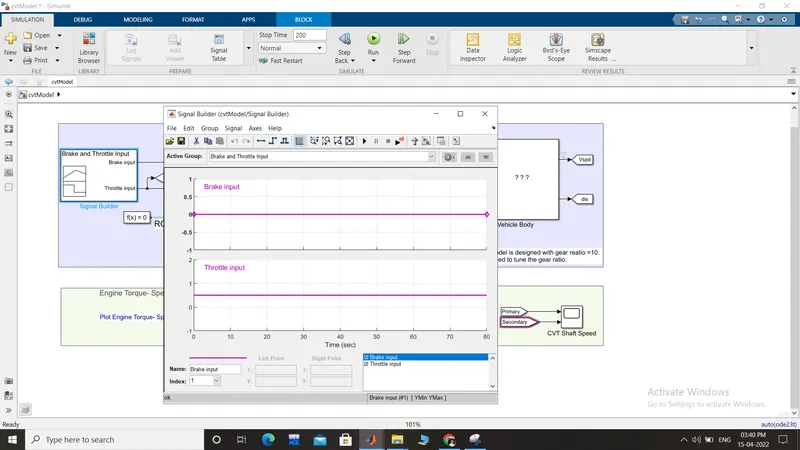
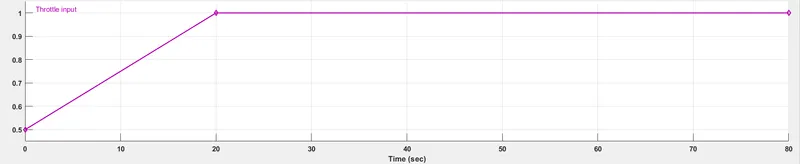
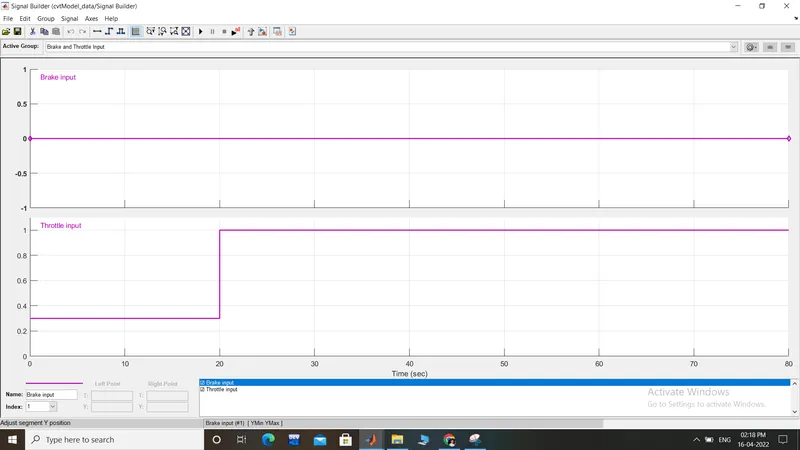
i.The throttle signal is generated by signal builder block and inputted to generic engine.
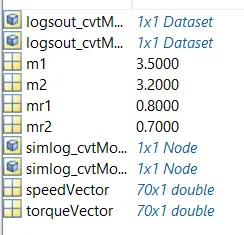
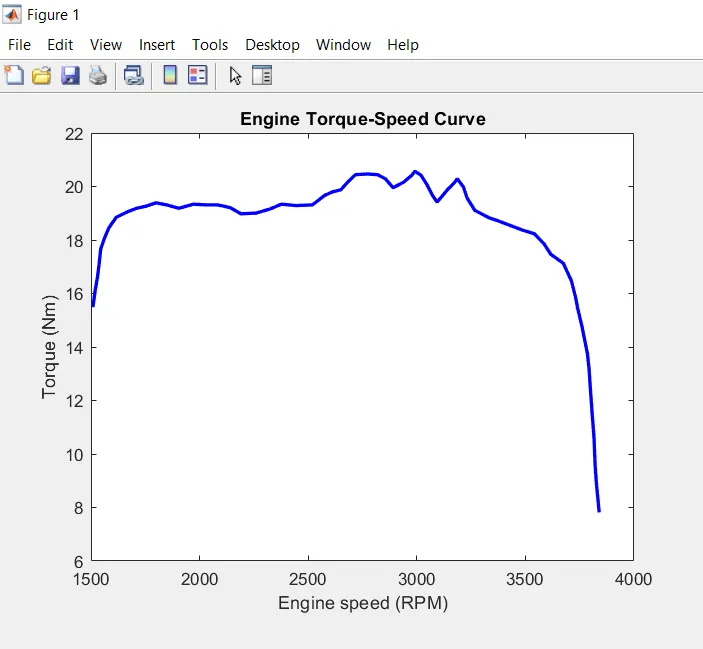
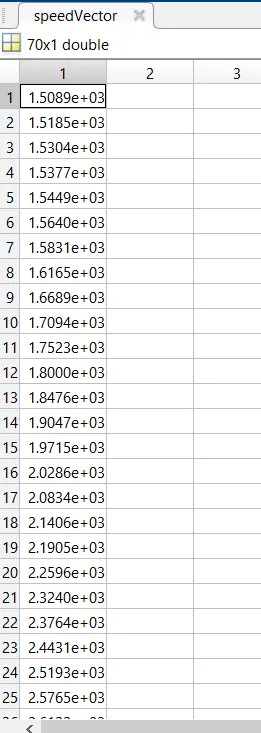
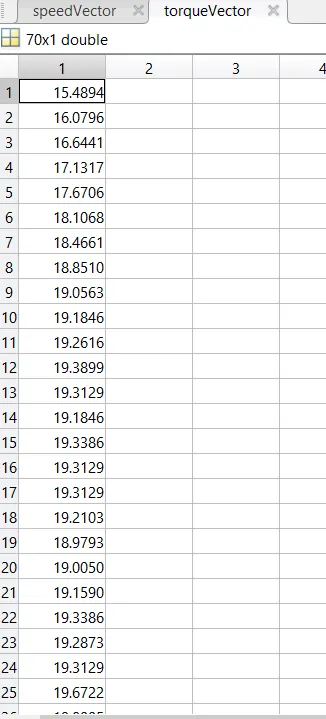
ii.The torque and speed vector are inputted from the matlab workspace
iii.The engine will generate the output rpm which can be taken from the crankshaft output. This speed will be given to
the Ideal Rotational Motion Sensor to sense the output rpm.
iv.The same output speed will be given to a simple gear mechanism to reduce the speed where the Gear Ratio is ‘4’.
v.Then the output speed from the gear reducer will be given to the Variable Ratio Transmission block (CVT).
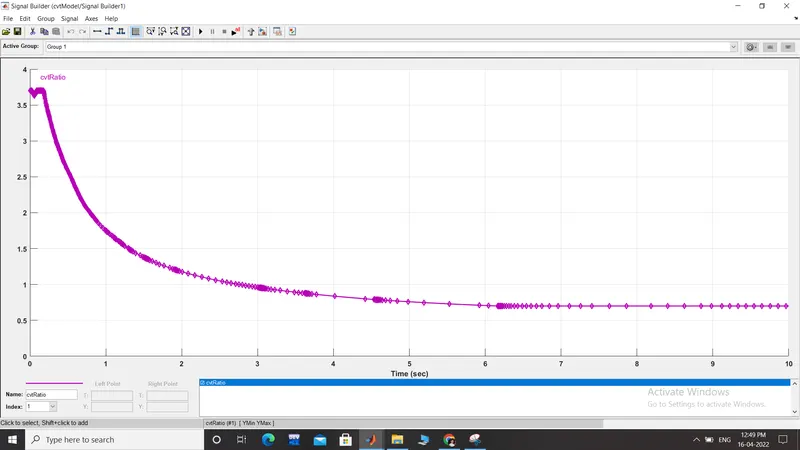
vi.The CVT ratio is provided to the Variable Ratio Transmission (CVT) block through Signal Builder.
vii. The speed is controlled by the variable CVT ratios and the controlled output speed is inputted to the vehicle axle.
viii.The brake signal is generated by the signal builder and inputted to the vehicle body (Double Shoe Brake) for
applying the brake to axle.
ix.The power from the CVT is inputted to the axle and the vehicle accelerates according to the speed.
x.Then the Velocity is taken as output from the vehicle body for further analysis.
INPUT SIGNALS-
throttle input-
Brake input signal-
matlab workspace-
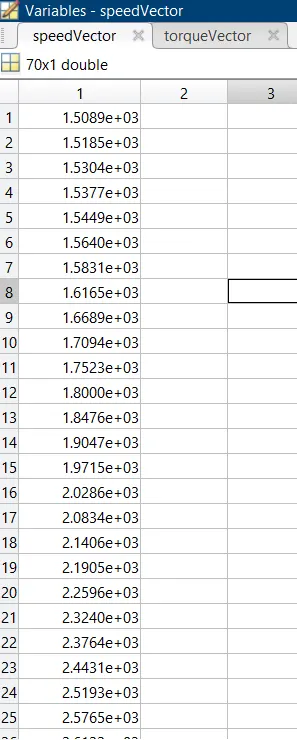
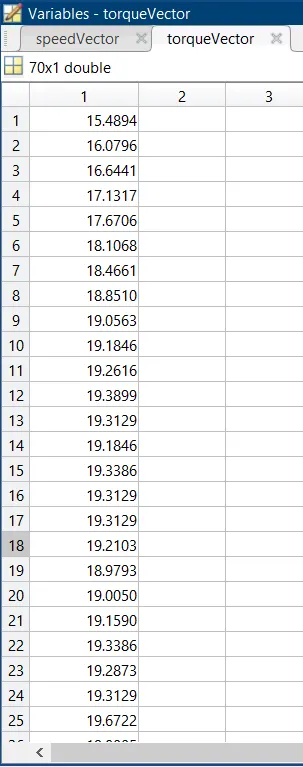
CVT ratio input-
it starts with 3.9 and goes down to 0.7. as shown below.
Engine sensor subblock-
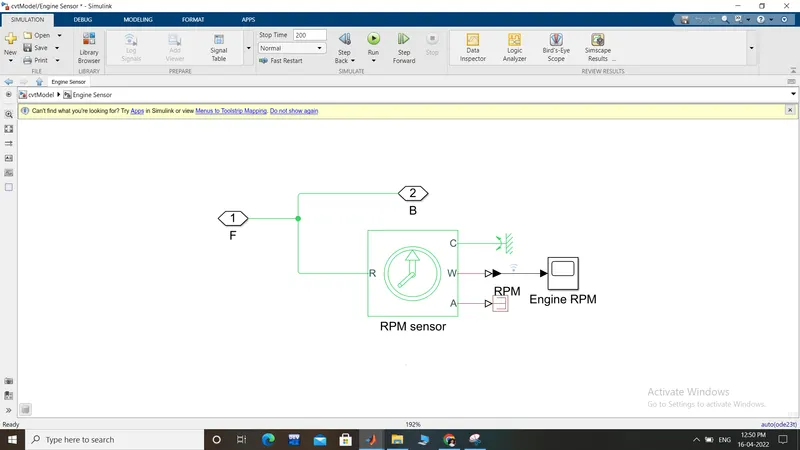
the engine sensor measures the rotational speed of the engine nad also measure the input and output rpm of the engine.
CVT subblock-
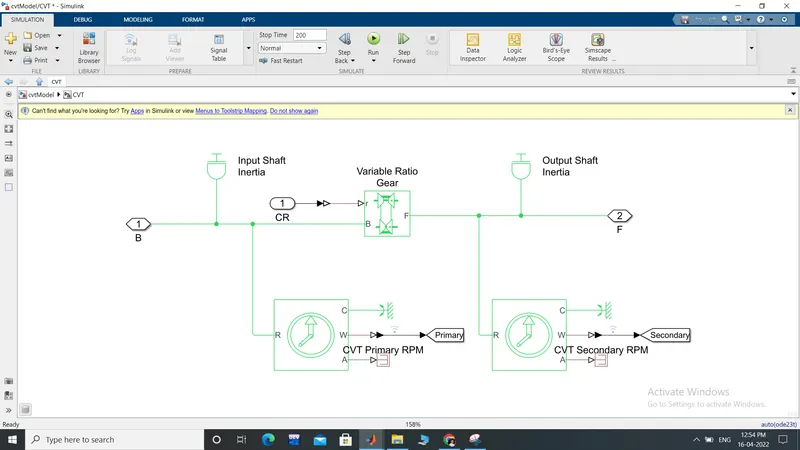
the cvt block provides the input and output inertia and torque in provided gear ratio.
VEHICLE BODY-
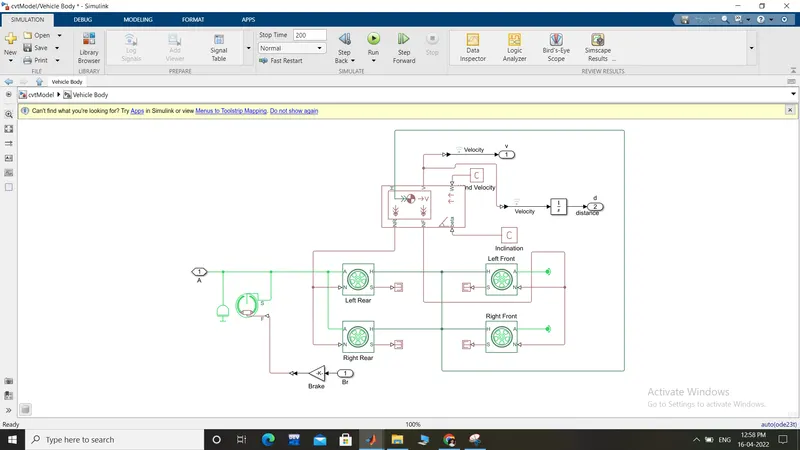
THE VEHICLE REPRESENTED ABOVE HAVING four wheel and have input to rear wheel and this are main wheels to move the vehicle,an inertia is added to simulate axle inertia, then the shoe brakes conserving port is connected to the all axle, and then the same axle connects the two rear tyres while the front tyres is free to rotate on a rotational free . All the tyres H hub port is connected together and then connected to the vehicle H port, Also the rear tyres N port is connected together and then connected to the vehicle body Nr output ports, while the front are connected to the Nf vehicle body output ports, the vehicle body takes the road inclination and wind velocity from physical constants.
Results-
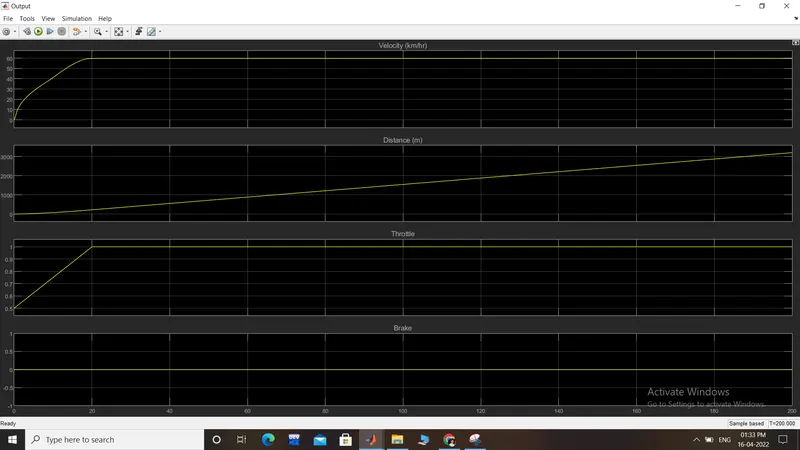
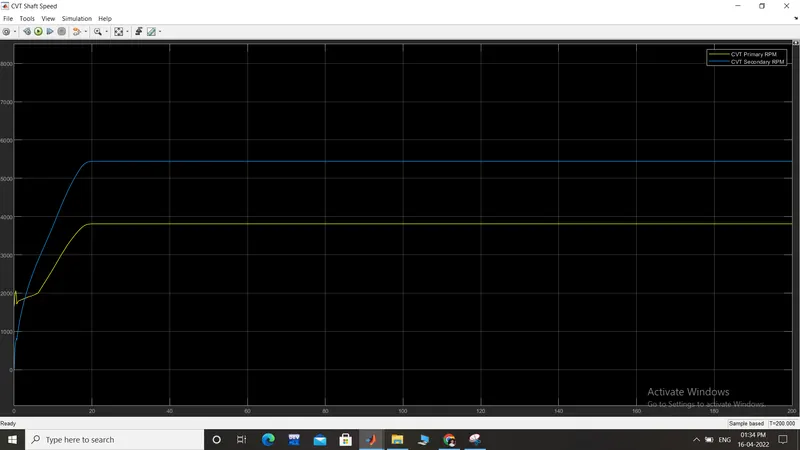
BAJA ATV (ctvModel_data)-
input data
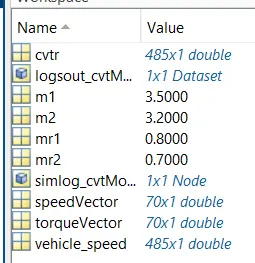
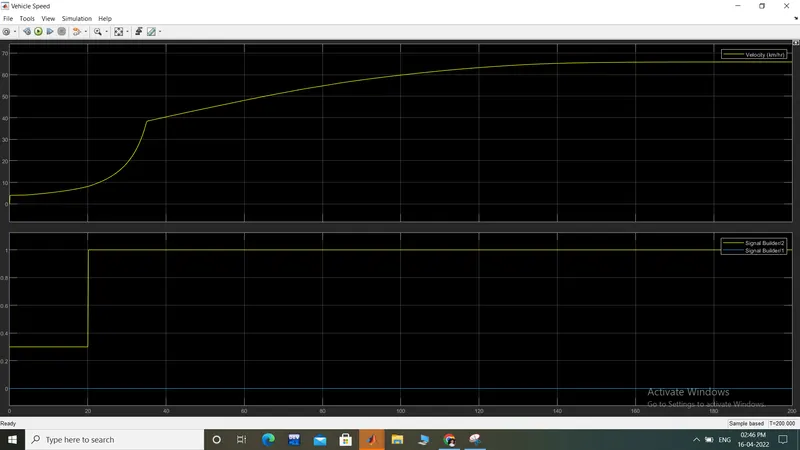
this is A same model as baja atv dashbord but in this model have added CVT ratio and vehicle speed data to extract data using work space.
BAJA MODEL WITH DASHBORD-
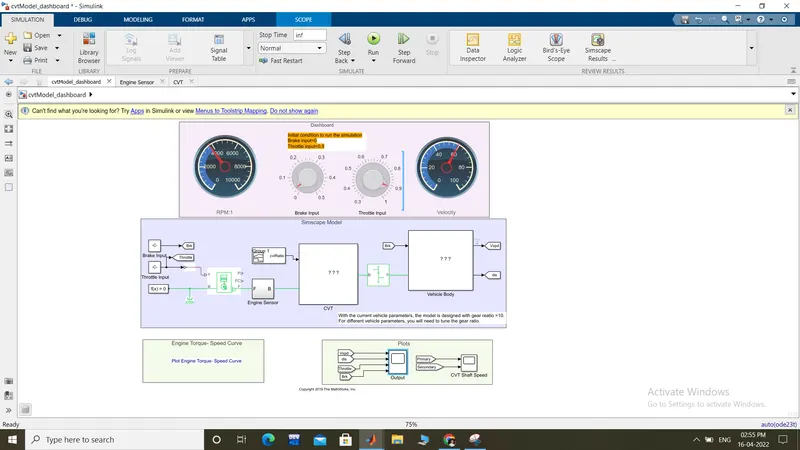
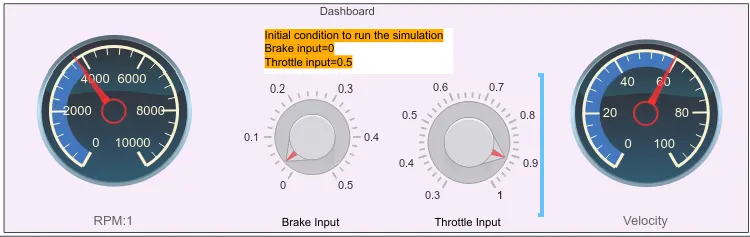
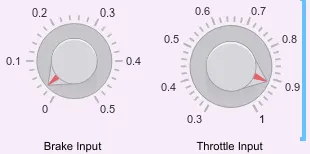
THIS NOOB are used to control the throttleand brake input to the systems.
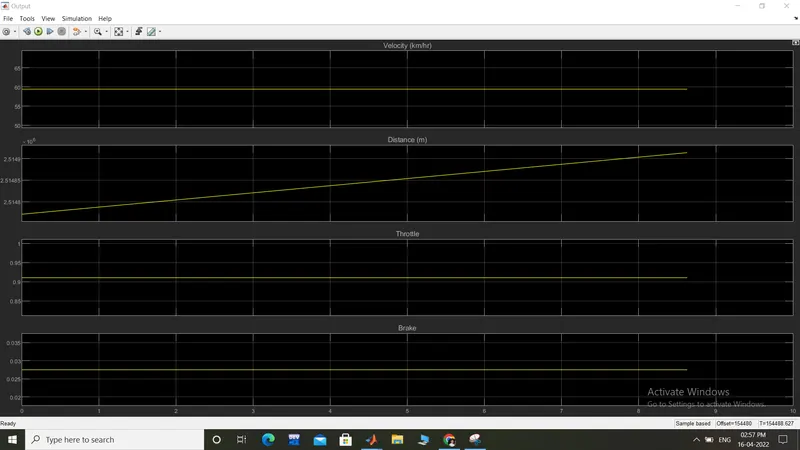
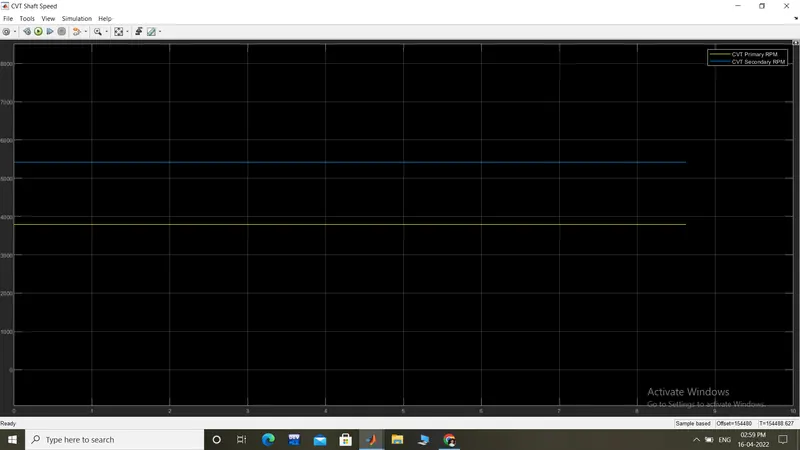
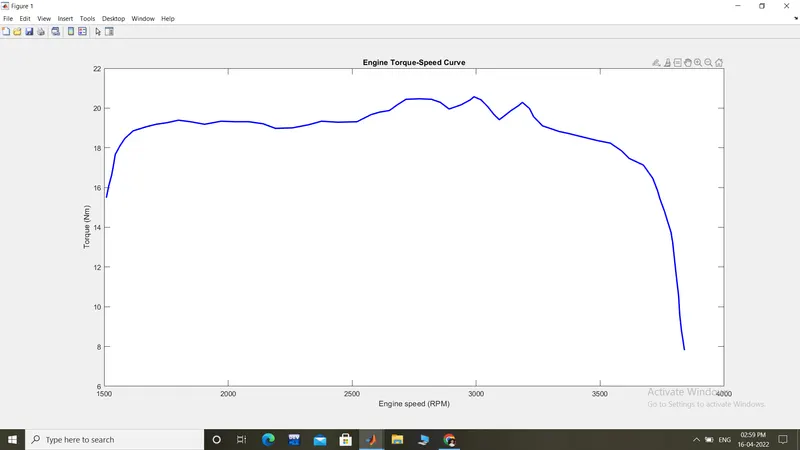
above pictures are the results of the cvt model with dash board system.
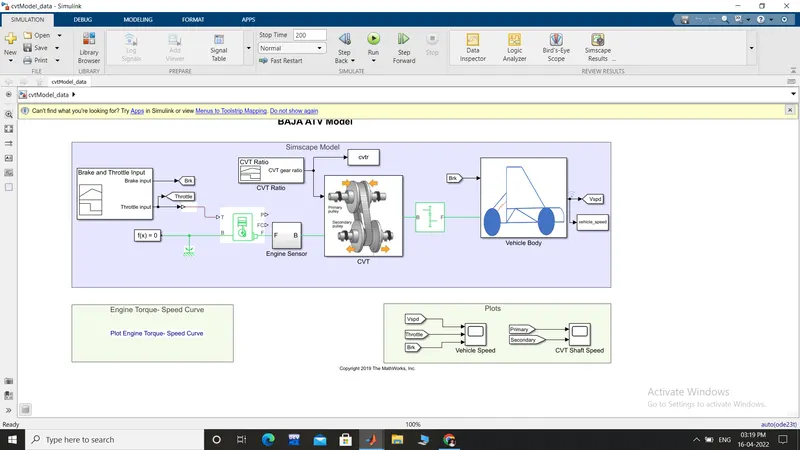
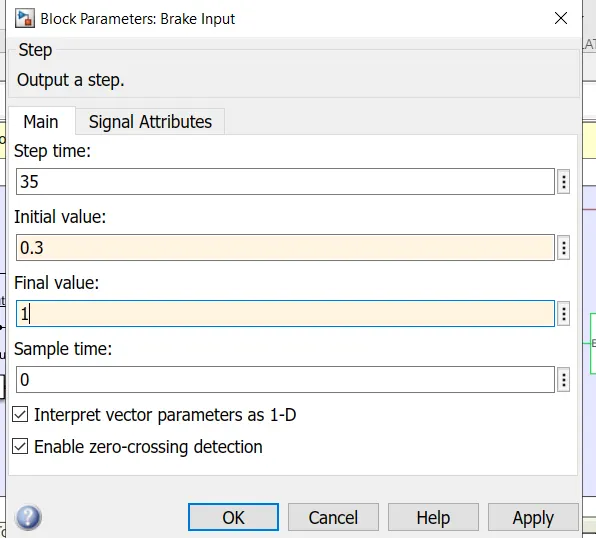
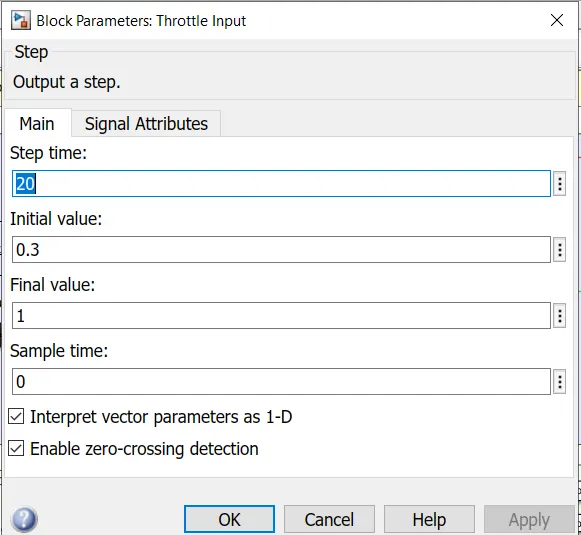
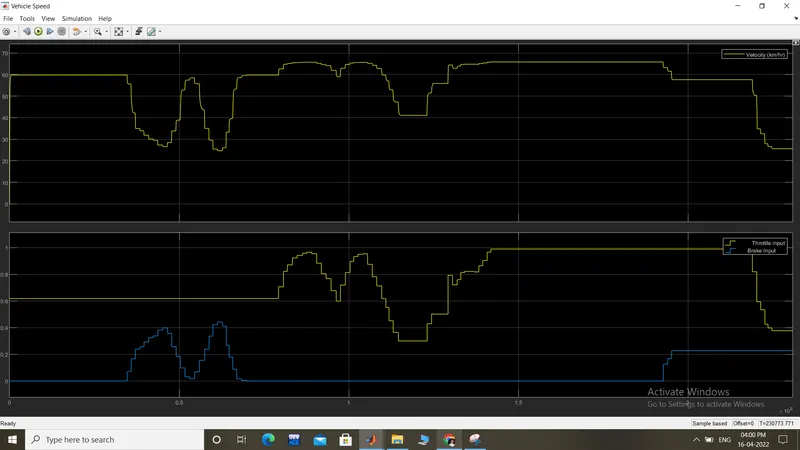
The model workflow process is same as the process of 'BAJA ATV model without Dashboard' except that it used instead of Signal Builder Blocks for Brake and Throttle Input Step input blocks are used. At 35 sec the brake input will take a step of value 'O' and at 20 sec throttle input will increases from 0.3-1 then remains constant throughout.
CVT SUBBLOCK-
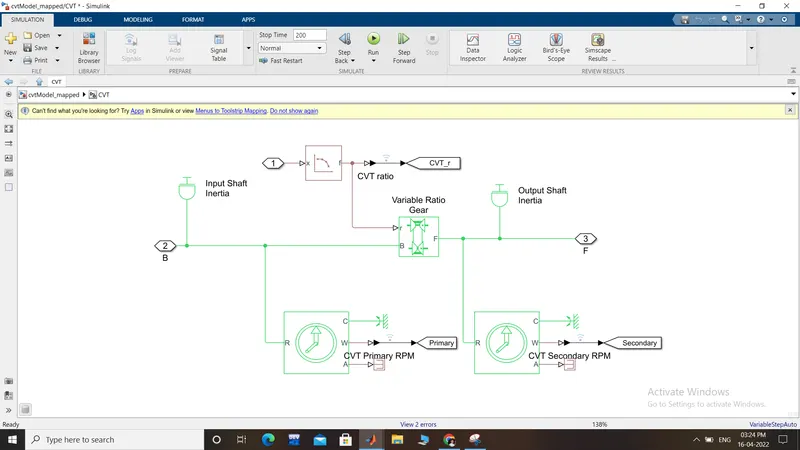
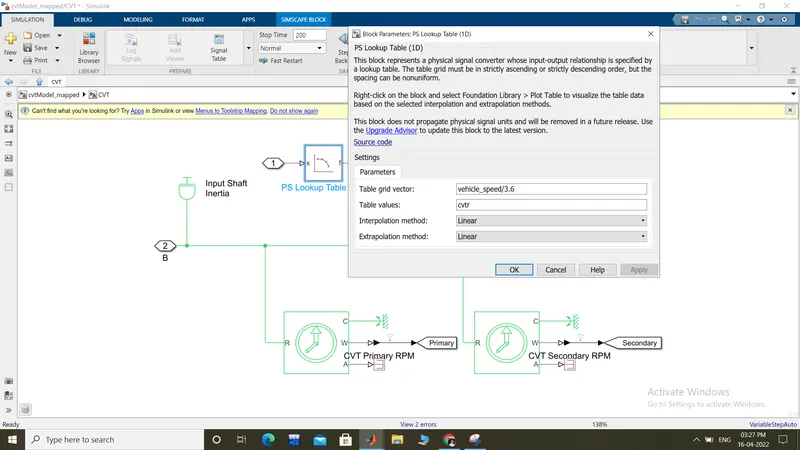
The cvt subblock is the same as the previous model "BAJA ATV model without Dashboard" but instead of Signal Builder Block for CVT Ratio the 2-D Lookup Table is used. The interpolations and extrapolation methods are set to linear. It needs to be loaded in the workspace having the file name as Lookuptable_data.mat Lookup Table: A lookup table is an array of data that maps input values to output values, thereby approximating a mathematical function. Given a set of input values, a lookup operation retrieves the corresponding output values from the table. If the lookup table does not explicitly define the input values, Simulink can estimate an output value using interpolation, extrapolation, or rounding, where: - Interpolation is a process for estimating values that lie between known data points. - Extrapolation is a process for estimating values that lie beyond the range of known data points. - Rounding is a process for approximating a value by altering its digits according to a known rule. A lookup table block uses an array of data to map input values to output values, approximating a mathematical function. Given input values, Simulink performs a "lookup" operation to retrieve the corresponding output values from the table. If the lookup table does not define the input values, the block estimates the output values based on nearby table values. At last the vehicle speed output is given as a feedback to the 2-D Lookup Table so that we can verify that the velocity of the vehicle is changing perfectly when the CVT Ratio changes. The vehicle speed is converted to m/s from Kmph.
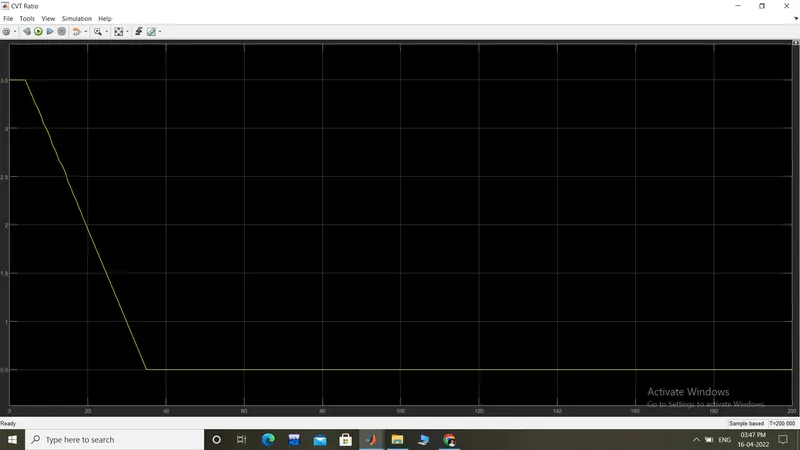
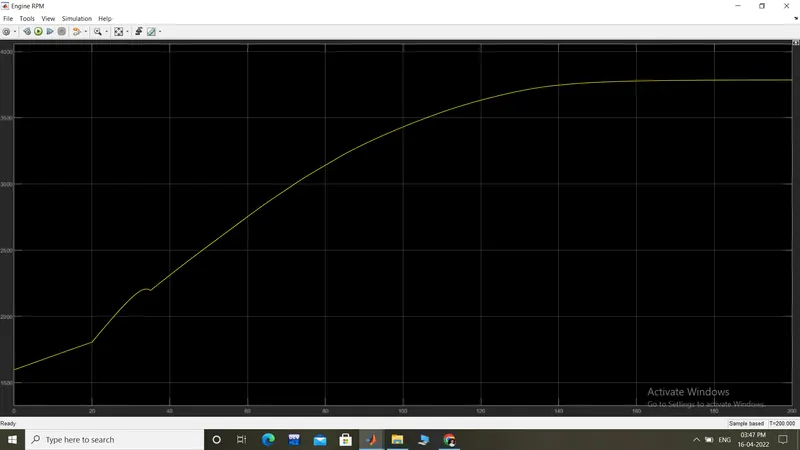
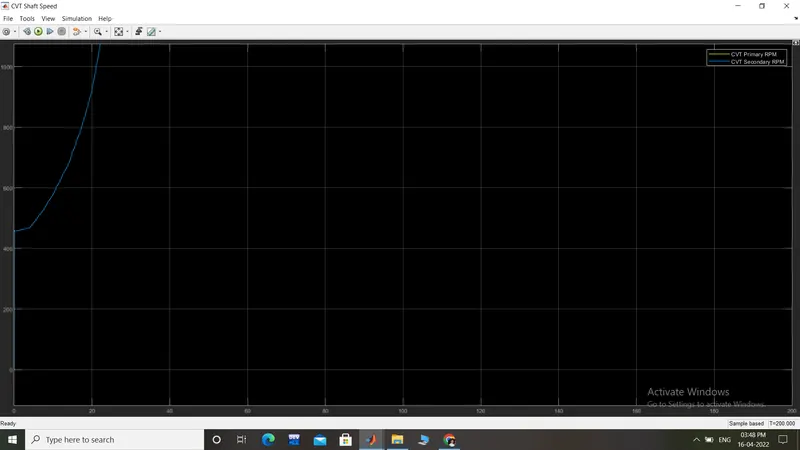
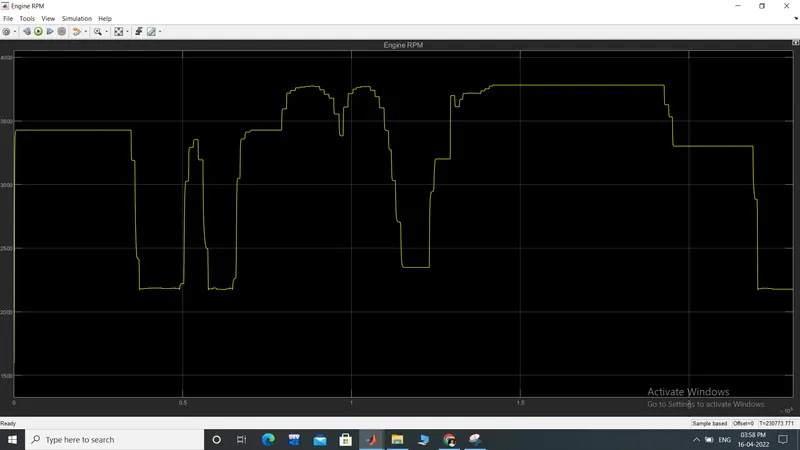
engine speed
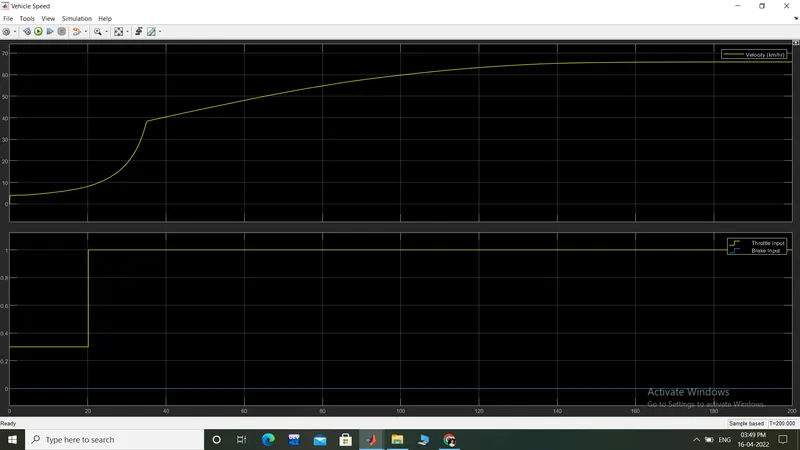
BAJA ATV MAPPED WITH DASHBOARD-
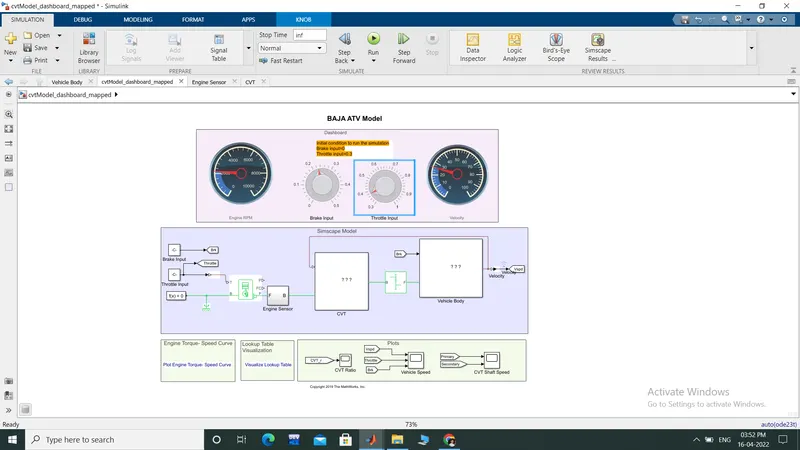
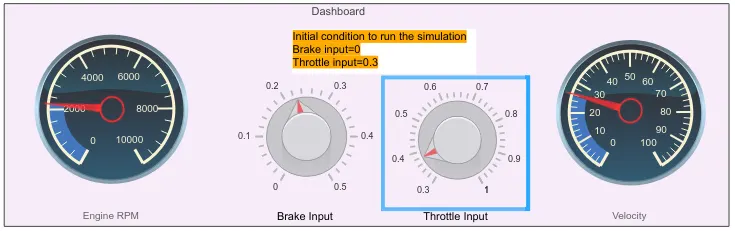
The model workflow process is same as the process of 'BAJA ATV model-mapped lookup table without Dashboard' but the Throttle and Brake inputs are controlled by the user with the Knob followed by the vehicle speed is given as feedback to the CVT Ratio lookup table.
CVT RATIO-
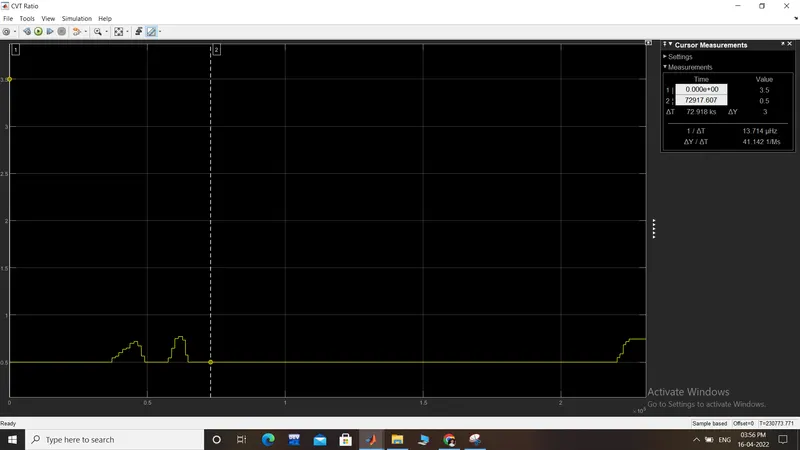
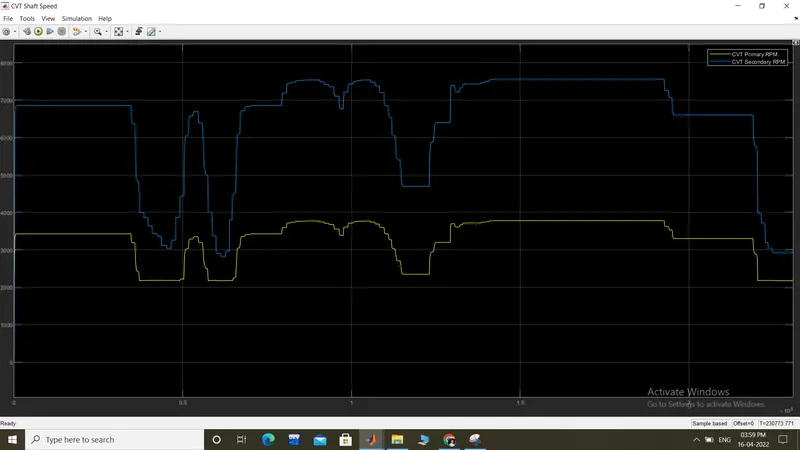
In this BAJA ATV Model, the Engine is pre-set to run at 3300 rpm with the throttle value of 0.3'. And the velocity at 45 KMPH. The CVT Ratio for minimum and maximum speed of the engine was pre-defined as 2.3 and 1.8 respectively. When the simulation is started the initial throttle value 0.3 is achieved so that the CVT Ratio is nearby to 1.85. When the throttle is being increased the CVT Ratio move towards 1.8 where the state is maximum engine speed. Simultaneously when the throttle is being decreased the CVT ratio will move towards 1.85. While the braking is applied the CVT Ratio increases so that it can achieve the nearest state of 2.3 Minimum Engine Speed). When braking is reduced the CVT Ratio move towards 1.85 which is the basic throttle input 0.3 or if any other throttle value is applied it would reach that CVT Ratio state.
ENGINE SPEED-
CVT RATIO-
VEHICLE SPEED-
REFARANCE-
MATLAB HELP