Project
System-level simulation of an All-Terrain Vehicle
AIM:
To study the system level simulation of an all terrian vehicle
OBJECTIVES:
1-Study the BAJA ATV model without dashboard
2-Study the BAJA ATV model with dashboard
3-Study the BAJA ATV model with CVT ratio in m script
4-Study BAJA ATV model with lookup table
5-Study BAJA ATV model with lookup table with dashboard
THEORY:
ALL TERRAIN VEHICLE:
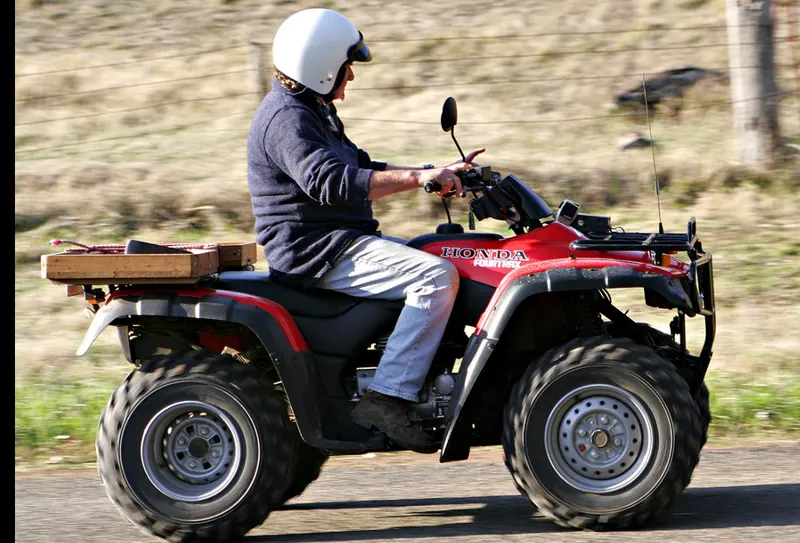
An all terrain vehicle(ATV),also known as a quad bike or simply aquad.It is a vehicle that travels on low pressure tires,with a seat that is straddled by the operator along with handlebars for steering control.ATVs are intended for use by a single operator,although some companies have developed ATVs intended for use by the operator and one passanger
CVT(CONTINUOUSLY VARIABLE TRANSMISSION):
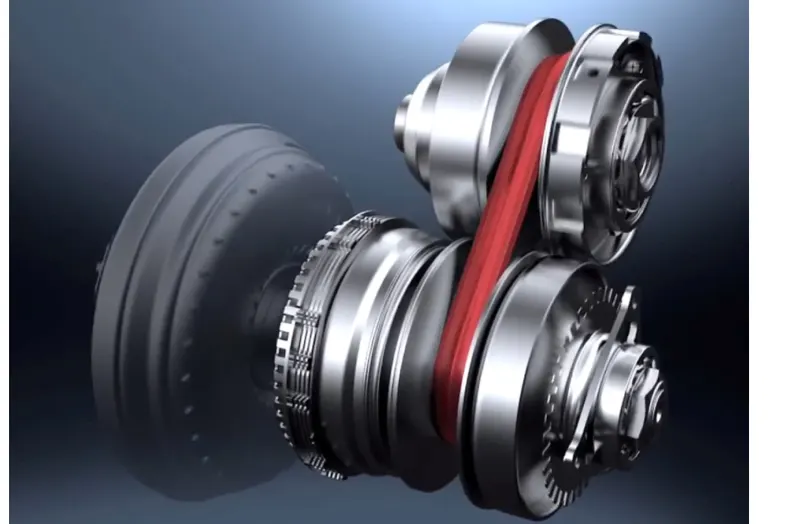
A continuously variable transmission is an automatic transmission and it is atype of single speed automatic gearbox.that can change seamlessly through a continous range of gear ratios.when compared to other other transmission that provide a limited number of gear ratio in fixed steps.The flexiblity of a CVT with suitable control may allow the engine to operate at aconstant RPM while the vehicle moves at varying speeds
BAJA SAE ATV:
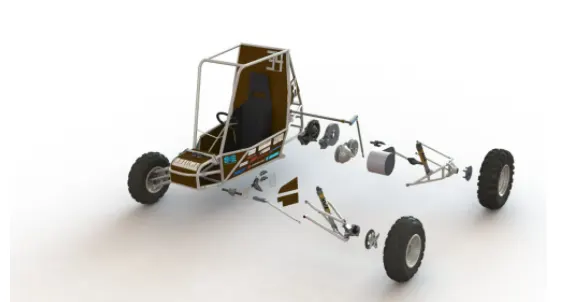
BAJA SAE is an intercollegiate engineering design competition for undergraguate and graduate engineering students.The object of the competion is to simulate real world enginnering design project and their related challanges.These vehicles need to go through 2 types of events ,static events and dyanmic events
STATIC EVENTS:
Technical inspection
Cost event
Design judging
Sales presentation
DYANMIC EVENTS:
Accleration
Hill climb or traction event and maneuverablity
Special events
Endurance race
MAJOR COMPONENTS USED:
GENERIC ENGINE BLOCK:
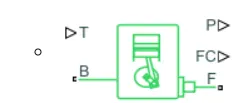
The generic engine bock reprents a general internal combustion engine .engine types include spark ignition and diesel.Speed -power and speed-torque parameterizations are provided .A throttle physical signal input specifies the normalized engine torque.Optional dyanmic parameter includes cranshaft inertia and response time lag .A phyiscal signal port output engine fuel conumption rate based on choice of fuel consumotion model.Optional speed and redline controllers prevent engine stall and enable cruise control
BLOCK PORTS
B-roatational conserving port representing the engine block
F-rotational conserving port representing the engine crankshaft
T-physical signal input port specifies the normal engine throttle level
P-physical signal output port reporting the instantaneous engine power ,in W
FC-Physical signal output port reporting the fuel consumption rate in kg/s
VARIABLE RATIO TRANSMISSION BLOCK:
The variable ratio transmission block represents a gearbox that dynamically transfers motion and torque between the connected drivershaft axes,base and follwer .variable ratio transmission is a dynamical mechanosm for transferring motion and torque between base and follwer.if the relative compliance between axes is absent the block is equivalent to a gear with variable ratio
Such a gear imposes a time -dependent kinematic constraint on the motion of two driveshafts
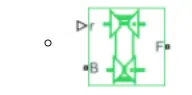
BLOCK PORTS:
B anD F are rotational conserving ports reprenting respectively the base and follwer drivershaft.
variable gear ratio gfb(t) can be specified as a function of time at the physical signal input at portr.if the signal value becomes zero or negative the simulation stopes with an error
SIMPLE GEAR:
The simple gear block reprents a gearbox that constrains the connected driveline axes of the base gear,B, and the follwer gear,F,to corotate with a fixed ratio that you specifiy.You choose whether the folloeing axis roatates in the same or oppsite direction as the base axis .if they roatate in same direction, and angular velocity of the base
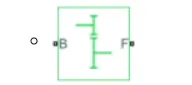
BLOCK PARTS:
B indicates base
F Indicates follwer
VEHICLE BODY:
The vehicle body block represents a two-axle vehicle body in longitudinal motion.The vehicle can have the same or a different numbers of wheels of each axle.For example,two wheels on the front axle and one wheel on the rear axle.The vehicle wheels are assumed identicak in size.The vehicle can also have a center of gravity(CG)that is at below the plane of travel
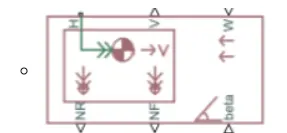
BLOCK PORTS:
INPUTS:
W-Headwind speed,m/s
beta-road incline angle ,rad
CG-center of gravity,m
M-Mass,kg
J-External moment of inertia,kg*m^2
OUTPUT:
V-Longitudnal velocity,m/s
NF-Front axle normal force,N
NR-Rear axle normal force,N
CONSERVING:
H-Horizontal motion
TIRE:
The tire block model a tire with lomgitudinal behavior given by the magic formula ,an emprical equation based on four fitting coefficients.The block can model tire dynamics under constant or variable pavement conditions
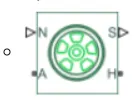
BLOCK PORTS :
INPUTS :
N-NORMAL FORCE
M- MAGIC FORMULA COFFICIENTS
OUTPUTS
S-SLIP
CONSERVING
A-AXLE
H-HUB
DOUBLE-SHOE BRAKE:
The double -shoe brake block reprents a frictional brake with two pivoted rigid shoes that press aganist a roataing drum to produce a braking action the rigid shoes sit inside or outside the rotating drum in adiametrically opposed configuration a positive actuating force causes tge rigid shoes to press aganist the roatating drum to decelerate
PORTS
F-ACTUATING FORCE
S-DRUM SHAFT ROTATION
H-HEAT FLOW
TYPES OF MODELS
1-CVT model
2-CVT model dashboard
3-CVT model data
4-CVT model mapped
5-CVT model mapped dashboard
1-MODEL:CVT MODEL MODELS AND SUBSYSTEMS
MAIN MODEL
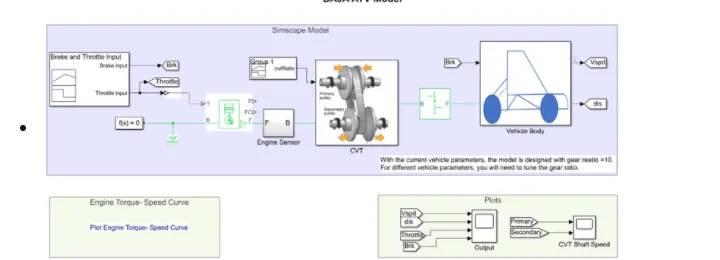
BAJA ATV MODEL
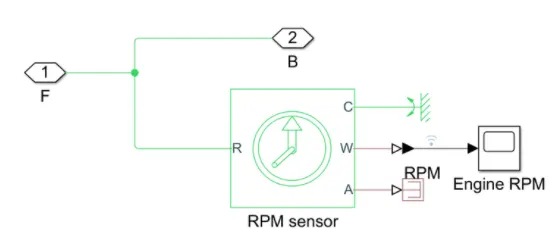
ENGINE SENSOR
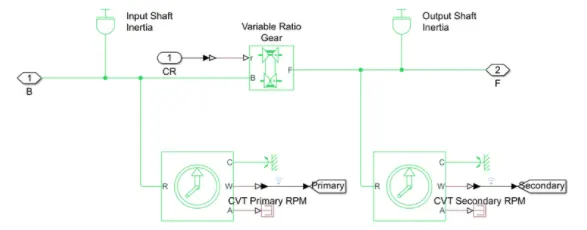
CVT SUBSYSTEMS
VEHICLE BODY SUBSYSTEMS
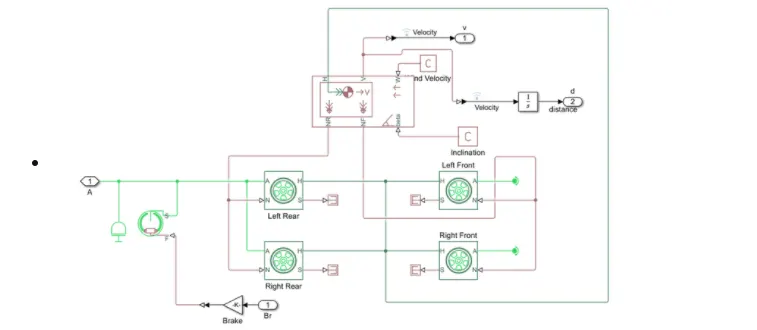
FLOW PROCESS:
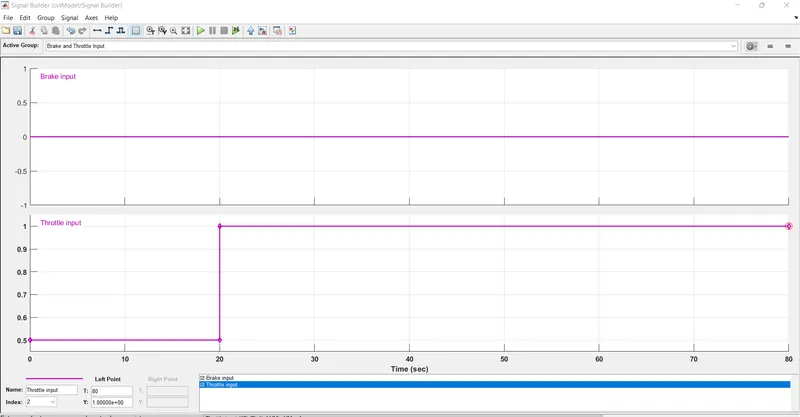
1-The initial input of the system are throttle input and brake input.These inputs are given by using signal bulider and only throttle signal is given as input to generic engine block.
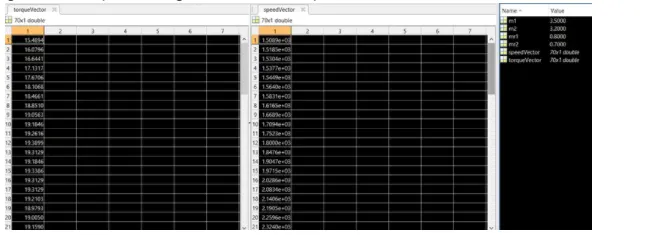
2-For the generic engine block the parametr are given by using tabulated torque data,the speed vector and torque vector are given as input using matlab workspace
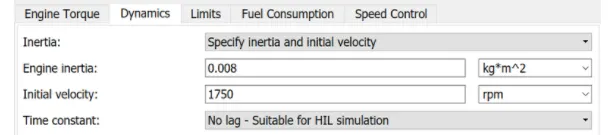
3-The initial RPM of the engine block is given as 1750RPM so the initial throttle should be 0.5 to initial the simulation
4-The output form the engine block which is required is RPM of crank shaft,this is connected to engine sensor subsystem which consists of ideal rotational motion sensor this sensor helps to plot engine RPM.This RPM is given as input to CVT subsystems.
5-In this model CVT ratio varies with time .so a signal bulider is used to give the input to block.
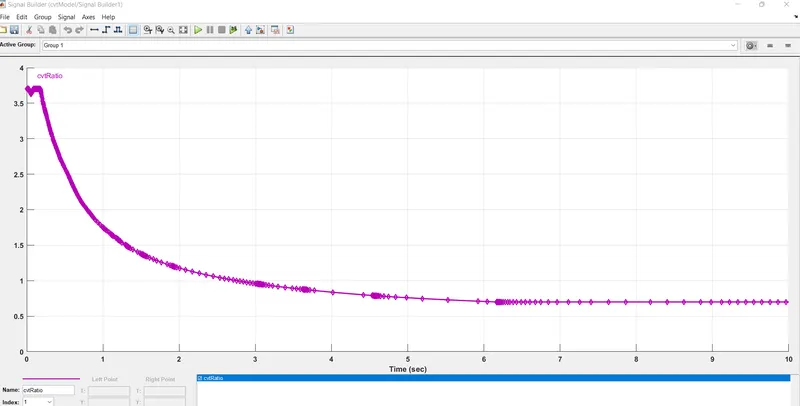
6-Two rotational sensors are used to log the RPM data of both primary and secondary pulleys
7-The output of the secondary pulleys is given to a simple gear which has fixed gear ratio the output form this block is given s input RPM to the tire block in vehicle body subsystems.
8-In the vehicle body subsystems vehicle parameters are given using vehicle body block .the output form this block are normal forces both front and rear,velocity of vehicle.
9-In the main model space these values are plotted using scopes and goto from blocks
OUTPUTS PLOTS:
ENGINE TORQUE VS RPM CURVE:
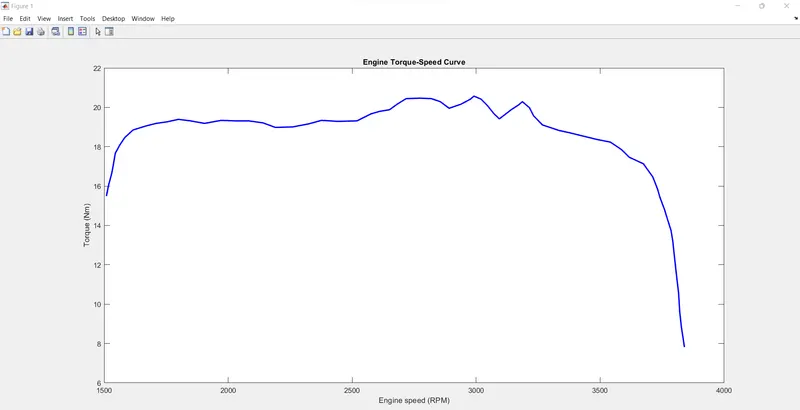
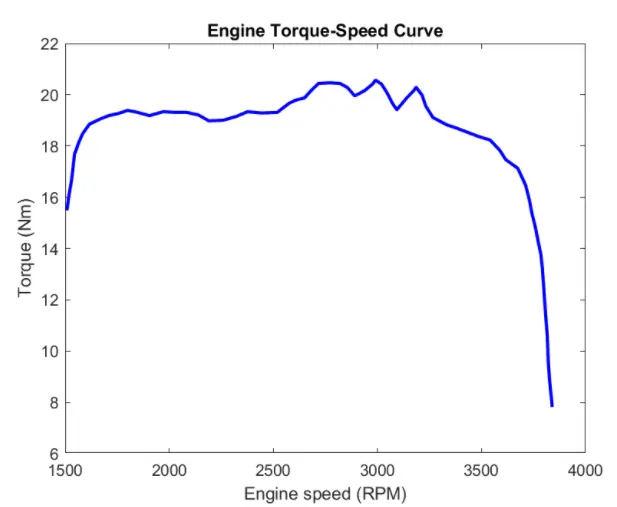
Plot shows the input parameters which are given to generic engine block as torque vector and speed vector
VELOCITY DISTANCE THROTTLE AND BRAKE VS TIME
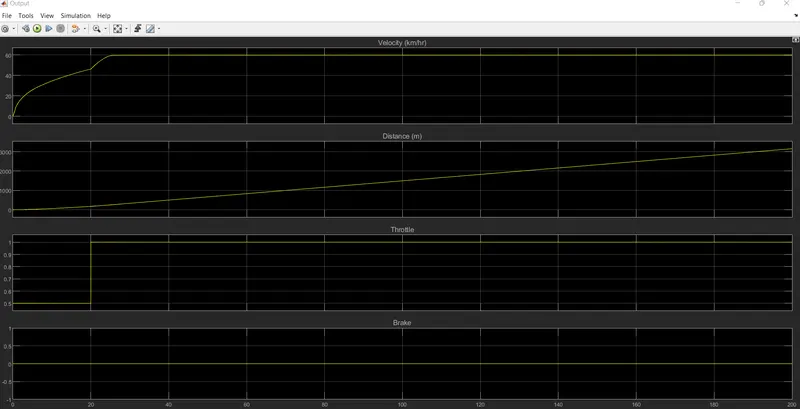
Plot shows variation in velocity with respect to time after a certain time plot is a straight line which is true because the gear ratio is constant after sometime and the throttle is maintain at 0.5 sec the distance covered is increasing with respect to time as the vehicle where did not stop.the cinversiin of velocity is done in PS -simulink converter
CVT PRIMARY AND SECONDARY RPM VS TIME
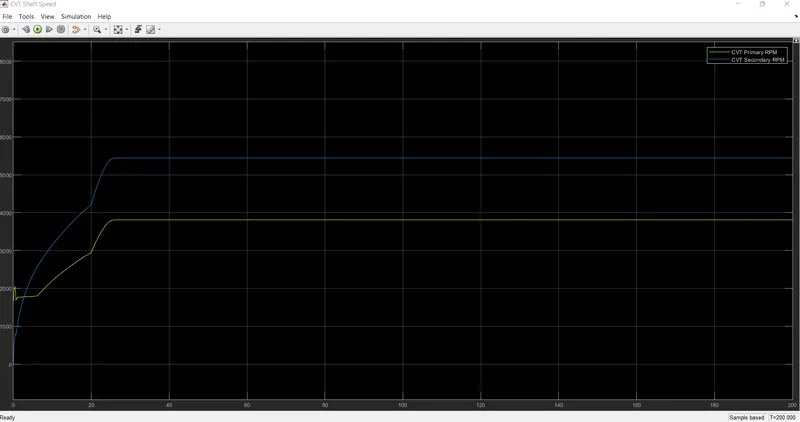
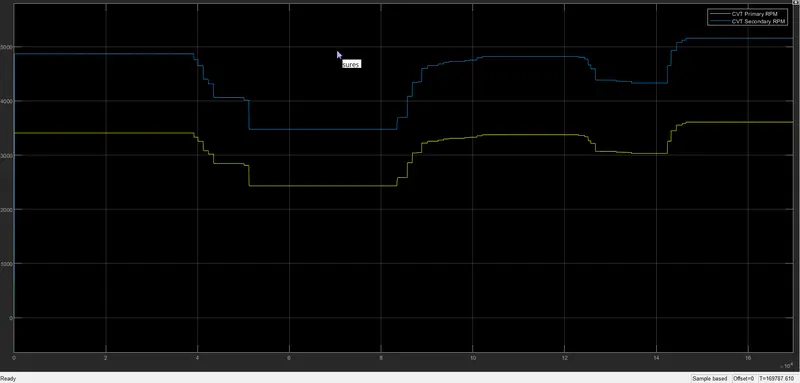
As the CVT gear ratio is decresing from a high value to a low valur in the initial time of simulation the RPM ,gear ratio is greater than 1 so RPM of secondary is less than primary and as the simulation is carried out for a longer time the secondary pulley RPM is more than primary which indicates the gear ratio in CVT is less than 1.
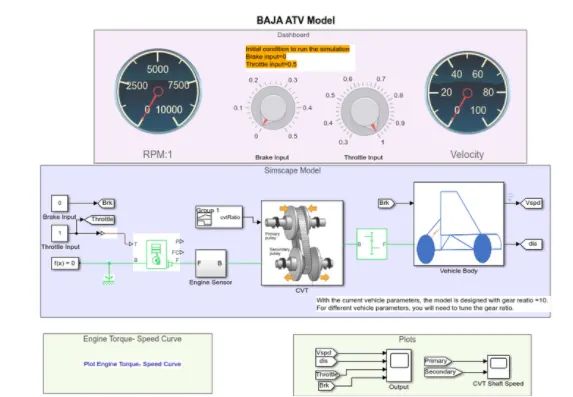
2- MODEL :CVT MODEL WITH DASHBOARD
MODELS AND SUBSYSTEMS
MAIN MODEL:
SUB SYSTEMS:
All the subsystems are same #1 model :CVT model
FLOW PROCESS:
.The flow process is same as#1 Model:CVT model. But the throttle input and brake input are given using user controlled knobs
OUTPUT PLOTS:
ENGINE TORQUE VS RPM CURVE:
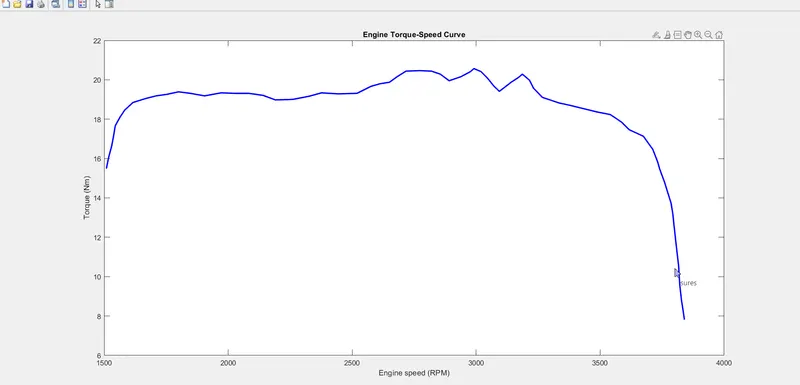
This plot shows the input parameter which are given to the generic Engine Block as Torque Vector and speed Vector
VELOCITY,DISTANCE,THROTTLE AND BRAKE VS TIME
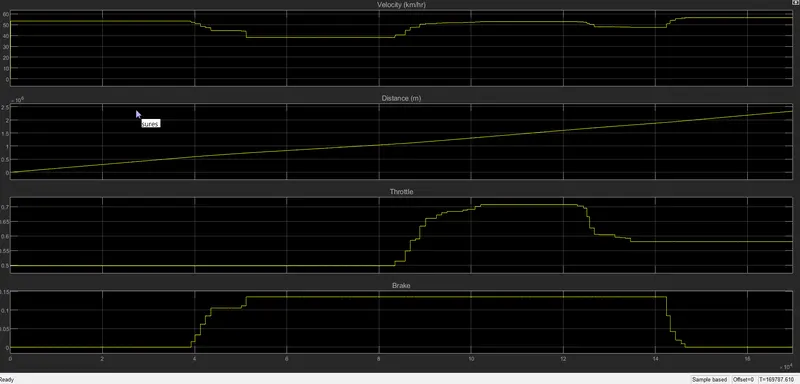
This plot shows variation in velocity with respect to time.As the throttle and brake input are user defined by using knobs there are steps created
CVT PRIMARY AND SECONDARY RPM VS TIME
3- MODEL CVT MODEL DATA
MODELS AND SUBSYSTEMS
MAIN MODEL:
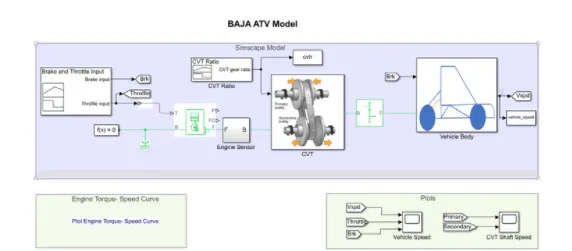
SUBSYSTEMS:All the subsystems are same as #1 MODEL:CVT model
FLOW PROCESS
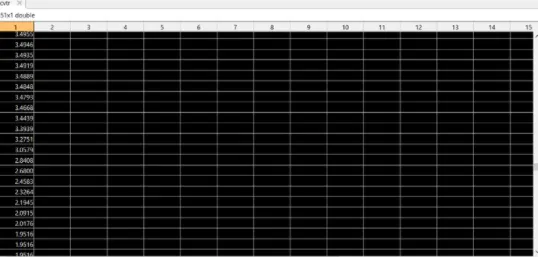
The flow process is also similar to that of#1 MODEL:CVT model .But there is an extra block added called to workspace which is connected to the CVT gear ratio.This block is used to send the CVT ratio to the matlab workspace and can be used for further analysis
OUTPUT:
The output plot ara same as #1 Model:CVT model
CVTR in matlab workspace
4-MODEL CVT MODEL MAPPED
MODEL AND SUBSYSTEMS:
MODEL:
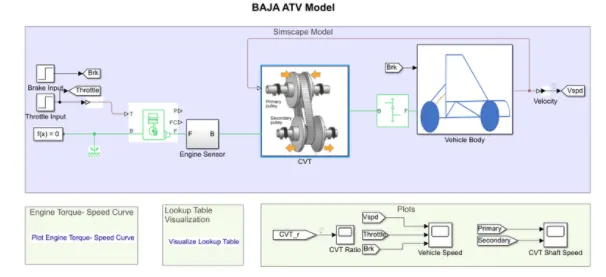
SUBSYSTEMS:All the subsustems are same as#1 Model:CVT model
FLOW PROCESS:
1-The flow process is similar to that of'#1 Model:CVT model'
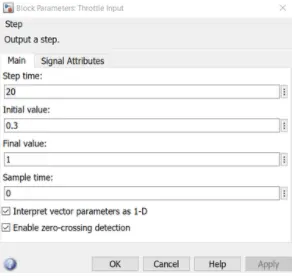
2-Instead of a signal bulider for brake and throttle input,in this model step block is used.Throttle input initial value is 0.3 and final value is 1 at 20 sec.Brake input is 0 through out the simulation.
THROTTLE INPUT
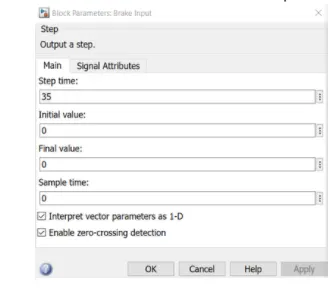
BRAKE INPUT
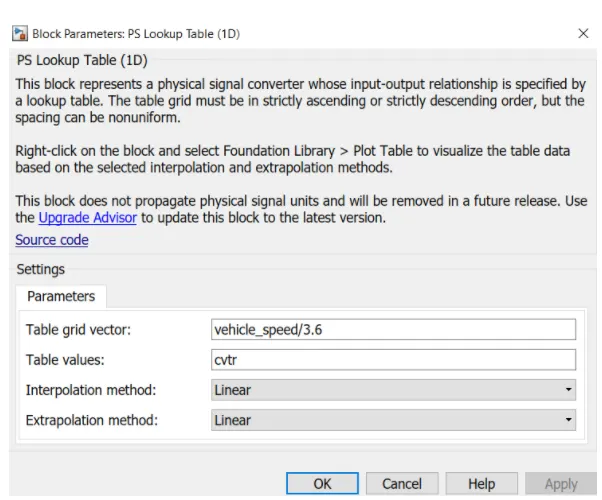
3-And instead of a signal bulider for CVT gear ratio,a lookup tabel is used which uses the vehicle speed is used as a feedback signal for lookup table. The data table is given using matlab workspace .vehicle speed is diveded by 3.6 to convert kph to m/s
4-Remaning flow process is same as the #1 Model:CVT model
1-ENGINE TORQUE VS RPM CURVE:
LOOKUP TABLE:
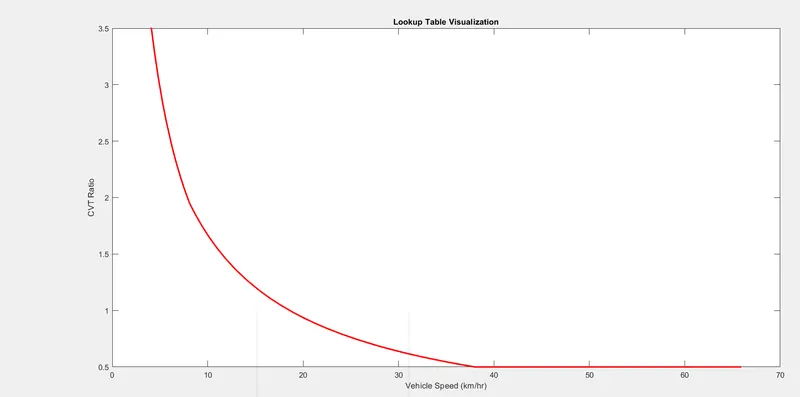
A lookup table is an array of data that maps input values to output values thereby approximatelyba mathametical function given a set of input values ,a lookup operation retrives the corresponding output values from the table if the lookup table does not explicity define the input values,simulink can estimate an output value using interpolation extrapolation or rounding where
.An interpolation is aprocess for estimating values that lies between know data points
.An extrapolation is a process for estimating values that lie beyond the range of known data points
.a rounding is a process for approximating a value by altering its digits accordind to known rule
The brake input and throttle input is given by step time which depends on the run time and varies accordingly by using lookup tablr for gear ratio which takes as input to CVT and works according to input gear ratio and obtained the output this method is very effective which can avoid the unusual torque at certain speed and very easy to achieve greate velocity and engine speed it works as closed loop when the input is given by lookup table.The simulink get the input value from lookup table and obtain the result according to input values of gear ratio.The gear ratio varies as input and output interms of velocity.The maximum velocity reached
OUTPUT
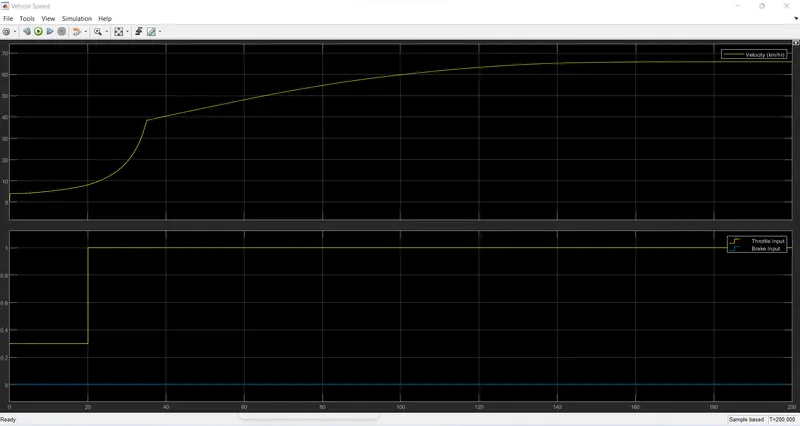
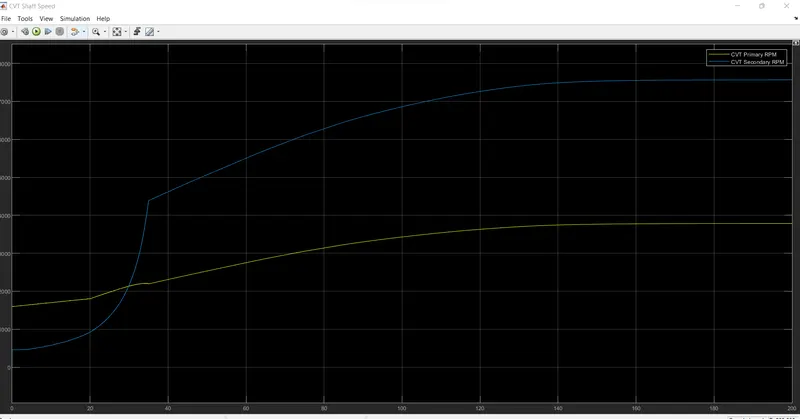
In the above fig the brake is maintained as constant and increase in throttle which shows increase in velocity.the flow of fuel is increases when the throttle increase fthus the power in the engine increases tge torque reaches approximtaely which defines that gear ratio is directly proportional to torque by this gear ratio the speed and velocity can achieve maximum .the gear ratio is assigned in lookup table and given as input to simulink which reads every input value and obtain the result according to input
the primary shaft speed increase by increasing throttle and decreasoing by increasing brake input value which defines that the throttle can flow more amount of fuel which increses the power of engine and similar to secondary shaft the radius if primary shaft as more than the secondary shaft the speed is directly proportional to radiud of shaft as the radius increases the speed of shaft also increases
5-CVT MODEL MODEL MAPPED DASHBOARD
MODEL AND SUBSYSTEMS:
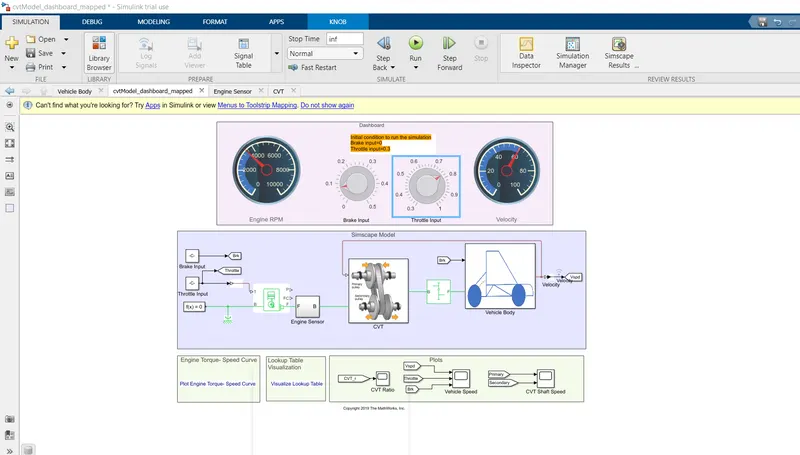
The above figure shows BAJA ATV with dashboard model using lookup table which consists throttle meter and brake input in dashboard and indicated as constant block rest of the blocks and subsystems are common in the abovebajaATV model without dashboard as shown.The main concept of using dashboard is study the reuslt by varying the input of brake and throttle which shows that the variation of velocity and speed .The gear ratio is given by lookup table simulink get the input value from the lookup table and obtain the result accordingly to lookup table as the brake input varies the velocity and speed decresingly accordingly which inturn the gear ratio also decreasing .By increasing the throttle the velocity and speed of the engine and shaft increases.The transmission as primary pulley and secondary pulley in which the radius of primary pulley increase by compacting and tge radius of secondary pulley decreases as gesr ratio varies as also torque varies gear ratio is directly proportional to torque which increases by increasing the gear ratio as tghe max torque the speed and velocity decreases
LOOKUP TABLE:
OUTPUT
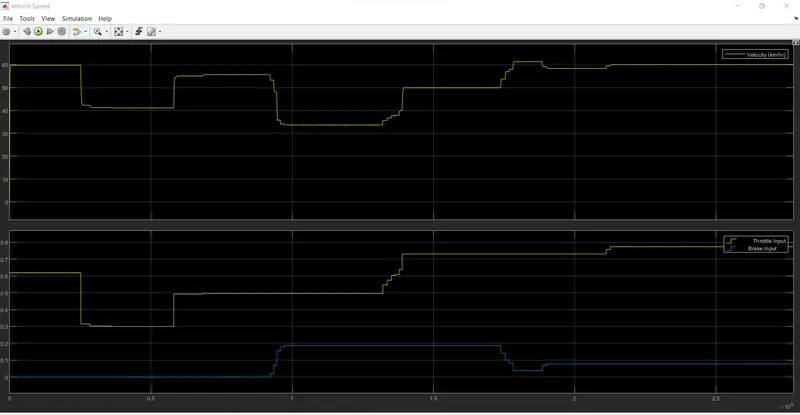
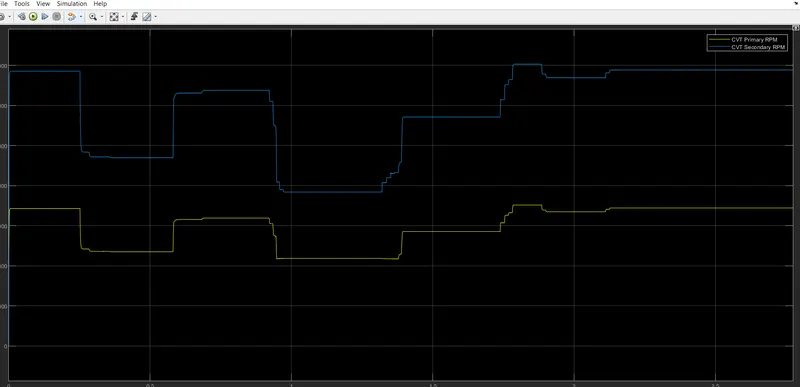
In the abovr figure the velocity of vehicle is maintained as constant for constant throttle value varying by increasing the value of throttle which increases the velocity of the vehicle decreasing accordingly which shown using lookup table it works as closed loop by recordingly the velocity value and we can get at any particular value of gear ratio which beyond the range or any random value within the range by using extrapolation and interpolation by lookup table
The primary shaft speed increases by increasing throttle and decreasing by increasing brake input value,which defines that the throttle can flow more amount of fuel which increases the power of engine and simiar to secondary shaft the radius of primary shaft as more than the secondary shaft the speed is directly poprtional to radius os shaft as the radius increases tge speed of the shaft also increases .The throttle value and brake input can be varying dashboard so we can get any particular value for input
RESULT:
As the throttle increases the velocity also increases which turn the power in engine also increases
At the begining the speed reducing because of gear ratio and torque output when the gear ratio increases the torque increases
As the brake input increases the velocity decreases and engine power also decreases at a certain brake input the engine may shut down and there is no power input.the engine power is inversly proportional to brake input
As the gear ratio increses torque increases which inturn the velocity decresses
The torque is increasing by increasing in engine speed at aparticular point that the torque is decressing when the gear ratio increases in ordee to achieve maximum velocity.for the high gear ratio the torque is more which decreases the velocity by changing to higher gear,the gear ratio become less parallely the toque also less which can get high velocity
With help of lookup table we can vary input value and also get the output value by using interpolation and extrapolation method which the simulinlk can solve