Project
SIMULATION OF BAJA ALL-TERRAIN VEHICLE
AIM: To study and analysis the BAJA All-Terrain Vehicle (ATV) using Simulink model.
OBJECTIVE: To Prepare a technical report explaining the model properties & comments on the results.
THEORY:
All-Terrain Vehicle
An all-terrain vehicle (ATV), also known as a quad, as defined by the ANSI is a vehicle that travels on low-pressure tires, with a seat that is straddled by the operator, along with handlebars for steering control. As the name implies, it is designed to handle a wider variety of terrain than most other vehicles. Although it is a street legal vehicle in some countries, it is not street-legal within most states, territories, and provinces of Australia, the United State or Canada. By the current ANSI definition, ATVs are intended for use by a single operator, although some companies have developed ATVs intended for use by the operator and one passenger.
BAJA ATV
Baja SAE is an intercollegiate engineering design competition for undergraduate and graduate engineering students. The object of the competition is to simulate real-world engineering design projects and their related challenges. Each team is competing to have its design accepted for manufacture by a fictitious firm. The students must function as a team to design, build, test, promote and compete a vehicle within the limits of the rules, also to generate financial support for their project and manage their educational priorities.
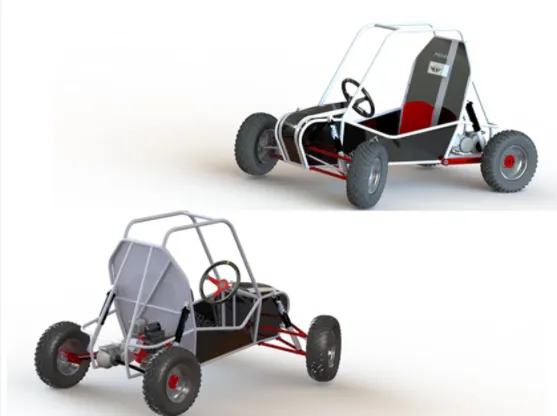
Each team's goal is to design and build a prototype of a rugged, single seat, off-road recreational vehicle intended for sale to the non-professional weekend off-road enthusiast. The vehicle must be safe, easily transported, easily maintained and fun to drive. It should be able to negotiate rough terrain without damage. As of 2010, the SAE Baja Series consisted of three competitions, though in the past there have been as many as seven sanctioned events. A Baja SAE competition event consists of three to four days.
Major Components :
Generic Engine: The Generic Engine block represents a general internal combustion (IC) engine which is a type of Spark Ingition (SI-Petrol) or Compression Ignition (CI-Diesel). The speed torque and speed power parameters are provided.
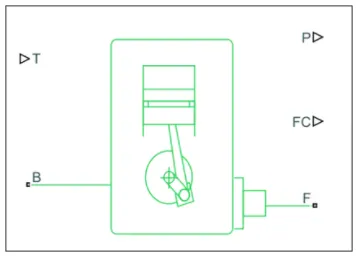
Ports,
• B- Rotational conserving port representing the Engine Block. level.
• F- Rotational conserving port representing the Engine Crankshaft.
• T- Physical signal input port specifying the normalized engine throttle.
• P- Physical signal output port reporting the instantaneous engine power, in W.
• FC-Physical signal output port reporting the fuel consumption rate, in kg/s.
Simple Gear:
The most common use is in motor vehicles, where the transmission adapts the output of the internal combustion engine to the drive wheels. Such engines need to operate at a relatively high rotational speed, which is inappropriate for starting, stopping, and slower travel. The transmission reduces the higher engine speed to the slower wheel speed, increasing torque in the process. Transmissions are also used on pedal bicycles, fixed machines, and where different rotational speeds and torques are adapted.
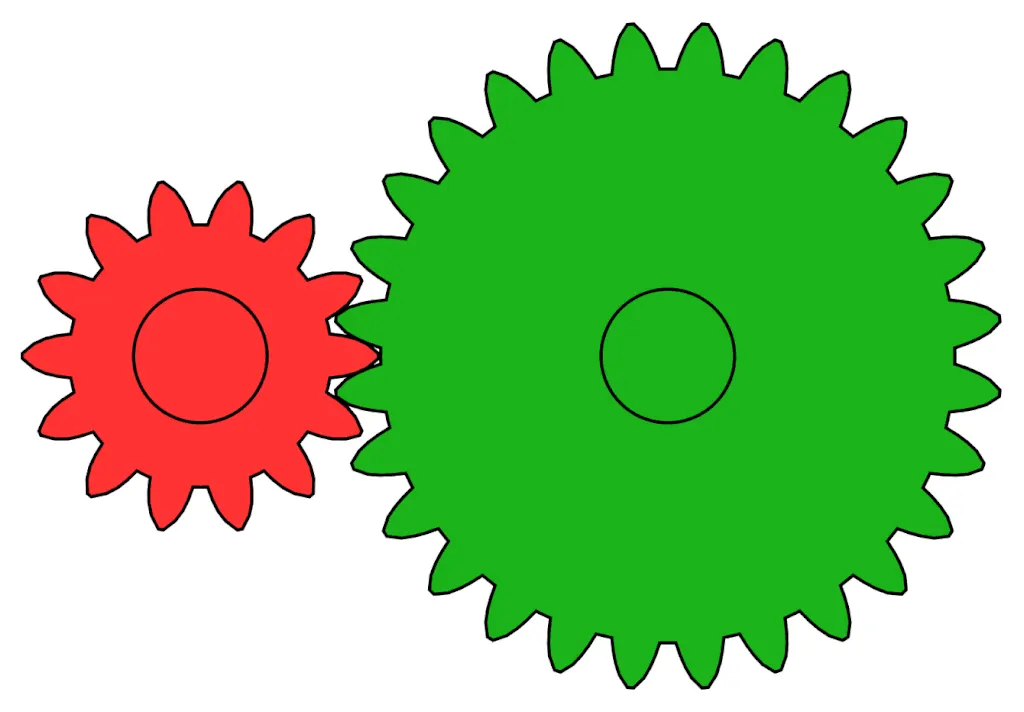
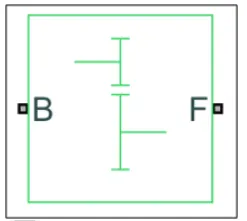
B- Base Gear, F-Follower Gear.
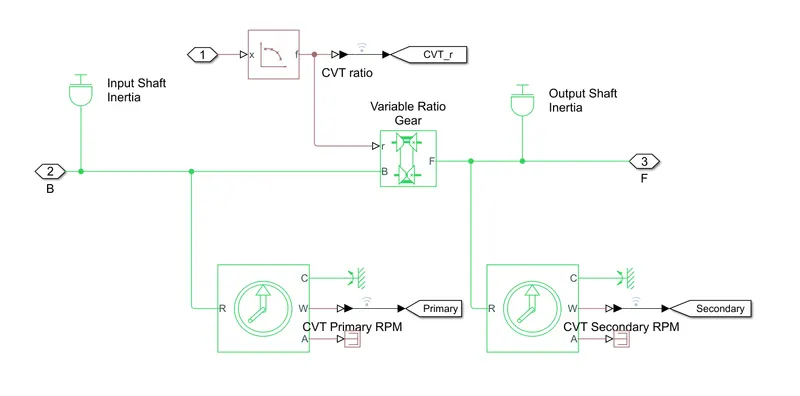
CVT Transmission:
The meaning of the abbreviation CVT is Continuously Variable Transmission, and it's a type of single-speed automatic gearbox. The CVT gearbox has been used in a variety of cars, but you'll usually find it fitted to a small car. Its compact size and simplicity of construction means it's more cost-effective to use in a small car than a conventional automatic gearbox in many ways a CVT gearbox is similar to a regular auto. For starters, there is no clutch pedal in a CVT-equipped car, so you can drive it on an automatic-only UK driving license. You'll also find that if a car is offered with a CVT gearbox, it will be more expensive than the same model with a manual gearbox, just like a regular auto. If you compared them back-to-back, the manual model would have better claimed fuel economy, too. But again, that's the same as you'll find with a regular auto 'box.
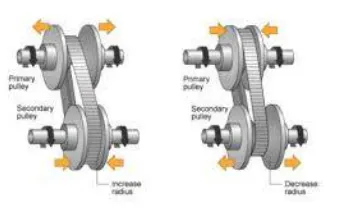
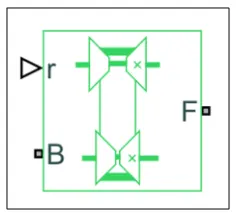
B- Base Pulley, F- Follower Pulley, r- Variable Transmission Ratio
Vehicle Body:
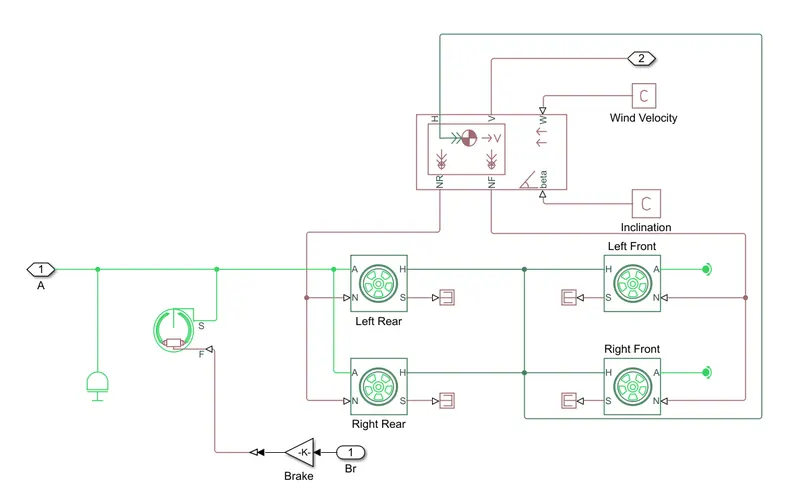
Two-axle vehicle with longitudinal dynamics and motion and adjustable mass, geometry and drag properties. The vehicle can have the same or a different number of wheels on each axle. For example, two wheels on the front axle and one wheel on the rear axle. The vehicle wheels are assumed identical in size. The vehicle can also have a center of gravity (CG) that is at or below the plane of travel.
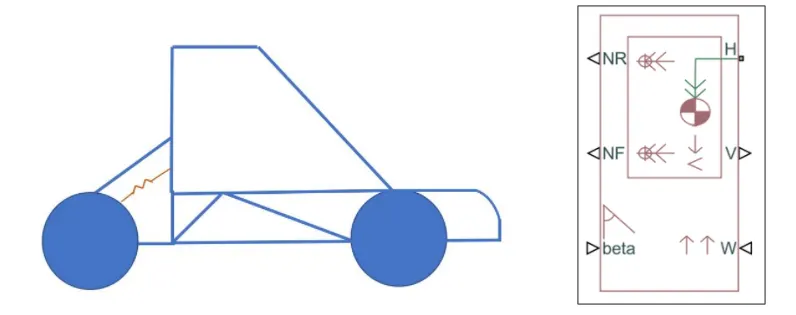
NR- Rear axle normal force, NF- Front axle normal force, beta- Road incline angle,
V- Longitudinal velocity, W- Head wind speed, H- Horizontal motion
Double Shoe Brake:
The Double-Shoe Brake block represents a frictional brake with two pivoted rigid shoes that press against a rotating drum to produce a braking action. The rigid shoes sit inside or outside the rotating drum in a diametrically opposed configuration. A positive actuating force causes the rigid shoes to press against the rotating drum. Viscous and contact friction between the drum and the rigid shoe surfaces cause the rotating drum to decelerate.
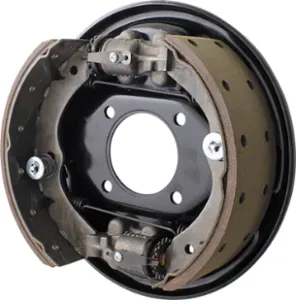
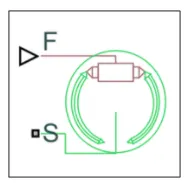
S- Rotational conserving port associated with the rotating drum shaft F- Physical signal input port associated with the applied actuating force
Tyre:
The Vehicle body is connected to 4 tyres each per axle to move the vehicle according to the power input to the axle.
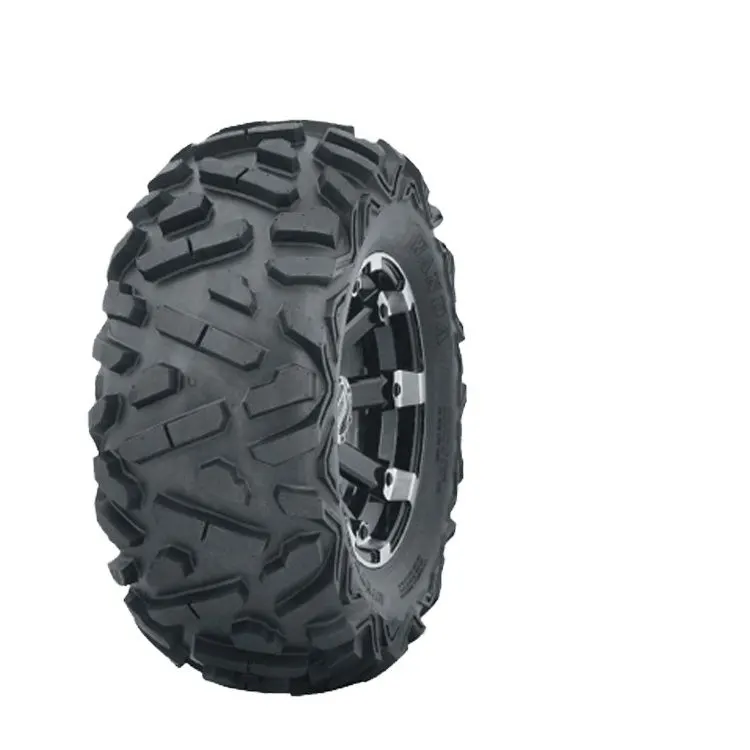
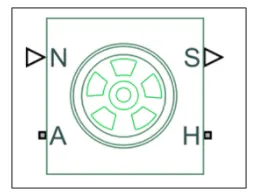
N- Normal force, 5- Tire Slip, A- Axle, H- Mechanical translational port
TYPES OF MODEL:
■ BAJA ATV model without Dashboard
■ BAJA ATV model with Dashboard
■ BAJA ATV model Lookup table data Extraction
■ BAJA AV model Mapped Lookup table without Dashboard
■ BAJA AV model Mapped Lookup table with Dashboard
BAJA ATV model without Dashboard:
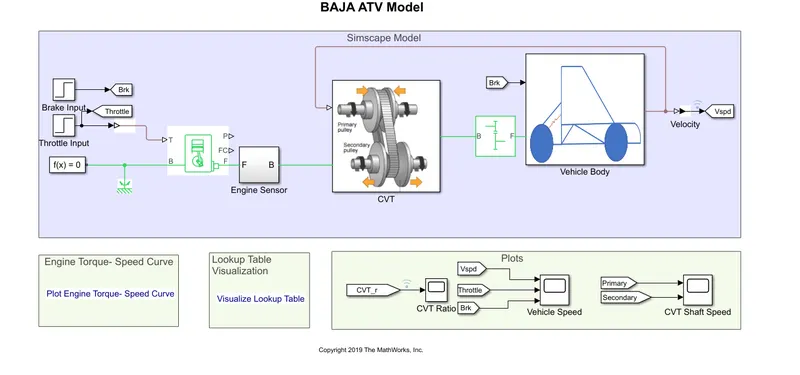
Main Model:
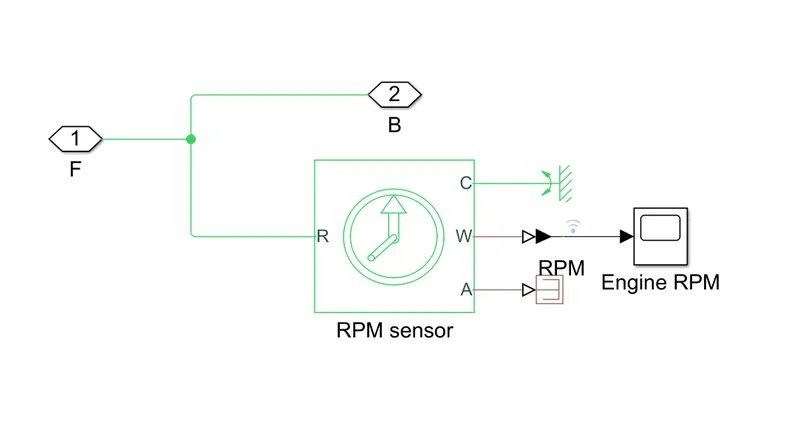
Engine Sensor :
CVT System :
Vehicle Body :
PROCESS:
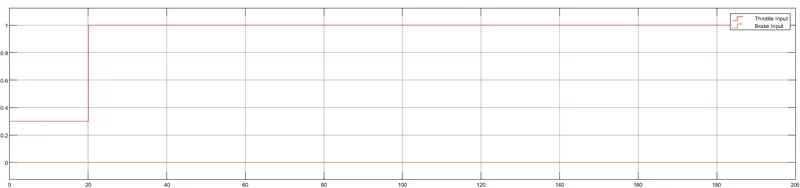
• The Throttle input signal is generated by the signal builder block and it connected to Engine.
• And the Brake input signal also generated by the Signal Builder block and its input to the Vehicle Axle.
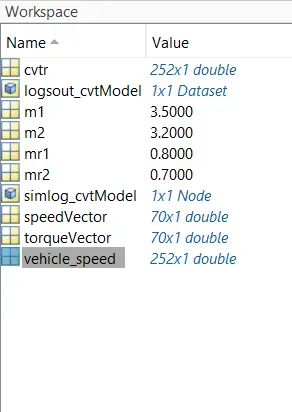
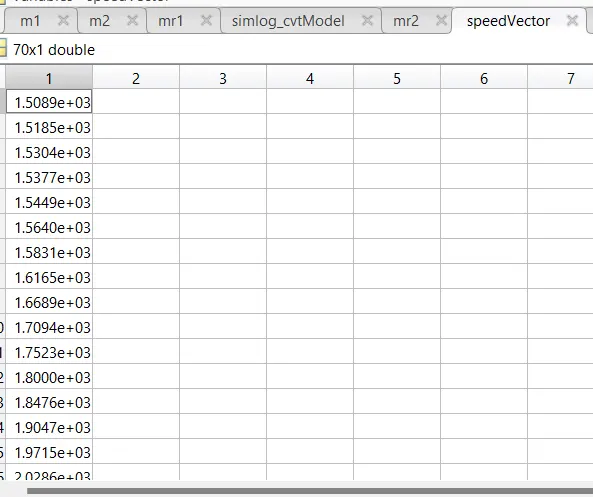
• The Speed Vector and Toque Vector input is given in the MATLAB Workspace.
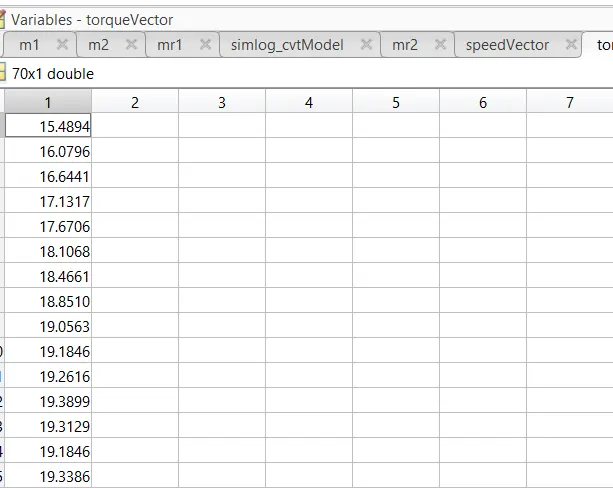
• The Engine will generate the output rpm which can be taken from the crankshaft output. This speed will be given to the Ideal Rotational Motion Sensor to sense the output rpm.
• Then the output speed of the Engine is given to CVT to reduce the speed.
• The CVT ratio is provided to the varaible Ratio Transmission CVT block through Signal Builder.
• The speed is controlled by the CVT ratio and the controlled output speed is input to the simple Gear.
• And the simple gear output is given to vehicle axle body to accelerates according to the speed.
• Then the Velocity is taken as output from the vehicle body for further analysis.
RESULTS:
Torque-speed plot,
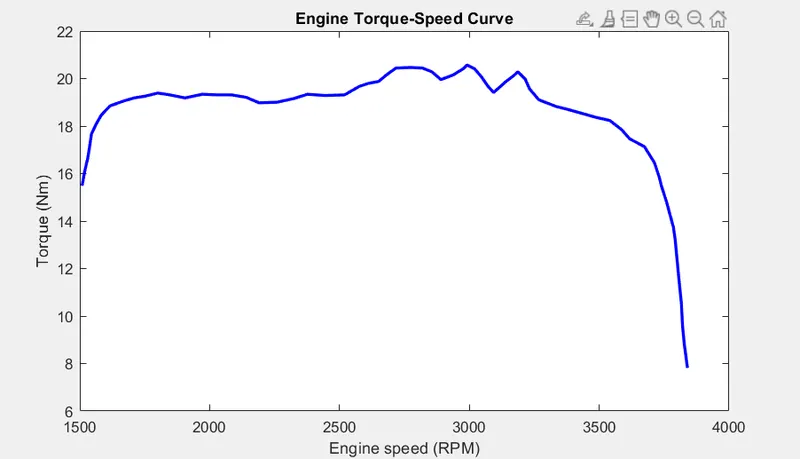
The torque and speed are input from the MATLAB workspace window to the generic engine block to generate the output RPM. This plot is common for all the cases because its a default input to the engine.
VEHICLE SPEED PLOT,
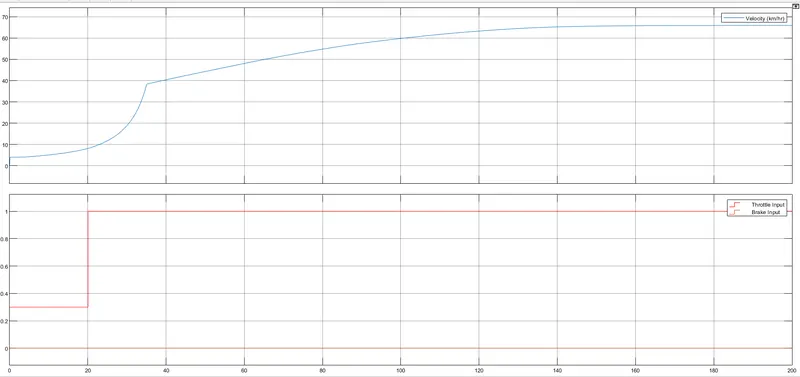
- In this plot the Brake value is not given and the Thottle value is constant in 0.3 till 20sec and after increase into 0.3 to 1 at after
20sec. - And the Velocity of the vehicle is increase gradually for the input of the thottle.
CVT SHAFT SPEED PLOT,
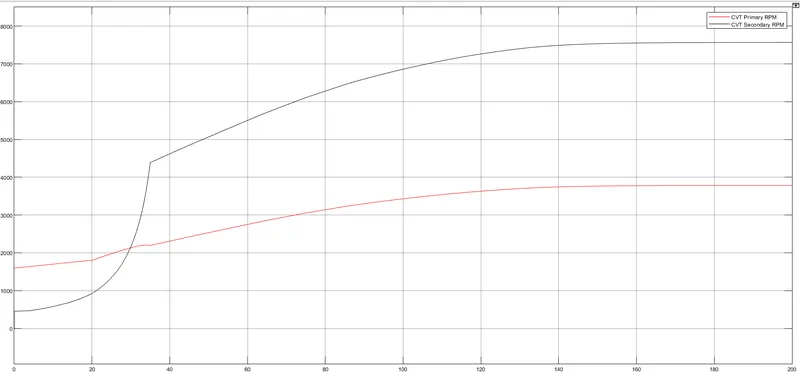
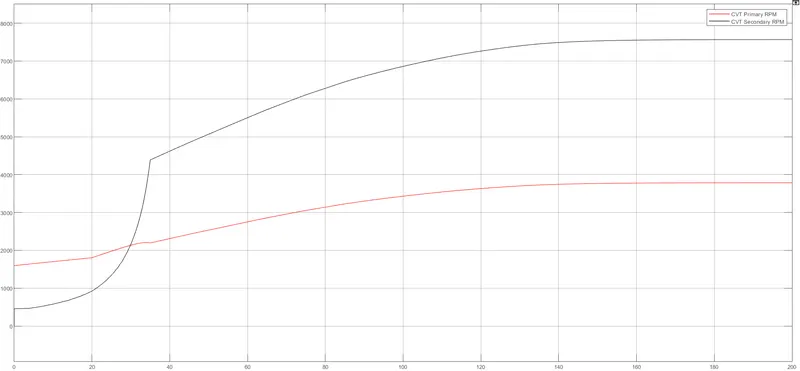
- In this plot we have two result one is CVT primary RPM and another one is CVT Secondary RPM
- In the CVT primary RPM is the input of the CVT it as high RPM above 7000 rpm and secondary RPM is used to reduce the rpm speed
as per the Gear ratio.
Maximum RPM=7400 rpm.
CVT Ratio = 1:1.8
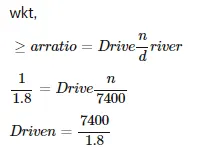
Driven = 4111.1RPM
The reduced maximum rpmis 41111 rpm.
BAJA ATV MODEL WITH DASHBOARD:
MAIN MODEL:
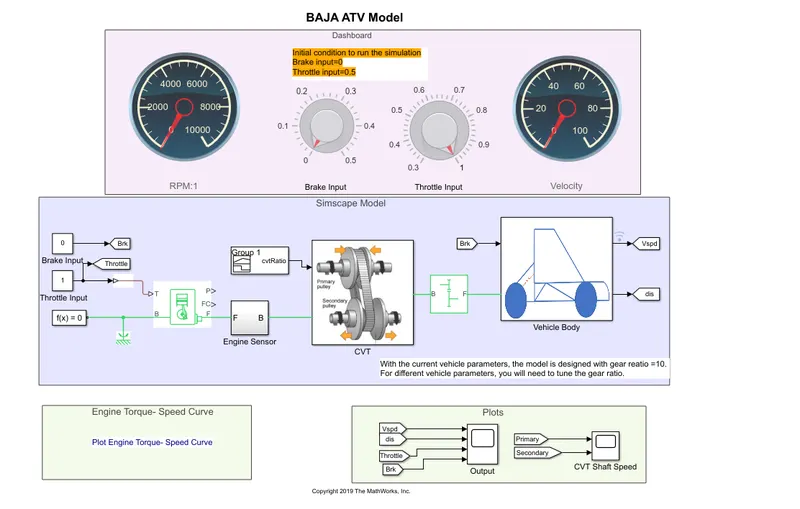
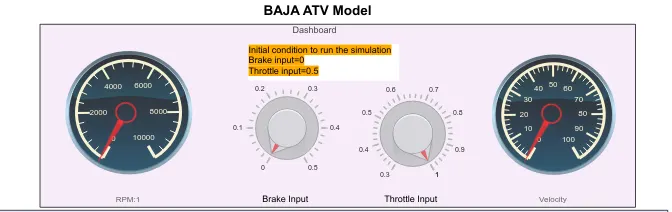
DASHBOARD:
FLOW PROCESS :
The model work flow process is same as the process of BAJA ATV model without DashBoard But the throttle and the brake inputs are controlled by user with the help of the knobs in this model.
RESULTS:
CVT Speed Reduction Plot,
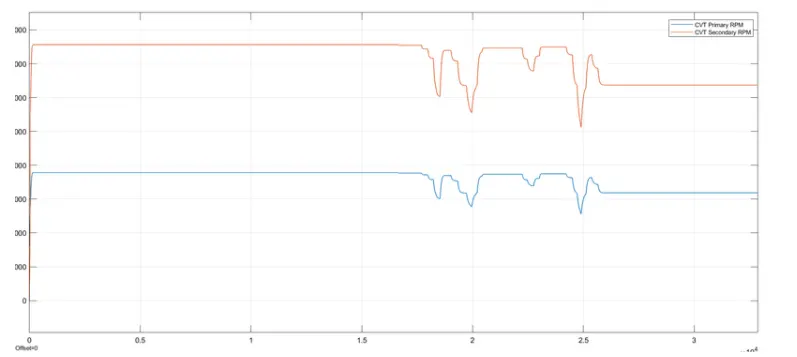
The engine reduction speed is controlled by Various CTV ratio.
VELOCITY
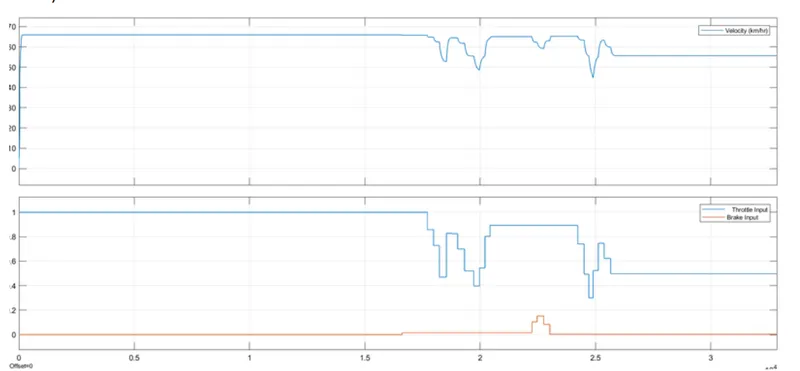
From the graph we can refer that vehicle is accelerating while throttle is applide (step UP) and deaccelerated when the brake is applied (Step Down)
Baja ATV Look Up Model Table Data Extraction:
MODEL :
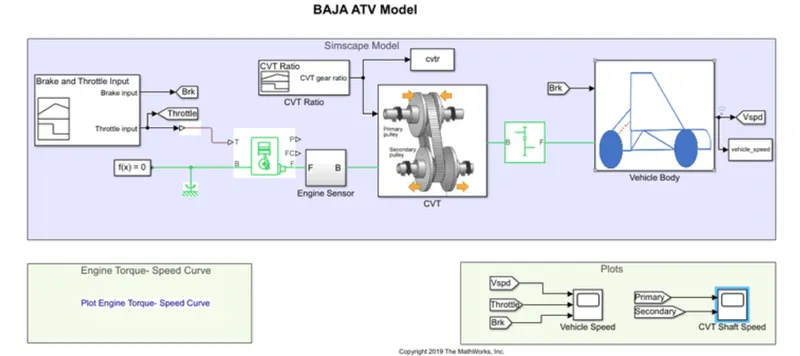
Flow Process:
The model workflow process is same as the process og BAJA ATV model without Dashboard. The small addition is here the CVT Ratio and Vehicle Speed data are extracted using To Workspace.
Results:
The results are same as BAJA ATV model without Dashboard but an additional output is the CVT Ratio and Vehicle Velocity to the Workspace.
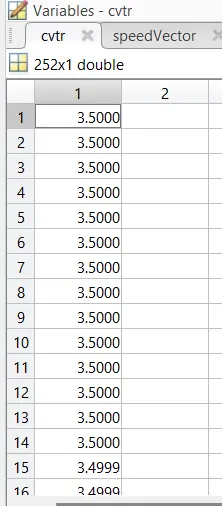
they are exproted to work space
BAJA ATV Model Mapped LookUP Table Without DashBoard
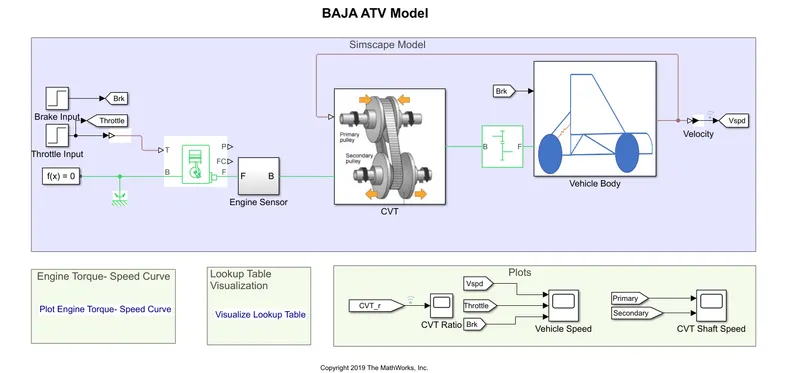
Main Model :
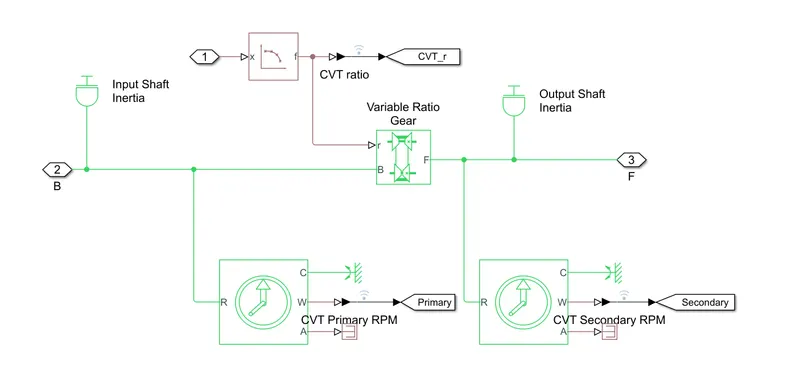
CVT Block :
Process :
- The Model workflow is same as the process of BAJA ATV modelwithout Dashboard.
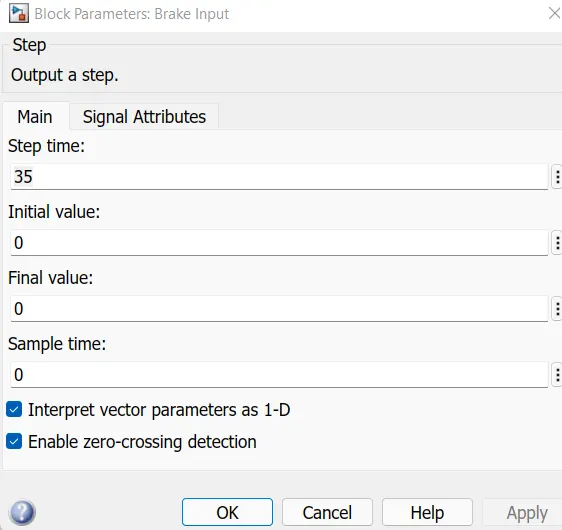
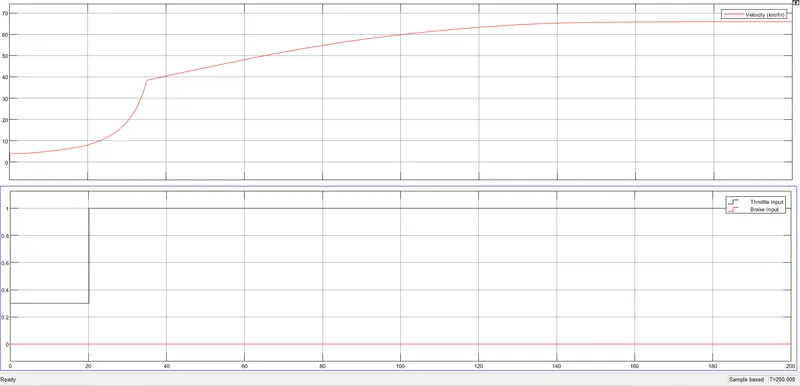
- Instead of SignalBuilder blocks for Brake and throttle input the step blocks are used.At 35 sec the brake input will take a step of value 0.
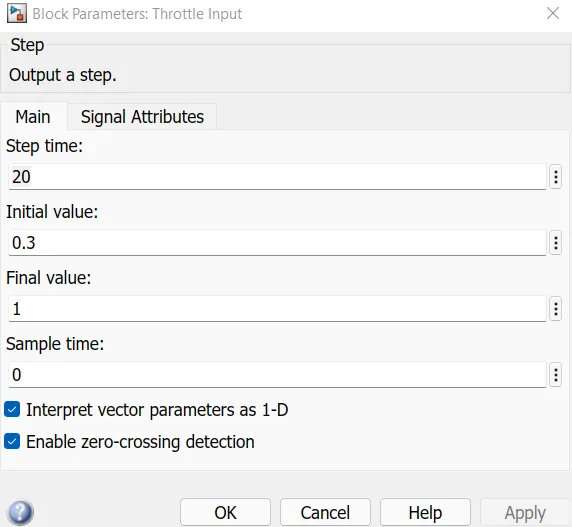
- The throttle inpust is 20 Secs, input will increase from 0.3 - 1 then remains constant through out.
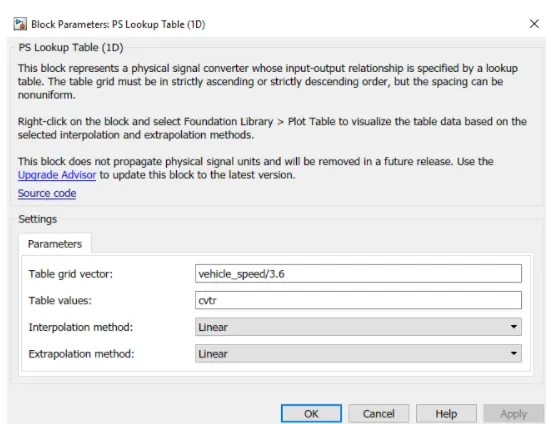
- And instead of signal builder block in CVT Ratio, 2 -D Look up table is used. the interpolation and extrapolation methods are set to linear
- At last the vehicle speed output is given as fedback tothe 2-D lookup table so that we can verify that the velocity of the vehicle is changing perfectly when the CVT Ratio changes. The vehicles speed is converted to m/s from kmph.
RESULTS:
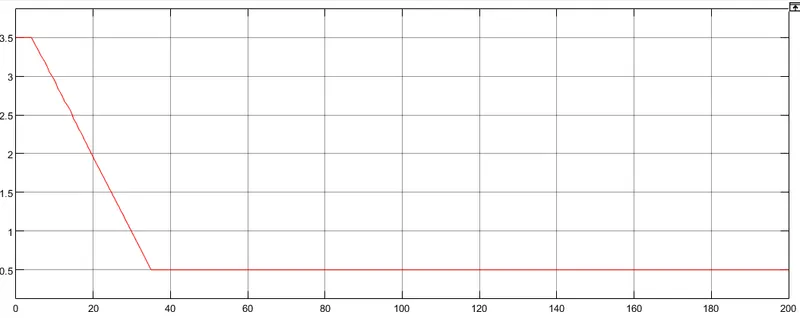
CVT Ratio vs Vehicle Speed: Lookup Table Visualization
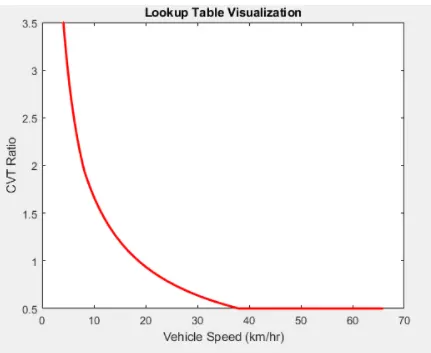
In the above plot is a value of the lookup table visualization.
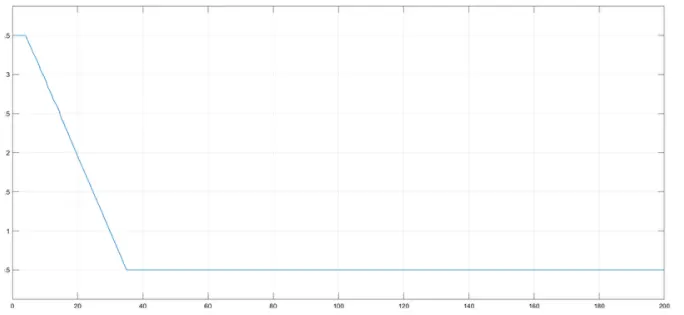
i. 0 to 5 km/hr. the CVT ratio is constant at 3.5.
ii. 5 to 35 km/hr. the CVT ratio is drops down to 0.5.
iii. 35 km/hr onwards. the CVT ratio is constant at 0.5.
Hence. we can conclude that the vehicles accelerates. decelerates and remains constant when the CVT Ratio is being vaned.
CVT Shaft Speed :
SPEED vs THROTTLE PLOT ;
BAJA AV model Mapped Lookup table with Dashboard:
Main Model:
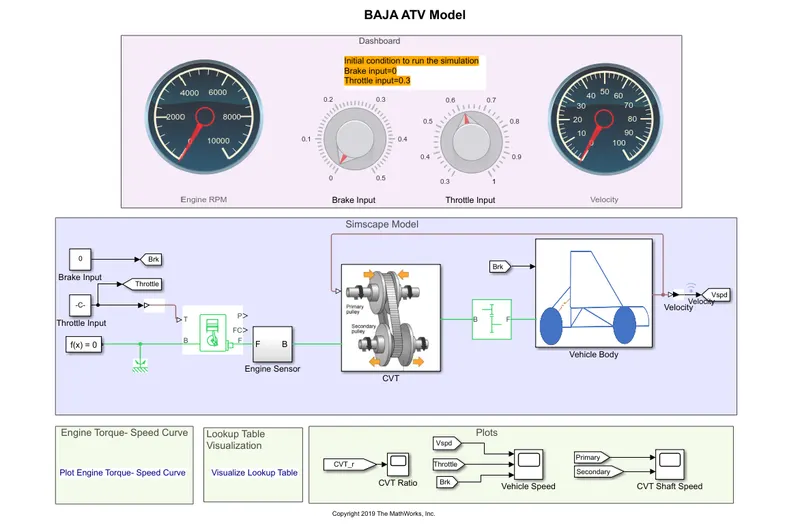
Flow Process:
The model workflow process is same as the process of BAJA ATV model - mapped lookup table with Dashboard but the Throttle and Brake inputs are controlled by the user with the knob followed by the vehicle speed is given as feedback to the CVT Ratio lookup table.
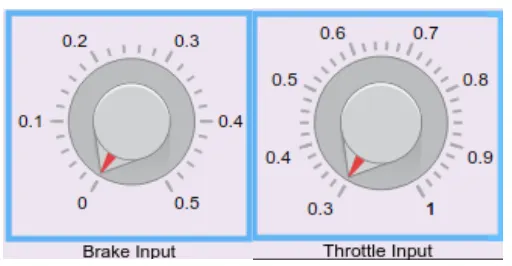
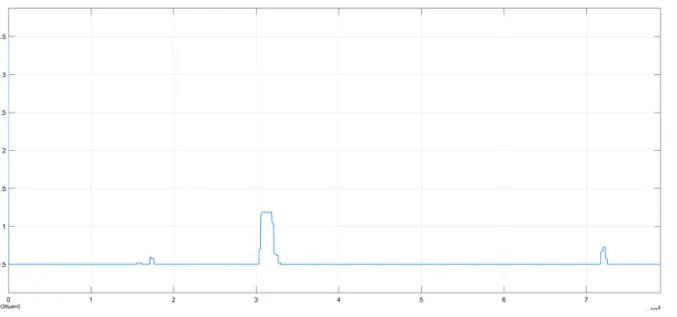
CVT Ratio :
CVT Shaft Speed :
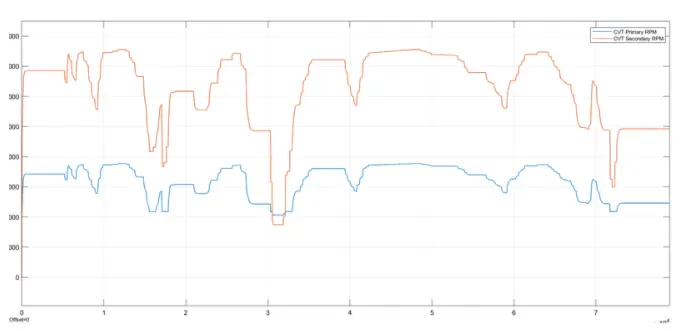
From the above graph we can understand that the throttle is applied (step up) and then kept constant then braking is applied (step down) then brake released so that the engine speedis increased with increase in throttle input.
Velocity :
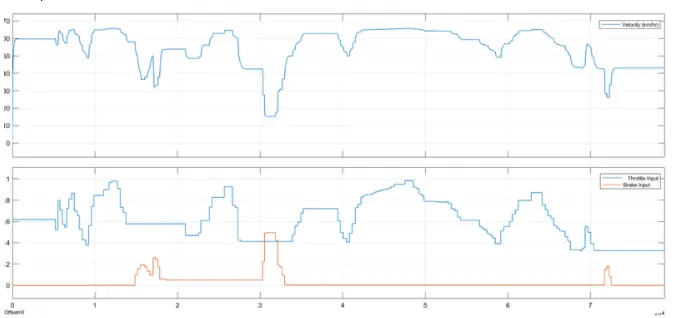
From the plot we can infer that when throttle is applied the vehicle speed increases and when brake is applied vehicle speed decreases simultaneously.
Conclusion:
System level Simulation of an BAJA All terrain vehicle Without Using Look Up Table and Using Look Up Table has been carried out and technical report for the model has been prepared and Output Results are plotted.
Simulink Model :
Download the model from the given link:
https://www.mathworks.com/matlabcentral/fileexchange/70576-baja-all-terrain-vehicle-atv-model