Project
System-level simulation for all terrian vehicle
AIM :-
To study and analysis the BAJA All-Terrain Vehicle (ATV) using Simulink model.
Objective:
- To prepare the technical report by explaning the model properties and comment on the result.
- To study all the models of simulink (i.e open loop,closed loop,mapped model using lookup table).
Theory:
An all-terrain vehicle (ATV), also known as a light utility vehicle (LUV), a quad bike, or simply a quad, as defined by the american national standard intitute(ANSI); is a vehicle that travels on low-pressure tires, with a seat that is straddled by the operator, along with handlebars for steering control. As the name implies, it is designed to handle a wider variety of terrain than most other vehicles
Baja SAE is an Collegiate design series competition run by the Society of Automotive Engineers International (SAE International). Teams of students from universities all over the world design and build small off-road cars. The cars all have engines of the same specifications. As of 2018 the engine has been an unmodified Model 19 Vanguard engine single-cylinder with a displacement of 305cc and power output of approximately 10 bhp (7.5 kW).
Baja SAE is an intercollegiate engineering design competition for undergraduate and graduate engineering students. The object of the competition is to simulate real-world engineering design projects and their related challenges. Each team is competing to have its design accepted for manufacture by a fictitious firm. The students must function as a team to design, build, test, promote and compete a vehicle within the limits of the rules, also to generate financial support for their project and manage their educational priorities.
Each team's goal is to design and build a prototype of a rugged, single seat, off-road recreational vehicle intended for sale to the non-professional weekend off-road enthusiast. The vehicle must be safe, easily transported, easily maintained and fun to drive. It should be able to negotiate rough terrain without damage. As of 2010, the SAE Baja Series consisted of three competitions, though in the past there have been as many as seven sanctioned events.
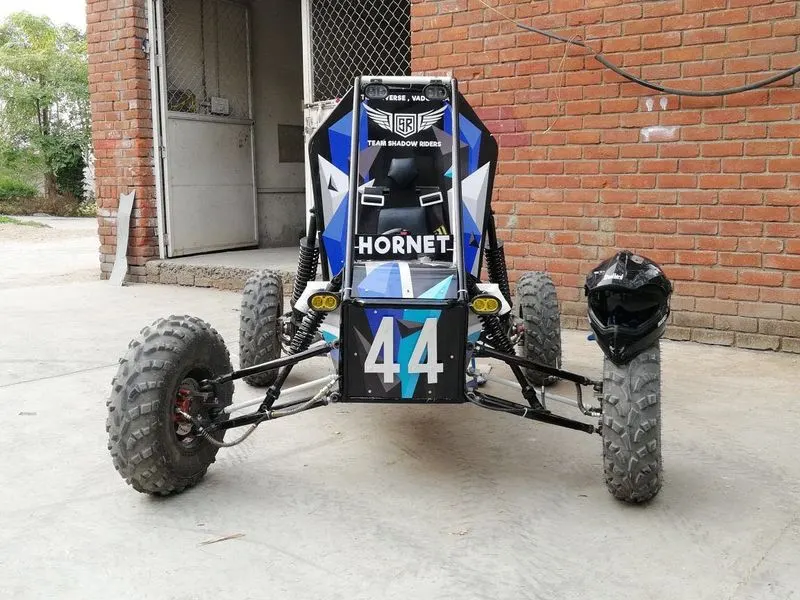
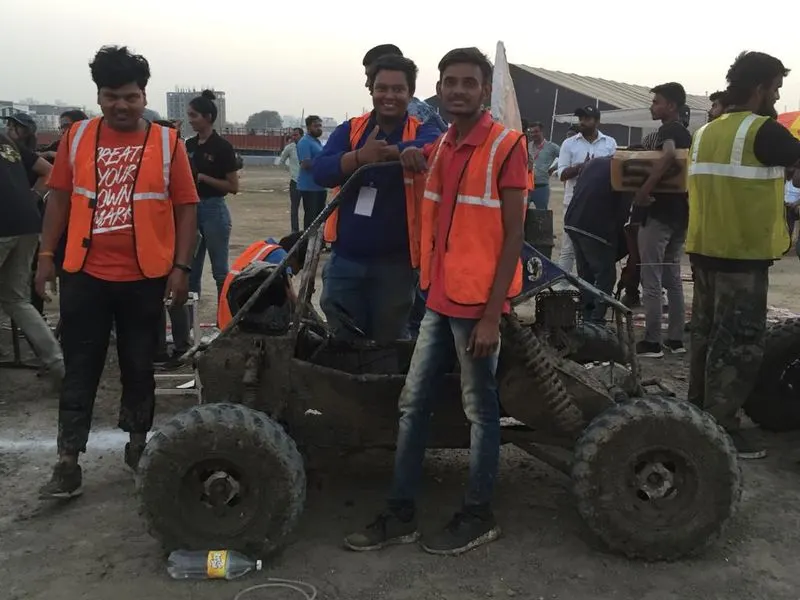
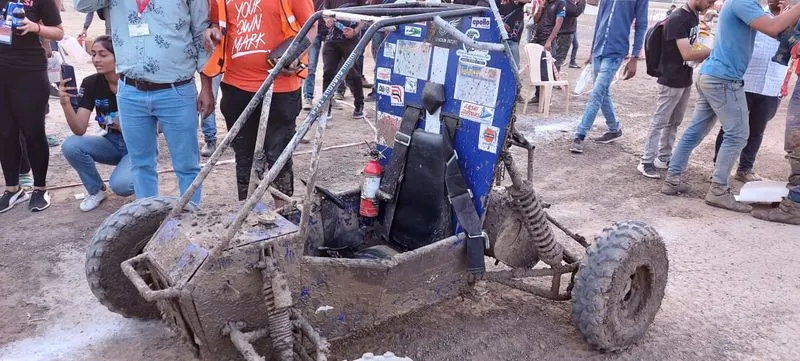
Below, is the 3 photo of our ATV (Team shaddow riders from ITM universe,vadodara)which we made in our final year and paricipated in ATVC2020,vadodara event our team got 9th rank in endurance out of around 70 team.
MAJOR COMPONENTS :-
Generic Engine :-
The Generic Engine block represents a general internal combustion (IC) engine which is a type of Spark Ingition (SI-Petrol) or Compression Ignition (CI-Diesel). The speed torque and speed power parameters are provided.
Ports,
- B- Rotational conserving port representing the Engine Block. level.
- F- Rotational conserving port representing the Engine Crankshaft.
- T- Physical signal input port specifying the normalized engine throttle.
- P- Physical signal output port reporting the instantaneous engine power, in W.
- FC-Physical signal output port reporting the fuel consumption rate, in kg/s.
Simple Gear : -
The most common use is in motor vehicles, where the transmission adapts the output of the internal combustion engine to the drive wheels. Such engines need to operate at a relatively high rotational speed, which is inappropriate for starting, stopping, and slower travel. The transmission reduces the higher engine speed to the slower wheel speed, increasing torque in the process. Transmissions are also used on pedal bicycles, fixed machines, and where different rotational speeds and torques are adapted.
- B- Base Gear,F-Follower Gear.
CVT(continuously variable transmission)
A continuously variable transmission (CVT) is an automatic transmission that can change seamlessly through a continuous range of gear ratios. This contrasts with other transmissions that provide a limited number of gear ratios in fixed steps. The flexibility of a CVT with suitable control may allow the engine to operate at a constant RPM while the vehicle moves at varying speeds.
The most common type of CVT uses two pulleys connected by a belt or chain, however, several other designs have also been used at times.
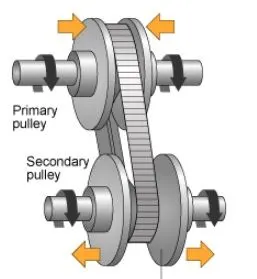
A CVT is a transmission having a speed ratio that can be varied continuously over its allowable range. Its speed ratio may take on any value between its operational limits, i.e., an infinite number of ratios are possible. A gearbox transmission, on the other hand, has a discrete number of fixed speed ratios.
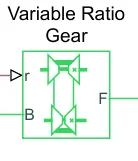
- B- Base Pulley
- F- Follower Pulley
- r- Variable Transmission Ratio
The Variable Ratio Transmission block represents a gearbox that dynamically transfers motion and torque between the two connected driveshaft axes, base and follower.
Ignoring the dynamics of transmission compliance, the driveshafts are constrained to corotate with a variable gear ratio that you control. You can choose whether the follower axis rotates in the same or opposite direction as the base axis. If they rotate in the same direction, ωFand ωB have the same sign. If they rotate in opposite directions, ωF and ωB have opposite signs.
Transmission compliance introduces internal time delay between the axis motions. Therefore, unlike a gear, a variable ratio transmission does not act as a kinematic constraint. You can also control torque loss caused by transmission and viscous losses
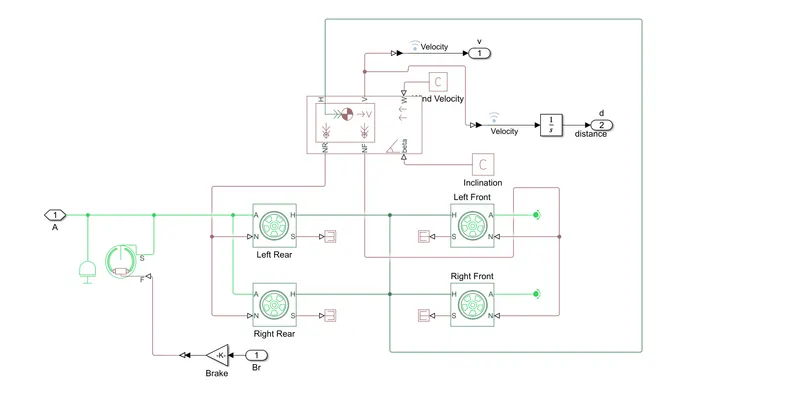
Vehicle Body :-
Two-axle vehicle with longitudinal dynamics and motion and adjustable mass,geometry and drag properties. The vehicle can have the same or a different number of wheels on each axle. For example, twowheels on the front axle and one wheel on the rear axle. The vehicle wheels are assumed identical in size. The vehicle can also have a centre of gravity (CG) that is at or below the plane of travel.
- NR- Rear axle normal force
- NF- Front axle normal force
- beta- Road incline angle
- V- Longitudinal velocity
- W- Head wind speed
- H- Horizontal motion
Double Shoe Brake :
The Double-Shoe Brake block represents a frictional brake with two pivoted rigid shoes that press against a rotating drum to produce a braking action. The rigid shoes sit inside or outside the rotating drum in a diametrically opposed configuration. A positive actuating force causes the rigid shoes to press against the rotating drum. Viscous and contact friction between the drum and the rigid shoe surfaces cause the rotating drum to decelerate.
- S- Rotational conserving port associated with the rotating drum shaft
- F- Physical signal input port associated with the applied actuating force
Tire :
The Vehicle body is connected to 4 tires each per axle to move the vehicle according to the power input to the axle.
- N- Normal force
- S- Tire Slip
- A- Axle
- H- Mechanical translational port
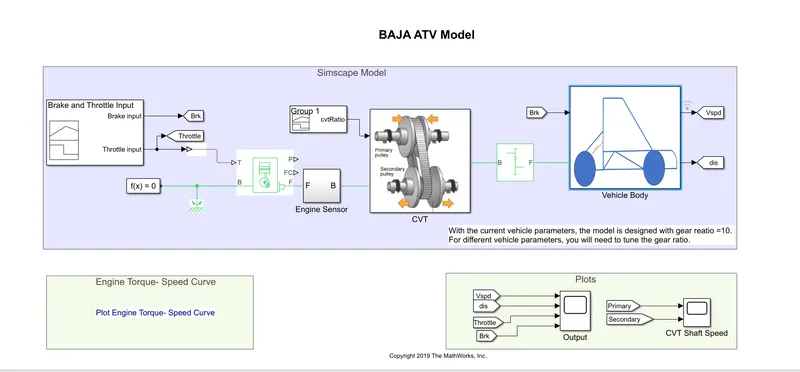
1. BAJA ATV MODEL WITHOUT DASHBOARD
MAIN MODEL :-
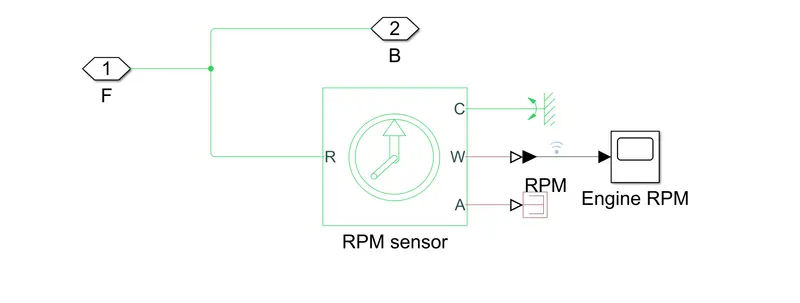
ENGINE SENSOR :-
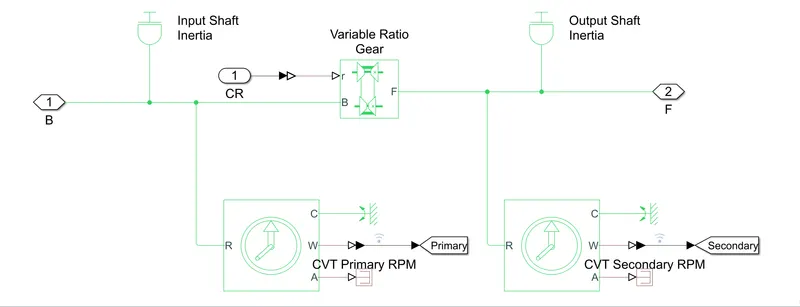
CVT SYSTEM :-
VEHICLE BODY :-
PROCESS:
- Here we used 2 seprate signal builder blocks each one for brake &throttle input and another block for CVT gear ratio.
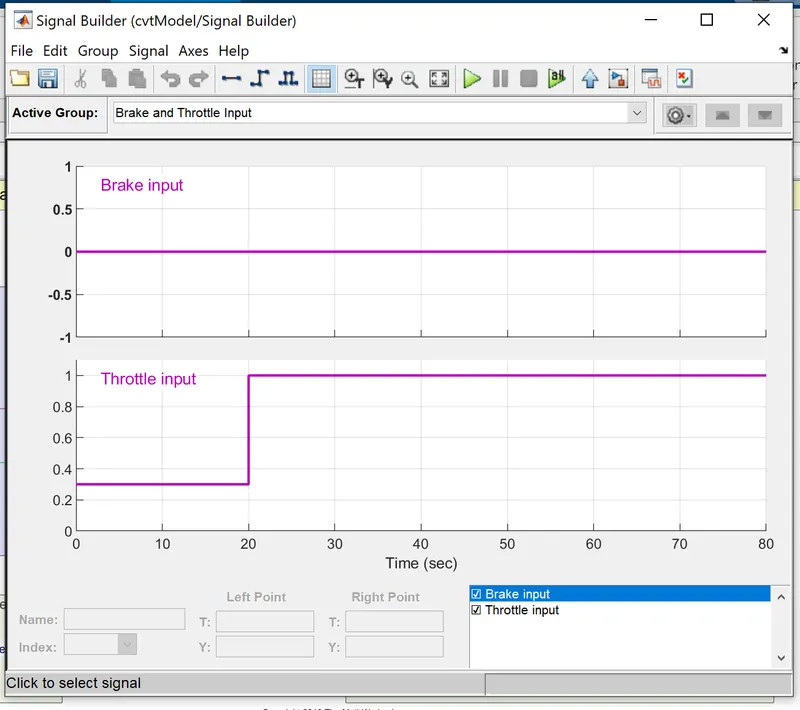
- From this signal builder we can understand that the input for brake is always zero for all conditions and the throttle input is 0.3 upto 20 sec of time and then its been increased to 1 and kept constant upto 80 sec.
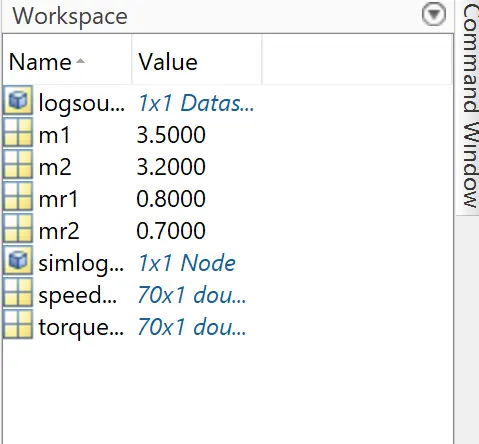
- The torque and speed vector are inputted from the MATLAB workspace.
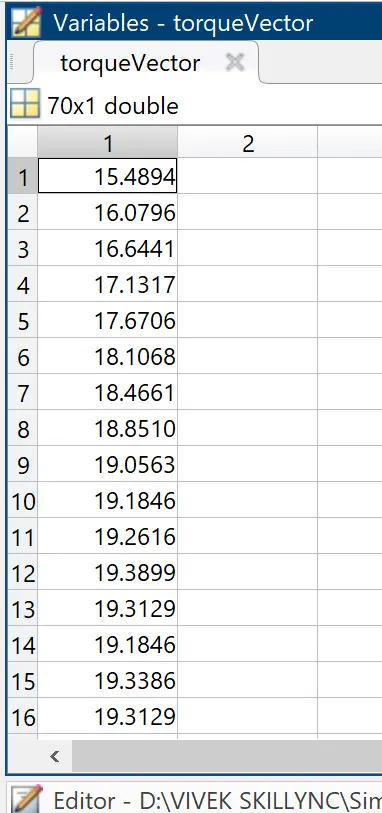
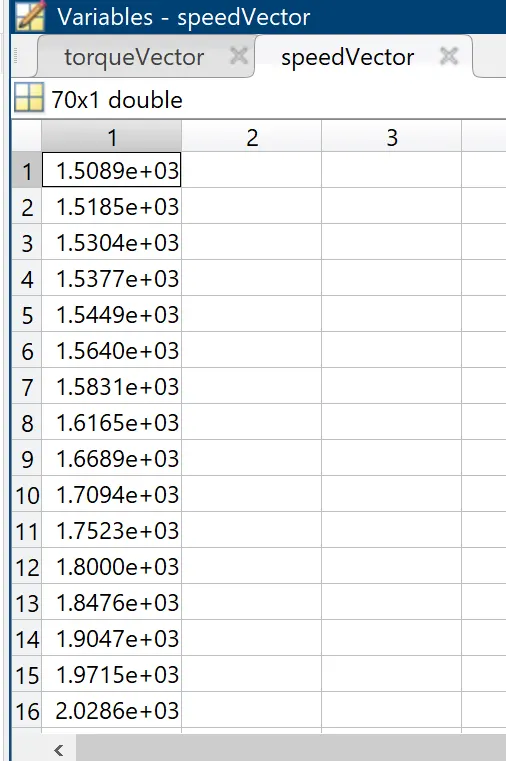
- The engine will generate the output rpm which can be taken from the crankshaft output. This speed will be given to the Ideal Rotational Motion Sensor to sense the output rpm.
- The same output speed will be given to a simple gear mechanism to reduce the speed where the Gear Ratio is ‘4’.
- Then the output speed from the gear reducer will be given to the Variable Ratio Transmission block (CVT).
RESULTS :-
TORQUE-SPEED PLOT :-
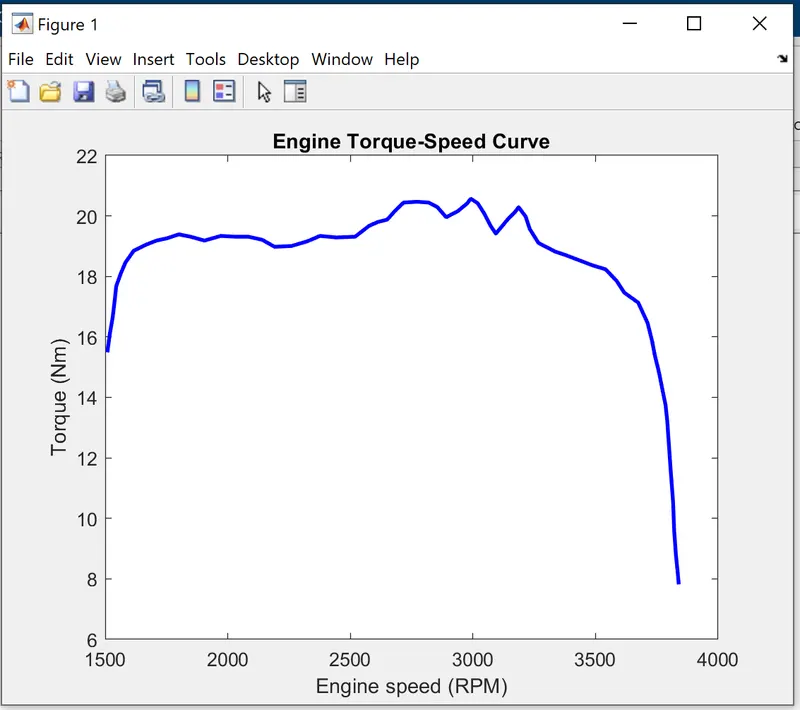
The torque and speed are inputted from the MATLAB workspace window to the generic engine block to generate the output RPM accordingly. This plot is common for all the cases because it’s a default input to the engine.
Output:
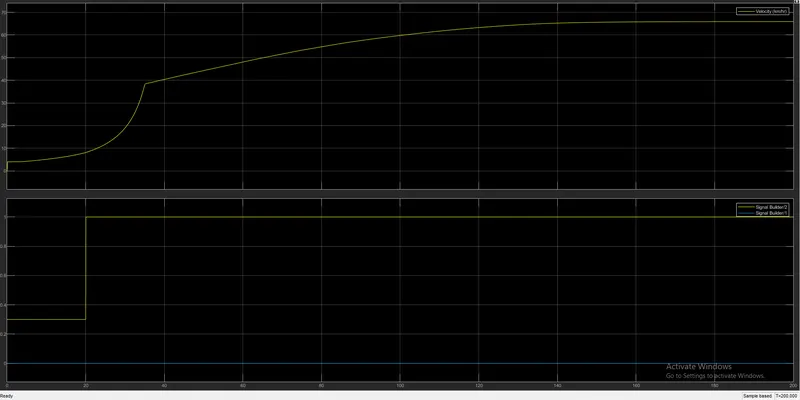
- In output first by observing the first plot we observe that how the velocity is increasing, at initial throttle value upto 35 s the velocity is increaing in parabolaic curve in nature and and after that its starts increasing in continuous manner without and discontinuity and after 140 it is seen that velcity is constant 68kmph till endrun time i.e 200sec
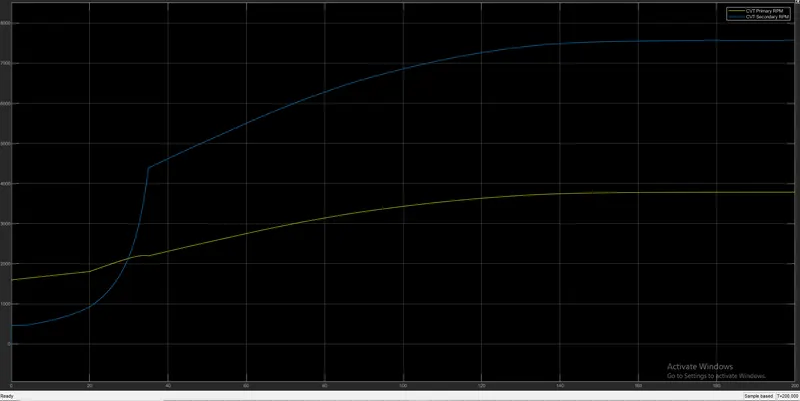
- Here by looking at plot the primary cvt at initial throttle value upto 20 sec it seems to be increasing lineraly and after increasing throttle value from 0.5 to 1 there some deviations in rpm upto 38 sec and after 40 sec rpm is been seen linearly increasing at constant throttle.
- In secondary cvt at output shaft it is been seen that the input throttle given to variable gear ratios its increasing with some losses and after some time i.e 140 s the cvt values matches with primary cvt which is constant till 200sec.
2. BAJA ATV MODEL WITH DASHBOARD
MAIN MODEL :-
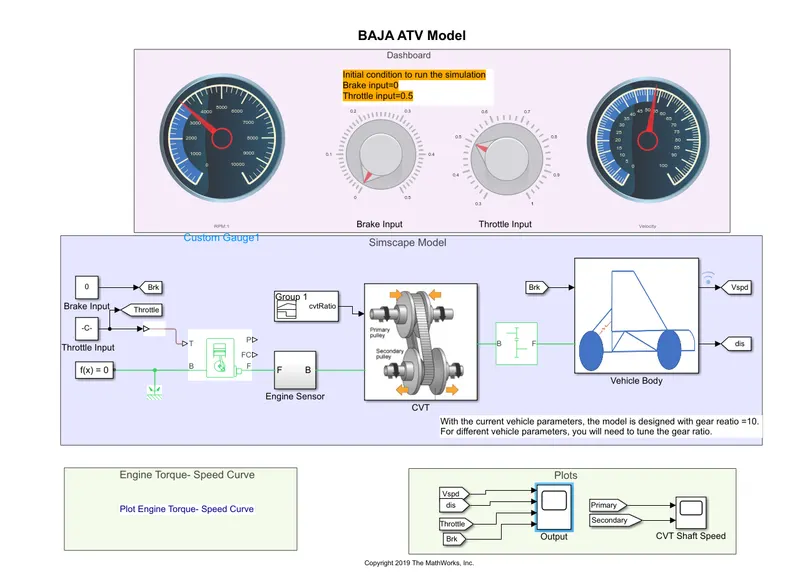
Explanation:
- In simscape model instead of the signal bulider block we used is the dashboard with two knobs of brake and throttle in which we gave the input as for brake input is 0 and throttle is 0.5 and we plot the result for inf time and stoped the run time at some point and visualize the result.
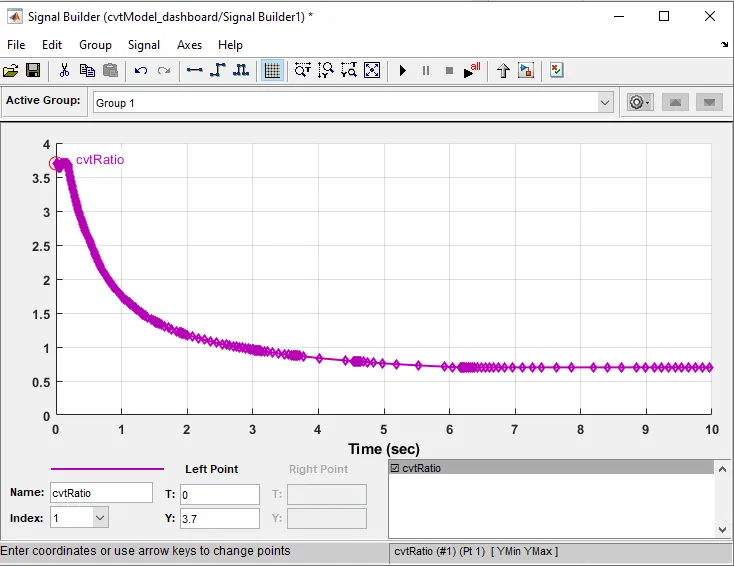
- Below shown is the cvt signal builder block in which we can see that at 0 the ratio was 3.7 initially and after some time with respect to time the ratio starts decreasing and after 6s the ratio was constant throughout at 0.7.
Output:
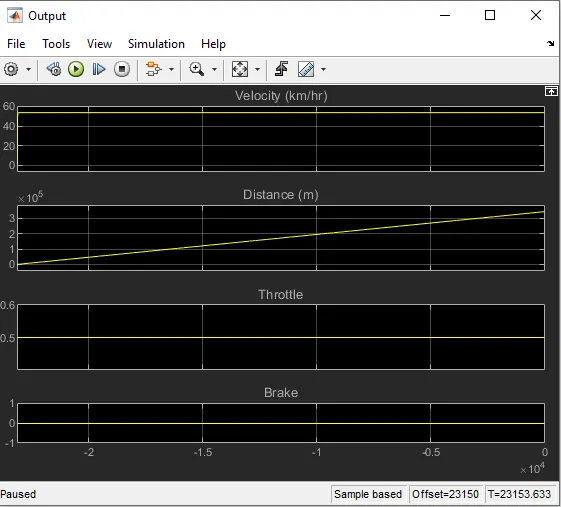
As we can see that after giving input of brake as 0 and throttle value as 0.5 constant throughout the speed as the vehichle is moving at 58kmph with a constant speed with linear increasing in a distance.
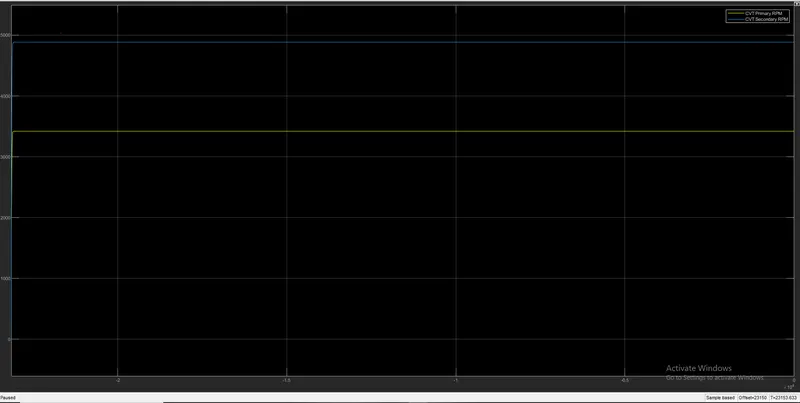
- After observing the output for primary and secondary cvt rpm it is oerved that primary cvt rpm started increasing after giving thrrotle upto 3400rpm amd after that rpm was constant throughout with respect tp chnage in velocity and time.
- Secondary cvt rpm is in increasing manner for intiall throttle value and it attined 4800 rpm and after that with respect to time and velocity it was constant .
Below we can see the plot of vehicle torque vs Rpm as it is observed that there is uneven cnahge in torque as the rpm changes after 3000 rpm torque value seems to be descreasing from 18Nm to 8Nm, as we know if speed increases torque decreases and vice versa.
3. Simulink model without dashboard but using lookup table for input values:
Simulink model:
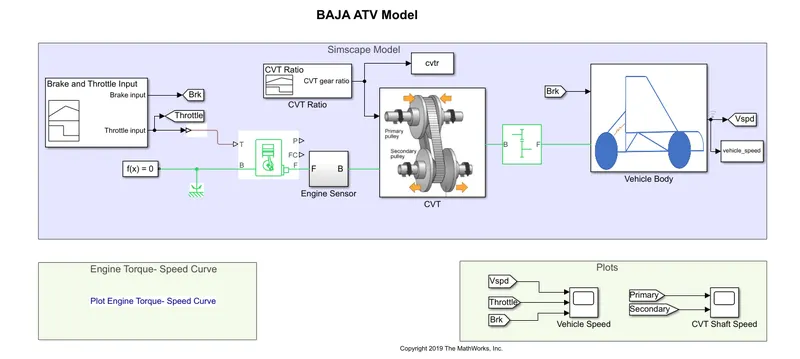
Explanation:
- Here we used the lookup table to visualize the results.Lookuptable is the array of data which is used to map the input values to output values.
- In other words the lookup table computes the mathematical function of the model i.e y=f(x).
- We used this lookup table to give the input values as cvt and vehcle speed and maped out the reults.
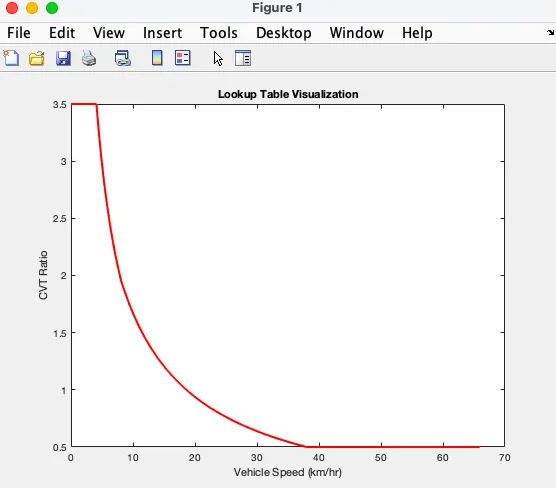
- Below we can see the lookup table plot according to which we gave as input values as initially the cvt ratio was 3.5 upto some 5-6 kmph speed and after that with increasing speed the cvt ratio starts decreasing and cvt ratio became 0 after speed was 38kmph and throughout the cvt was 0 for vehicle spee ahead.
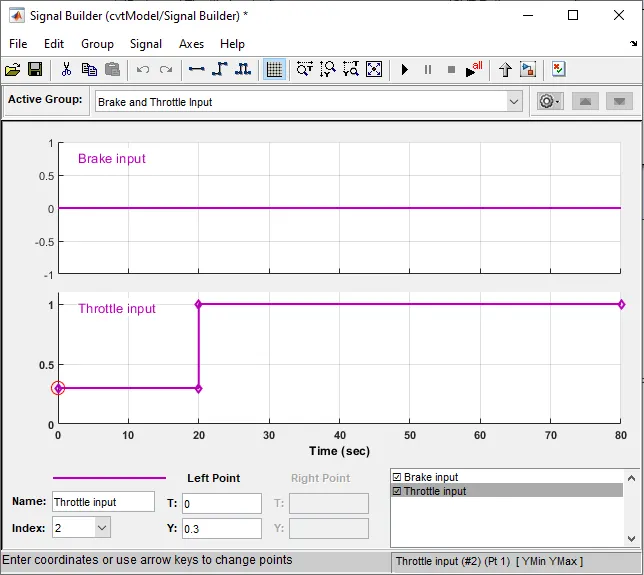
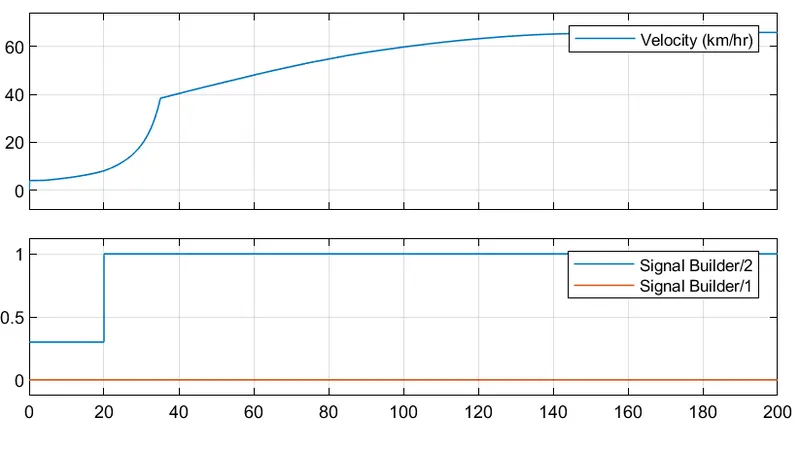
- From this signal builder we can understand that the input for brake is always zero for all conditions and the throttle input is 0.3 upto 20 sec of time and then its been increased to 1 and kept constant upto 80 sec.
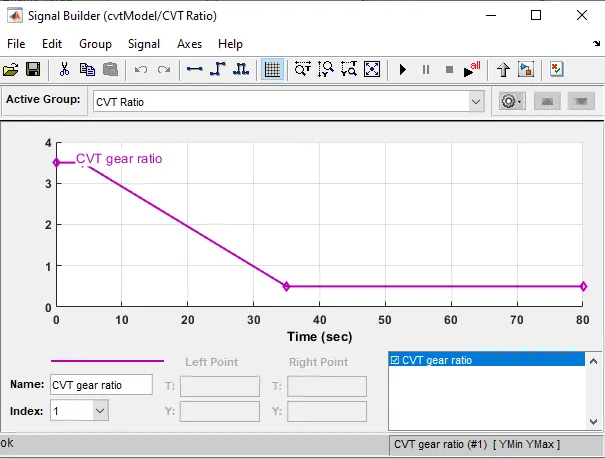
- Below signal builder block is for CVT gear ratios and by looking at that plot we can see that the input which we gave is 3.5 initially at 0 sec and this is gradually decreasing to 0.5till 35 sec after 35 sec the gear ratio is kept constant upto 80 sec which 0.5.
Output:
- After using the lookup table input values we observe that the velocity initially started increasing from 0 to 3.5 after that as the cvt ratio was in decreasing manner by increasing in speed we can observe here in plot the curve which is parablic form and afte some time when cvt value is zero velocity was constant and this plot also the after some time speed is linearlyincreasing manner and after some time it attains linearity without any varies in speed.
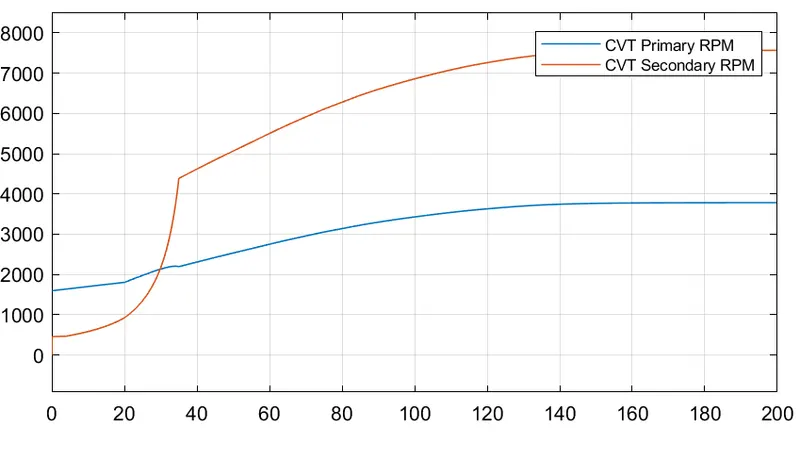
- Here by looking at plot the primary cvt at initial throttle value upto 20 sec it seems to be increasing lineraly and after increasing throttle value from 0.5 to 1 there some deviations in rpm upto 38 sec and after 40 sec rpm is been seen linearly increasing at constant throttle.
- In secondary cvt at output shaft it is been seen that the input throttle given to variable gear ratios its increasing with some losses and after some time i.e 140 s the cvt values matches with primary cvt which is constant till 200sec.
4-Simulink model with dashboard and using lookup tables for input values:
Simulink model:
Explanation:
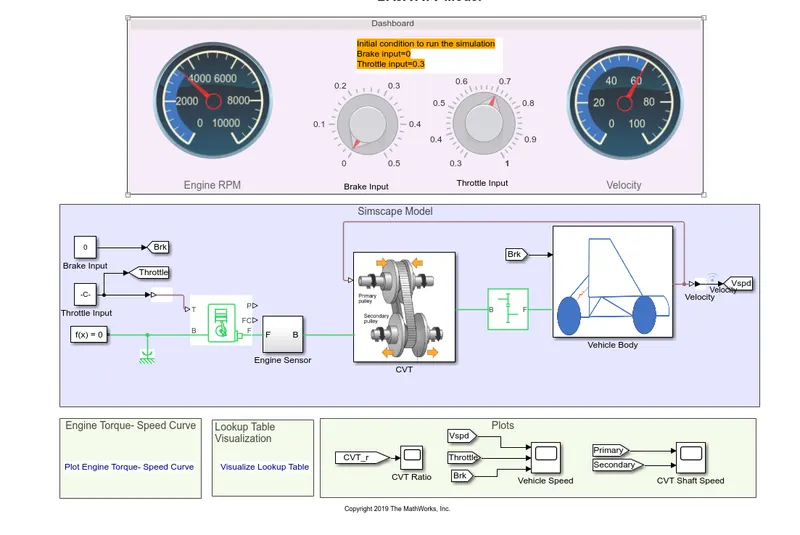
- Here we used the lookup table for input values for cvt ratio and vehicle speed and through knob we changed the throttle values to 0.7 and brake input is kept at zero.
- Lookuptable is the array of data which is used to map the input values to output values.
- In other words the lookup table computes the mathematical function of the model i.e y=f(x).
- We used this lookup table to give the input values as cvt and vehcle speed and maped out the reults.
Output:
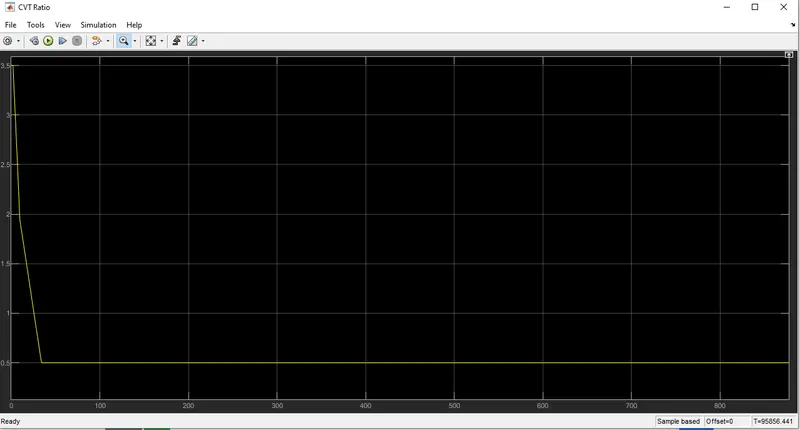
- Here by observing cvt ratio plot we see that initiall the ratio was 3.5 and after that it started dercreasing with respect to increase in speed and was constant at 0.5 after 60kmph speed of the vehicle.
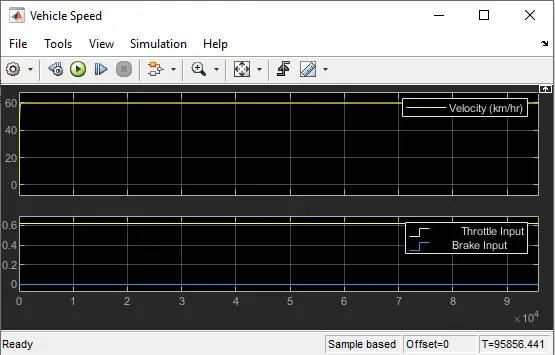
- Here by observing vehicle speed plot speed was not linear for some time with decreasing cvt ratio after that it attended the linear speed as the cvt ratio became constant at 0.5 and throttle was kept constant at 0.7.
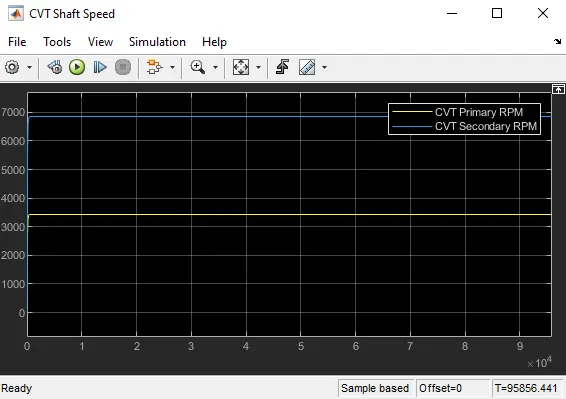
- In secondary and primary cvt rpm at input shaft primary cvt rpm was increasing in non linear manner upto 3500 rpm and after that as the cvt ratio got constant the input shaft rpm became constant and same as for secondary cvt rpm the rpm at output shaft after cvt ratio became constant the rpm was 6800 rpm and was constant throughout.
Conculsion:
We studied all the conditions of baja atv where we used lookup table for 2 conditions and for 2 conditions we manually changed the values by changing parameters and knob values and ploted the results.