Project
System-level simulation of an all-terrain vehicle:
INTRODUCTION
Carry out a system-level simulation of an all-terrain vehicle and prepare a technical report explaining the model properties & comments on the results.
ALL TERRAIN VEHICLE:
An all-terrain vehicle (ATV) is defined as a motorized off-highway vehicle designed to travel on four low-pressure or non-pneumatic tires, having a seat designed to be straddled by the operator and handlebars for steering control.
ABSTRACTION
This paper presents the modelling and analysis of path-following planning motion of an All-Terrain Vehicle (ATV) using system identification technique in term of yaw stability. The modelling is based on the single track and established by using Newtonian equation motion. Mathematical modelling is constructed in form of state space equation with the parameters used are measured through physical measurement of prototype ATV. Based on this model selection, the open loop system is simulated and the result will be validated by using system identification. Inertial Measurement Unit (IMU) sensor is used to collect and measure the data for the path-following planning. The analysis results for yaw stability of prototype ATV are validated by system identification method with step response approach. Both of the simulated.and measured data is compared and the data is estimated to get the best fit for yaw estimation by using complimentary filter technique. From the result, the best fit for yaw estimation is 91.96% and considered as stabilized at steering angle of 45°.
OBJECTIVE
- Study the baja ATV model without dashboard.
- Study the baja ATV model with dashboard.
- This ability to seamlessly shift through these different gears provides a number of benefits including extremely smooth shifts and exceptional fuel economy. A CVT draws top engine power from a small engine, which gives drivers quicker acceleration than standard automatic transmissions. Because of their greater ability to control the engine speed range, CVTs produce fewer emissions. CVTs are also lighter weight than traditional automatic transmissions.
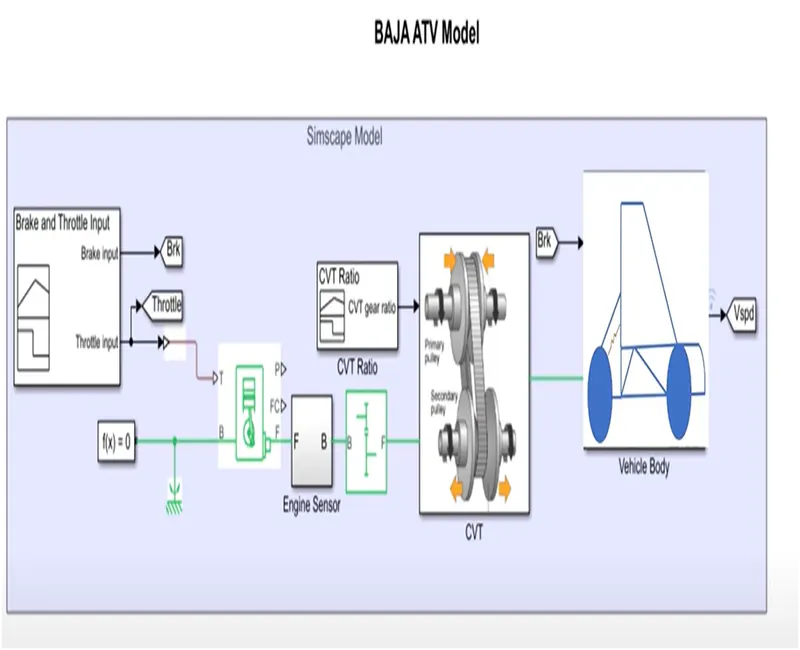
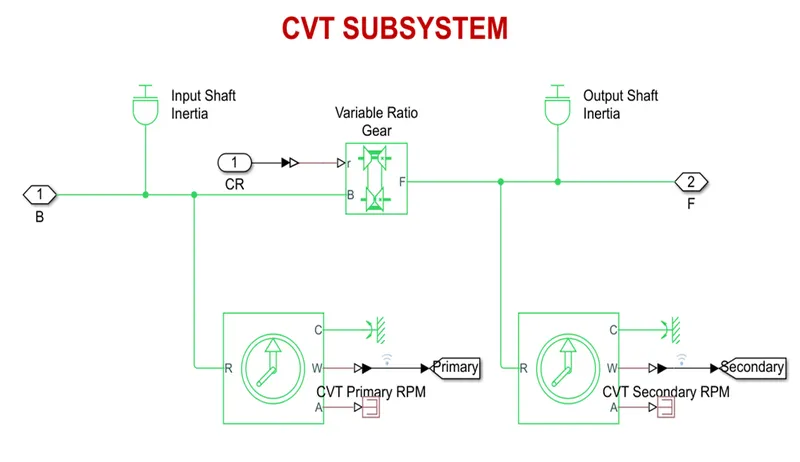
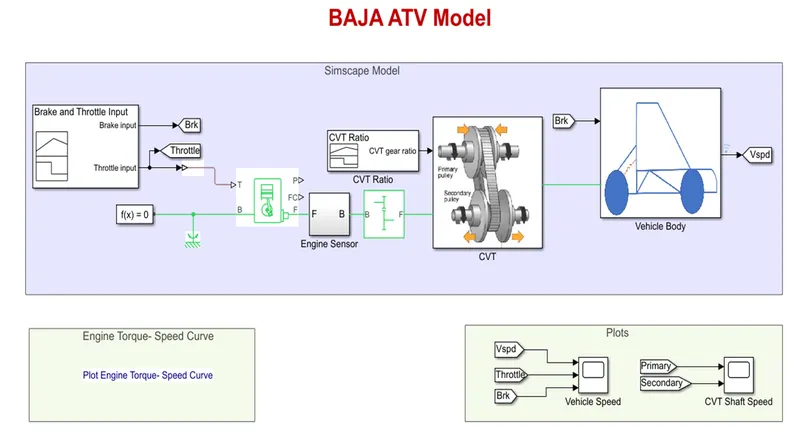
- By using simulink model of CVT consists of Signal builder, generic engine, motion sensors, vehicle transmission, vehicle body,tyres and solver configuration blocks etc., as shown in figure-1. The CVT subsystem includes Transmission block, input and output shaft inertia and motion sensors as shown in figure-2. The vehicle body subsystem includes vehicle body block, double drum brake and tyres as shown in figure-3. The initial engine speed is given as 2100 rpm, mechanical rotation for driven pulley and driver pulley as 0.8 & 0.7 respectively. The mass of the vehicle as 250kg and 2 axles which connects 4 wheel accordingly.
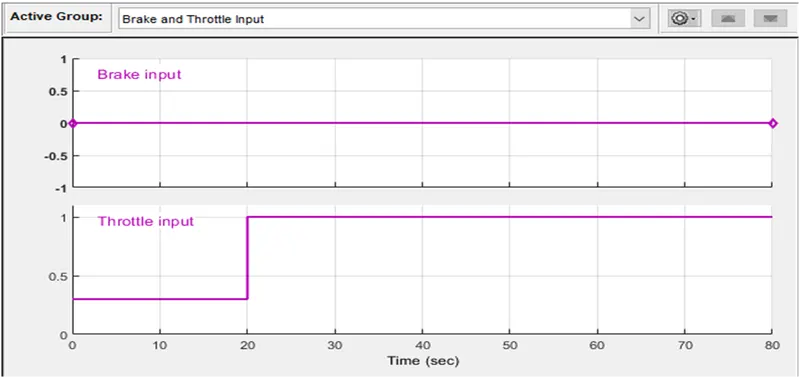
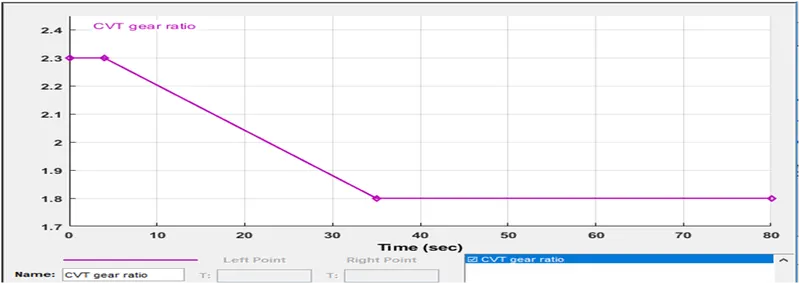
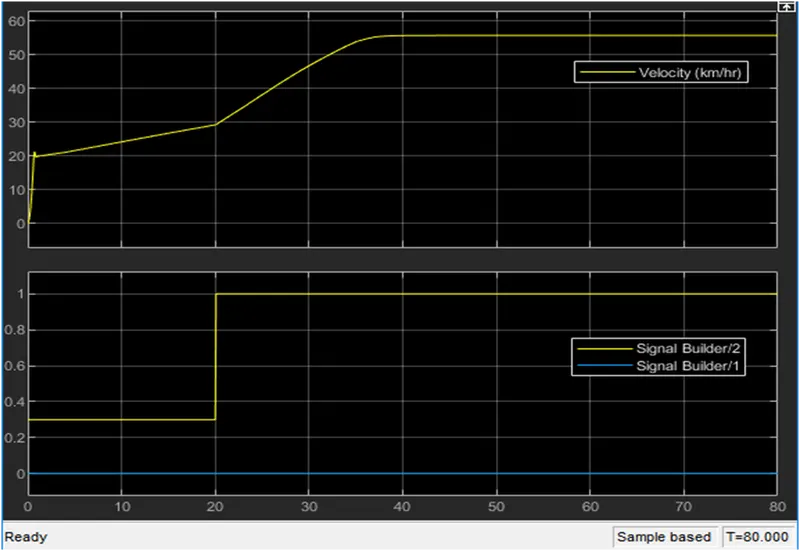
The signal builder is used as input for brake, throttle and gear ratio. Brake input is maintained as 0 for overall simulation. The throttle input is given as 0.3 for20 secs and increases to 1 for overall simulatuion. The throttle valve is mainly to control the flow or amount of fuel into the engine, if the throttle value increases the flow of fuel increases to the IC engine which inturn increases the power of the engine. The gear ratio is maintained as 2.3 for 5 secs and linearly decreases to 1.8 and maintained constant for overall simulation as shown in figure.
Cvt gear ratio:
Study the baja ATV model with dashboard included LOOKUP CHART
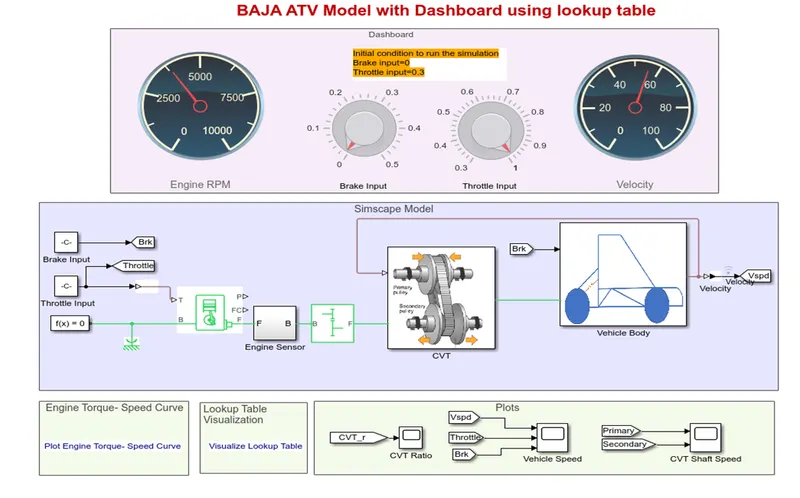
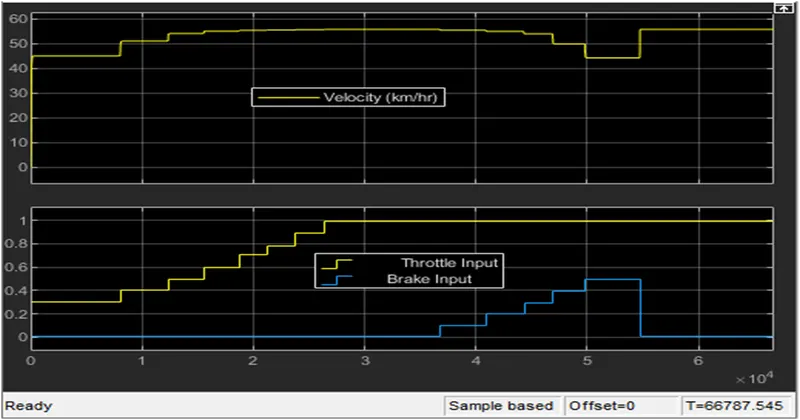
The above figure shows 'Baja ATV with dashboard' model using lookup table which consists throttle meter and brake input in the dash board and indicated as constant block. Rest of the blocks and subsystems are common in the above baja ATV model without dash board as shown in figure 8 & figure 9. The main concept of using dash board is study the result by varying the input of brake and throttle, which shows that the variation of velocity and speed of the engine. The gear ratio is given by lookup table, simulink get the input value from the lookup table and obtain the result according to the lookup table. As the brake input varies from 0 - 0.5, the velocity and speed decreases accordingly which inturn the gear ratio also decreasing. By increasing the throttle, the velocity and speed of the engine & shaft increases. The transmission as primary pulley and secondary pulley, in which the radius of primary pulley increses by compacting and the radius of secondary pulley decreases. As the gear ratio varies, the torque also varies. Gear ratio is directly proportional to the torque, which increases by increasing the gear ratio. At the max torque, the speed and velocity is decreases.
OUTPUT:Study 1:- Variation of velocity & Shaft speed:
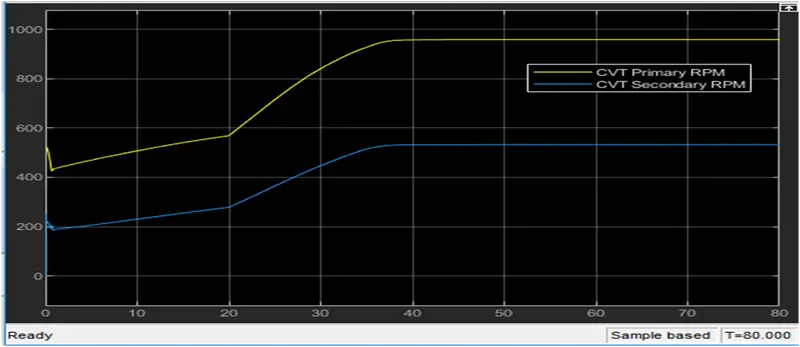
In the above figure, the primary shaft reaches high speed and secondary shaft as low rotational speed because the radius of the primary shaft as more than the secondary shaft, the speed is directly proportional to the radius of the shaft. As the radius increases the speed of the shaft also increases.
Study 2:- Variation of velocity & Shaft speed
In the above figure, the primary shaft speed increases by increasing throttle and decreasing by increasing brake input value, which defines that the throttle can flow more amount of fuel which increases the power of the engine and similar to the secondary shaft. The radius of the primary shaft as more than the secondary shaft, the speed is directly proportional to the radius of the shaft. As the radius increases the speed of the shaft also increases.
Study 3:- Variation of velocity & Shaft speed
In the above figure, the velocity of the vehicle is maintained as constant for constant throttle value as 0.3 and varying by increasing the value of throttle which increases the velocity of vehicle. By increasing the brake input, the velocity of the vehicle decreasing accordingly which shown in figure18. By using lookup table, it works as closed loop by recording the velocity value and we can get at any particular value of gear ratio which is beyond the range or any random value within the range by using extrapolation and interpolation by lookup table.
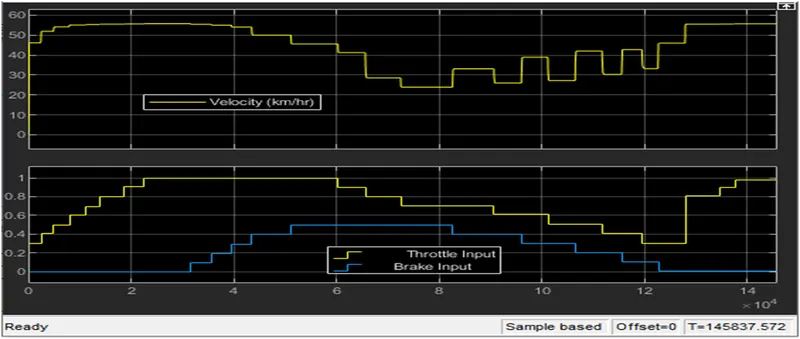
In the above figure, the velocity of the vehicle is maintained as constant for constant throttle value as 0.3 and varying by increasing the value of throttle which increases the velocity of vehicle. By increasing the brake input, the velocity of the vehicle decreasing accordingly which shown in figure18. By using lookup table, it works as closed loop by recording the velocity value and we can get at any particular value of gear ratio which is beyond the range or any random value within the range by using extrapolation and interpolation by lookup table.
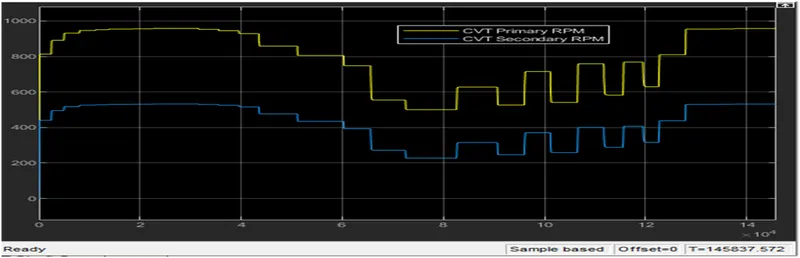
In the above figure, the primary shaft speed increases by increasing throttle and decreasing by increasing brake input value, which defines that the throttle can flow more amount of fuel which increases the power of the engine and similar to the secondary shaft. The radius of the primary shaft as more than the secondary shaft, the speed is directly proportional to the radius of the shaft. As the radius increases the speed of the shaft also increases. The throttle value and brake input value can be varying in dashboard, so we can get any particular value for input.
CONCLUSION:
- As the throttle increases, the velocity also increases which inturn the power in the engine also increases.
-
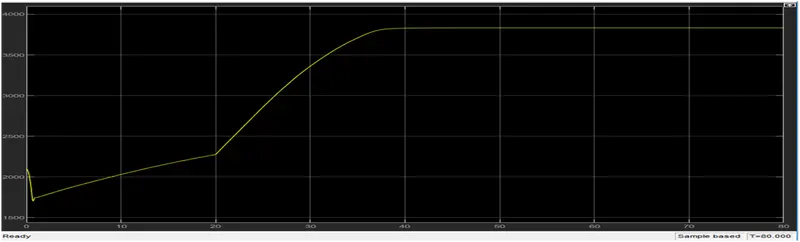
In the above figure, at the begining the speed reducing because of gear ratio and torque output. When the gear ratio increases, the torque increases.
As the brake input increases, the velocity decreases and engine power also decreases. At a certain brake input value the engine may shut down and there is no power output. The engine power is inversly proportional to the brake input.
- As the gear ratio increases, torque increases which inturn the velocity decreases.
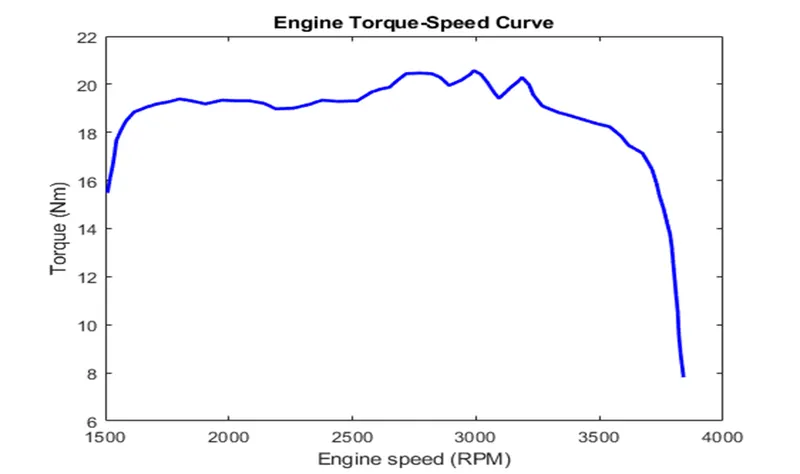
In the above figure, the torque is increasing by increase in engine speed. At a particular point the the torque is decreasing when the gear ratio increases inorder to achieve maximum velocity.
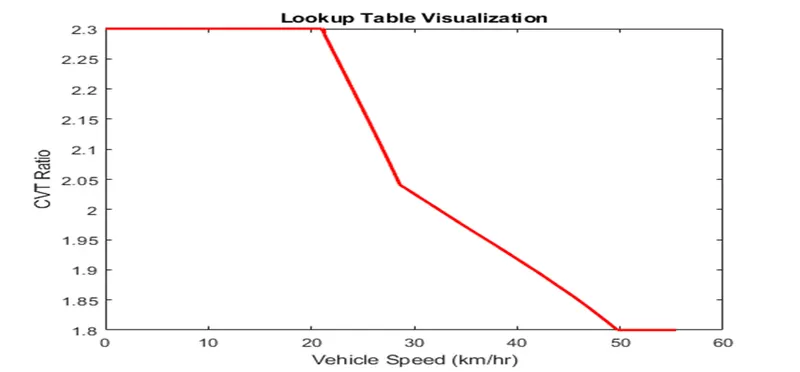
-
In the above figure, the velocity is varying wrt the gear ratio. For the high gear ratio, the torque is more which decrease the velocity. By changing to high gear, the gear ratio become less paralelly the torque also less which can get high velocity.
With help of lookup table, we can vary any input value and also get the output value by using interpolation and extrapolation method which the simulink can solve.